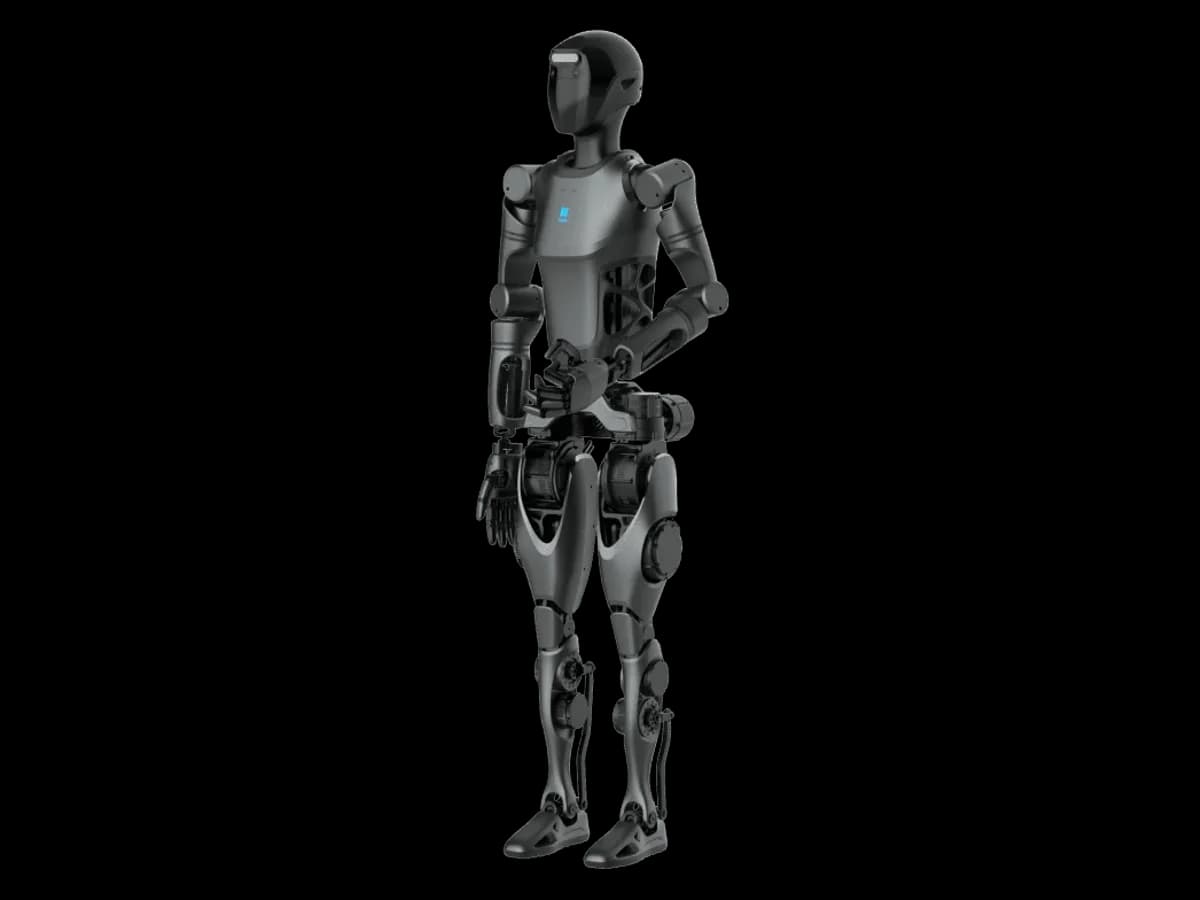
The UBTECH Walker X is a 130 cm, 63 kg humanoid robot carrying 41 high-performance servo joints. The head holds a 4.6K dual flexible curved screen wrapping 160 degrees and a four-dimensional light language system.
Read moreShow less
The arm has seven and the force-controlled human-like hand six degrees of freedom. Navigation uses U-SLAM, with a stated localisation accuracy of 10 cm, navigation accuracy of 20 cm and fine localisation accuracy of 1 cm. Maximum walking speed is 3 km/h, maximum uneven terrain adaptation 3 cm, maximum step height 15 cm and maximum slope angle 20 degrees. The 54.6V 10Ah lithium battery weighs 3.6 kg and charges in two hours; it is removable and the body is modular.
Enterprise supply · specification support · integration engineering
1/6
Overview
The UBTECH Walker X is a 130 cm, 63 kg humanoid robot carrying 41 high-performance servo joints. We supply UBTECH platforms to corporate projects in Turkey through enterprise supply, commissioning and technical integration. Configuration, delivery terms and investment are set by corporate quotation.
Navigation uses U-SLAM, and the manufacturer gives three separate accuracy figures: 10 cm localisation accuracy, 20 cm navigation accuracy and 1 cm fine localisation accuracy. Three tiers make sense, because moving along a corridor and grasping an object demand different precision.
The terrain envelope is given in numbers too: a maximum up and down slope of 20 degrees, a maximum step height of 15 cm, maximum uneven terrain adaptation of 3 cm and a maximum walking speed of 3 km/h. Those three limits directly determine where the robot can go in a building.
The arm has seven and the force-controlled human-like hand six degrees of freedom. The head carries a 4.6K dual flexible curved screen wrapping 160 degrees and a four-dimensional light language system. The body is modular and the battery is easily removable.
The battery is 54.6V 10Ah lithium, weighs 3.6 kg and charges in two hours. 546 Wh of capacity cannot be converted into hours without consumption.
The capabilities the manufacturer foregrounds are terrain adaptation, balance under disturbance, object manipulation through hand-eye coordination, whole-body flexibility for safe interaction, autonomous path planning with U-SLAM, environment and human perception, visual intelligence for human-like communication and smart home control.
3 videos: manufacturer footage and field recordings. Tap a cover to play.
UBTECH Walker X product video
UBTECH Walker X product video
UBTECH Walker X product video 2
Use Cases
The use cases the manufacturer defines for the UBTECH Walker X.
01Companionship and home
02Performance and events
Key Advantages
Three Tiers of Localisation Accuracy
The Walker X's most concrete technical data is navigation accuracy.
10 cm localisation accuracy, 20 cm navigation accuracy and 1 cm fine localisation accuracy.
Three tiers make sense, because 20 cm suffices while a robot moves along a corridor but 1 cm is needed to grasp a door handle.
Publishing that distinction shows the manufacturer has actually measured the system.
The Terrain Envelope: 20 Degrees, 15 cm, 3 cm
The manufacturer gives three terrain limits: a maximum up and down slope angle of 20 degrees, a maximum step height of 15 cm and maximum uneven terrain adaptation of 3 cm.
Those three numbers directly determine where the robot can go in a building.
A 15 cm step is slightly below a standard indoor stair riser, which means the robot cannot climb every staircase.
A deployment decision should follow that envelope.
The Curved Head Screen and Light Language
The head carries a 4.6K dual flexible curved screen wrapping 160 degrees and a four-dimensional light language system.
On an interaction robot the screen does not merely show information; it conveys where the robot is looking and what it registers, and wrapping 160 degrees means someone standing to the side can also read the expression.
The light language system adds a second channel on top.
The UBTECH Walker X up close
3 images; tap to enlarge.
Technical Specifications
31 values in 6 categories; data published by the manufacturer.
Size and weight
Dimensions (standing)
130 cm tall
Weight
63 kg
Arm reach
Single arm 600 mm
Motion and performance
Arm payload
1.5
Maximum speed
3 km/h
Climb angle
20°
Obstacle and step
15 cm
Joint torque
4.5-200 Nm
Motor speed
30-90 rpm
Positioning accuracy
Localization accuracy of 10cm; fine localization accuracy of 1cm
2 h under combined working conditions; charging time 2 h
Charging time
2 h
General structure
Mobility form
Bipedal humanoid handling up to 20 degrees of slope, 15 cm steps and 3 cm of uneven terrain
Degrees of freedom
41 high-performance servo joints; seven per arm and six in the force-controlled hand
Arm DoF
7 DoF
Leg DoF
6 DoF
Neck DoF
3 DoF
Materials
Modular design with a removable battery
Manufacturer note
Single arm span 600 mm. Maximum uneven terrain adaptation 3 cm. The load figure applies with the arm in the extended state. It can carry 10 kg of weight or walk with 3 kg of weight on both hands.
DoF layout
41 high-performance servo joints; seven degrees of freedom per arm and six in the force-controlled human-like hand
Structure and materials
130 cm and 63 kg with a modular design and an easily removable battery
Joint module
A force-controlled human-like hand; whole-body flexibility is aimed at safe interaction
Size and weight
Dimensions (standing)
130 cm tall
Weight
63 kg
Arm reach
Single arm 600 mm
Motion and performance
Arm payload
1.5
Maximum speed
3 km/h
Climb angle
20°
Obstacle and step
15 cm
Joint torque
4.5-200 Nm
Motor speed
30-90 rpm
Positioning accuracy
Localization accuracy of 10cm; fine localization accuracy of 1cm
U-SLAM navigation with autonomous path planning; 10 cm localisation accuracy, 20 cm navigation accuracy and 1 cm fine localisation accuracy. The head carries a 4.6K dual flexible curved screen wrapping 160 degrees and a four-dimensional light language system
Sources and documents
Verified on the manufacturer page on 18 September 2026.
Analysis of an Interaction-Focused HumanoidDesign decisions, comparison table and evaluation
What 130 cm Means
The Walker X is noticeably shorter than the industrial humanoids: the Walker S2 is 176 cm and the Walker C 163 cm. At 130 cm it comes to eye level with a seated adult or a standing child. The 63 kg weight is high for that height, though; the Unitree G1 at a similar height is 35 kg. The difference comes from the Walker X carrying heavy components such as 41 servo joints and a force-controlled hand. The practical consequence is that the robot is deployable rather than portable.
The Walker X Against Humanoids of Similar Height
Feature
UBTECH Walker X
UBTECH Panda Robot
Unitree G1
Height
130 cm
130 cm
132 cm
Weight
63 kg
63 kg
35 kg
Degrees of freedom
41
41
23 (up to 43 on the EDU)
Speed
3 km/h
3 km/h
2 m/s
Battery
54.6V 10Ah, two-hour charge
54.6V 10Ah, two-hour charge
Approximately two hours of runtime
Sourcing in Turkey
Enterprise supply
Enterprise supply
Orderable
Engineering Assessment
The Walker X is among the most technically transparent models in the UBTECH family. Giving three tiers of localisation accuracy and the terrain envelope as numbers makes it directly calculable where the robot can be deployed in a building, which most manufacturers do not do. Six degrees of freedom in the force-controlled hand and the 160-degree wrapping head screen are consistent choices on the interaction side. The 63 kg weight is also high compared with alternatives of the same height and limits portability.
Purchasing support
Supply model
Supply to Turkey is planned per project; import, delivery and commissioning scope are itemised in the quote.
Pre-sales assessment
Site and mission focused technical feasibility; specification and administrative process support.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
Supply and delivery scheduling backed directly by the manufacturer
Site- and mission-focused technical feasibility and simulation
Turnkey hardware, software and mission integration
Advisory on corporate tenders, specifications and administrative processes
The most common questions about the UBTECH Walker X.
Can the UBTECH Walker X be bought in Turkey?
We deliver UBTECH hardware to corporate projects through enterprise supply, commissioning and engineering support. Investment is set by corporate quotation against configuration, quantity and delivery terms. If you have a corporate requirement we can assess the sourcing route and timeline together. If you are looking for a humanoid of similar height deliverable today, the Unitree G1 can be ordered in Turkey.
Can the Walker X climb stairs?
Partly. a maximum step height of 15 cm, a maximum slope angle of 20 degrees and maximum uneven terrain adaptation of 3 cm. Indoor stair risers in Turkey are usually between 16 and 18 cm, so the robot cannot climb every staircase. Step height in the building should be measured before deployment; where a ramped route exists, the 20 degree limit covers most indoor ramps.
What is the difference between the Walker X and the Panda Robot?
The body is shared: both state 130 cm, 63 kg and 41 degrees of freedom, carry the same navigation accuracies and the same 54.6V 10Ah battery. The difference lies in exterior design and interaction concept. The Panda Robot was prepared with a panda appearance for the China Pavilion at Expo 2020 Dubai, with a bionic eye design and more than 28 emotion display types. The Walker X has a humanoid appearance and foregrounds smart home control.