






























































Unitree dexterous hand
Unitree Dex5-S
Announced by Unitree on 21 September 2026, the Dex5-S is a five-finger hand module at exact human-hand size. All 22 active degrees of freedom are backdrivable and every joint carries impact torque protection. Everyday objects such as scissors, a spoon or a drink can are handled as they were designed for the human hand.
- 22
- active degrees of freedom
- 1:1
- real human-hand size
- 5
- fingers
- 43 sn
- official launch video
Unitree Robotics official launch video, 21 September 2026. Footage at real speed.
Technical summary
Technical specifications.
- Degrees of freedom
- 22 active joints; all five fingers are motorised.
- Size
- Exact human-hand size (1:1). Tools and objects designed for people are used without any change of scale.
- Joint behaviour
- Every joint is backdrivable: it yields to external force instead of resisting it, which is the basis for force control.
- Protection
- Impact torque limiting protection on every joint.
- Design
- Precision biomimetic design; finger layout and motion follow the human hand.
Specifications are based on the official Unitree Robotics launch of 21 September 2026. Detailed technical documentation, dimensions, interface details and the compatibility matrix are provided by our engineering team within the project scope.
Tasks shown in the video
Objects made for people, handled like a human hand.
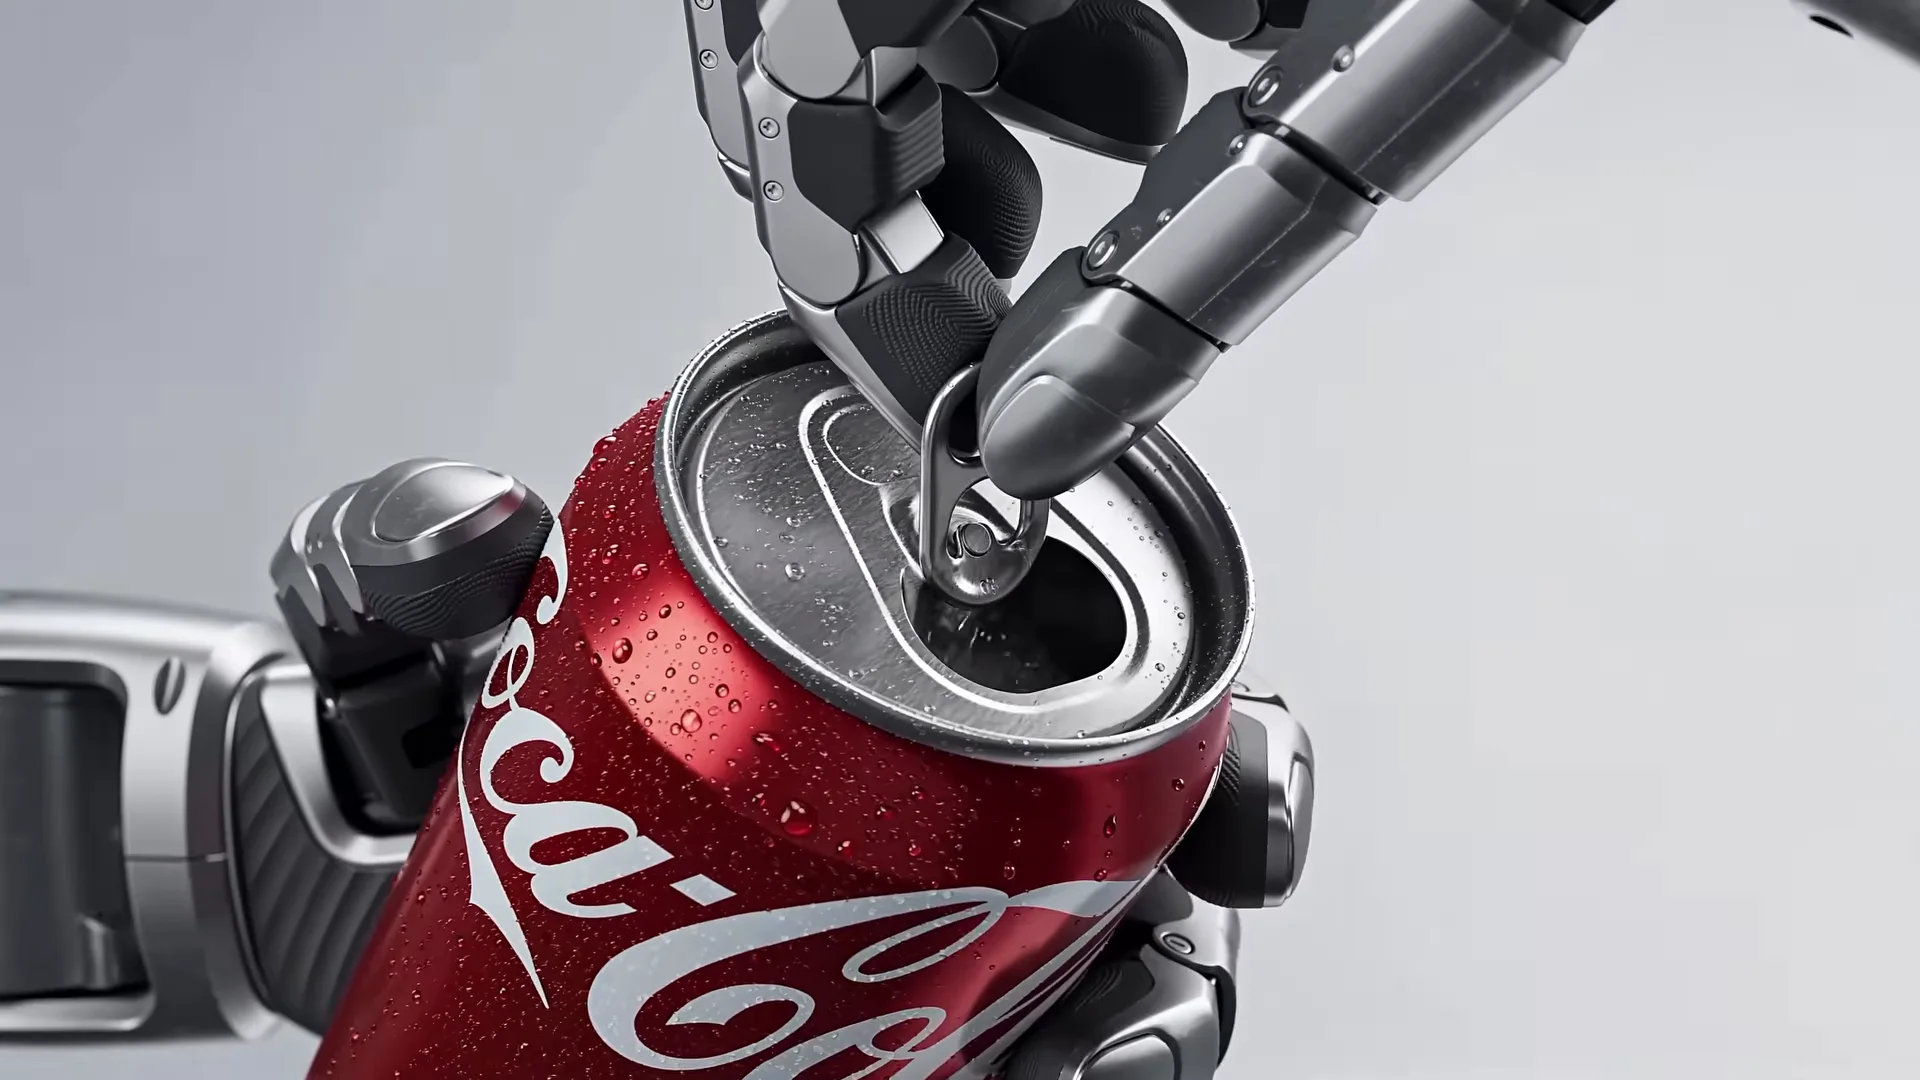
Opens a drink can's pull tab with a single finger.
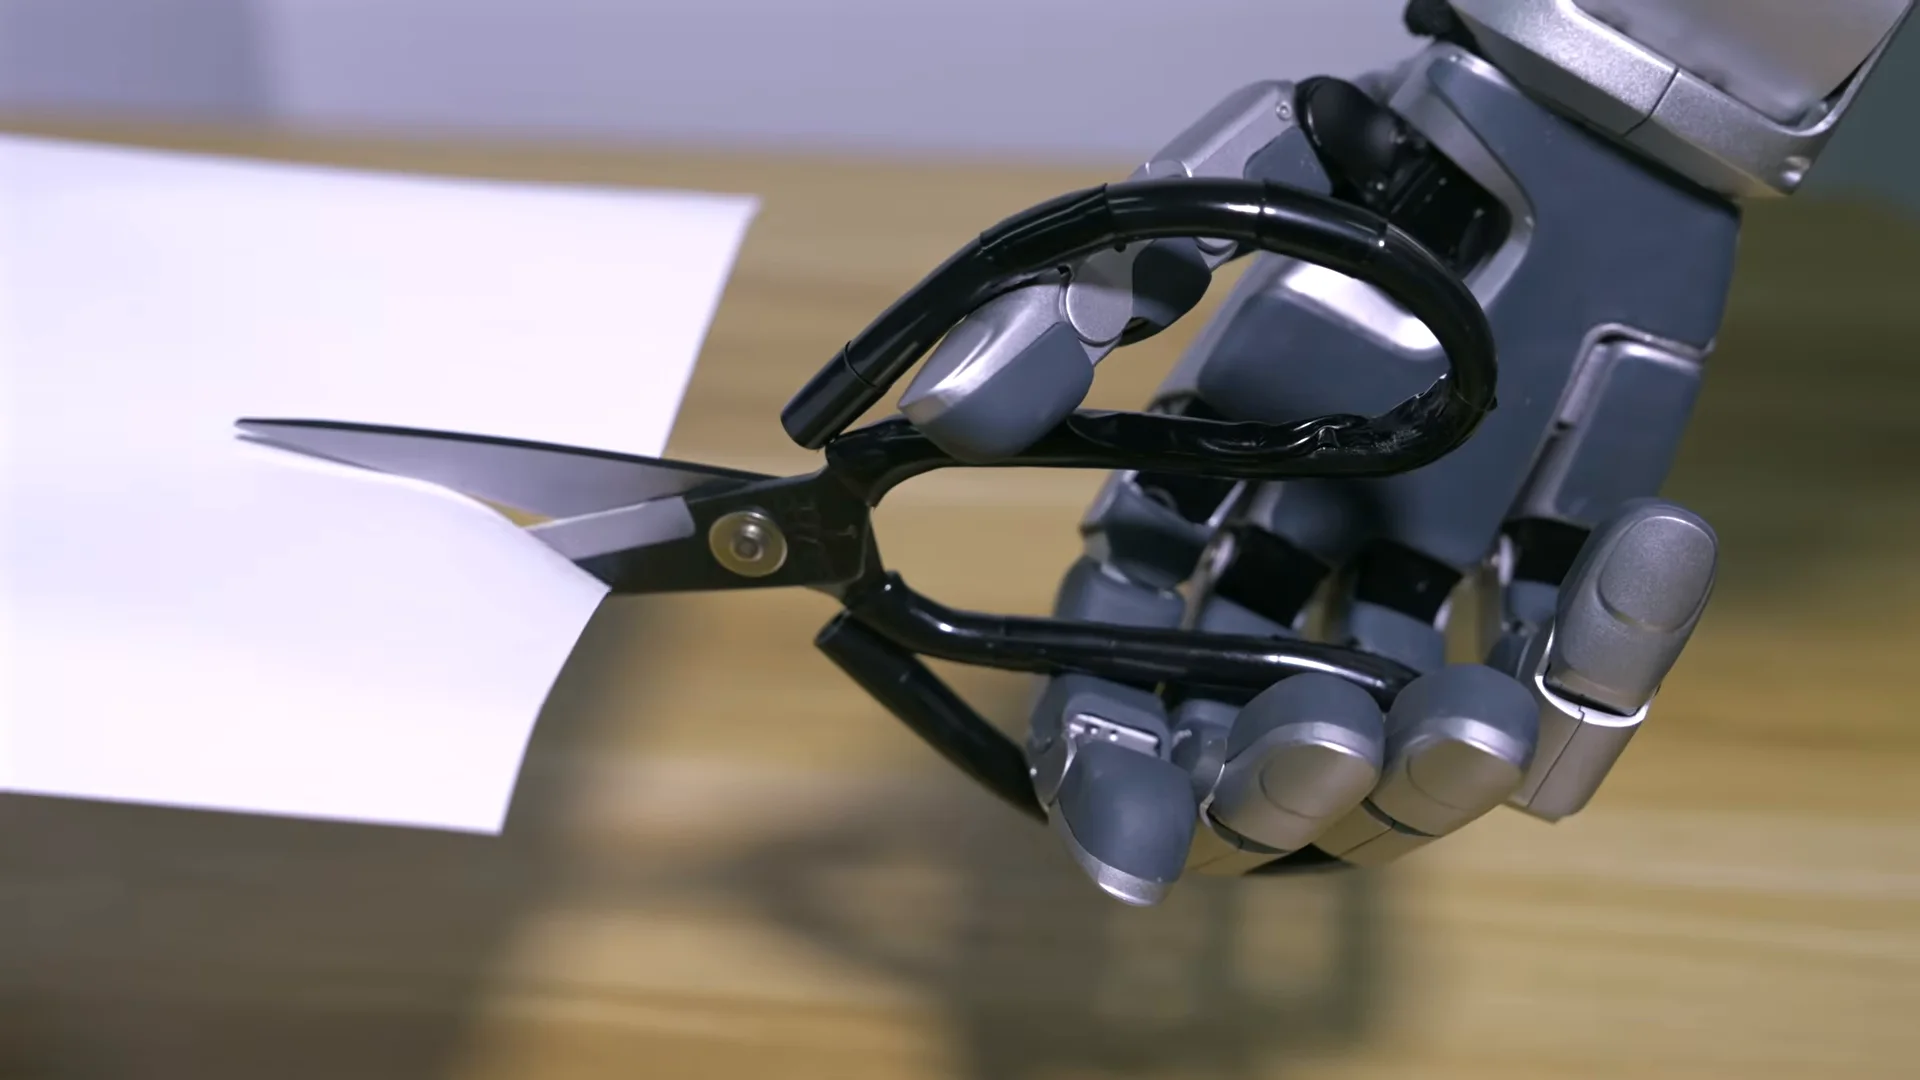
Holds scissors with a human grip and cuts paper.
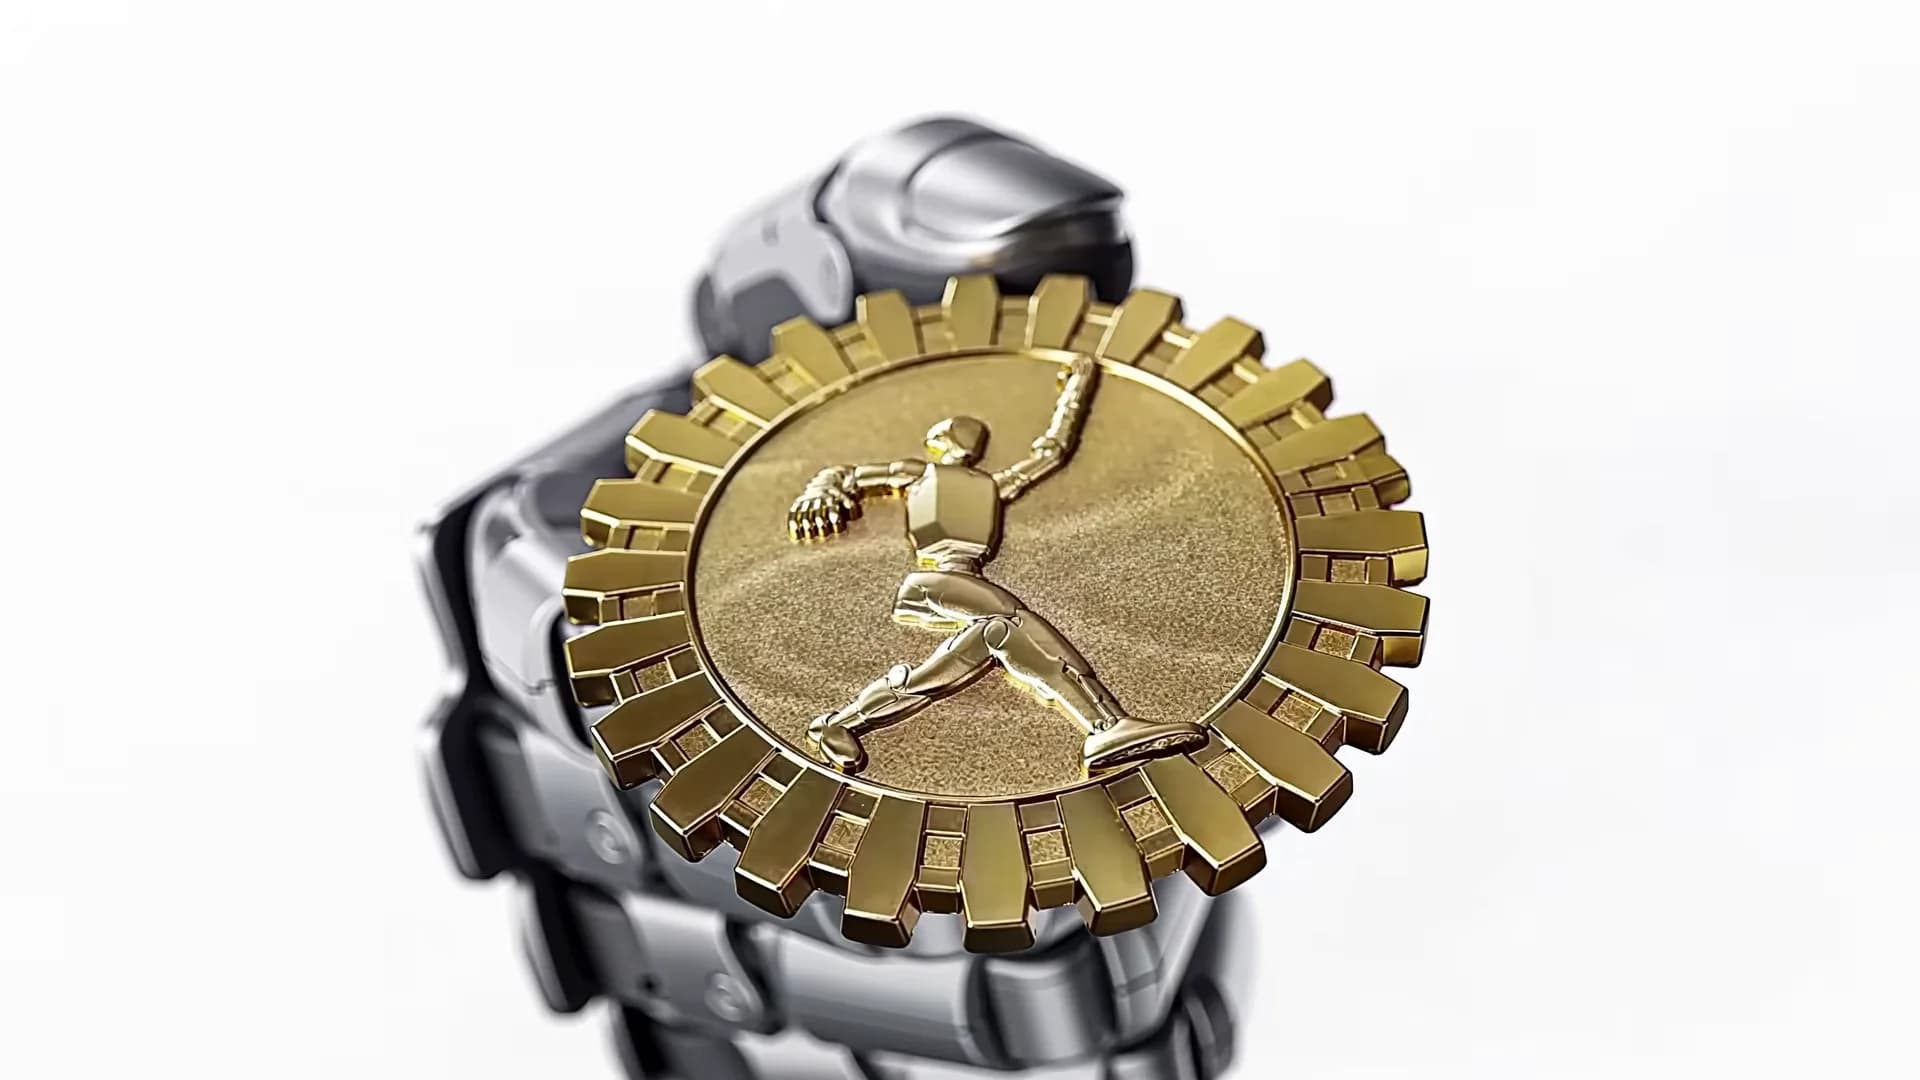
Carries a thin, flat object on its fingertips.
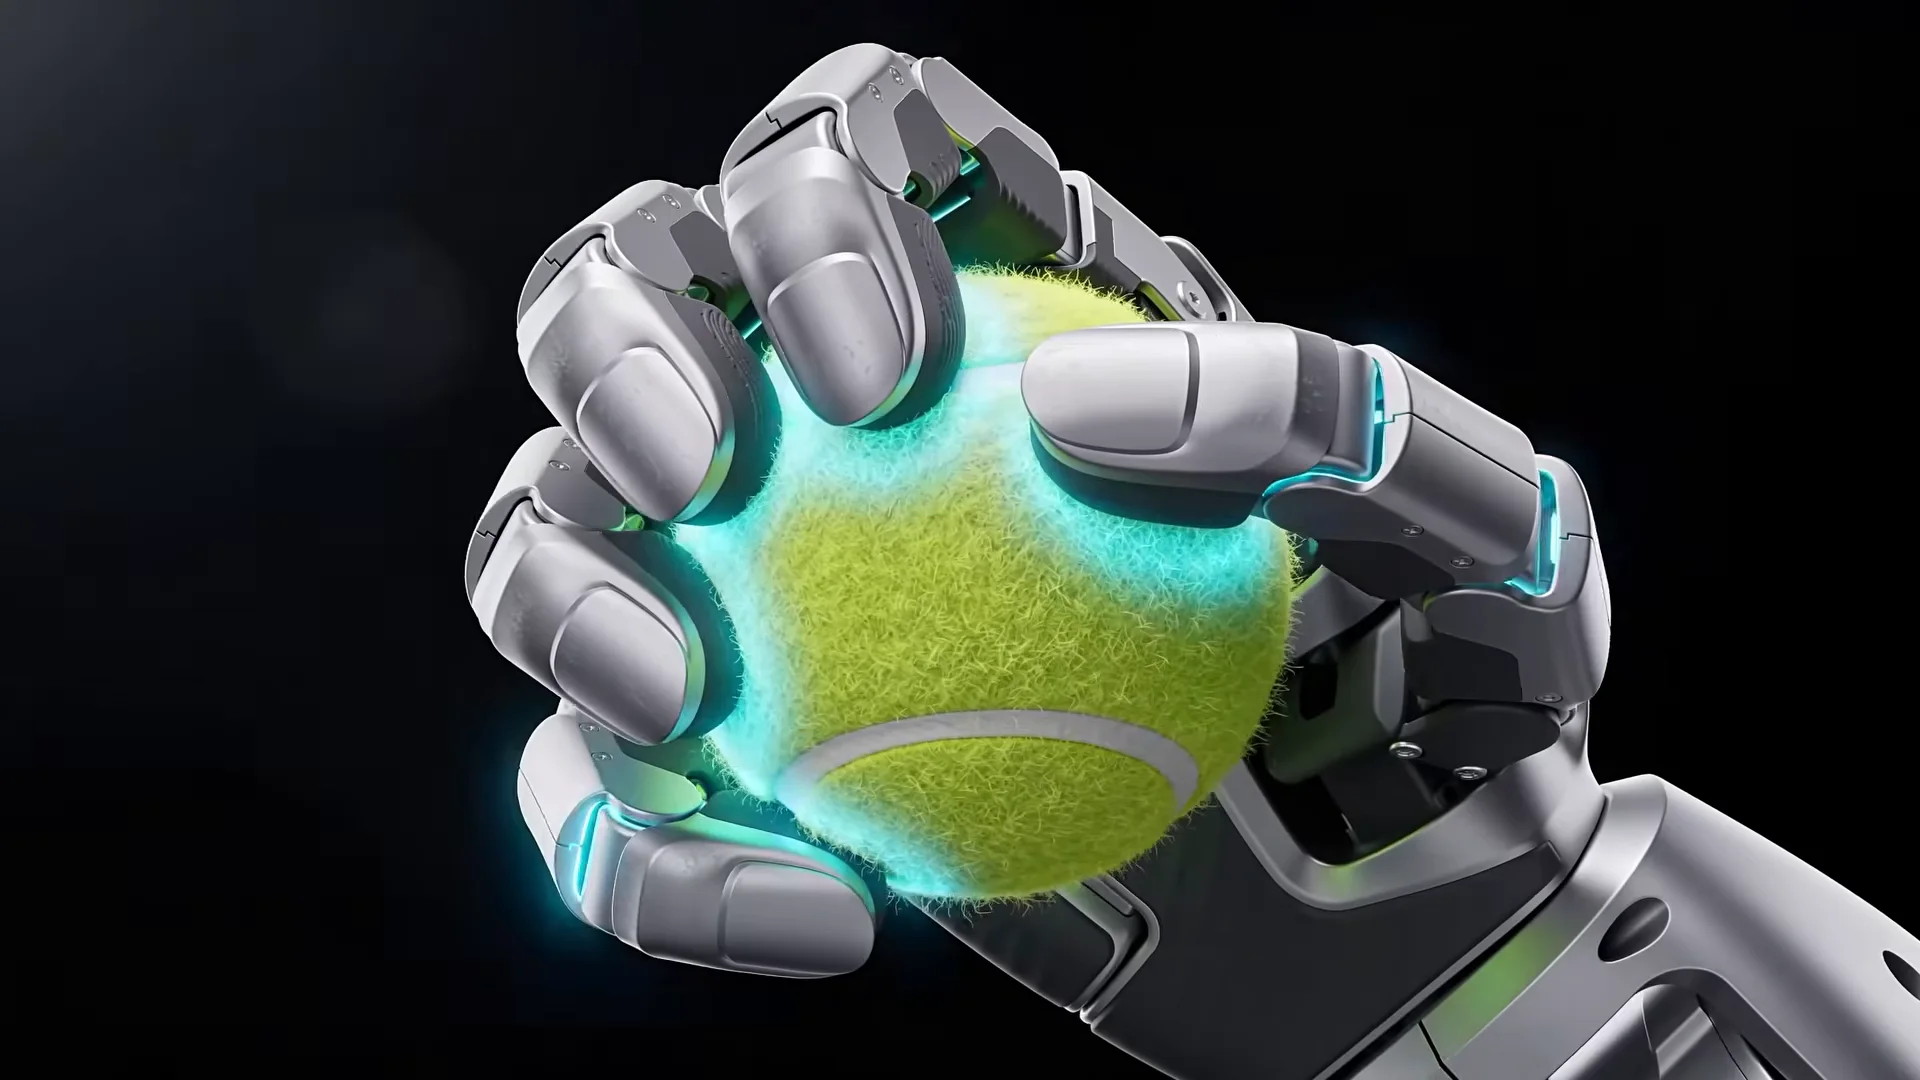
Wraps all five fingers around a tennis ball.
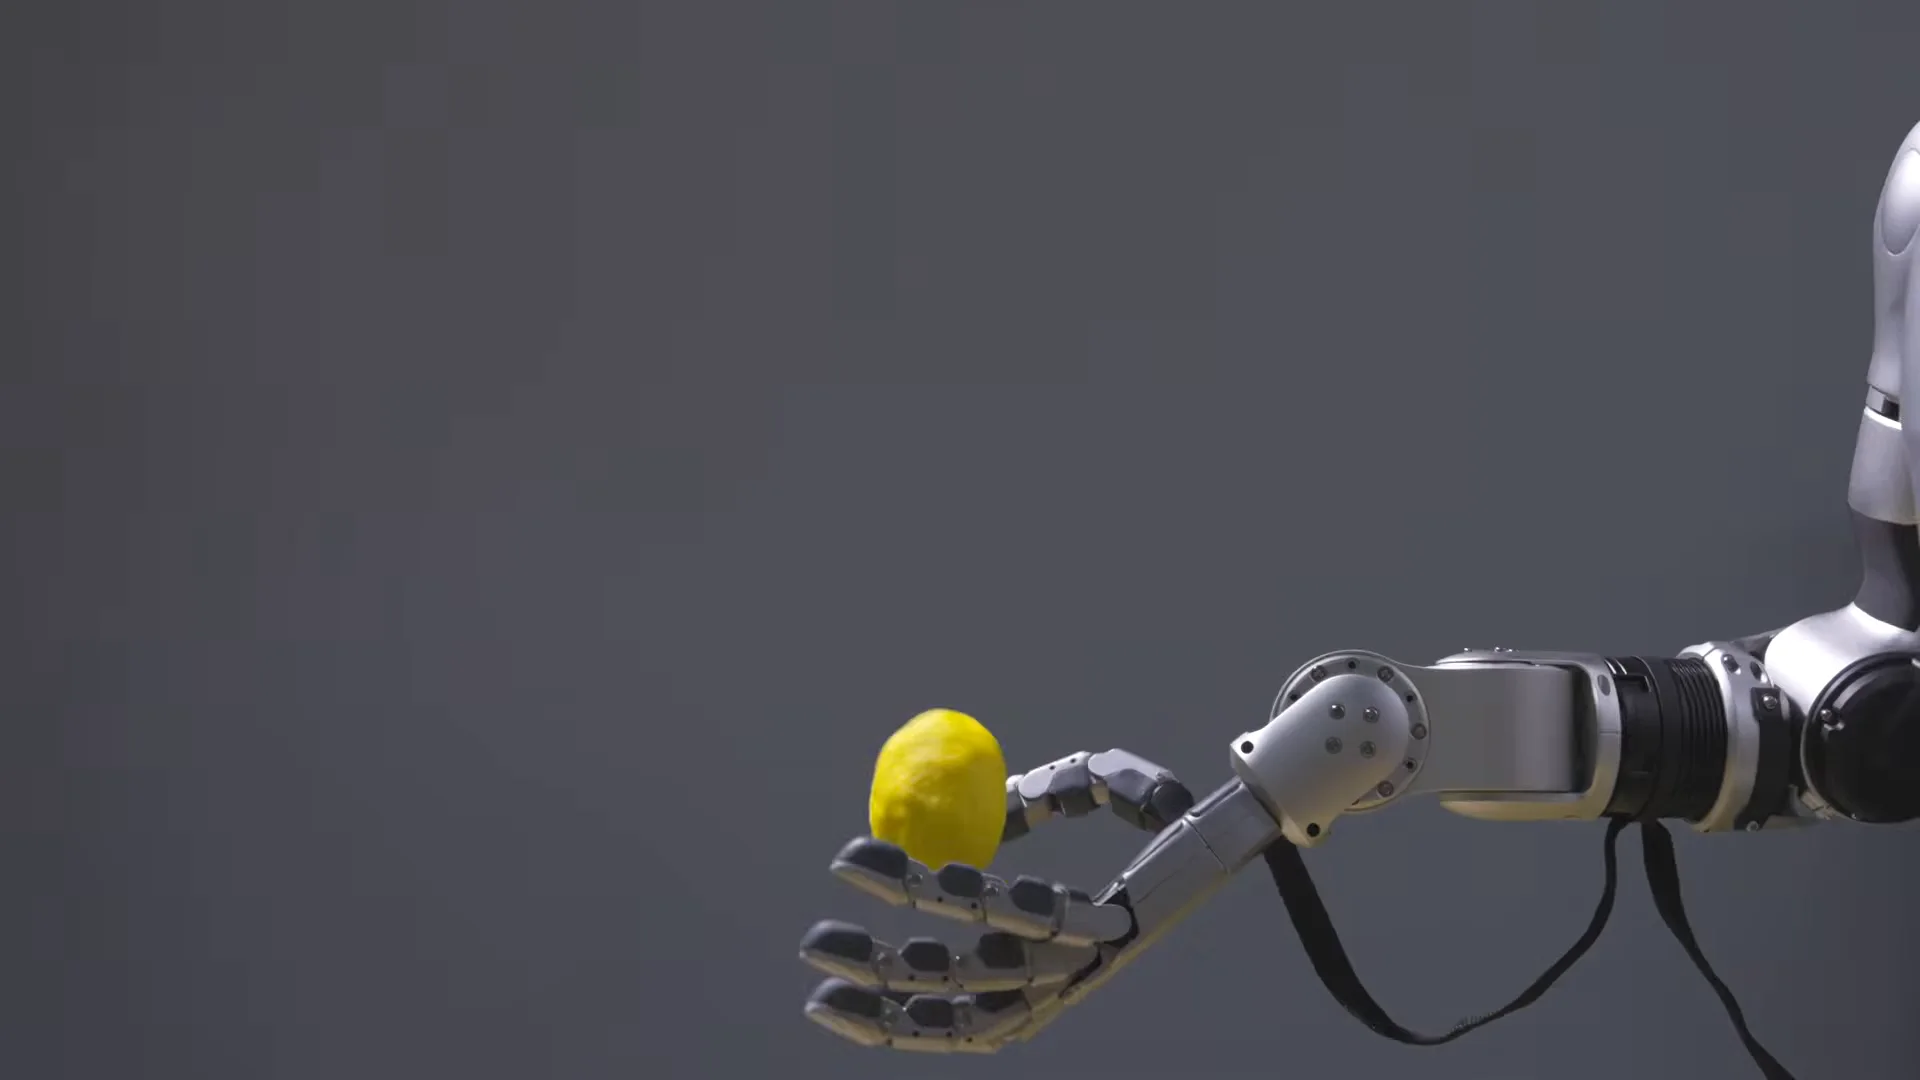
Mounted on a humanoid arm, holding a small piece of fruit.
Images: Unitree Robotics official launch, 21 September 2026.
Why it matters
Three design decisions, and what they mean in the field.
Backdrivable joints
The motor can be turned by an external force. When the hand bumps into an object, or an object slips during a grasp, the joint yields instead of resisting. Contact force is read from motor current, and grasps become soft and compliant.
Impact torque protection
During a sudden impact the torque a joint transmits is limited, so gears and motors are protected from overload. For a hand in constant contact with everyday objects this is the basis of durability.
Exact human-hand size
Scissors, spoons, keys and cans made for people are used as they are. In teleoperation and imitation learning, the human hand's motion transfers to the robot without any change of scale.
The Unitree hand family
Where the Dex5-S sits in the family.
| Model | Fingers | Degrees of freedom | Highlights |
|---|---|---|---|
| Dex1-1 | Gripper, two jaws | Single-axis grasp, 90 mm stroke | Grip force adjustable from 5 to 120 N; 550 g; compatible with G1, H2 and R1. |
| Dex3-1 | 3 | 7 (thumb 3, index 2, middle 2) | 33 pressure sensors, hybrid force and position control; 710 g; compatible with G1. |
| Dex5-1 | 5 | 20 (16 active, 4 passive) | ±1 mm fingertip repeatability; 94 tactile points on the Dex5-1P version; 1,100 g. |
| Dex5-S | 5 | 22 active | Exact human-hand size; every joint backdrivable; impact torque protection on every joint. |
Source: Unitree Robotics official product information.
Where it is used
From research to data collection.
Humanoid robot R&D
Two-handed manipulation and grasping research on full-size humanoid platforms.
Teleoperation and data collection
The operator's hand motion transfers to the robot at one-to-one scale; demonstration data is collected for imitation learning.
Model training
Demonstrations collected with human-scale objects feed vision-language-action model training directly.
Everyday-object tasks
Finger-level tasks on objects made for people: cans, scissors, spoons and keys.
Corporate quotation
Let us plan the quotation and delivery for the Dex5-S.
Robotlar.org is the Turkey Partner of Unitree Robotics; Dex5-S supply, the choice of a compatible humanoid platform and integration support are handled from one source.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
- Supply and delivery scheduling backed directly by the manufacturer
- Site- and mission-focused technical feasibility and simulation
- Turnkey hardware, software and mission integration
- Advisory on corporate tenders, specifications and administrative processes
Direct contact and advisory line: 0850 532 6 777
Frequently asked
What is the difference between the Dex5-S and the Dex5-1?
The Dex5-1 is a 1,100 g hand offering 20 degrees of freedom across five fingers (16 active, 4 passive). The Dex5-S is designed at exact human-hand size with 22 active degrees of freedom; all joints are backdrivable and every joint carries impact torque protection. The model that suits your project is selected together with our engineering team, based on your application requirements.
Which robots is it compatible with?
With its exact human-hand size, the Dex5-S is a hand module intended for full-size humanoid platforms and is shown on a full-size humanoid arm in the official launch. The hand configuration, mounting interface and software integration for your platform are defined by our engineering team within the project scope and stated in writing in the quotation.
Does it have tactile sensing?
The tactile sensing configuration and version options of the Dex5-S are defined at the quotation stage according to your application requirements. Within the Unitree hand family, tactile sensing is offered with 33 pressure sensors on the Dex3-1 and 94 tactile points on the Dex5-1P.
Why does backdrivability matter?
In a backdrivable joint the motor can be turned by an external force. When the hand bumps into an object or the object slips, the joint yields instead of resisting; force control and safe contact rest on this property. On the Dex5-S all 22 joints work this way.
How are price and delivery determined?
The price is set by the chosen version and configuration; we do not publish list prices for Unitree products. When you share your requirements, our engineering team prepares a pro forma quotation and a delivery schedule for your organisation; as the Turkey Partner of Unitree Robotics, Robotlar.org handles supply and integration support from one source.
See the full range of Unitree hand modules.
Dex1-1 gripper, Dex3-1 three-finger hand and Dex5-S, on one page.