Skip to content
Robotlar

Field Projects and Application Scenarios.

Deployed systems, completed customer installations and application scenarios in one place. Every record is classified by maturity level.

Field projects
Systems deployed or run under field conditions. Environment, hardware, workflow, measurements and limits are on record.
Customer deployments
Installations completed at customer sites: robot model, quantity and commissioning period.
Application scenarios
Drafts defining which robot class, environment and workflow a job can be built with.

Field projects

Systems deployed and run under field conditions. Every record documents the environment, task, hardware, software, workflow, operator role, safety approach, measurements and limits.

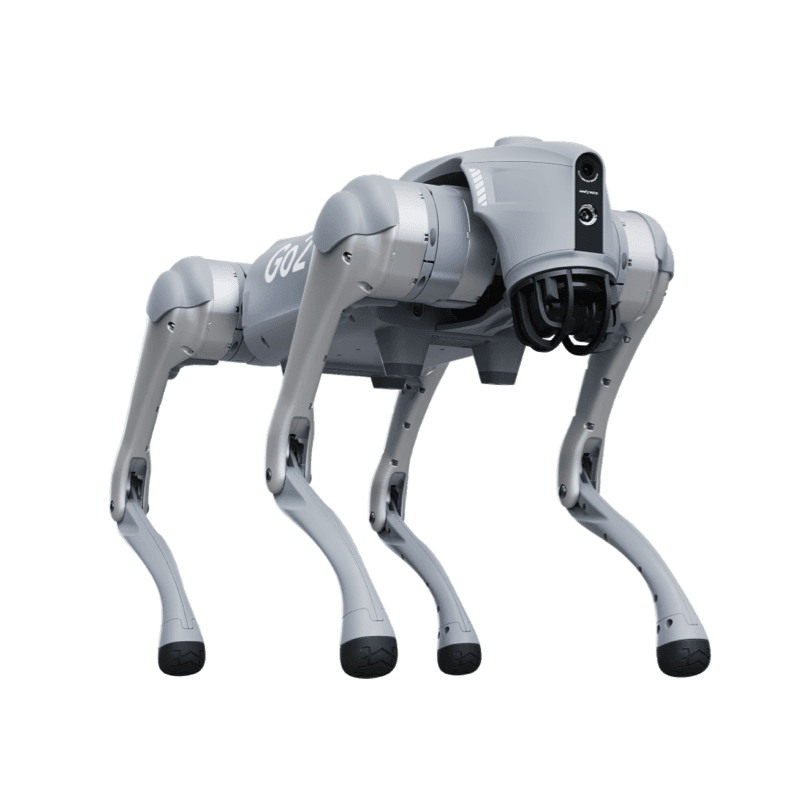
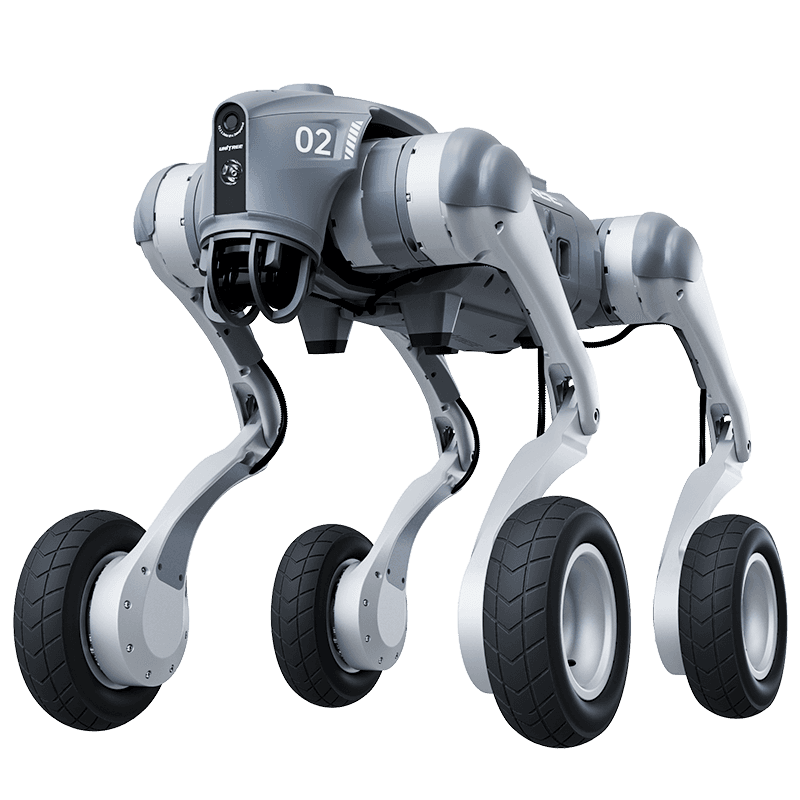
Unitree Go2-W wheeled-legged robot
Pilot deployment

Autonomous patrol and thermal inspection with a quadruped robot at an electricity distribution site

Industry
Electricity distribution and energy infrastructure
Customer
Electricity distribution company, Turkey
Robot
Unitree Go2-W
Review the project
Unitree Go2-W wheeled-legged robot
Proof of concept

Occupational safety inspection from the robot: helmet check and two-state equipment inspection

Industry
Energy and industrial facility operations
Customer
Electricity distribution site, Turkey
Robot
Unitree Go2-W
Review the project
Unitree G1 humanoid robot
Lab demo

Human video to humanoid motion transfer: training and verification in simulation

Industry
R&D, demos and events
Customer
Robotlar.org R&D
Robot
Unitree G1
Review the project

Customer deployments

Customer sites where installation is complete: robot model, quantity and commissioning period are confirmed with the customer.

All references
  • Deployed

    Airport Terminal Deployments: Sabiha Gökçen, Izmir Adnan Menderes

    Aviation / Airport Operations

    Pudu CC1 Pro · 2 havalimanında filo kurulumu

  • Deployed

    IGA Istanbul Airport

    Aviation / Airport Operations

    Pudu CC1

  • Deployed

    Istanbul Atatürk Airport

    Aviation / Airport Operations

    Pudu CC1

  • Deployed

    Turkish Airlines

    Aviation / Airport Operations

    Pudu CC1 Pro

  • Deployed

    Turkish Support Services

    Aviation / Ground Services

    Pudu CC1

  • Deployed

    TAV Airports

    Aviation / Airport Operations

    Pudu CC1, Pudu CC1 Pro

  • Deployed

    Ankara Esenboğa Airport

    Aviation / Airport Operations

    Pudu BellaBot Pro

  • Deployed

    JW Marriott Hotel Ankara

    Hotel / Hospitality

    Pudu CC1 Pro, Pudu MT1 Max, Pudu MT1, Pudu MT1 Vac · 5 robotluk temizlik filosu

  • Deployed

    Gıpta Holding

    Industrial Production & Logistics

    Unitree G1, Unitree Go2-W, Unitree A2 Pro, Pudu CC1, Pudu MT1 Max

  • Deployed

    Teknovinç

    Industrial Production & Logistics

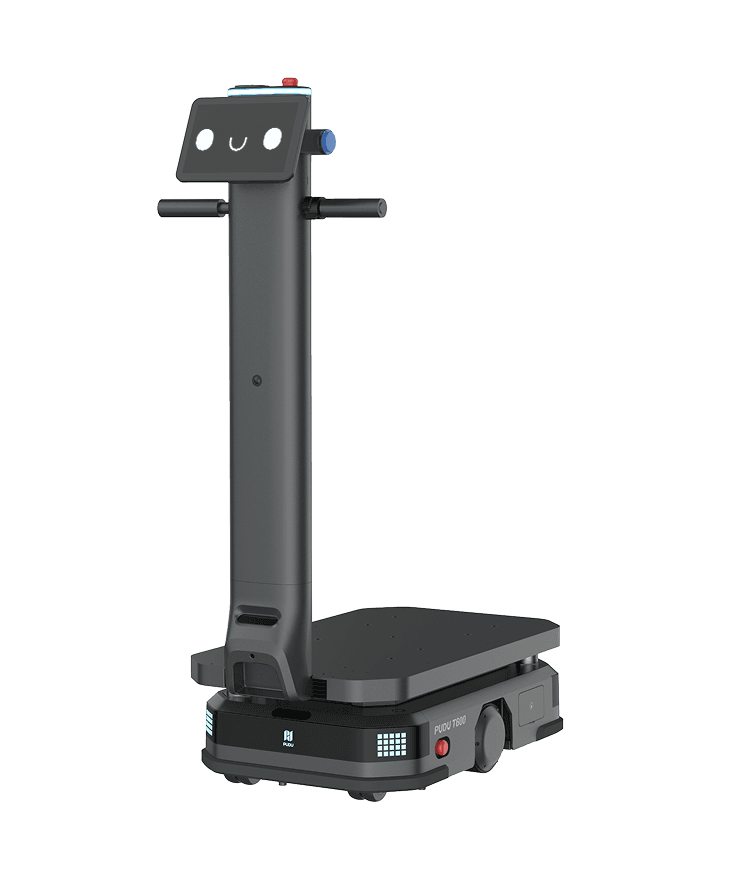
    Pudu T600, Pudu MT1 Max, Unitree Go2 Pro · 26 robotluk karma filo

  • Deployed

    Grand Hyatt Istanbul

    Hotel / Hospitality

    PuduBot 2

  • Deployed

    Bilkent Hotel

    Hotel / Hospitality

    Pudu MT1, Pudu CC1

  • Deployed

    Turkish Ministry of Energy and Natural Resources & TENMAK

    Public Sector / Energy Research

    Unitree Go2, Unitree Go2-W

  • Deployed

    Kuzu Group

    Real Estate & Construction

    Unitree Go2

  • Deployed

    BEDAŞ (Boğaziçi Electricity Distribution)

    Energy / Infrastructure

    Pudu CC1 Pro

  • Deployed

    Tepe Kurumsal

    Facility Management

    Pudu CC1 Pro

  • Deployed

    Tende

    Corporate Facilities

    Pudu CC1 Pro, Pudu T600

  • Deployed

    Panotte

    Service & Retail

    Unitree Go2, Pudu BellaBot, Pudu CC1

Application scenarios

Working drafts describing how catalogue robots could do a given job: environment, mission flow and a proposed hardware and software configuration.

The scenario library defines the environment, the mission flow and a proposed hardware and software configuration. Deployment records and measured data sit under field projects and customer deployments.

238 scenarios · showing 24

Concept scenarioIND-01

Autonomous Oil Leak and Thermal Anomaly Detection in High Voltage Transformers

Early detection of micro oil leaks and dangerous thermal expansions before human patrol.

Environment
Outdoor field
Operation
Supervised autonomy
Robot
Unitree A2
Review the scenario
Concept scenarioIND-02

Solar Panel (GES) Efficiency and Hotspot Analysis

Time loss and production drop caused by manual thermal measurement in massive GES areas.

Environment
Outdoor field
Operation
Supervised autonomy
Robot
Unitree B2-W
Review the scenario
Concept scenarioIND-03

Wind Turbine (RES) Foundation and Anchor Control

Detection of concrete fatigue and bolt loosening that are difficult to see with the naked eye.

Environment
Outdoor field
Operation
Supervised autonomy
Robot
Unitree A2
Review the scenario
Concept scenarioIND-04

Natural Gas Pipeline Corrosion Mapping

The cost of human inspection of kilometer-long lines and the risks of leakage.

Environment
Outdoor field
Operation
Supervised autonomy
Robot
Unitree B2-W
Review the scenario
Concept scenarioIND-05

Conveyor Belt Acoustic Bearing Tracking

Conveyor belts breaking and production line stopping as a result of bearing lock-up.

Environment
Indoor, facility
Operation
Supervised autonomy
Robot
Unitree AS2
Review the scenario
Concept scenarioIND-06

Ultrasonic Air Leak Detection

Invisible pressurized air leaks that cause compressors to run unnecessarily.

Environment
Indoor, facility
Operation
Supervised autonomy
Robot
Unitree AS2
Review the scenario
Concept scenarioIND-07

Data Center Cable and Cabinet Thermal Inspection

Hardware burns and data loss risks caused by local cooling errors.

Environment
Indoor, facility
Operation
Supervised autonomy
Robot
Unitree AS2
Review the scenario
Concept scenarioIND-08

Cold Storage Insulation Test

Hidden insulation damage and product degradation risks that increase cooling costs.

Environment
Indoor, facility
Operation
Supervised autonomy
Robot
Unitree AS2
Review the scenario
Concept scenarioIND-09

Boiler Room Analog Gauge OCR Reading

The necessity of manual reading of non-digitalized equipment in old facilities by humans.

Environment
Indoor, facility
Operation
Supervised autonomy
Robot
Unitree B2
Review the scenario
Concept scenarioIND-10

Railway Track Gap and Switch Measurement

Slowness of traditional pedestrian railway inspection and human measurement errors.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree B2-W
Review the scenario
Concept scenarioIND-11

Underground Mine Gallery Autonomous Mapping and Methane Gas Analysis

Manual controls endangering human life in high-risk underground galleries.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree B2
Review the scenario
Concept scenarioSEC-01

Industrial Facility Face Recognition and Intrusion Verification

Theft cases or unauthorized persons leaking into dangerous areas in large facilities.

Environment
Indoor, facility
Operation
Supervised autonomy
Robot
Unitree AS2
Review the scenario
Concept scenarioSEC-02

Mall and Underground Parking Plate/Security Patrol

Rule violations in the parking lot, car thefts occurring in blind spots, and lack of patrol.

Environment
Indoor, public area
Operation
Supervised autonomy
Robot
Unitree AS2
Review the scenario
Concept scenarioSEC-03

Airport Apron Foreign Object Debris (FOD) Detection

Inadequacy in finding foreign objects that could damage aircraft engines by human eyes.

Environment
Indoor, public area
Operation
Supervised autonomy
Robot
Unitree AS2
Review the scenario
Concept scenarioSEC-04

Critical Infrastructure (Plant/Pipe) Peripheral Fence Sabotage Analysis

Use of static camera blind spots by saboteurs.

Environment
Outdoor field
Operation
Supervised autonomy
Robot
Unitree B2-W
Review the scenario
Concept scenarioSEC-05

Port Container Number Tracking and Stock Verification

Ship loading delays caused by incorrectly stacked containers.

Environment
Outdoor field
Operation
Supervised autonomy
Robot
Unitree B2-W
Review the scenario
Concept scenarioSEC-06

Suspicious Package Detection in Crowds (Metro/Airport)

Risks of bombing actions resulting from static cameras being unable to see every corner in large areas.

Environment
Indoor, public area
Operation
Teleoperation
Robot
Unitree AS2
Review the scenario
Concept scenarioSEC-07

Underground Parking Carbon Monoxide (CO) and Fire Patrol

Poisoning risks due to insufficient ventilation in parking lots and late detection of vehicle fires.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree A2
Review the scenario
Concept scenarioSEC-08

Precious Mineral / Bank Vault Night Watch

Theft/sabotage risks from inside (Insider) or outside in high-security areas.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree B2
Review the scenario
Concept scenarioSEC-09

VIP Protection Advance Reconnaissance and Blind Spot Control

Assassination/attack risks arising from guards being unable to physically check every corner.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree A2
Review the scenario
Concept scenarioRES-01

Thermal Life Tracking Under Earthquake Debris

Detection of human life within critical 72 hours after disaster, protection of rescue personnel from secondary collapse risk.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree B2
Review the scenario
Concept scenarioRES-02

Quarantine Zone Autonomous Medicine Distribution

Vital risks exposed to health personnel in epidemic or high radiation areas.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree B2-W
Review the scenario
Concept scenarioRES-03

Gas Measurement and Initial Reconnaissance After Mine Accident

Rescue teams entering blind mine tunnels experiencing poisoning or secondary explosion risk.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree B2
Review the scenario
Concept scenarioRES-04

Nuclear Leak Mapping and Dosage Marking

Humans having to perform measurements by being exposed to radiation.

Environment
Outdoor field
Operation
Teleoperation
Robot
Unitree B2
Review the scenario

A feasibility study for your own site

The gap between a scenario and an installation is the site survey: floor and route, network coverage, charging point, safety rules and intervention responsibilities. The survey report defines the scope, the constraints and the commissioning steps.

Request a site survey