Conveyor Belt Acoustic Bearing Tracking
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Indoor, facility
- Operating mode
- Supervised autonomy
- Proposed robot
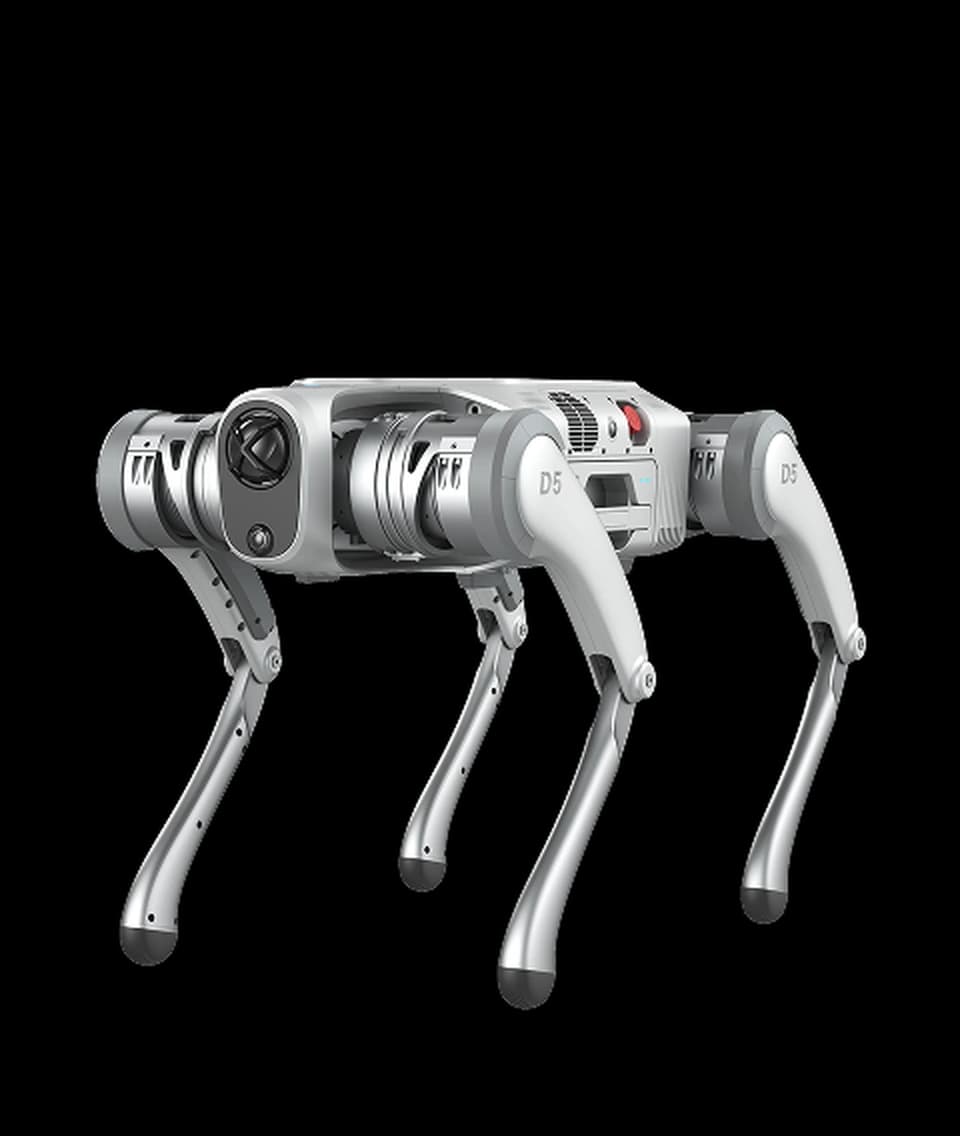
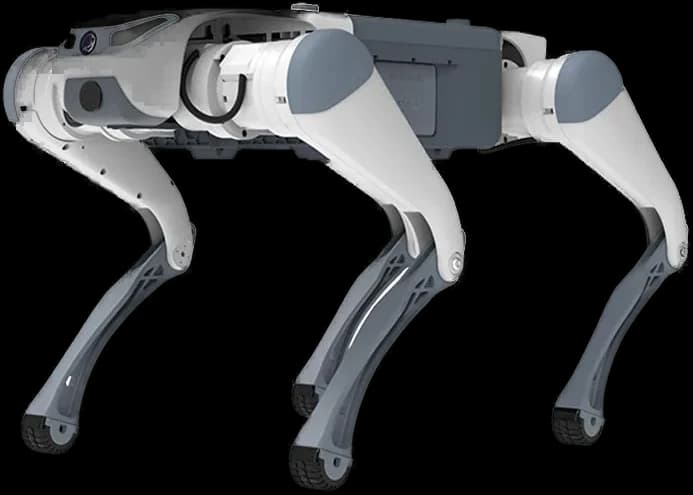
- Unitree AS2
The problem addressed
Conveyor belts breaking and production line stopping as a result of bearing lock-up.
Draft mission flow
- 1Advances at slow speed on a planned route along the production line.
- 2Isolates asymmetric friction sounds coming from conveyor bearings by filtering ambient noise.
- 3When bearing failure frequency is captured, the identity of the related motor unit is reported to the center.
Proposed hardware
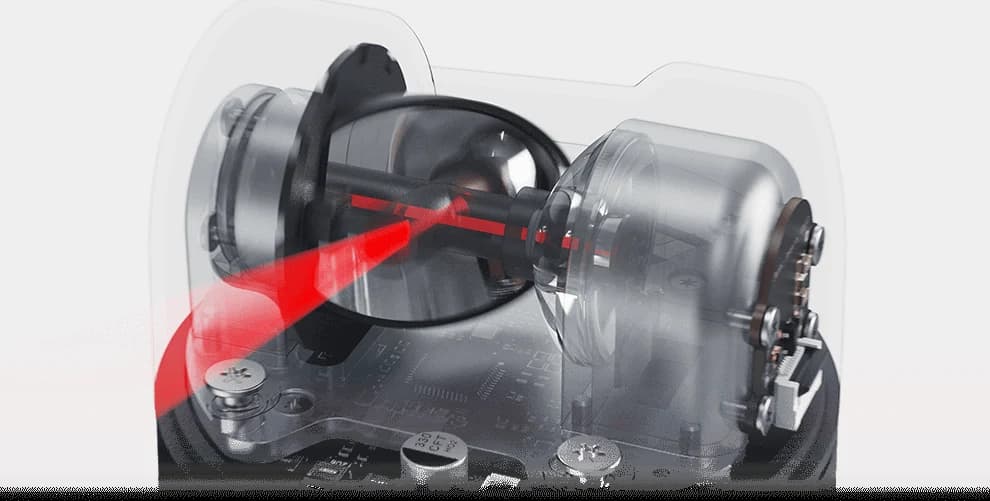
- Omnidirectional Acoustic Sensor (Microphone Array)
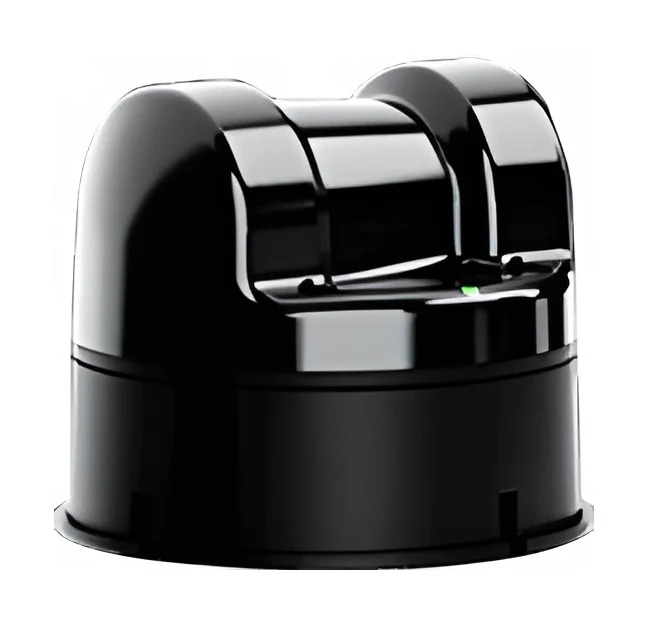
- 360 Degree PTZ Camera
- Edge AI
Proposed software
- Navigation
- In-facility SLAM with dynamic obstacle avoidance
- Model
- Machine Sound Anomaly Detection (Acoustic AI)
- Integration
- Facility SCADA and Predictive Maintenance Software
The robot's real operating limits
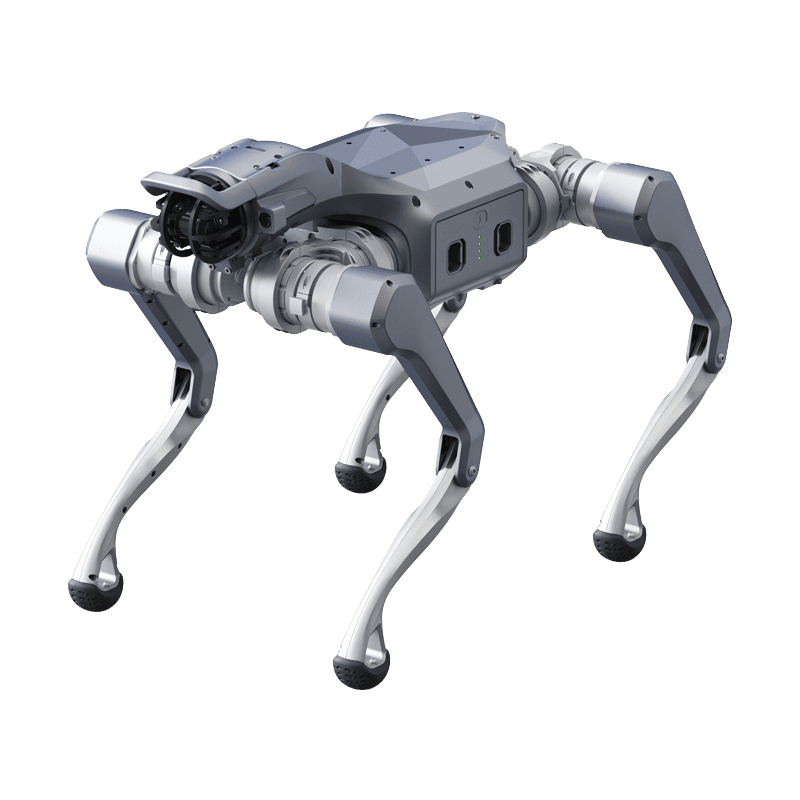
Unitree AS2
Industrial Capacity in a Compact Chassis
Product page- Ingress rating
- IP54
- Runtime
- >4 hours (No load)
- Operating temperature
- -20°C to 50°C
- Payload
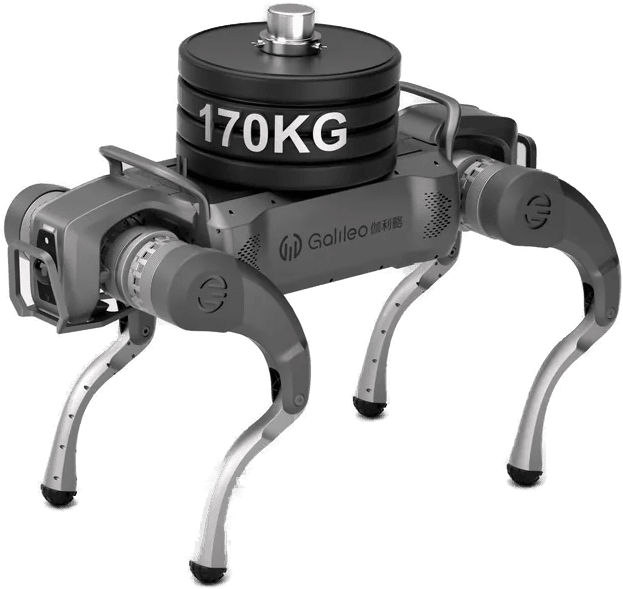
- Up to 65 kg
- Max speed
- >5 m/s
- Climb
- 40°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.