Dexterous Robot Hands
Five-finger dexterous hands for humanoids and robot arms, plus teleoperation data gloves.
2 models · 1 brandsFilter
What Is a Dexterous Robot Hand and How Do You Choose One?
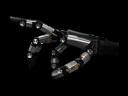
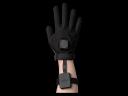
A dexterous robot hand is an end effector with a human-like finger structure that can do more than hold an object: it can turn it between the fingers and change the grasp. It mounts on a humanoid's wrist or on a robot arm's flange, and in research labs it is the physical end of imitation learning, reinforcement learning and vision-language-action model work. This page lists the Wuji Hand 2 (a fully direct-drive hand with 20 active degrees of freedom) and the Wuji Glove data glove that drives it through teleoperation.
Four measures decide the choice. First, degrees of freedom: an active joint turns with its own motor, a passive joint follows another joint; more active joints mean better adaptation to new grasps. Second, drive type: in a direct-drive design the motor sits inside the joint and the joint is back-drivable, so contact stays soft; in a tendon design the motors sit in the palm or forearm and cables pull the joints; in a linkage design one motor moves several joints together. Third, weight and interface: the humanoid wrist and the arm's payload limit set the hand's mass, and the controller sets the communication line (Ethernet, CAN, USB). Fourth, software: the SDK language, a ROS 2 package and URDF, MJCF or USD models shorten the path from simulation to the real hand.
Unitree hand modules have their own pages: the Unitree Dex5-S with 22 active degrees of freedom, the Unitree Dex5-1 with its 94-point tactile version, and the Unitree hand modules including the Dex3-1 and Dex1-1. Robotlar.org is the official distributor of Unitree Robotics in Turkey. For Wuji products, Robotlar.org provides enterprise sourcing, technical specification support and integration engineering; supply into Turkey is planned per project, and the scope of import, delivery and commissioning is itemised in the quotation. Pricing and sourcing are explained on the Wuji Hand 2 price and sourcing page.
Wuji Hand 2 and Unitree Dex5-1: published values
| Measure | Wuji Hand 2 | Unitree Dex5-1 |
|---|---|---|
| Degrees of freedom | 20, all active (4 per finger) | 20 (16 active, 4 passive) |
| Drive | Fully direct drive, every axis back-drivable | Every joint back-drivable |
| Weight | About 800 g (with soft layer and cable), bare hand 650 g | 1,100 g |
| Fingertip force | 12 N or more (provisional) | 10 N |
| Tactile sensing | None in the shipping 2.2 (Beta) build | 94 points (Dex5-1P version) |
| Communication and control | Ethernet 100BASE-TX, 1000 Hz on 20 axes | 1000 Hz communication |
| Supply | 11-13 V DC | 24-60 V |
Sources: Wuji Hand 2.2 (Beta) documentation (docs.wuji.tech) and the Unitree Dex5-1 product page, 13 November 2026. Wuji states that the Hand 2 documentation describes a Beta build that is not final; wrist load, ingress protection and lifetime values are not in this table for either hand.
Dexterous Robot Hands
things people ask.
For questions you can't find answers to, contact us directly. Our engineering team responds specifically to your project.
Inquire NowRequest a quote.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
- Supply and delivery scheduling backed directly by the manufacturer
- Site- and mission-focused technical feasibility and simulation
- Turnkey hardware, software and mission integration
- Advisory on corporate tenders, specifications and administrative processes
or call: 0850 532 6 777