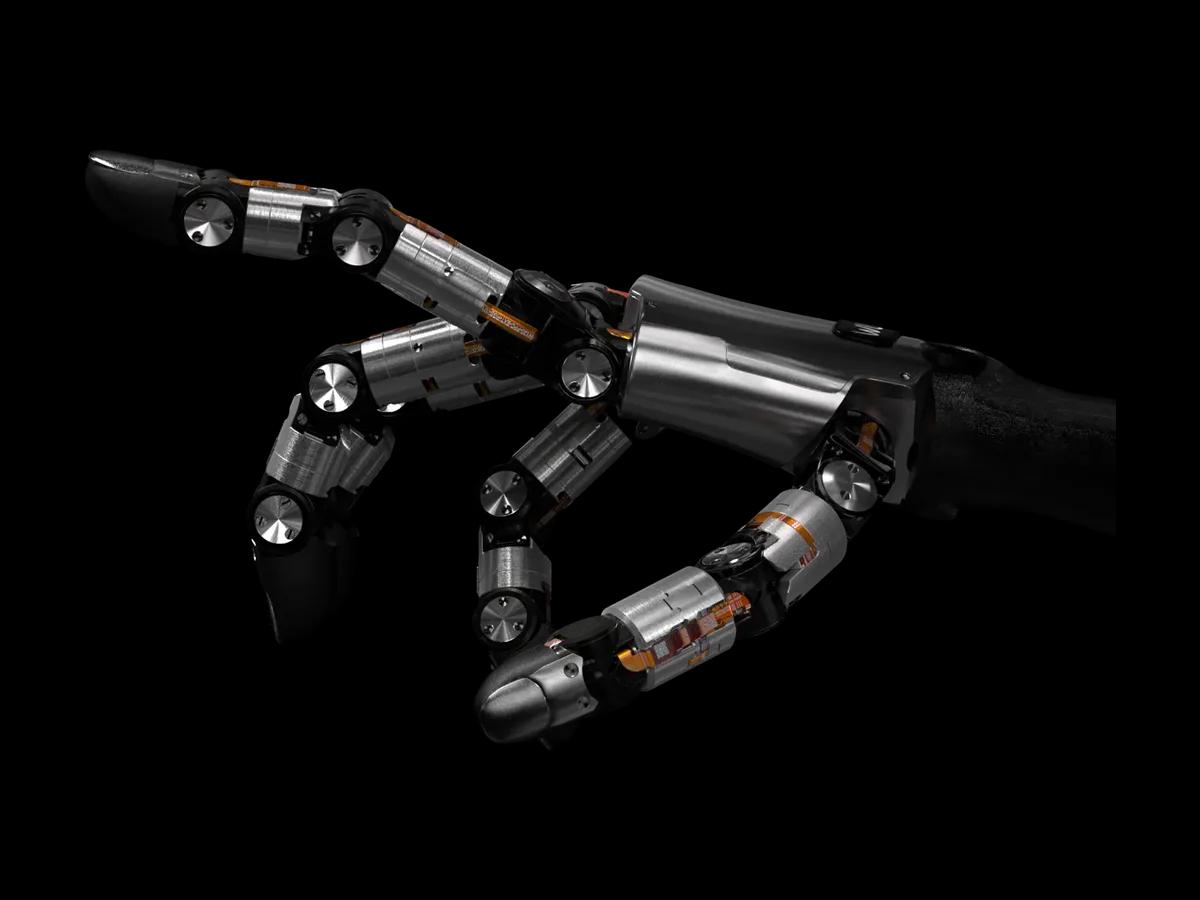
The Wuji Glove is Wuji Technology's teleoperation and data collection glove.
Read moreShow less
A 526-point tactile matrix covering the palm side measures contact force at 120 FPS; 5 electromagnetic pose modules track the fingertips at 120 Hz, and a 6-axis IMU on the back of the hand reports at 800 Hz. Weighing 67.5 g, the glove drives the Wuji Hand 2 in real time, and the recorded motion and contact data is used to train imitation learning and vision-language-action models.
Enterprise supply · specification support · integration engineering
1/3
Overview
The Wuji Glove is the data and teleoperation glove introduced in February 2026 by Wuji Technology, a robot hand maker based in Shenzhen. It targets one of the hardest parts of robot hand research, collecting high-quality human demonstrations: the 526-point tactile matrix in the palm measures contact force, five electromagnetic modules track the fingertips and an IMU on the back of the hand measures the hand's motion. This data is used to drive the Wuji Hand 2 in real time and to train imitation learning and vision-language-action models.
Robotlar.org offers the Wuji Glove to research labs and data collection teams in Turkey through enterprise sourcing, technical specification support and integration engineering.
The Wuji Glove in motion
5 videos: manufacturer footage and field recordings. Tap a cover to play.
Wuji Glove product video
The videos are from the manufacturer's official YouTube channel. The teleoperation demo was filmed together with a Wuji Hand; the research dataset is the work of a third-party team.
Wuji Glove and Wuji Hand teleoperation
Calibration tutorial
Unboxing and setup
EgoExplorer: real-world data collection with the glove
Key Advantages
526 Tactile Points Across the Palm
The palm side of the glove is covered by a 24 x 31 pressure matrix, and 526 effective points measure contact force.
(1) Measurement runs at 120 FPS over a 0-20 N range with 0.1 N resolution; spatial resolution is 4 mm.
(2) According to the manufacturer the matrix withstands at least 100,000 press and bend cycles.
(3) The recorded contact map carries the human contact in the demonstration into the dataset, even when the robot hand itself has no tactile sensing.
Electromagnetic Pose Tracking
Five electromagnetic modules, each with 6 degrees of freedom, track the position and orientation of the fingertips.
(1) The update rate is 120 Hz; position accuracy is 2 mm RMS or better, orientation below 5° RMS.
(2) Unlike camera-based hand tracking it needs no line of sight; measurement continues when a finger is behind an object.
(3) A 6-axis IMU on the back of the hand reports at 800 Hz over ±16 g and ±2000°/s.
Drives the Wuji Hand 2 in Real Time
wuji-retargeting builds the link between the glove and the robot hand.
(1) The operator's finger motion is transferred to the 20 joints of the Hand 2 in real time.
(2) The Hand 2 documentation includes a quick-start chain that runs both products together, and the manufacturer's official channel published a short video of glove-to-hand teleoperation.
(3) The same retargeting library also supports Vision Pro, video, RealSense and ZED inputs.
Data Collection and Calibration
The Wuji SDK and CLI record the glove's tactile, pose and IMU streams and process them offline.
(1) Hand-model calibration and tactile calibration are done with the CLI; the manufacturer published an official tutorial video for it.
(2) With the ROS 2 packages the data is placed on the same timeline as the camera and joint data on the robot side.
(3) The manufacturer's channel shows the EgoExplorer work, in which a research team collected real-world multimodal data with the glove.
The Wuji Glove up close
2 images; tap to enlarge.
Which robot for which job?
The Wuji Glove is a candidate for all of these jobs; in each scenario our catalogue also holds other bodies that can do the same work. The right robot follows from the job itself and the delivery timeline.
Demonstration data for imitation learning
The operator wears the glove and drives the robot hand; the glove's contact and pose data is recorded together with the robot's camera and joint data. These demonstrations go into the training set of imitation learning and vision-language-action models.
The glove is also used without a robot: finger pose and palm contact are measured together during grasping. It supplies data for human-robot interaction, hand biomechanics and motion input in virtual or augmented reality.
Technical Specifications
14 values in 7 categories; data published by the manufacturer.
Size and weight
Weight
0.0675 kg (67.5 g; 192.6 g with cable)
Motion and performance
Positioning accuracy
Electromagnetic pose: position 2 mm RMS or better, orientation below 5° RMS
Power and runtime
Operating voltage
USB-C 5 V / 1 A at the glove
General structure
Manufacturer note
Press and bend life of the tactile matrix is at least 100,000 cycles (manufacturer). Values from the Wuji Glove 1.0 documentation, 13 November 2026.
Body dimensions
215 x 195 mm; thickness 6.55 mm at the fabric, 35 mm with modules; total cable length 340 mm
In the box
Glove, USB-C to USB-C cable, USB-C to Ethernet and power adapter, USB-A to USB-C cable and network cable
Availability
Wuji Glove 1.0 was introduced in February 2026
Size and weight
Weight
0.0675 kg (67.5 g; 192.6 g with cable)
Motion and performance
Positioning accuracy
Electromagnetic pose: position 2 mm RMS or better, orientation below 5° RMS
Power and runtime
Operating voltage
USB-C 5 V / 1 A at the glove
Sensors and connectivity
Sensors
526-point tactile matrix (120 FPS); 5 electromagnetic pose modules with 6 degrees of freedom each (120 Hz); 6-axis IMU on the back of the hand (800 Hz, ±16 g, ±2000°/s)
Interfaces
Wuji SDK and CLI: tactile, pose and IMU streams, data recording, offline processing, hand-model and tactile calibration; ROS 2 packages
Connectivity
Data over RJ45 Ethernet (100BASE-TX) through an adapter; power over USB-C
Tactile sensing
24 x 31 pressure matrix, 526 effective points, full palm-side coverage; 120 FPS; 0-20 N range, 0.1 N resolution, 4 mm spatial resolution; repeatability ±6%
Software and development
Software features
Real-time teleoperation of the Wuji Hand 2 through retargeting (wuji-retargeting); a two-product quick-start chain in the Hand 2 documentation
Environmental resilience
Operating temperature
-5 to 40 °C, relative humidity below 55%
Storage temperature
-10 to 70 °C, relative humidity below 80%
Sources and documents
Verified on the manufacturer page on 13 November 2026.
Lead time is stated in the quotation per project, after confirmation from the manufacturer. Warranty scope and duration are stated in writing in the quotation according to the sourcing channel; the manufacturer's public after-sales terms apply within Mainland China.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
Supply and delivery scheduling backed directly by the manufacturer
Site- and mission-focused technical feasibility and simulation
Turnkey hardware, software and mission integration
Advisory on corporate tenders, specifications and administrative processes
The Wuji Glove is a data glove that measures the operator's hand and finger motion and the contact in the palm. It has two main uses: driving the Wuji Hand 2 through real-time teleoperation and collecting demonstration data for imitation learning and vision-language-action models. It is also used without a robot in human hand motion research.
Which sensors does it have?
A 24 x 31 pressure matrix on the palm side (526 effective points, 120 FPS, 0-20 N), 5 electromagnetic pose modules at the fingertips with 6 degrees of freedom each (120 Hz) and a 6-axis IMU on the back of the hand (800 Hz).
Can it be used without the Wuji Hand 2?
Yes. The glove records data on its own through the SDK and CLI. Retargeting to other robot hands is also possible with the wuji-retargeting library, but the manufacturer's ready teleoperation chain is documented for the Wuji Hand 2. On another hand, joint mapping is done within the project.
How does it connect to a computer?
The glove is powered with 5 V / 1 A over USB-C; data is transferred over RJ45 Ethernet (100BASE-TX) through the adapter in the box. The Wuji SDK runs on Windows, Linux and macOS, and ROS 2 packages are available.
Is calibration needed?
Yes. Hand-model calibration and tactile calibration are done with the Wuji CLI; the manufacturer published an official tutorial video for these steps. Calibration is repeated for operators with different hand sizes.
What are the operating conditions?
According to the manufacturer the operating temperature is -5 to 40 °C at relative humidity below 55%; storage is -10 to 70 °C at relative humidity below 80%. The tactile matrix is designed to withstand at least 100,000 press and bend cycles.
How much does it cost and how is it sourced in Turkey?
Robotlar.org does not publish prices. Glove quantity, whether it is sourced together with the Wuji Hand 2 and the integration scope are set in a corporate quotation. For Wuji products Robotlar.org provides enterprise sourcing, technical specification support and integration engineering; supply into Turkey is planned per project, and the scope of import, delivery and commissioning is itemised in the quotation.
How are lead time and warranty set?
Lead time is stated in the quotation per project, after confirmation from the manufacturer. Warranty scope and duration are stated in writing in the quotation according to the sourcing channel; the manufacturer's public after-sales terms apply within Mainland China.