How Much Does the Wuji Hand 2 Cost?
The manufacturer has no published price list for the Wuji Hand 2, and Robotlar.org does not state a price on this page. The quotation is built from these items: hand quantity (a single hand or a left and right pair), build and firmware version, the spare finger and skin plan, the need for a Wuji Glove, the wrist adapter and integration scope, and import and delivery terms. Because the manufacturer's documentation states that it gives no durability or lifetime guarantee at the 2.2 (Beta) stage, we recommend pricing the spare-parts plan together with the hand. For a quotation, use the quote form.
How Is the Wuji Hand 2 Sourced in Turkey?
Robotlar.org assesses Wuji products for research labs, humanoid and robot arm integrators and data collection teams in Turkey through enterprise sourcing. Supply into Turkey is planned per project; the scope of import, delivery and commissioning is itemised in the quotation. The lead time is stated in the quotation after confirmation from the manufacturer. Warranty scope and duration are stated in writing in the quotation according to the sourcing channel; the manufacturer's public after-sales terms apply within Mainland China. For full technical details see the Wuji Hand 2 product page.
Technical Data
| Measure | Value |
|---|---|
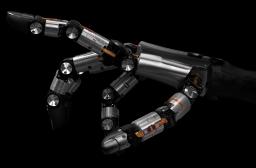
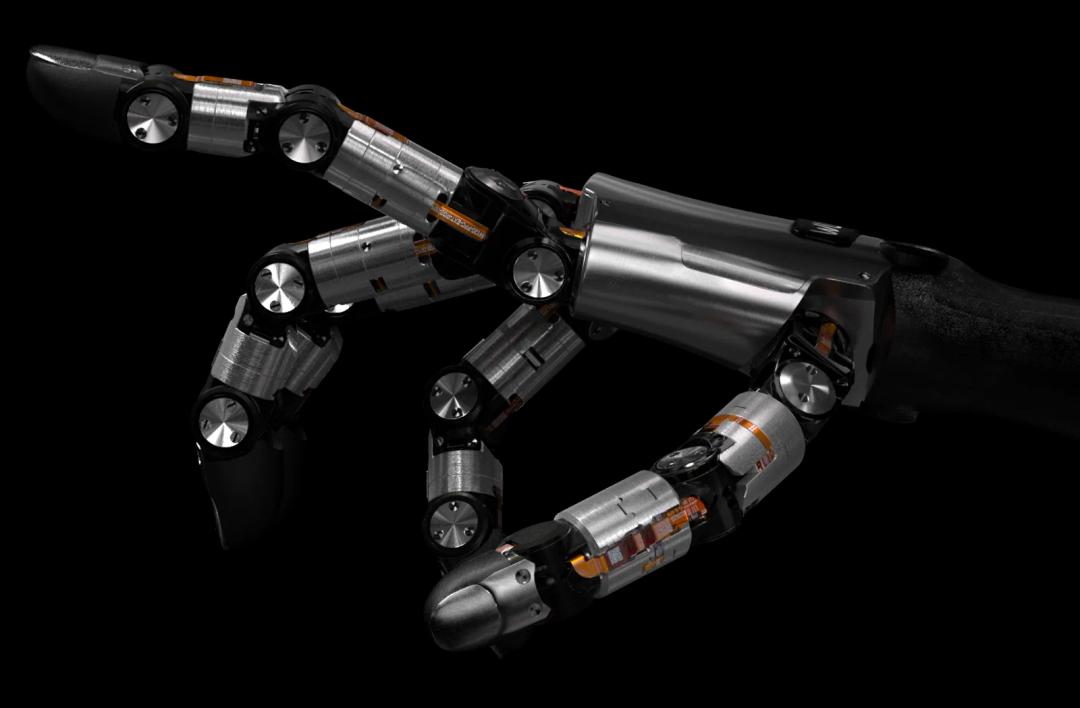
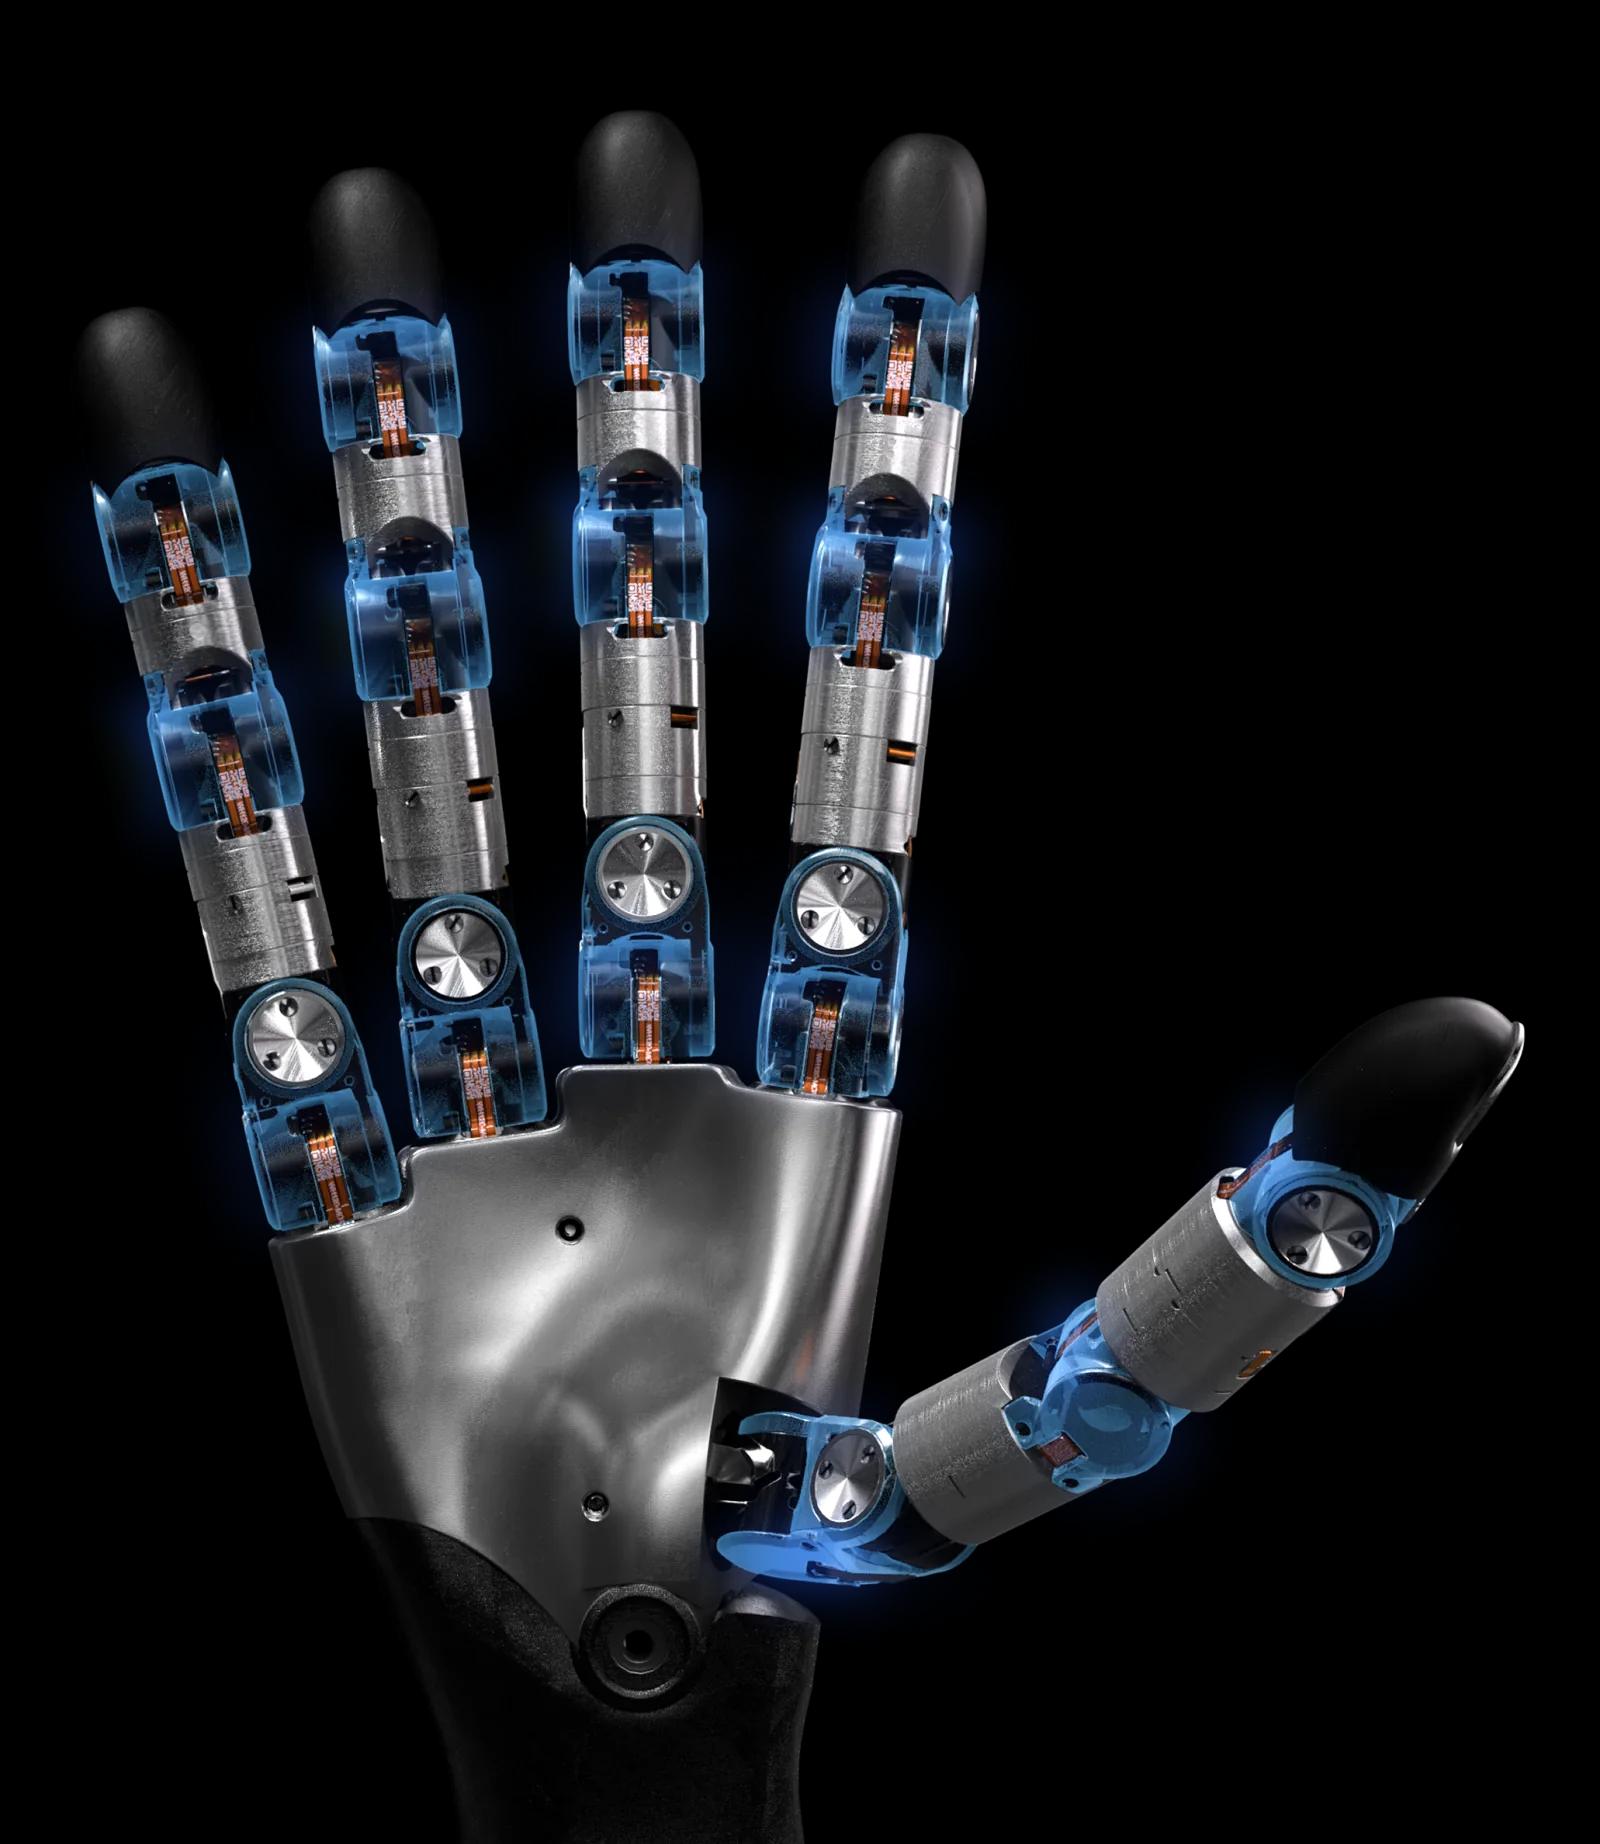
| Degrees of freedom | 20 active, 4 per finger; every joint driven independently |
| Drive | Fully direct drive, FOC control; no tendons or gears, every axis back-drivable |
| Weight | About 800 g (with soft layer and cable), bare hand 650 g |
| Size | About 180 x 80 x 40 mm (open hand, fingers together) |
| Control | 1000 Hz on 20 axes; MIT force-position hybrid mode, position mode (Beta) |
| Communication | RJ45 Ethernet, 100BASE-TX, static IP |
| Supply | 11-13 V DC (12 V nominal), XT30 |
| Fingertip force | 12 N or more (provisional, for the earlier Beta) |
| Joint backlash | Below 1° (provisional, for the earlier Beta) |
| Tactile sensing | None in the shipping 2.2 (Beta) build |
| Software | Python and C SDK, Wuji CLI, ROS 2; URDF, MJCF, USD; MuJoCo and Isaac Sim |
Payload, wrist load and moment, ingress protection, lifetime and repeatability are not published by the manufacturer. The manufacturer reports that the external interface and the voltage range will change in later 2.2 builds.
Single Hand, Pair or With the Glove?
- Single hand (left or right): grasping, in-hand reorientation and reinforcement learning research on one arm.
- Left and right pair: a dual-arm platform, a humanoid body or two-handed tasks. Both hands run on the same network with different default IP addresses and share the same mount interface.
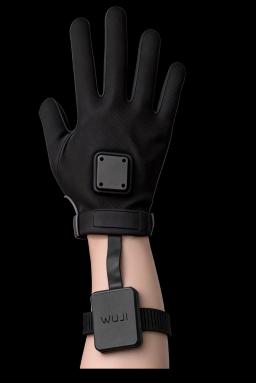
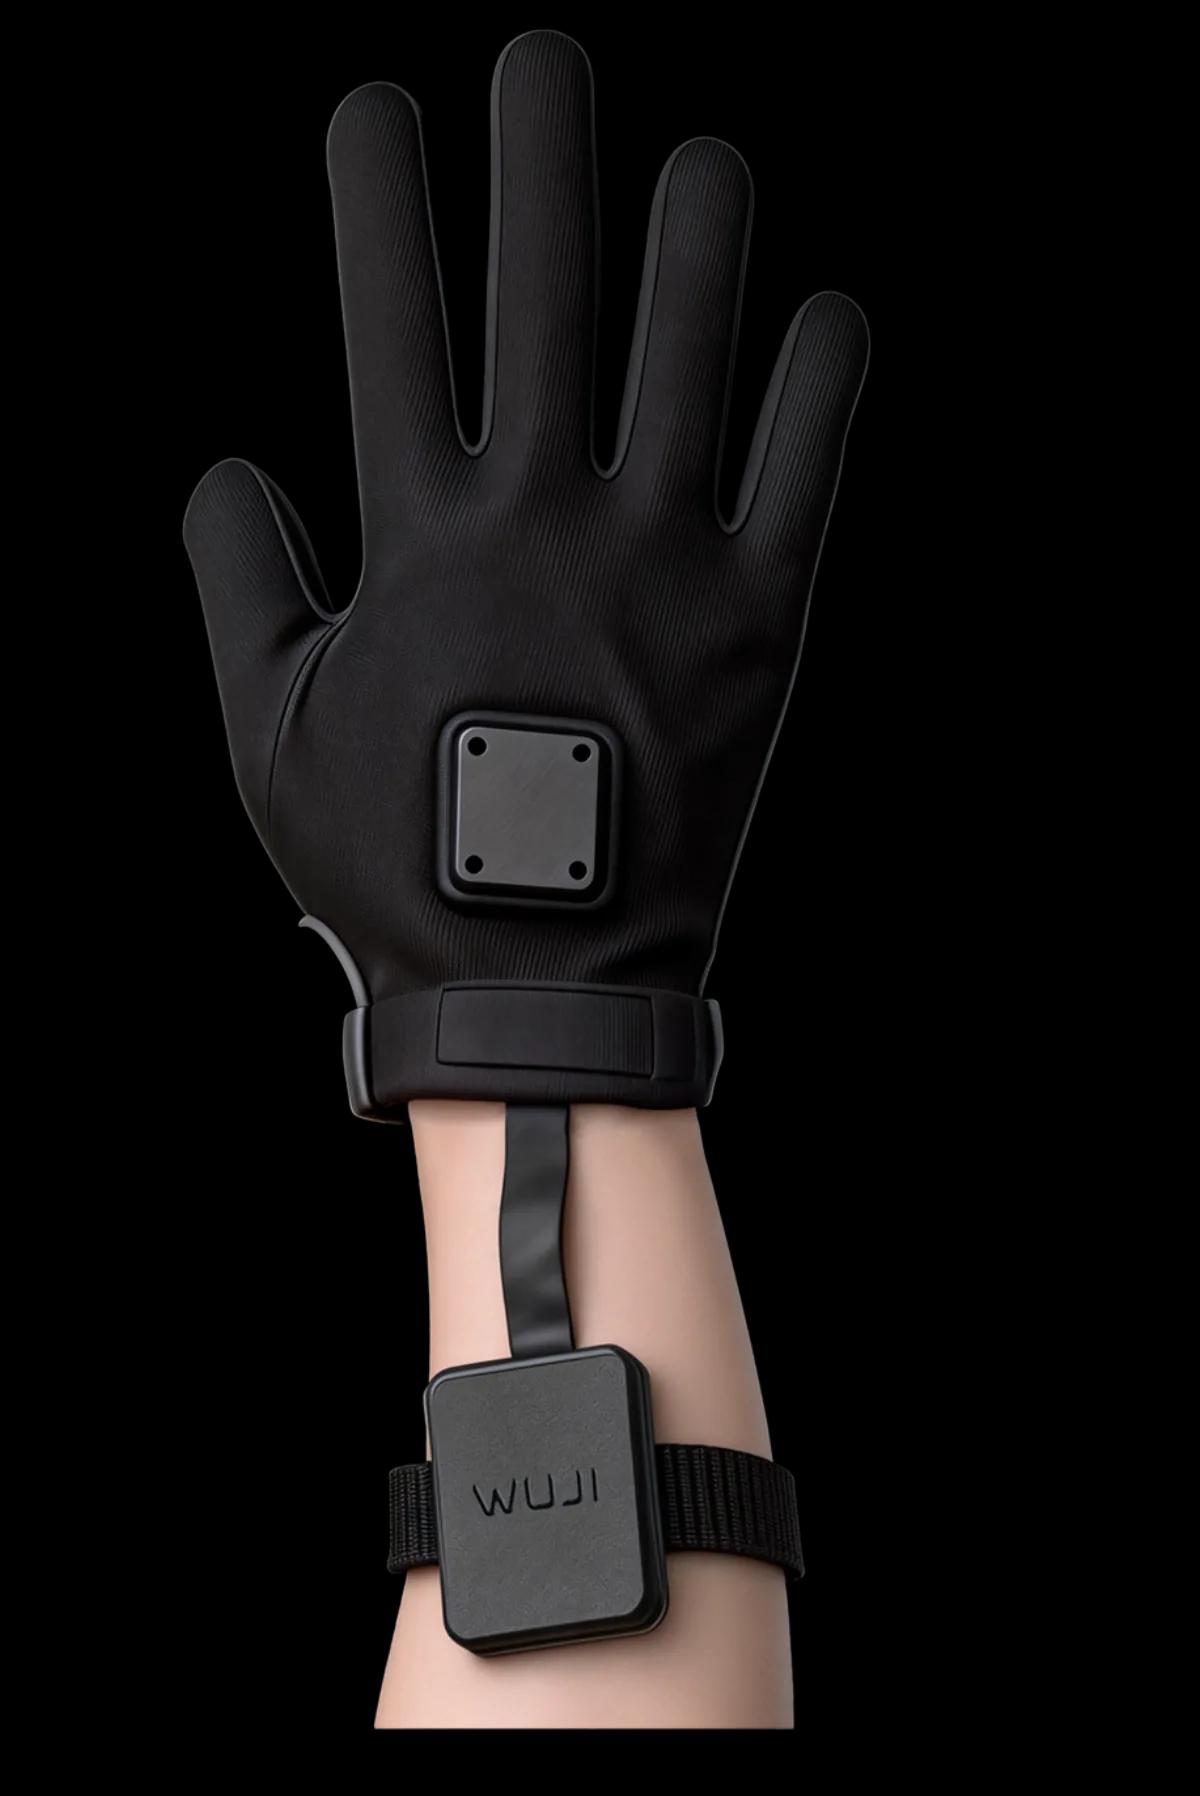
- Hand and Wuji Glove: demonstration data collection through teleoperation. The Wuji Glove records the operator's motion and contact with a 526-point tactile matrix, 5 electromagnetic pose modules and an 800 Hz IMU.
Open Software and Developer Resources
Wuji publishes its software in the github.com/wuji-technology organisation: wuji-sdk (Python and C SDK), wuji-description (URDF, MJCF, USD and the palm-mount STEP drawing), wuji-retargeting (motion from a glove, Vision Pro or video), wuji-mjlab (reinforcement learning and sim-to-real) and, for the previous generation, wujihandpy. Licences are MIT and Apache-2.0. Setup, control and integration documentation is at docs.wuji.tech.
Alternatives and Comparison
The choice of a dexterous hand comes down to degrees of freedom, drive type, weight, interface and the need for tactile sensing. The comparison table and selection guide are on the Dexterous Robot Hands page. If a five-finger hand with tactile sensing is needed, consider the Unitree Dex5-1 (94 tactile points in the Dex5-1P version); for more active joints, the Unitree Dex5-S with 22 active degrees of freedom is another option. Robotlar.org is the official distributor of Unitree Robotics in Turkey; to assess hand and body together, see the Unitree G1 page.