Dual-arm coordination
Two RM65-B-V arms carrying 5 kg each run synchronized bimanual tasks; the RM75-B-V arm is offered as an option.
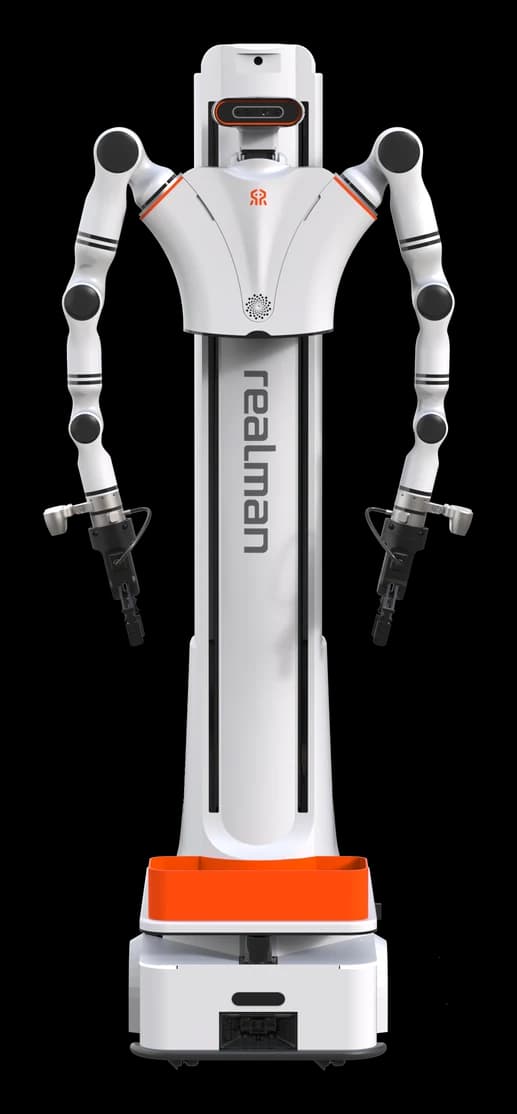
Dual-Arm Vertical Lift Mobile Manipulator
The RealMan Dual-Arm Lift is a dual-arm mobile manipulator that carries two 6-axis RM65-B-V arms on a 900 mm lift column and reaches 0-2400 mm vertically when fully extended.
The 640 × 450 × 1780 mm body weighs approximately 157 kg; it works with 5 kg per arm, 790 mm lateral reach beyond the base and 0-690 mm forward reach, a 450 mm in-place turning radius and 1.5 m/s travel speed. Integrated vision sensors and a CTAG2F90D gripper provide autonomous object recognition and grasping; wired teleoperation supports dual-arm data collection and AI model training, and with 3-4 hours of runtime and 220 V AC charging it is designed for AI training, industrial, commercial and home service, research and education.
Enterprise supply · specification support · integration engineering
The Dual-Arm Lift is RealMan Robotics' dual-arm vertical lift mobile manipulator. Two 6-axis RM65-B-V arms attach to a lift column with 900 mm of effective travel; when the column is fully extended the arms work across a vertical range from 0 to 2400 mm, lateral reach is 790 mm beyond the base on one side and forward reach 0-690 mm. The body measures 640 × 450 × 1780 mm and weighs approximately 157 kg; payload per arm is 5 kg and the RM75-B-V arm is offered as an option.
The RM65 series arms are built to a 610 mm working radius, 7.2 kg net weight and ±0.05 mm repeatability. The integrated vision sensor feeds object recognition, grasping and environment monitoring; compute runs on an NVIDIA Jetson AGX Orin and the CTAG2F90D gripper performs autonomous object recognition and precision grasping. Synchronized coordination of the two arms makes it possible to grasp wide objects from both sides and to hold with one hand while working with the other. Wired teleoperation allows real-time control, recording of dual-arm task data and AI model training; RealMan runs dual-arm lift platforms for the same purpose at the Beijing humanoid robot data training center it established in 2025. The base with autonomous navigation travels at 1.5 m/s and turns with a 450 mm in-place turning radius; continuous runtime is 3-4 hours, charging uses a 220 V AC ±10% 50 Hz supply and the operating temperature range is 5 to 40 °C. On a retail floor it performs shelf scanning and inventory monitoring while navigating the aisles autonomously. RealMan was founded in Beijing in 2018, added lifting robots and dual-arm robots to its range in 2021 and has served more than 8,000 enterprise customers. The Dual-Arm Lift is designed for AI training and data collection, industrial applications, commercial and home service, research and education; it is supplied to Turkey with enterprise supply, commissioning and engineering support.
3 use casesTap the cover to play; sound and loading start only on click.
The use cases the manufacturer defines for the RealMan Dual-Arm Lift.
Two RM65-B-V arms carrying 5 kg each run synchronized bimanual tasks; the RM75-B-V arm is offered as an option.
The 900 mm effective lift travel gives 0-2400 mm vertical reach when fully extended; lateral reach 790 mm beyond the base, forward reach 0-690 mm.
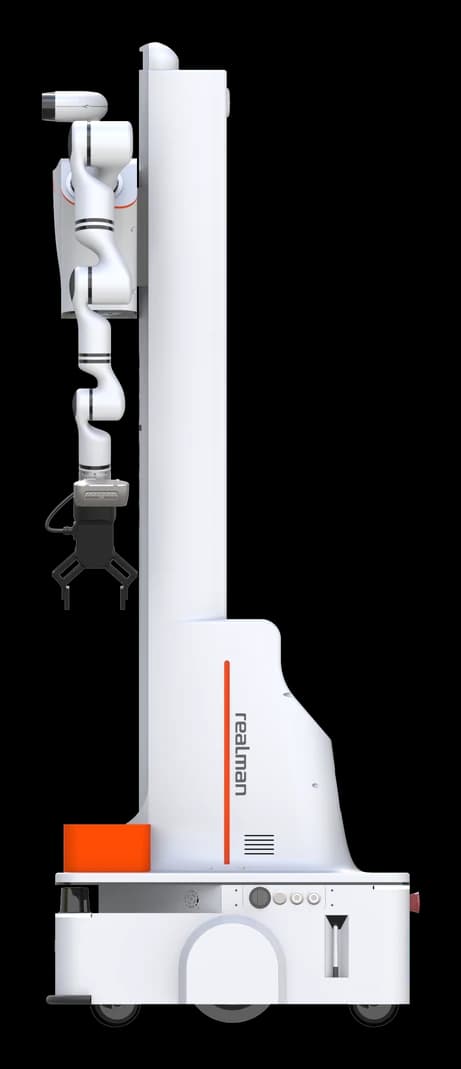
Autonomous object recognition and precision grasping with the integrated vision sensor and the CTAG2F90D gripper; NVIDIA Jetson AGX Orin.
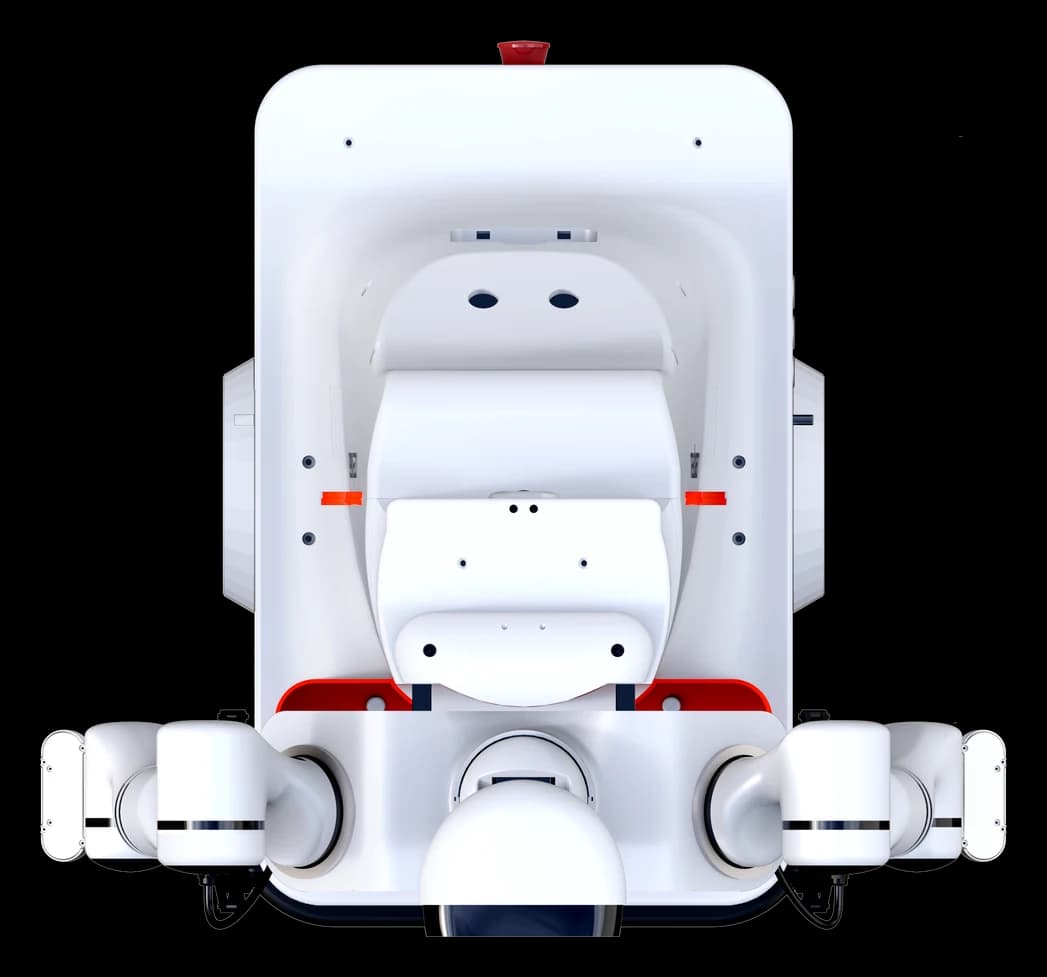
Real-time control, dual-arm data collection and AI model training workflows; 1.5 m/s speed, 450 mm in-place turn, 3-4 hours of continuous operation.
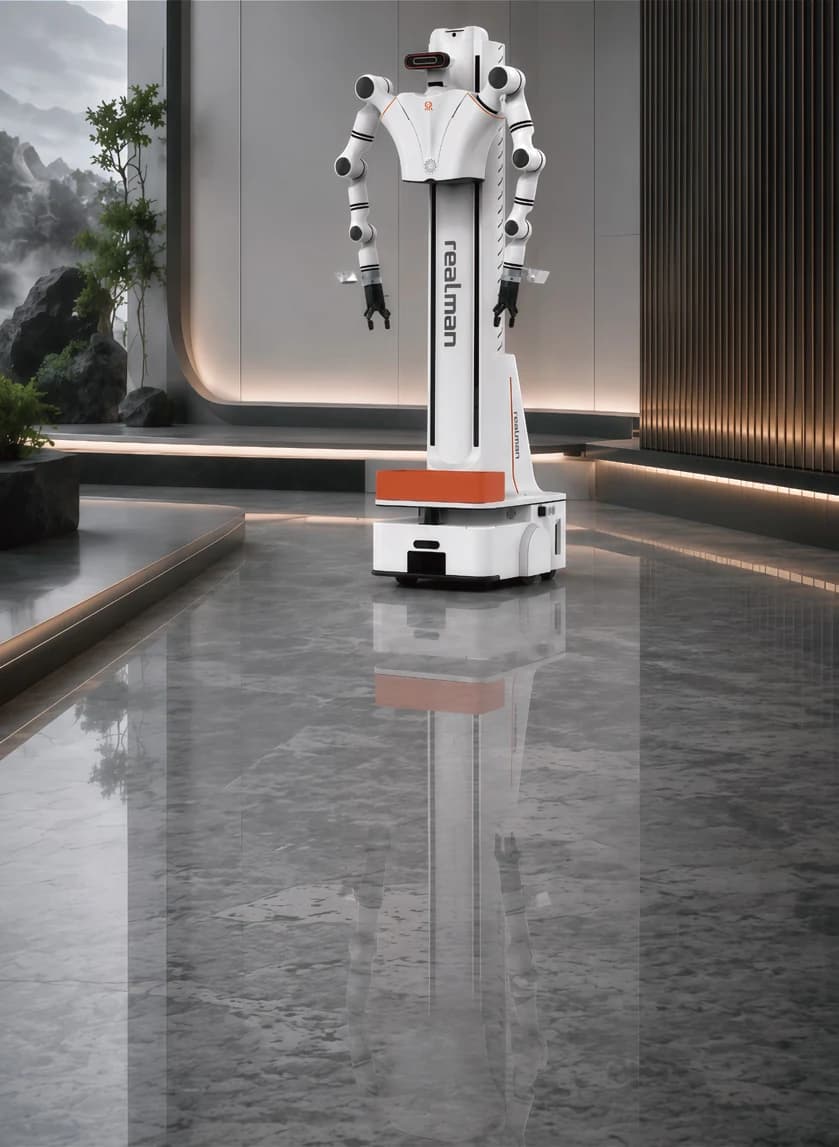
4 images; tap to enlarge.
24 values in 7 categories; data published by the manufacturer.
Verified on the manufacturer page on 18 September 2026.
An itemised quote for the RealMan Dual-Arm Lift is prepared by configuration, quantity and delivery scope.
The Dual-Arm Lift attaches two 6-axis RM65-B-V arms to a lift column with 900 mm of effective travel; when the column is fully extended the arms work across a vertical range from 0 to 2400 mm. Lateral reach is 790 mm beyond the base on one side and forward reach 0-690 mm. Synchronized coordination of the two arms opens up work a single arm cannot do: grasping a wide box from both sides, holding with one hand while working with the other, opening a lid and taking from inside. The body measures 640 × 450 × 1780 mm and weighs approximately 157 kg; the RM75-B-V arm is offered as an option.
The integrated vision sensor feeds object recognition, grasping and environment monitoring; compute runs on an NVIDIA Jetson AGX Orin. At the end-effector the CTAG2F90D gripper performs autonomous object recognition and precision grasping. The RM65 series arms are built to a 610 mm working radius, 7.2 kg net weight and ±0.05 mm repeatability; payload per arm is 5 kg.
Wired teleoperation allows real-time control of the robot, recording of dual-arm task data and training of AI models on that data. RealMan positions the platform as part of its own data infrastructure: at the Beijing humanoid robot data training center it established in 2025, 108 robots including dual-arm lifting humanoids run tasks, and the company supplies real-robot data for training open-source embodied-AI models. A Dual-Arm Lift installed in Turkey can produce an organisation's own task-specific dataset with the same workflow.
The base with autonomous navigation travels at 1.5 m/s and turns with a 450 mm in-place turning radius; continuous runtime is 3-4 hours, charging uses a 220 V AC ±10% 50 Hz supply and the operating temperature range is 5 to 40 °C. On a retail floor the robot performs shelf scanning and inventory monitoring while navigating the aisles autonomously; the video on this page shows that application in a store deployment.
The Dual-Arm Lift is sourced for Turkey on a project basis; arm choice (RM65-B-V or RM75-B-V), gripper and teleoperation configuration, quantity and delivery terms set the corporate quotation. Import, customs clearance, commissioning and engineering support are part of delivery. Request a quotation with your task definition and data collection goal.
| Parameter | Value |
|---|---|
| Robot type | Vertical lift dual-arm mobile robot |
| Overall dimensions | 640 × 450 × 1780 mm |
| Weight | Approx. 157 kg |
| Arm model | 2 × RM65-B-V (6 axes); RM75-B-V optional |
| Payload per arm | 5 kg |
| Effective lift travel | 900 mm |
| Vertical reach | 0-2400 mm (fully extended) |
| Lateral reach | 790 mm beyond base (single side) |
| Forward reach | 0-690 mm |
| Travel speed | 1.5 m/s |
| Turning radius | 450 mm (in-place) |
| Vision sensors | Integrated vision sensor |
| Compute | NVIDIA Jetson AGX Orin |
| End-effector | CTAG2F90D (optional) |
| Teleoperation | Wired; real-time control, dual-arm data collection, model training |
| Battery runtime | 3-4 hours |
| Charging power supply | AC 220 V ±10%, 50 Hz |
| Operating environment | 5-40 °C |
The Dual-Arm Lift is RealMan's mobile platform that combines two RM65-B-V arms with a 900 mm lift column and an autonomous base to offer bimanual manipulation across a 0-2400 mm vertical range. Vision from three depth and two wide-angle cameras, the CTAG2F90D gripper and wired teleoperation suit it both to autonomous retail and manufacturing tasks and to embodied-AI data collection workflows; 1.5 m/s speed and 3-4 hours of runtime call for a charging window in the shift plan. Organisations evaluating it for wide objects and two-step tasks beyond a single arm should state arm preference and target tasks in the quotation request.
Supply model
Supply to Turkey is planned per project; import, delivery and commissioning scope are itemised in the quote.
Pre-sales assessment
Site and mission focused technical feasibility; specification and administrative process support.
Demo and site visit request
Send a demo request; availability and scope are settled in the call.
Source documents
Technical values come from the manufacturer's documents; verified on 18 September 2026. 1 documents at the bottom of the page.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
Direct contact and advisory line: 0850 532 6 777
The most common questions about the RealMan Dual-Arm Lift.
RealMan Robotics' dual-arm vertical lift mobile manipulator: two 6-axis RM65-B-V arms carrying 5 kg each on a 900 mm lift column, 0-2400 mm vertical reach when fully extended, integrated vision sensors, a CTAG2F90D gripper and autonomous navigation. The body measures 640 × 450 × 1780 mm and weighs approximately 157 kg.
Through wired teleoperation an operator drives the robot in real time; the task data of both arms is recorded and used in AI model training. RealMan runs the same workflow with dual-arm lift platforms at its humanoid robot data training center in Beijing.
The standard configuration is two RM65-B-V arms; the RM75-B-V arm is offered as an option. Arm choice is fixed in the order configuration and reflected in the corporate quotation.
With the lift column fully extended vertical reach is 0-2400 mm; lateral reach is 790 mm beyond the base on one side and forward reach 0-690 mm. Payload per arm is 5 kg.
It performs shelf scanning and inventory monitoring while navigating the aisles autonomously, and handles product recognition and grasping with its integrated vision sensors and gripper. The video on this page shows that application in a store deployment.
It is sourced on a project basis; import, customs clearance, commissioning and engineering support are part of delivery. Investment is set by corporate quotation against arm choice, gripper and teleoperation configuration, quantity and delivery terms. Send your task definition and data collection goal; the quotation follows.