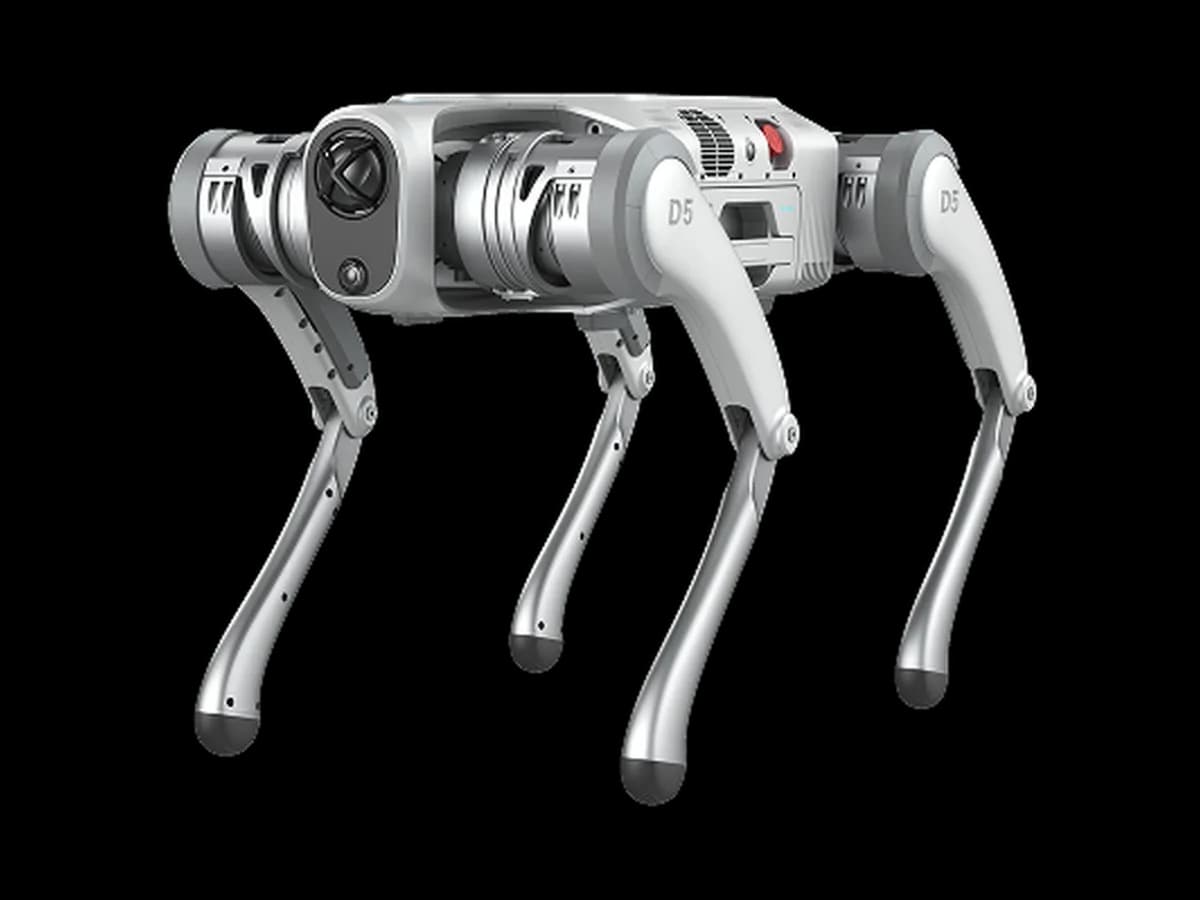
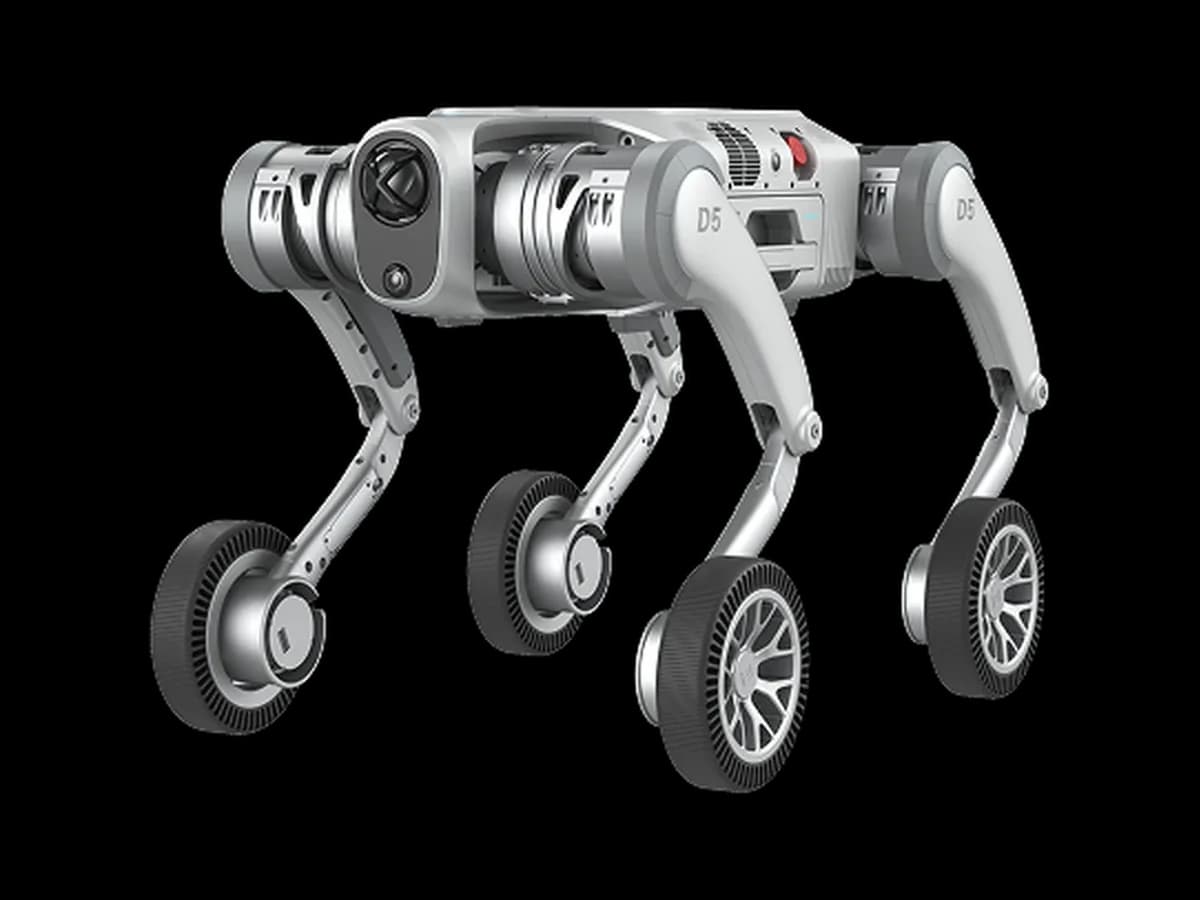
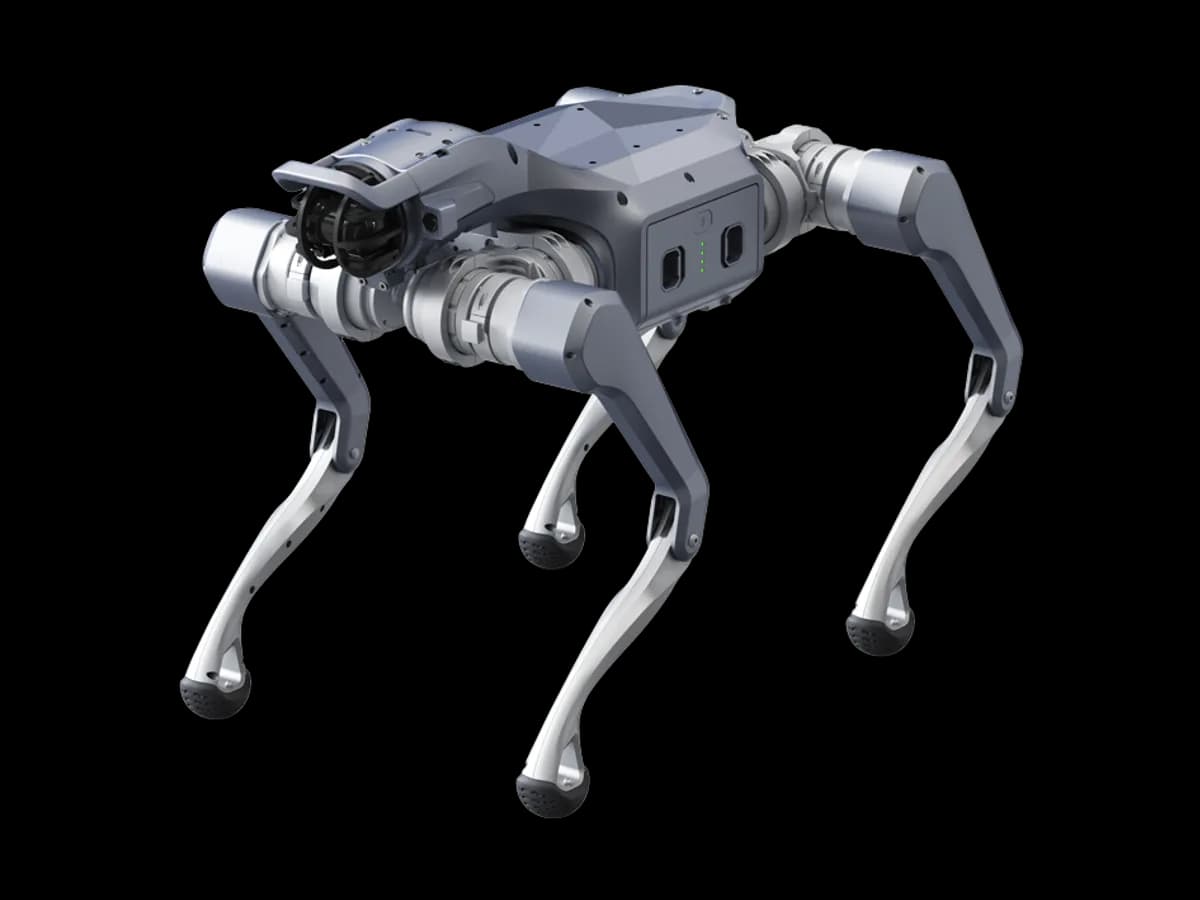
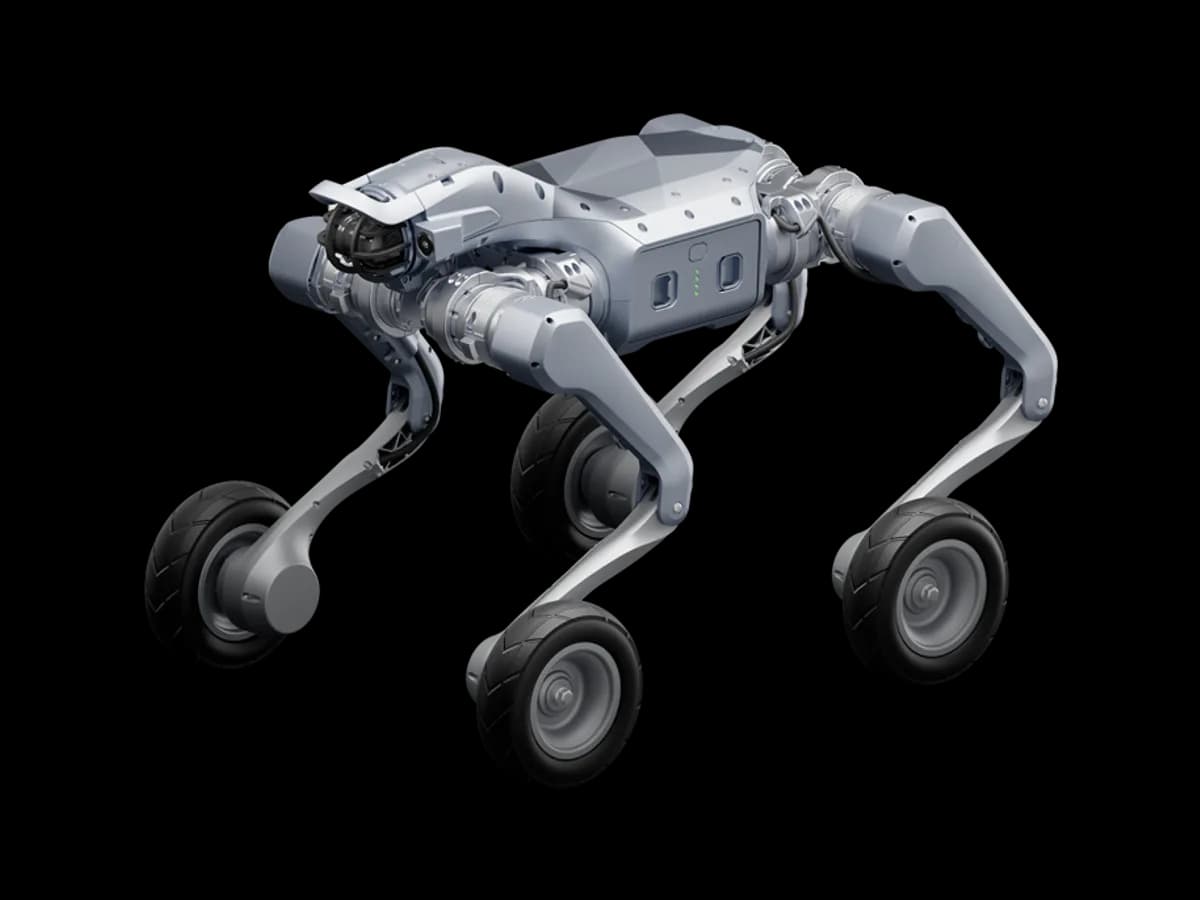
- Mobility form
- Quadruped; 12 degrees of freedom (3 per leg), RL-based gait control
- Degrees of freedom
- 12 (entire machine), 3 per leg
- Joint motor
- Dual-encoding joint control; requires no zero-position calibration, ready to use upon startup
- Torque density
- Joint peak torque 48 Nm; drive specific power 2 kW/kg
- Materials
- Aluminium alloy and high-strength engineering plastic; vacuum press-formed aluminium shafts, sealed and corrosion-treated core components; IP54; 16 kg
- Material
- Aluminum alloy with high-strength engineering plastic; vacuum press-formed aluminum shafts
- Manufacturer note
- The manufacturer states 200 h of stable operating time in extreme environments; values are laboratory test data. The intelligent follow function requires user secondary development.
- DoF layout
- 12 degrees of freedom, 3 per leg; 12 aluminum alloy precision joint motors
- Joint torque
- Peak joint torque 48 Nm; drive system specific power 2 kW/kg
- Joint range
- Range of motion: body -28° / +28°, thigh -170° / -66°, calf +35° / +156°
- Joint control
- Dual-encoder control; no zero calibration, ready on startup; impact resistant, long module lifespan
- Protection
- IP54; vacuum press-formed aluminum alloy shafts, sealed protection and anti-corrosion treatment on core components; 200 hours of stable operation in extreme environments
- Packaging
- Packing box 80 × 45 × 25 cm; the box holds the robot, battery, charging dock, adapter with 5 power cables, screen remote, manual, transport case, 4 anti-slip feet and a tool kit