Skip to content
Robotlar

Unitree Dex5-S

Five-Finger Dexterous Robot Hand (22 Active DoF)

Active DoF
22
Every joint has its own motor
Weight
620 g
Aluminium alloy body
Payload
2 kg
Peak; 1 kg continuous
Control Rate
1000 Hz
Ethernet and USB
Supply
15-65 V
Peak 200 W, XT30
Interface
2 x T1s
Ethernet, RS-485, USB

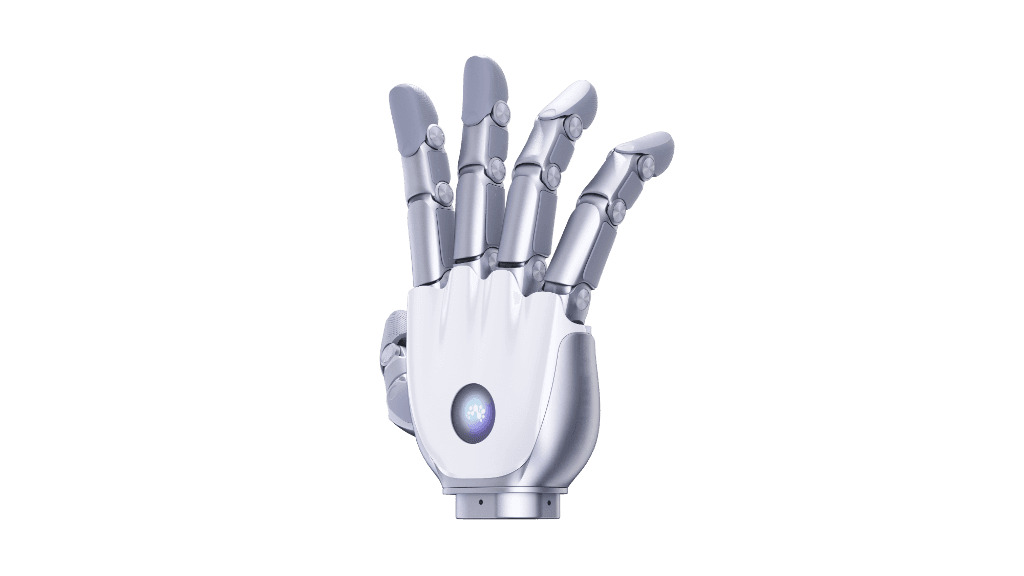
The Unitree Dex5-S is a five-finger dexterous hand that Unitree Robotics designed at exact human-hand scale. Each of its 22 active degrees of freedom is driven by its own motor; all 22 motors are direct drive, back-drivable and fitted with dual encoders.

Read more

With a weight of 620 g, an aluminium alloy body, two T1s Ethernet ports, RS-485 and USB and 1000 Hz control, it mounts on a humanoid robot's wrist. The Dex5-S Pro version adds tactile sensing.

Unitree Turkey Distributor · on-site commissioning and support protocol (SLA)

Overview

The Unitree Dex5-S is a five-finger dexterous hand at exact human-hand scale that Unitree Robotics introduced in September 2026. Each of its 22 active degrees of freedom is driven by its own motor; the manufacturer states that all 22 motors are direct drive, back-drivable and fitted with dual encoders. The hand weighs 620 g, has an aluminium alloy body and carries a peak load of 2 kg and a continuous load of 1 kg.

Communication runs over two T1s Ethernet ports, one high-speed RS-485 and one USB; the control rate is 1000 Hz over Ethernet and USB. The Dex5-S Pro version adds tactile sensing; its point count is not published. Fingertip force, speed, repeatability and an official list of compatible robots are not published either. This page covers the specification table and the version difference; the Dex5-S guide page covers the launch video, task frames and the hand's place in the Unitree family. As the official distributor of Unitree Robotics in Turkey, Robotlar.org handles Dex5-S supply and integration support through a corporate quotation.

2 use cases

The Unitree Dex5-S in motion

2 videos: manufacturer footage and field recordings. Tap a cover to play.

Unitree Dex5-S product video

The video is from Unitree Robotics' official YouTube channel (21 September 2026). The tasks shown are the manufacturer's setup; actual performance depends on the project and the control software.

  • Unitree Dex5-S official launch video

Which Dex5-S fits your needs?

The manufacturer's official variant matrix; the values are documented data.

FeatureDex5-SDex5-S Pro
Active DoF2222
Weight620 g620 g
Load (per hand)Peak 2 kg, continuous 1 kgPeak 2 kg, continuous 1 kg
Interface2 x T1s Ethernet, RS-485, USB2 x T1s Ethernet, RS-485, USB
Supply15 to 65 V, peak 200 W15 to 65 V, peak 200 W
Tactile sensingNoneYes (point count not published)
QuoteGet a Quote for This ModelDex5-SGet a Quote for This ModelDex5-S Pro

Values from the table on Unitree's Dex5-S product page, 13 November 2026. Left or right hand and quantity are set in the quotation.

Dex5-S

For grasping, teleoperation and imitation learning work that runs on joint position and camera data.

Dex5-S Pro

The tactile version for work that needs fragile-object handling, slip detection or a contact map.

Use Cases

The use cases the manufacturer defines for the Unitree Dex5-S.

  1. Education and research
  2. Factory and production

Key Advantages

22 Active Degrees of Freedom at Human-Hand Scale

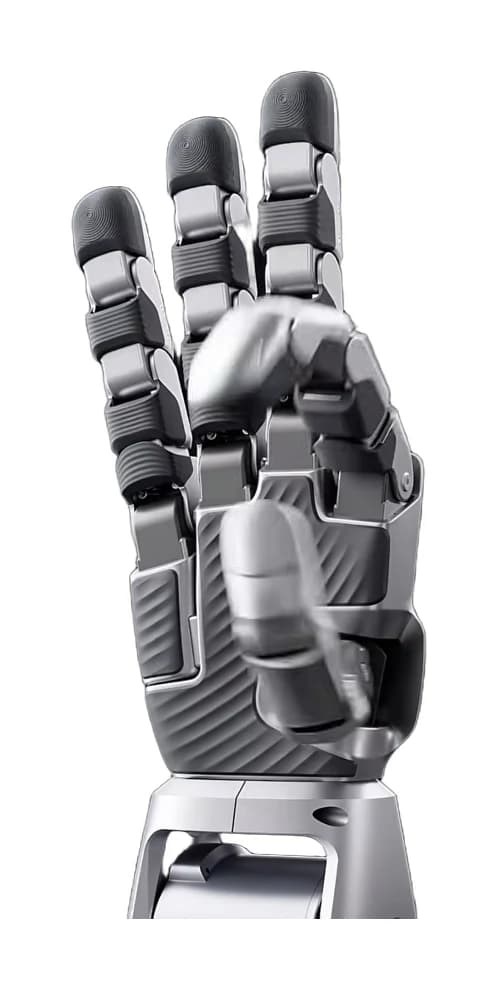
The five fingers of the Dex5-S carry 22 active degrees of freedom in total: thumb 5, index, middle and ring fingers 4 each, little finger 5.

  • (1) There are no passive or coupled joints; every joint is driven by its own motor.
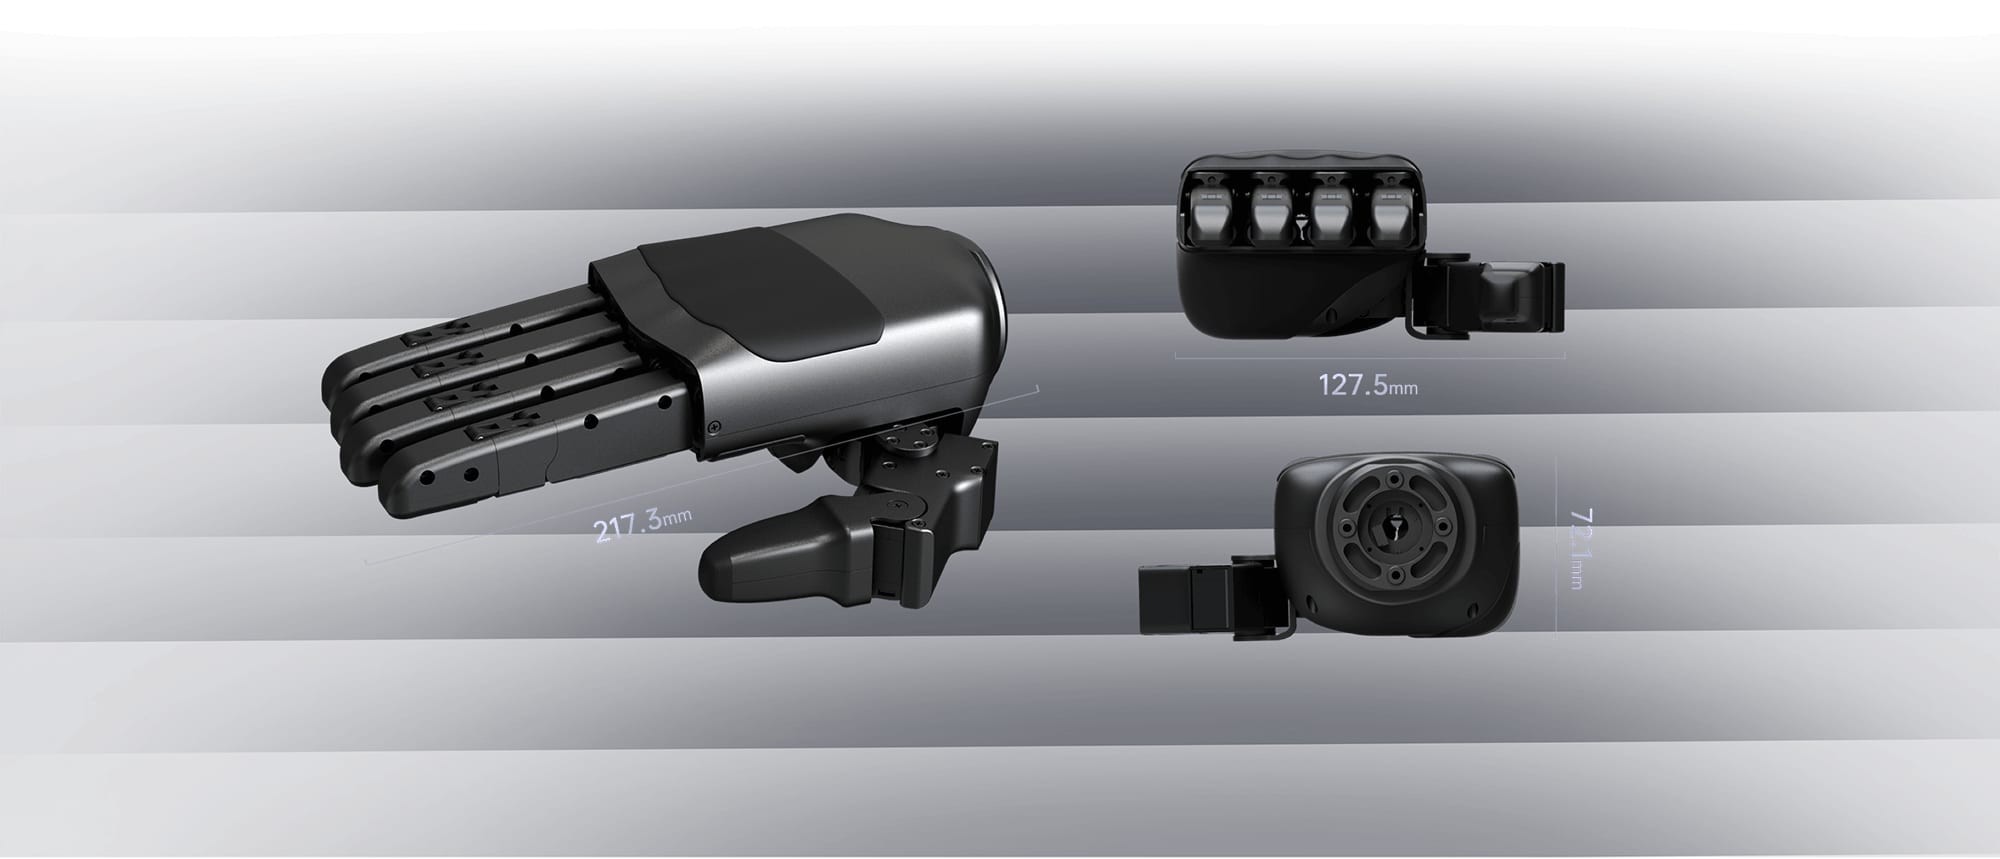
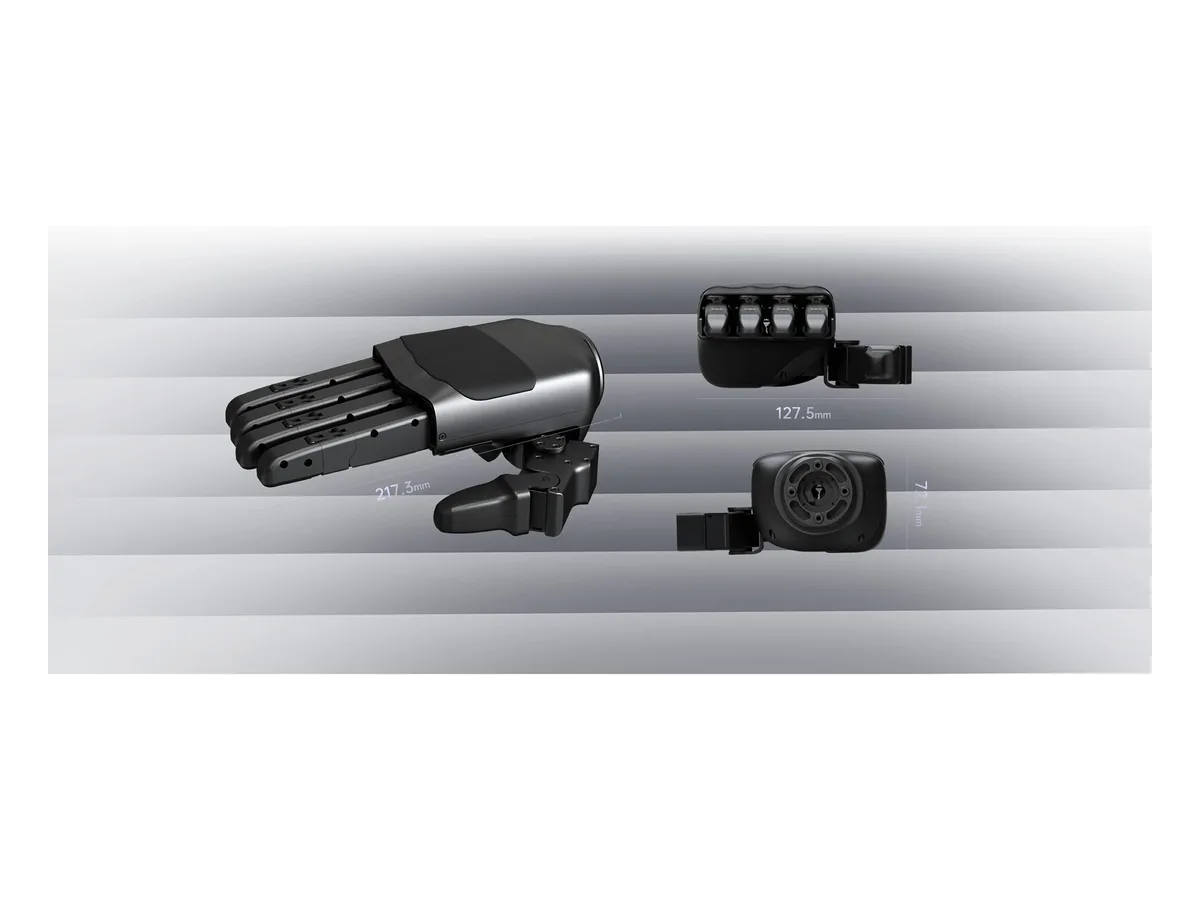
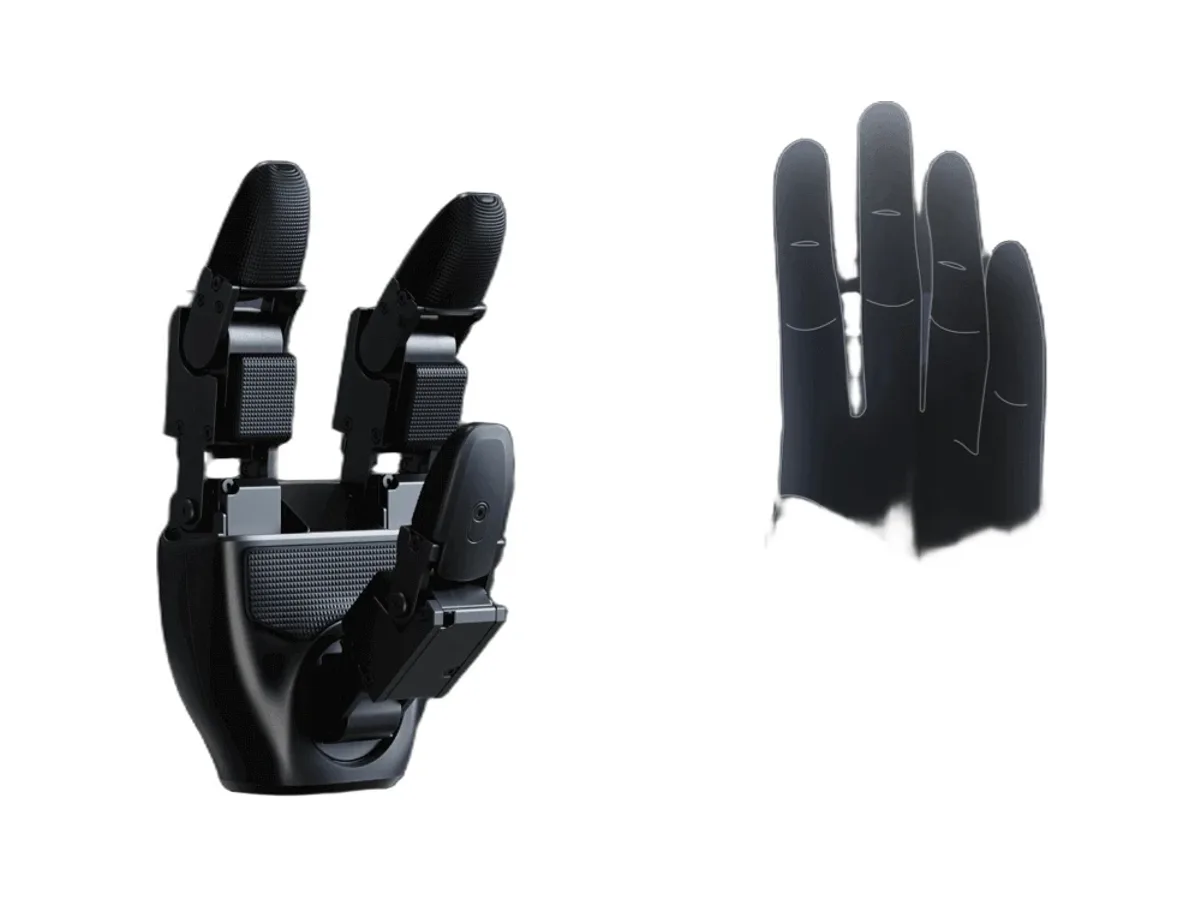
  • (2) The hand is designed at exact human-hand scale; the manufacturer's table gives a size of 102 x 187 x 26 mm.
  • (3) The front and back view in the image comes from the manufacturer's product page.
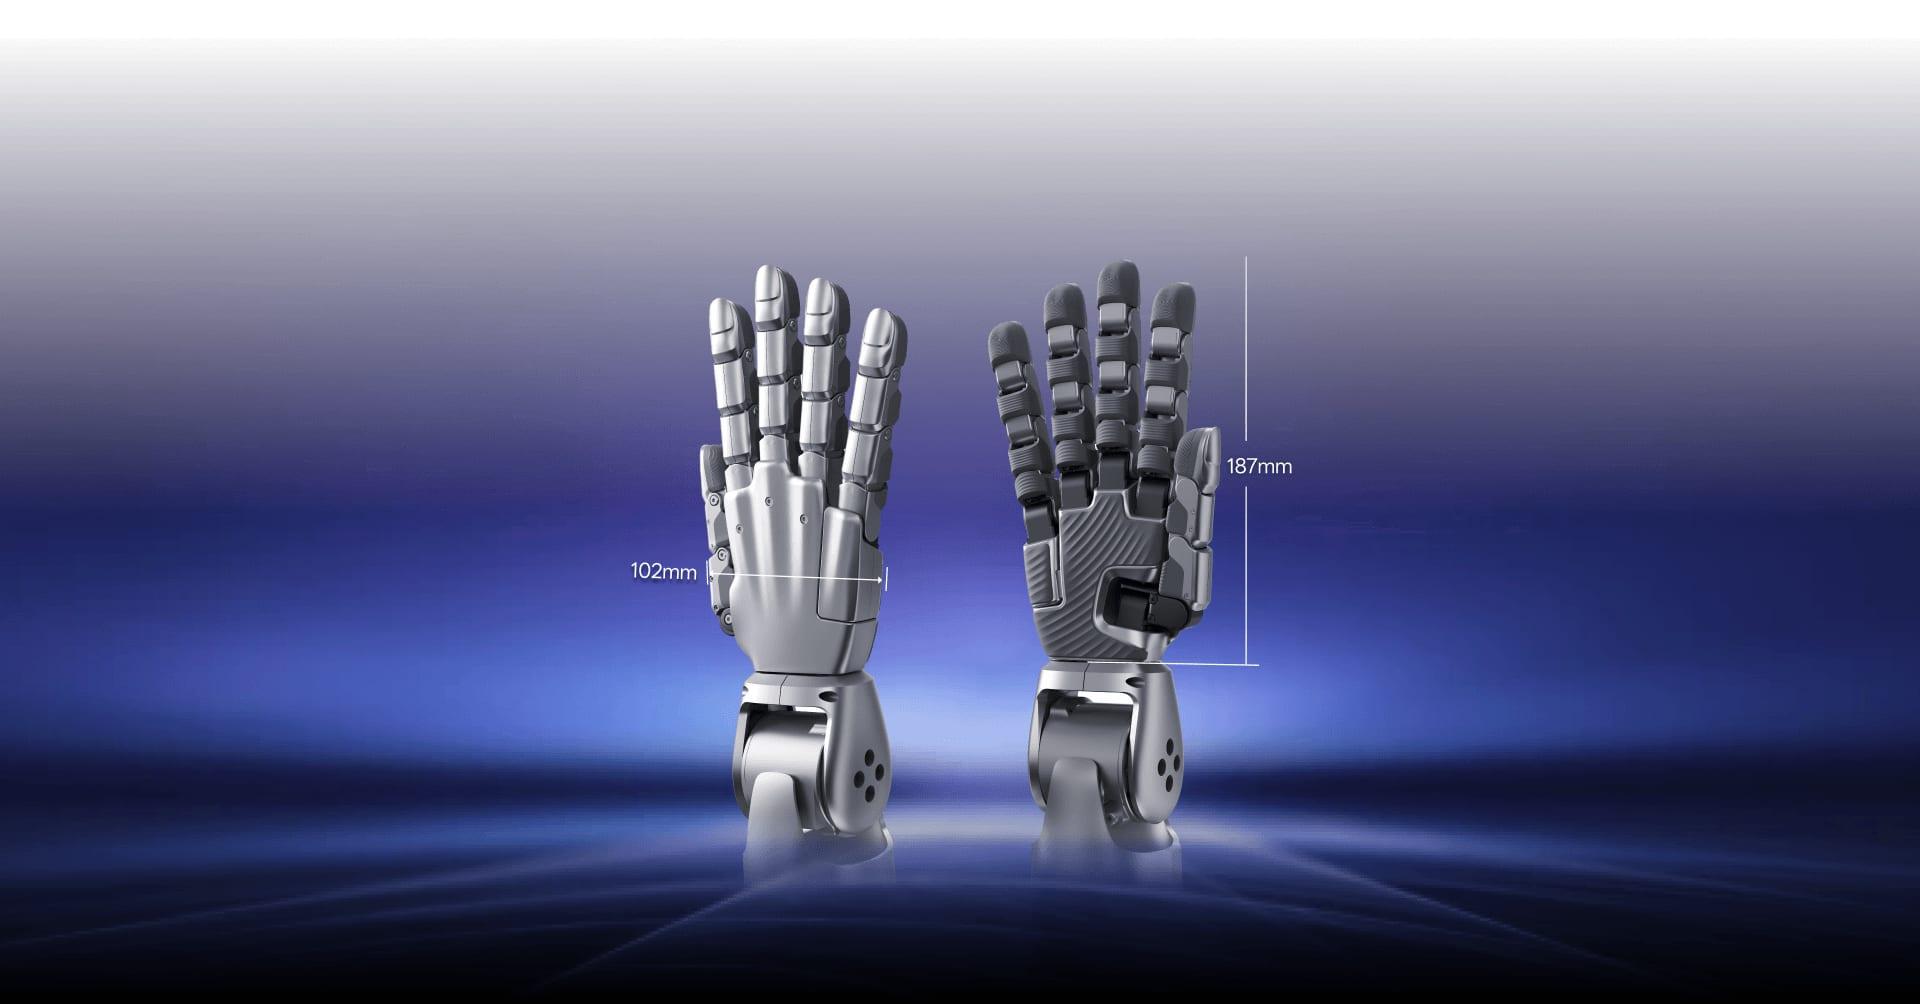
Unitree Dex5-S, 22 Active Degrees of Freedom at Human-Hand Scale

22 Direct-Drive, Back-Drivable Motors

The manufacturer states that all 22 motors are direct drive and back-drivable, each with dual encoders.

  • (1) A back-drivable joint can be turned by an external force; when the hand meets a surface it yields instead of resisting.
  • (2) Dual encoders support the measurement of joint position.
  • (3) Precision micro gearboxes are used in the transmission.
Unitree Dex5-S, 22 Direct-Drive, Back-Drivable Motors

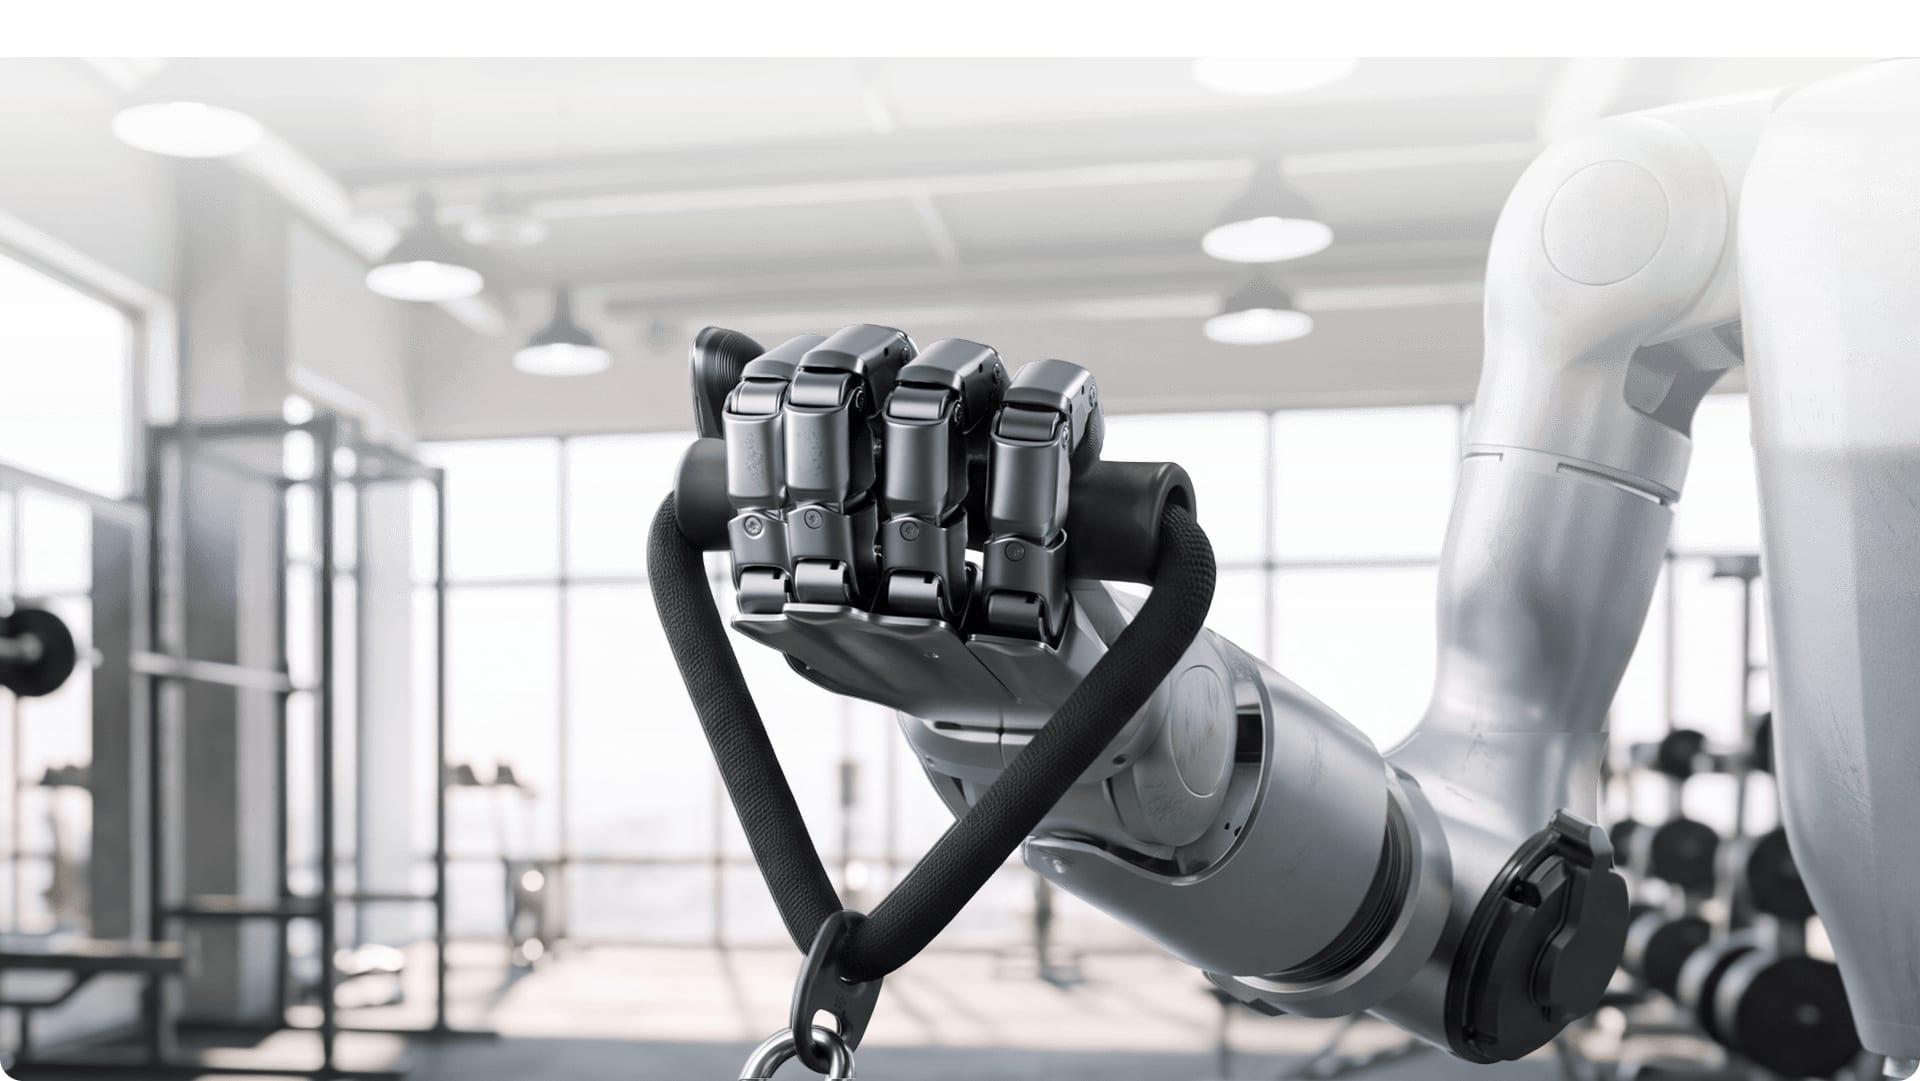
2 kg Peak, 1 kg Continuous Load

The manufacturer's table gives a peak load of 2 kg and a continuous load of 1 kg per hand.

  • (1) These values are defined for a 620 g hand; the payload limit of the humanoid wrist and arm is assessed separately.
  • (2) Fingertip force and grip force are not published.
  • The image comes from the manufacturer's product page: the hand grips a resistance-band handle.
Unitree Dex5-S, 2 kg Peak, 1 kg Continuous Load

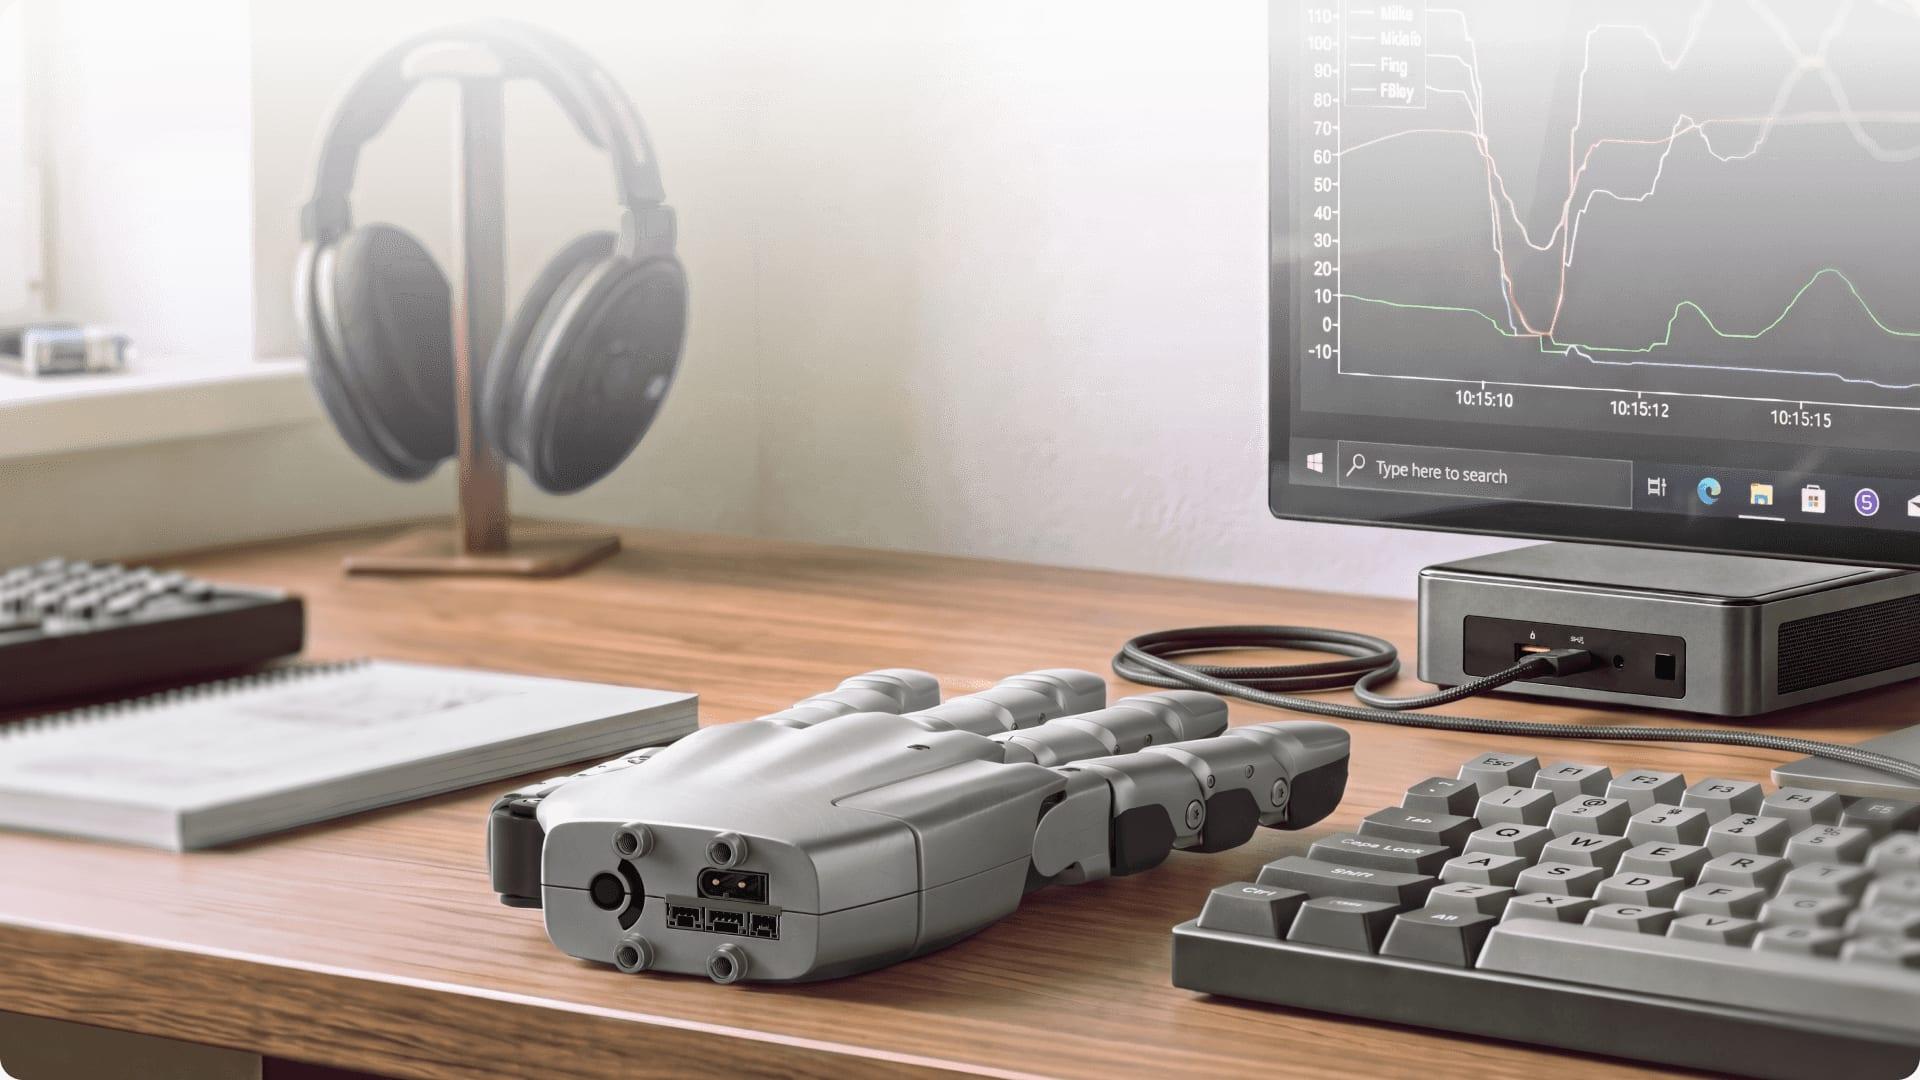
Three Interfaces: T1s Ethernet, RS-485, USB

The hand has two T1s Ethernet ports (1000BASE-T1), one high-speed RS-485 and one USB connection.

  • (1) The control rate is 1000 Hz over Ethernet and USB and 50 Hz over RS-485; the data rate is given as 6 Mbps.
  • (2) In the Ethernet configuration a palm camera can connect directly to the hand.
  • (3) Supply is 15 to 65 V through an XT30 connector; peak power is 200 W.
Unitree Dex5-S, Three Interfaces: T1s Ethernet, RS-485, USB

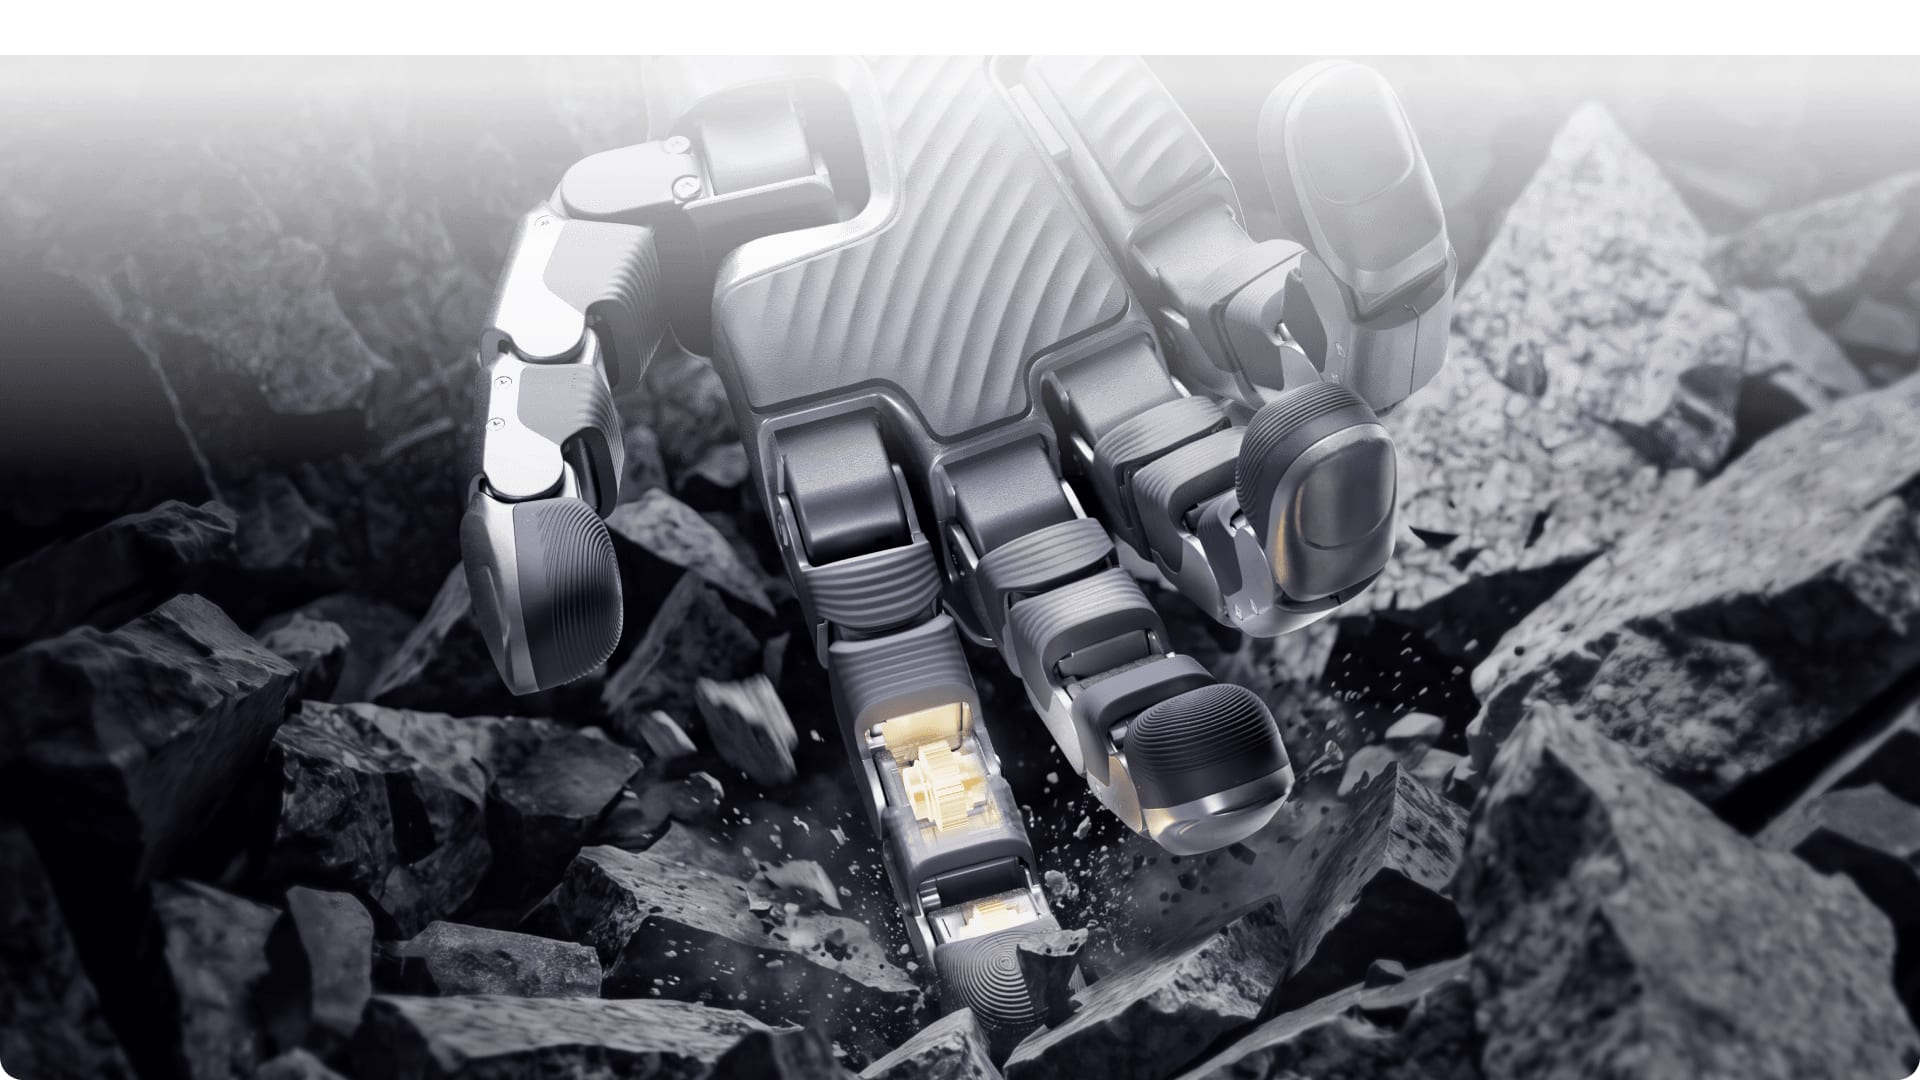
Joints Protected Against Impact

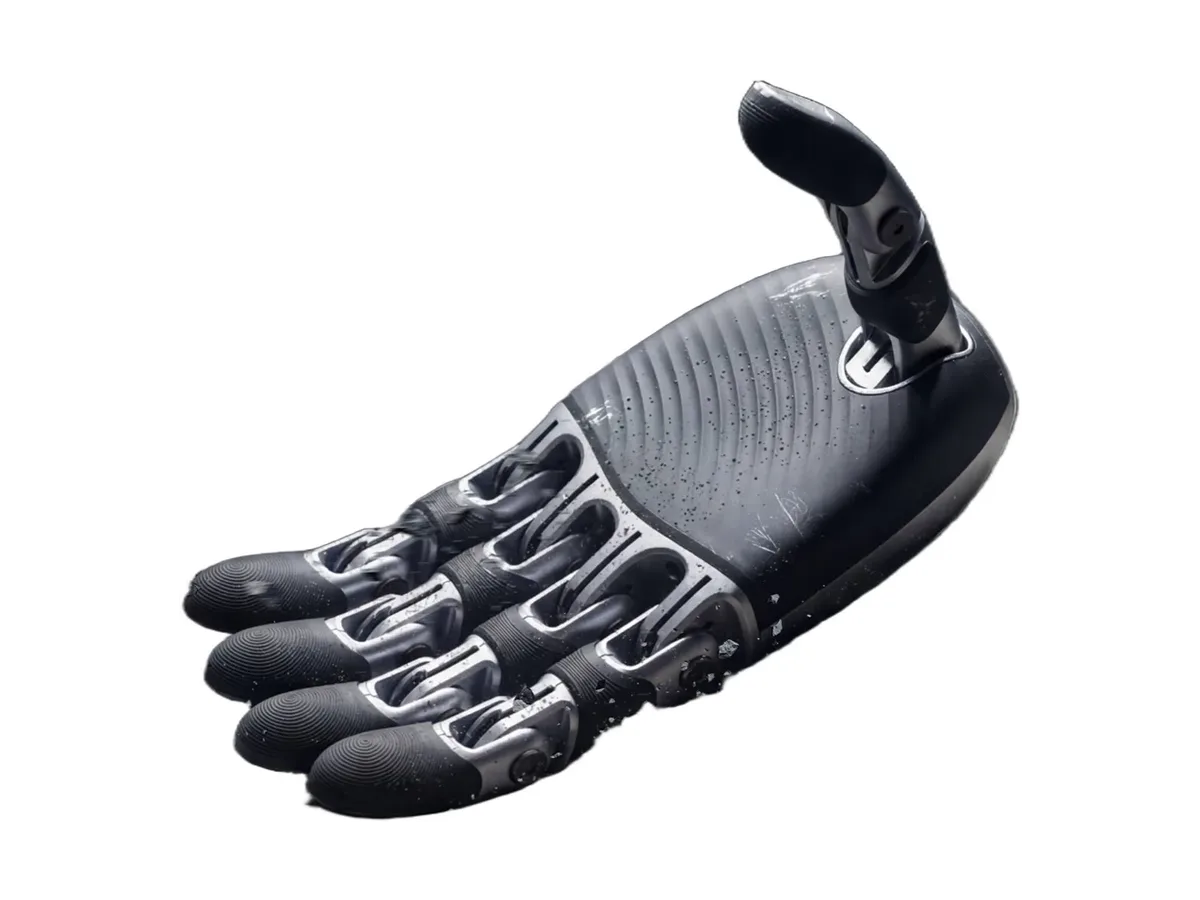
The manufacturer states that all 22 joints have an impact protection structure and that the hand passed a bending life test.

  • The official launch video says every joint has impact torque limiting protection.
  • (1) The test cycle count and ingress protection are not published.
  • (2) The image is a representative scene from the manufacturer's product page.
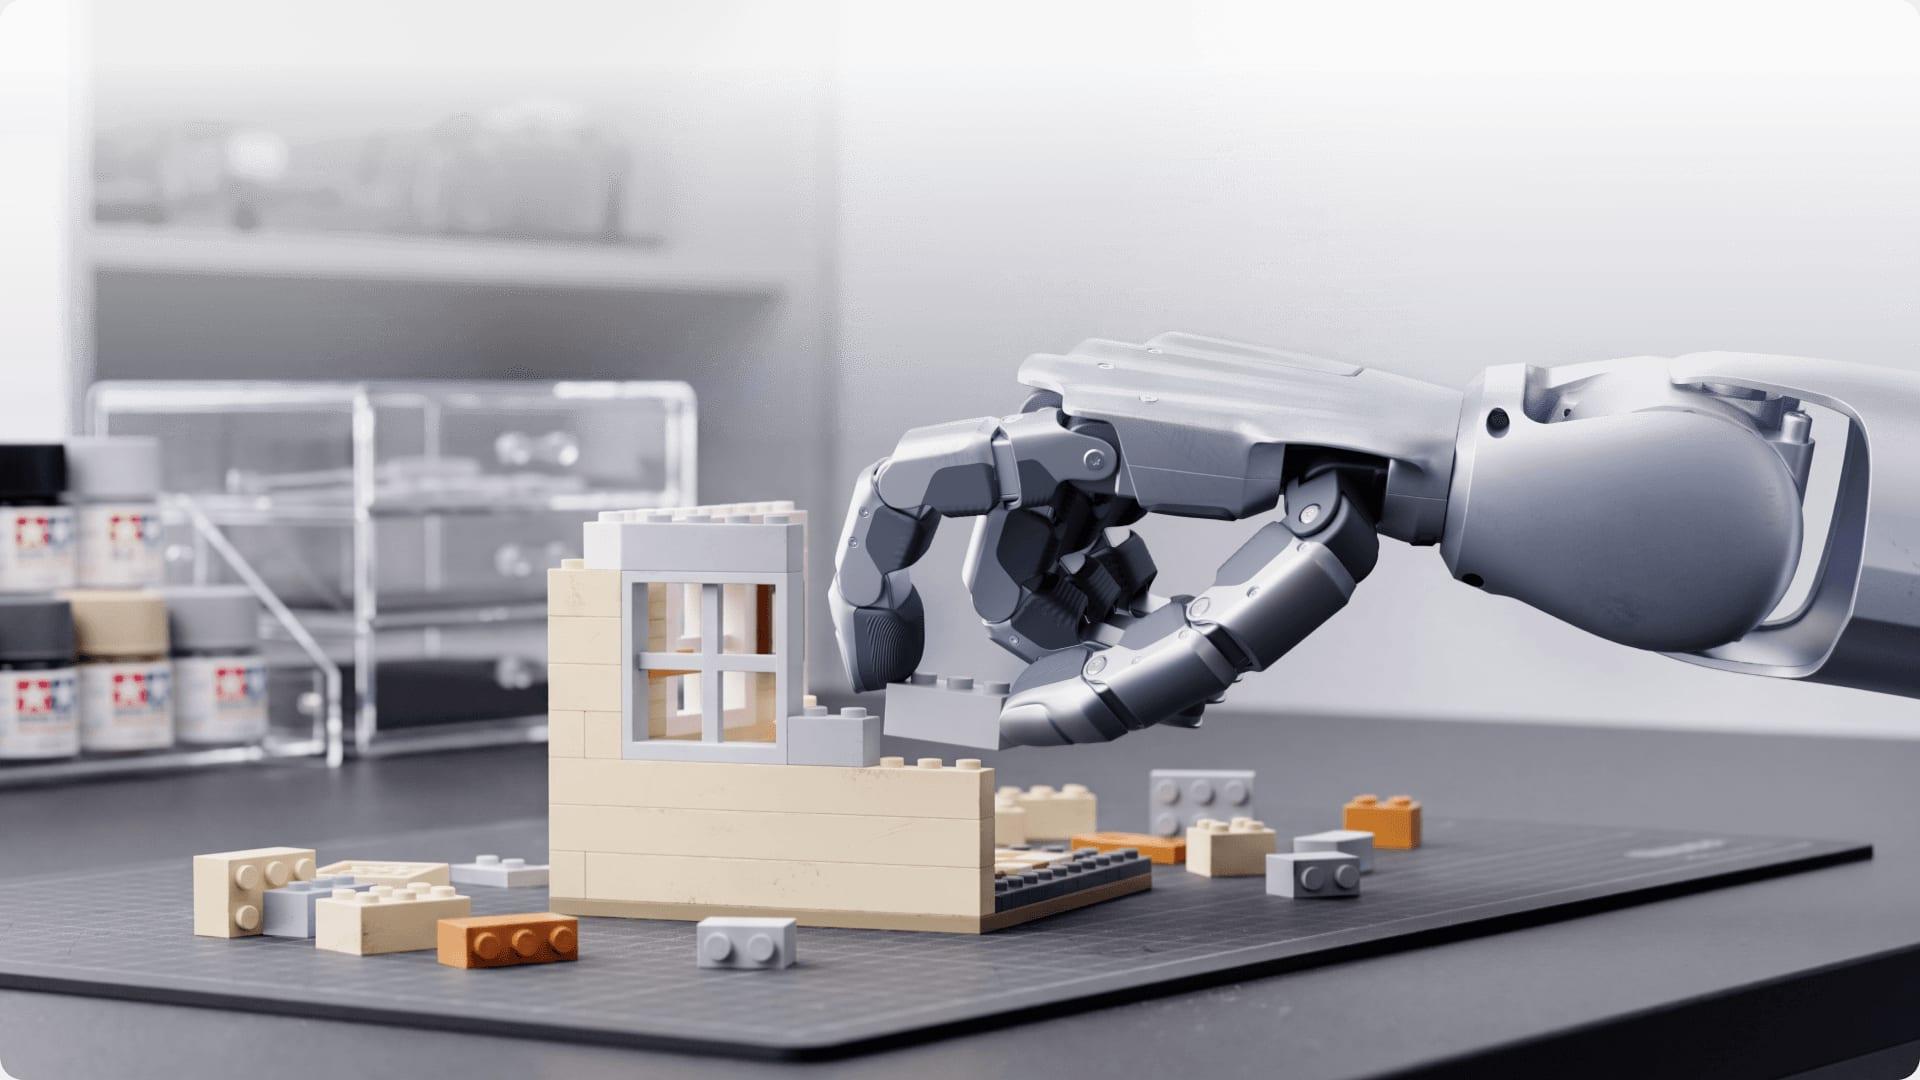
Unitree Dex5-S, Joints Protected Against Impact

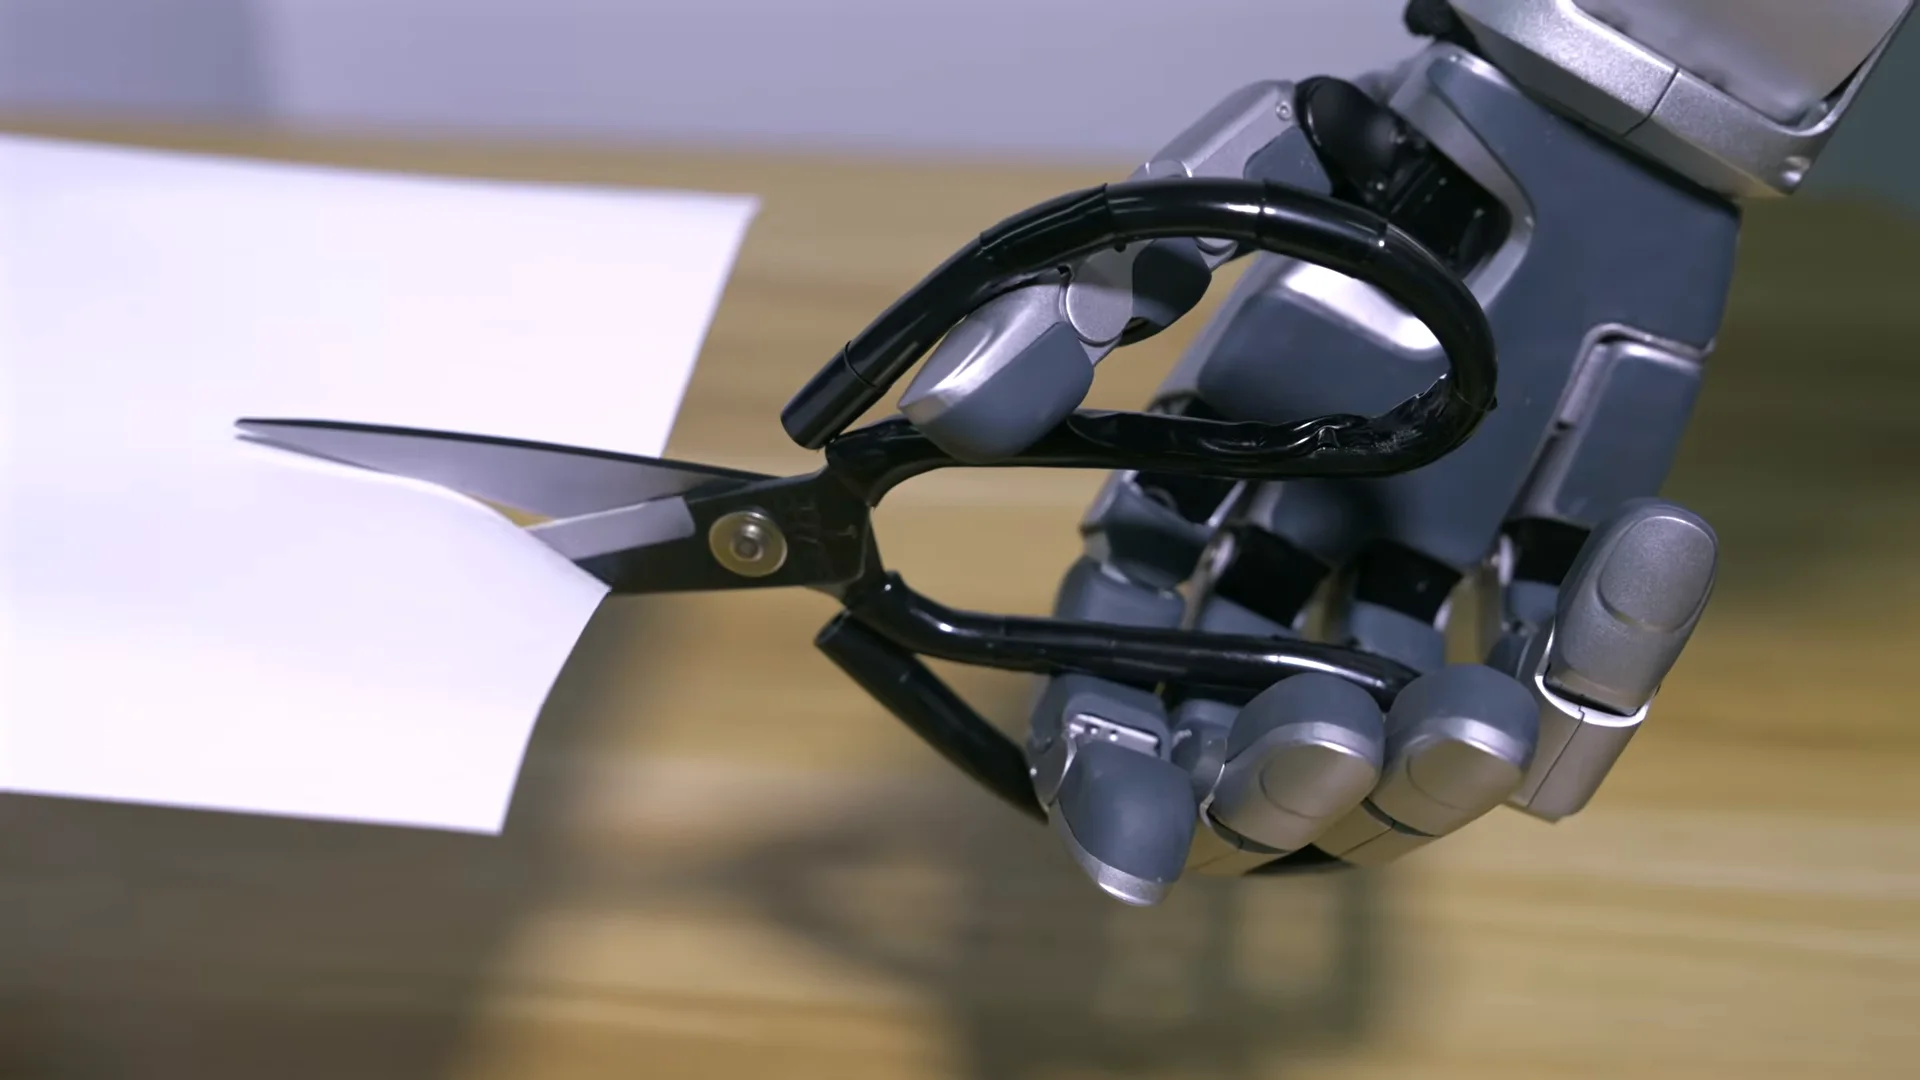
Tasks With Everyday Objects

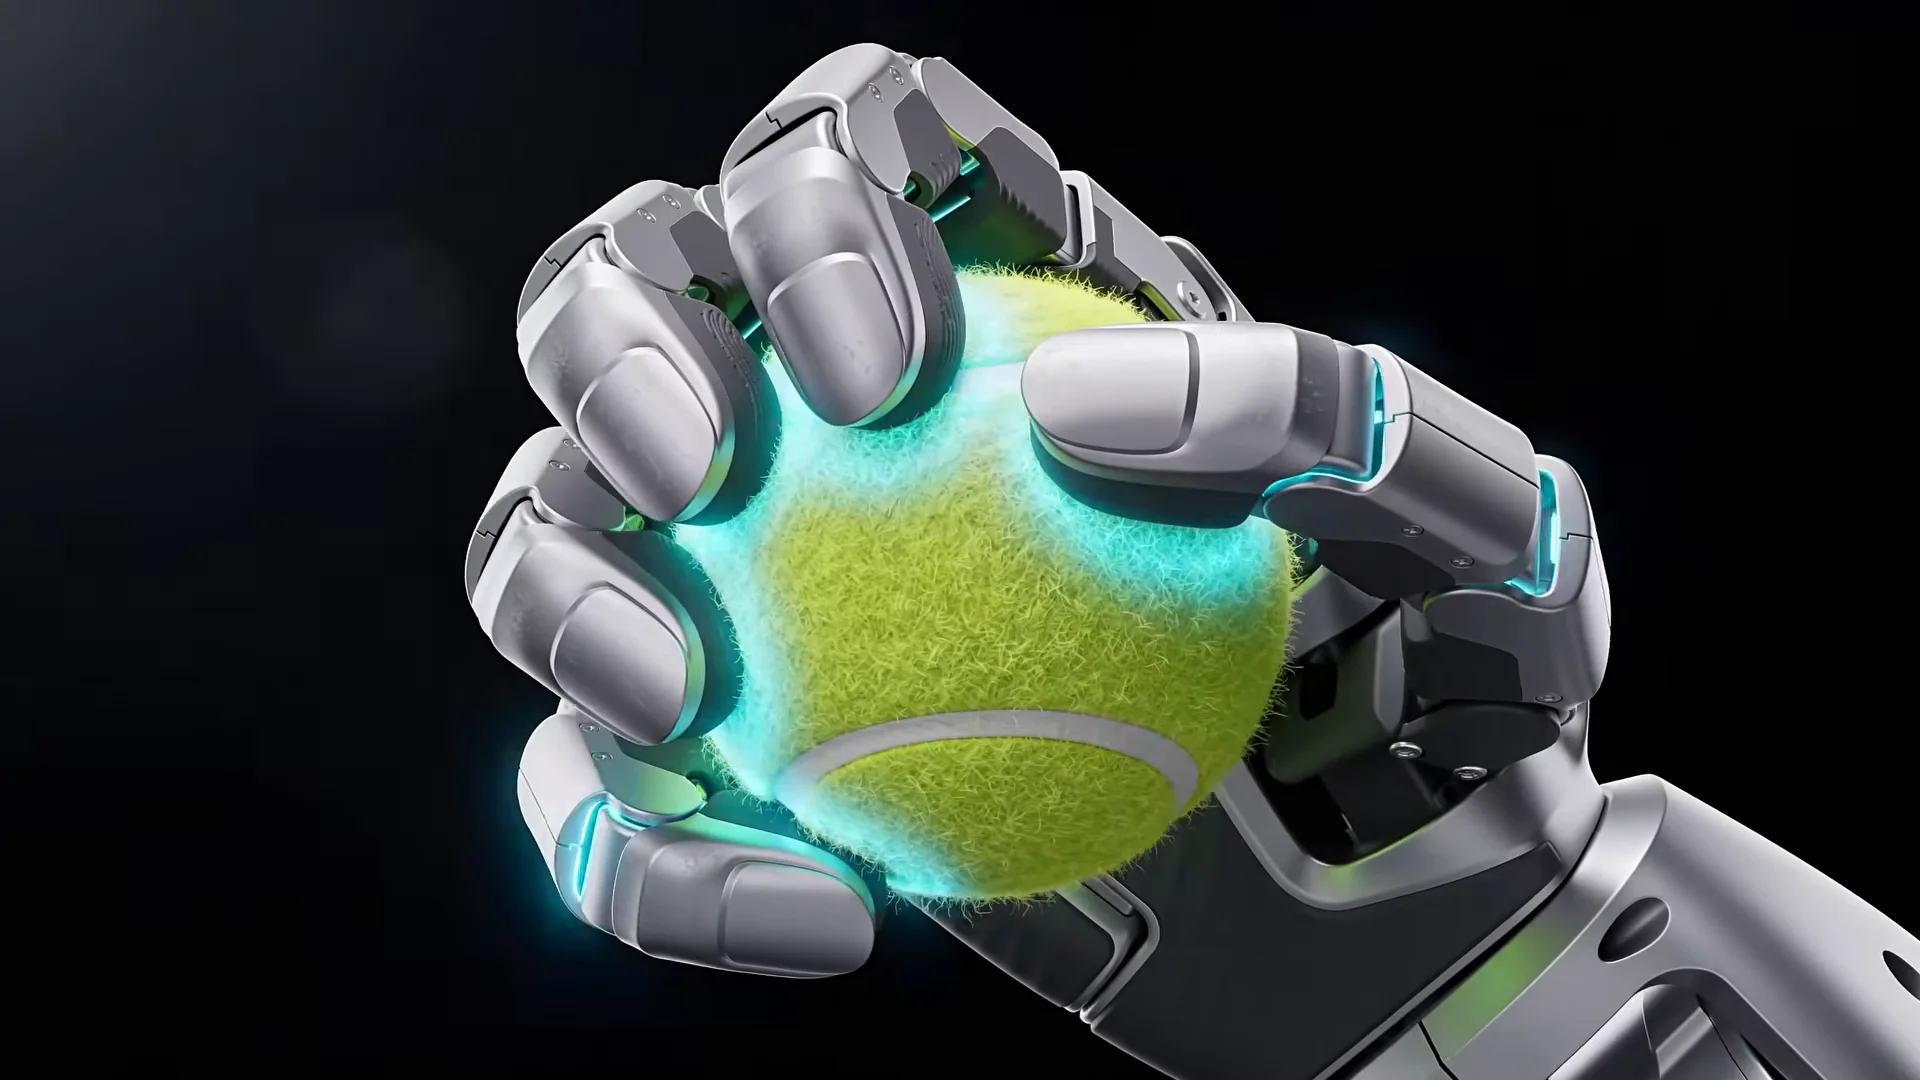
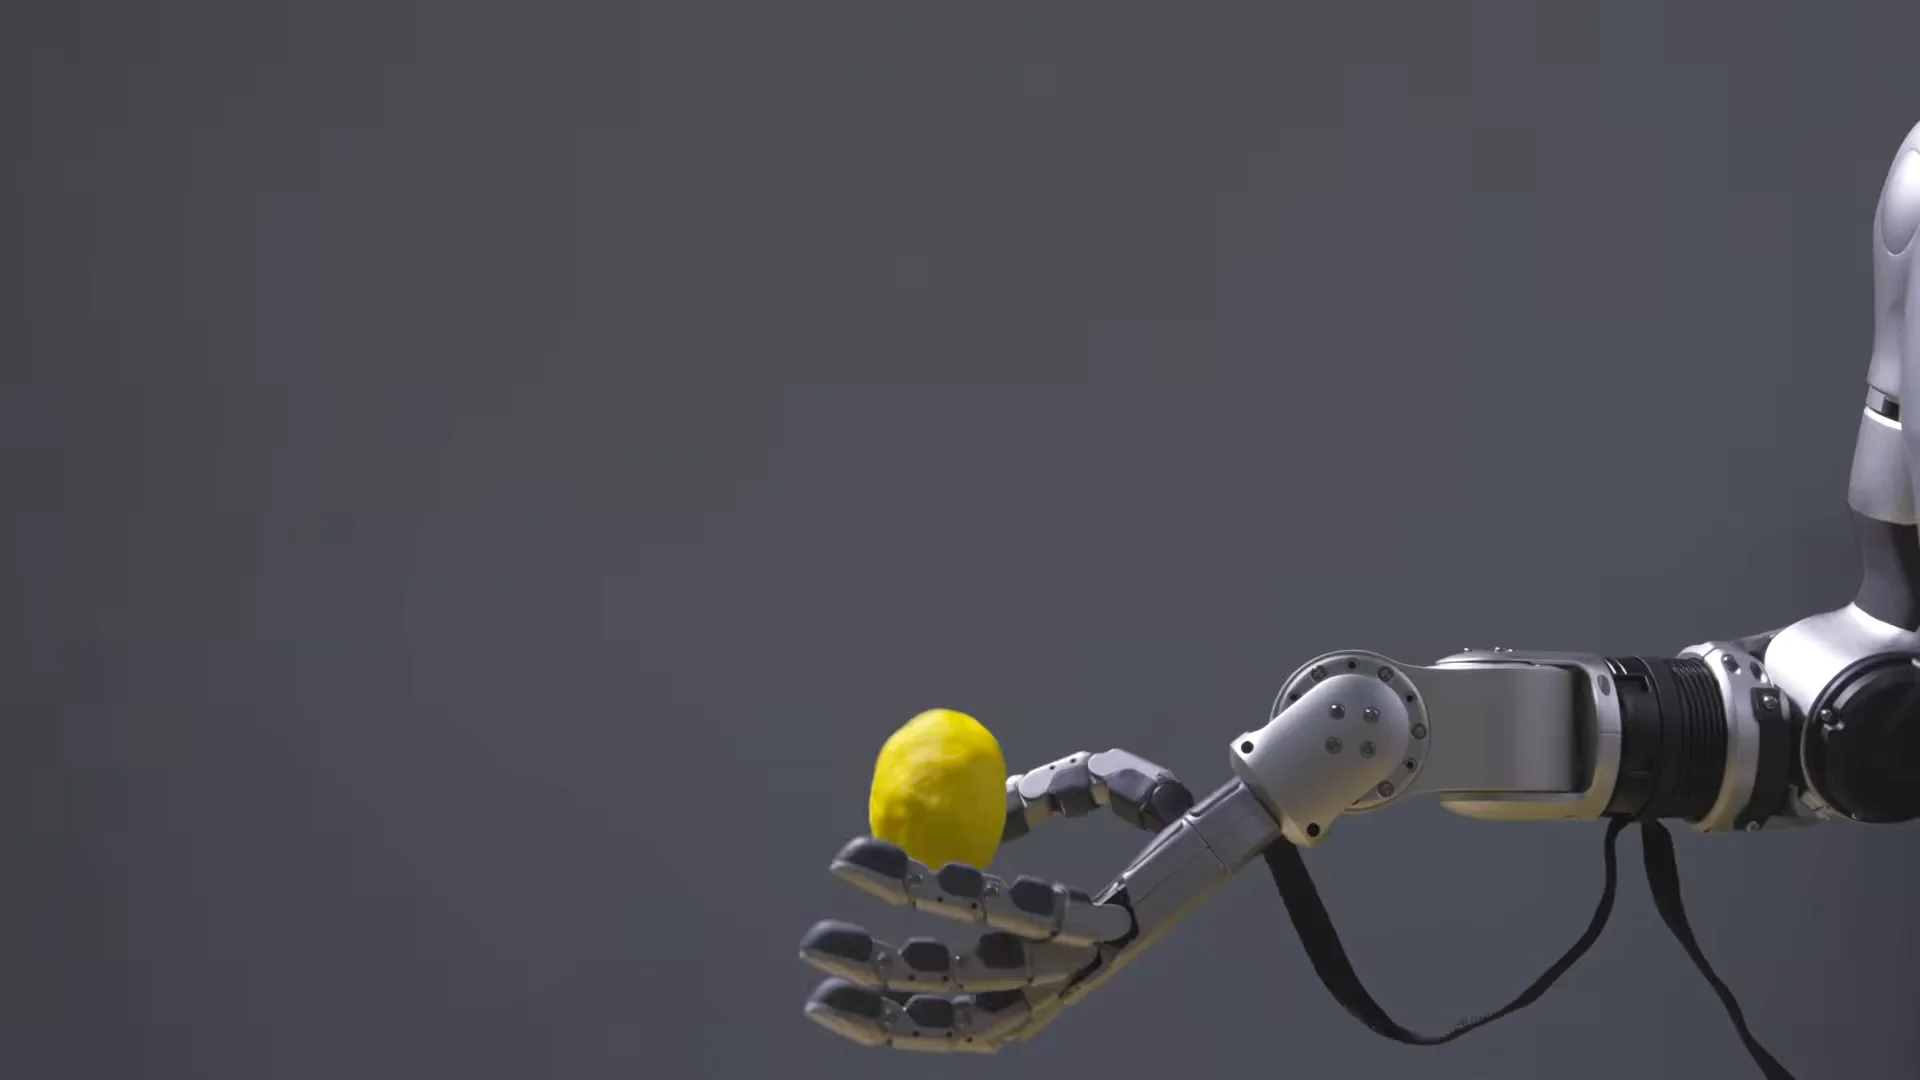
In the official launch video the Dex5-S opens a drink can's tab, cuts paper with scissors, wraps five fingers around a tennis ball and, mounted on a humanoid arm, holds a small piece of fruit.

  • (1) These tasks are the manufacturer's demonstration; the hand does not ship with these skills.
  • (2) Task skill comes from the project's control software and training data.
Unitree Dex5-S, Tasks With Everyday Objects

Dex5-S and Dex5-S Pro

The manufacturer's table gives two columns.

  • All mechanical and electrical rows are the same; the only difference is the tactile sensing row: none on the Dex5-S, present on the Dex5-S Pro.
  • (1) The tactile point count and any additional hardware of the Pro version are not published.
  • (2) Projects that need contact force measurement choose the Pro version and request the sensor details from the manufacturer in writing at the quotation stage.
Unitree Dex5-S and Dex5-S Pro

Software and Simulation

Unitree's unitree_ros repository includes a URDF model for the Dex5-S; unitree_sdk2 defines the hand command and state messages (HandCmd_, HandState_).

  • (1) Unitree's xr_teleoperate teleoperation tool has no ready option for the Dex5 hands; it supports the Dex1, Dex3, Inspire and BrainCo hands.
  • (2) The scope of mounting, wiring and software documentation for the Dex5-S is clarified at the quotation stage.
Unitree Dex5-S, Software and Simulation

Unitree Dex5-S: What It Carries, and Where

22 active joints

Thumb 5, index, middle and ring 4 each, little finger 5 degrees of freedom.

Human-hand scale

1:1 scale; objects made for people are grasped as they are.

Aluminium body

Aluminium alloy housing, 620 g in total.

Unitree Dex5-S technical hardware diagram

Direct drive

All 22 motors are direct drive and back-drivable.

Dual encoders

Two encoders on every motor; 1000 Hz control.

Impact protection

Impact protection structure on all 22 joints.

The Unitree Dex5-S up close

5 images; tap to enlarge.

22 Active Degrees of Freedom at Human-Hand Scale
22 Direct-Drive, Back-Drivable Motors
2 kg Peak, 1 kg Continuous Load
Three Interfaces: T1s Ethernet, RS-485, USB
Joints Protected Against Impact

Which robot for which job?

The Unitree Dex5-S is a candidate for all of these jobs; in each scenario our catalogue also holds other bodies that can do the same work. The right robot follows from the job itself and the delivery timeline.

Unitree Dex5-S use case: Two-handed manipulation research on a humanoid

Two-handed manipulation research on a humanoid

The lab mounts two Dex5-S hands on a humanoid's wrists and tests grasping, handover and tool-use tasks with human-scale objects. 22 active joints and 1000 Hz control let the policy work at joint level. Wrist mounting and wiring are planned through engineering within the project; no official compatibility list is published.

Unitree Dex5-S use case: Teleoperation and imitation learning data

Teleoperation and imitation learning data

The operator's hand motion transfers to a hand at one-to-one scale; joint and camera data are recorded on the same timeline. Because the scale gap is small, retargeting becomes simpler. Since Unitree's ready teleoperation tool has no Dex5-S option, the transfer layer is built within the project.

Unitree Dex5-S use case: Delicate grasping that needs tactile sensing

Delicate grasping that needs tactile sensing

In a project that needs a force limit or slip detection on a fragile object, the Dex5-S Pro is assessed. Because the Pro version's tactile point count is not published, sensor details are requested from the manufacturer in writing at the quotation stage.

Technical Specifications

18 values in 6 categories; data published by the manufacturer.

General structure
Degrees of freedom
22 active (thumb 5, index, middle and ring 4 each, little finger 5)
End effector
Five-finger hand at exact human-hand scale (1:1)
Joint motor
All 22 motors direct drive, back-drivable and fitted with dual encoders; precision micro gearboxes
Material
Aluminium alloy body
Manufacturer note
The manufacturer's table gives the size as 102 x 187 x 26 mm (L x W x H); the hand pose for this measurement is not stated. Fingertip force, speed, repeatability, minimum grasp diameter, joint angles and operating temperature are not published. No official list of compatible robots is published.
Body dimensions
102 x 187 x 26 mm (manufacturer table, L x W x H; measurement pose not stated)
Structure and materials
Aluminium alloy body; impact protection structure on 22 joints; the manufacturer states it ran a bending life test (cycle count not published)
Availability
Unitree announced the Dex5-S with an official launch video on 21 September 2026
Size and weight
Weight
0.62 kg (620 g)
Motion and performance
Payload
Peak 2 kg, continuous 1 kg (per hand)
Power and runtime
Operating power
Peak 200 W
Operating voltage
15 to 65 V, XT30 connector
Sensors and connectivity
Sensors
Dual encoders on every motor; tactile sensing on the Pro version. In the Ethernet configuration a palm camera connects directly to the hand
Interfaces
unitree_sdk2 hand messages (HandCmd_, HandState_); Dex5-S URDF model in the unitree_ros repository
Connectivity
2 x T1s Ethernet (1000BASE-T1), 1 x high-speed RS-485, 1 x USB; 6 Mbps
Tactile sensing
Dex5-S: none. Dex5-S Pro: yes (manufacturer table "Tactile Sensing: YES"; point count not published)
Joint encoder
Dual encoders on every motor
Software and development
Software features
Control rate 1000 Hz (Ethernet and USB), 50 Hz (RS-485); impact protection structure on 22 joints

An itemised quote for the Unitree Dex5-S is prepared by configuration, quantity and delivery scope.

Purchasing support

Get a quote for the Dex5-S

Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.

  • Supply and delivery scheduling backed directly by the manufacturer
  • Site- and mission-focused technical feasibility and simulation
  • Turnkey hardware, software and mission integration
  • Advisory on corporate tenders, specifications and administrative processes

Direct contact and advisory line: 0850 532 6 777

Add project details (optional)

Product of interest: Unitree Dex5-S

Dex5-S: Frequently Asked Questions

The most common questions about the Unitree Dex5-S.

What is the Unitree Dex5-S?

The Unitree Dex5-S is a five-finger dexterous hand that Unitree Robotics designed at exact human-hand scale. It has 22 active degrees of freedom (thumb 5, index, middle and ring 4 each, little finger 5); all 22 motors are direct drive, back-drivable and fitted with dual encoders. Unitree introduced the hand with an official video on 21 September 2026.

How much does the Dex5-S weigh and how big is it?

According to the manufacturer's table the Dex5-S weighs 620 g (0.62 kg) and its size is given as 102 x 187 x 26 mm (L x W x H). The table does not state the hand pose for this measurement; for mounting design the dimensions are verified against the manufacturer's drawing.

What is the difference between the Dex5-S and the Dex5-S Pro?

In the manufacturer's table all mechanical and electrical values are the same for both versions. The only difference is tactile sensing: none on the Dex5-S, present on the Dex5-S Pro. The Pro version's tactile point count is not published.

How much load can the Dex5-S carry?

The manufacturer gives a peak load of 2 kg and a continuous load of 1 kg per hand. Fingertip force and grip force are not published. When the hand is mounted on a humanoid wrist, the arm's payload limit is taken into account separately.

Which interfaces does it connect through?

The hand has two T1s Ethernet ports (1000BASE-T1), one high-speed RS-485 and one USB connection. The control rate is 1000 Hz over Ethernet and USB and 50 Hz over RS-485. Supply is 15 to 65 V through an XT30 connector, with 200 W peak power. In the Ethernet configuration a palm camera connects directly to the hand.

Which robots is the Dex5-S compatible with?

Unitree does not publish a list of compatible robots on the Dex5-S product page. With its human-hand scale the hand targets humanoid platforms, and the official video shows it on a humanoid arm. Which platform and which wrist interface it will use are defined with our engineering team within the project and stated in writing in the quotation.

Is there SDK and simulation support?

Unitree's unitree_ros repository includes a URDF model for the Dex5-S, and unitree_sdk2 defines the hand command and state messages. Unitree's xr_teleoperate tool has no ready option for the Dex5 hands. The scope of additional documentation for the Dex5-S is clarified at the quotation stage.

What is the difference between the Dex5-S and the Dex5-1?

On the Dex5-S all 22 degrees of freedom are active, it weighs 620 g and runs on 15 to 65 V. On the Dex5-1, 16 of 20 degrees of freedom are active and 4 are passive; it weighs 1,100 g, uses USB 2.0, runs on 24 to 60 V and has a published fingertip force of 10 N. The tactile versions are the Dex5-S Pro and the Dex5-1P.

How is the Unitree Dex5-S sourced in Turkey and what does it cost?

Robotlar.org is the official distributor of Unitree Robotics in Turkey. List prices are not published for Unitree products; the price is set in a corporate quotation by version (Dex5-S or Pro), quantity, left or right hand and integration scope. The delivery schedule is stated in the quotation.

Official Guarantee

Official Distributor of Unitree Robotics in Turkey

Robotlar.org is the official distributor of Unitree Robotics in Turkey, the Turkey Distributor for Pudu Robotics, and authorized systems integrator (Service Hub), providing sales, on-site engineering across Turkey, spare parts, and SDK/API integration support.

Request Corporate QuoteUnitree Competence Center
Free Pre-Sales Engineering Consultation