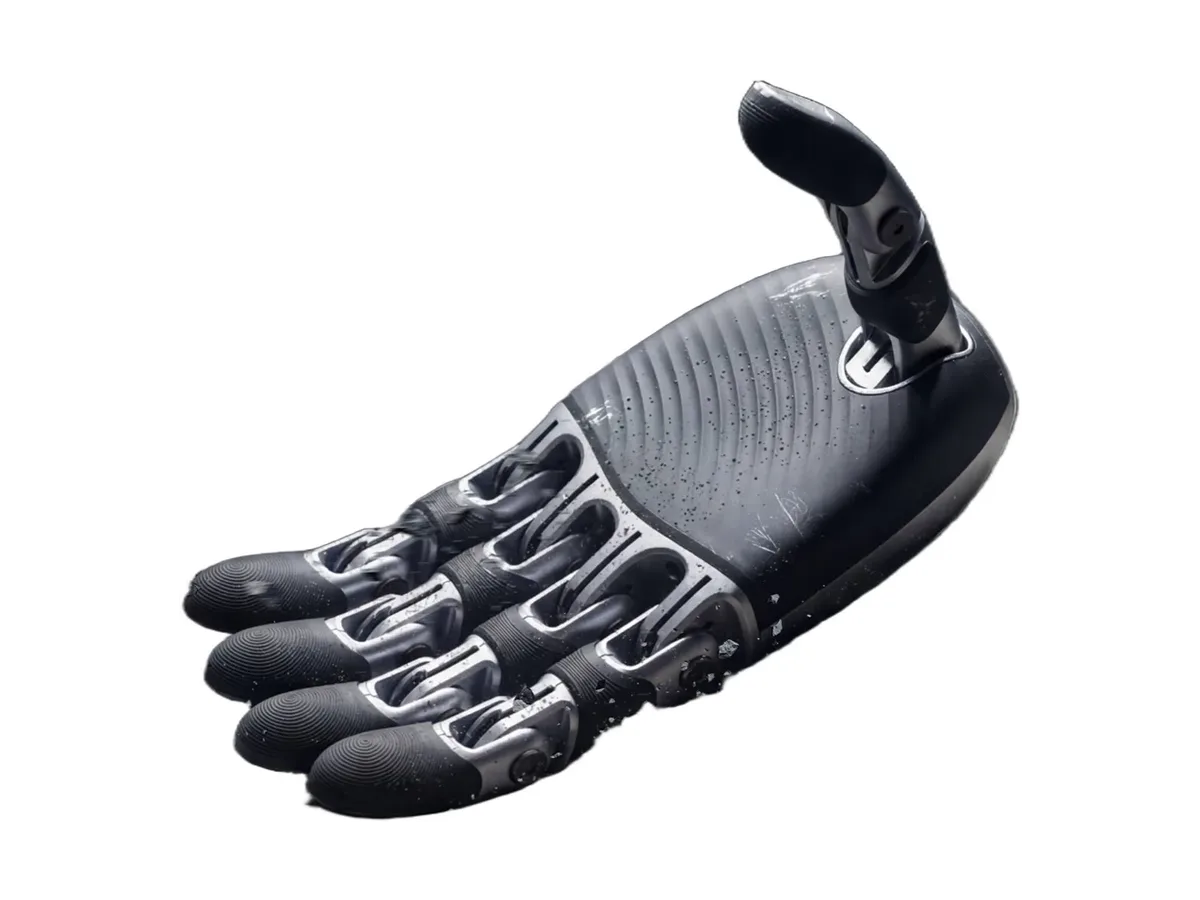
A Gripper, Not a Hand
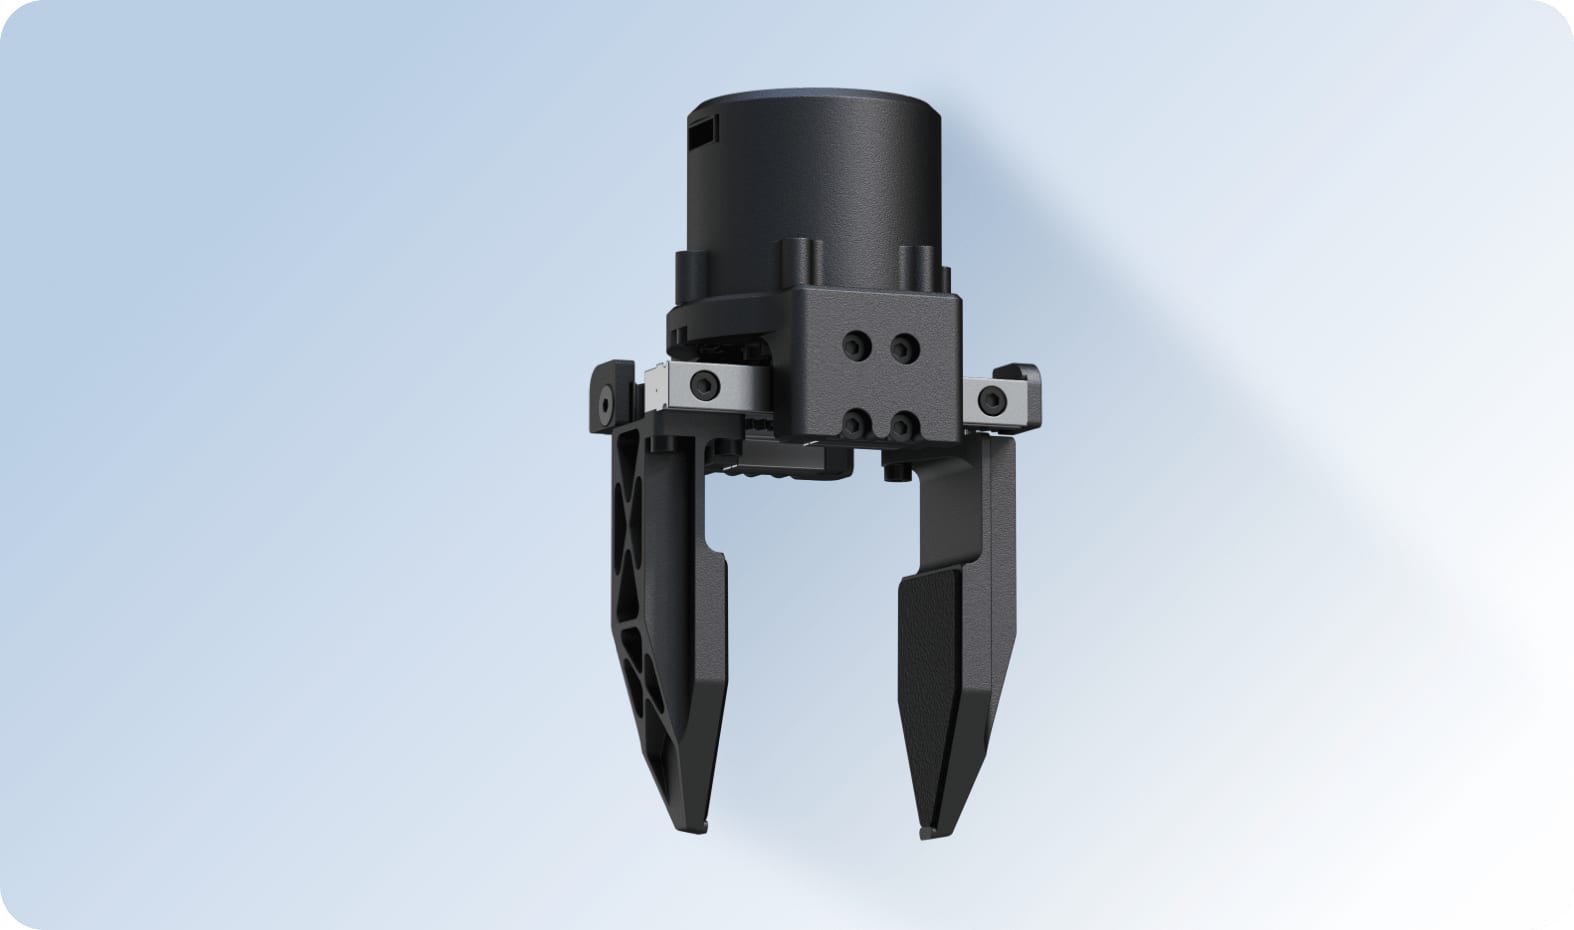
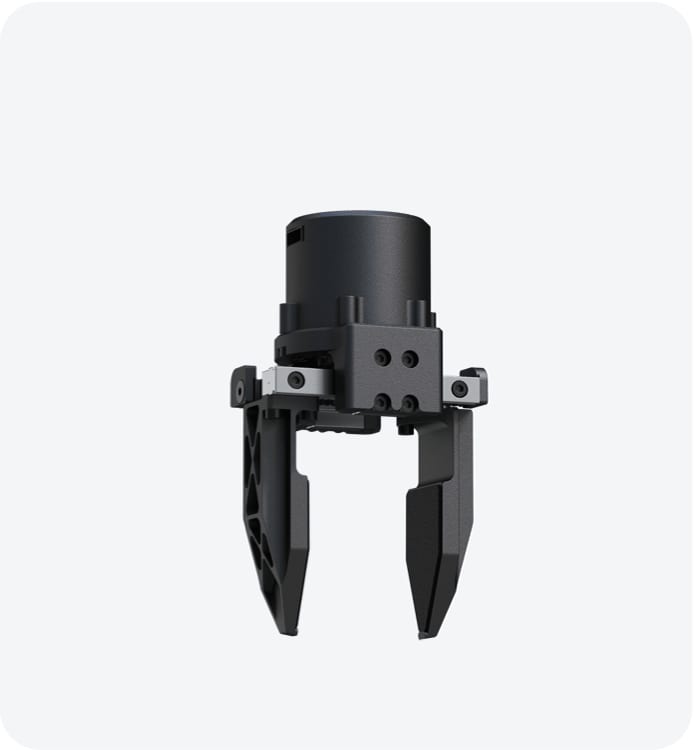
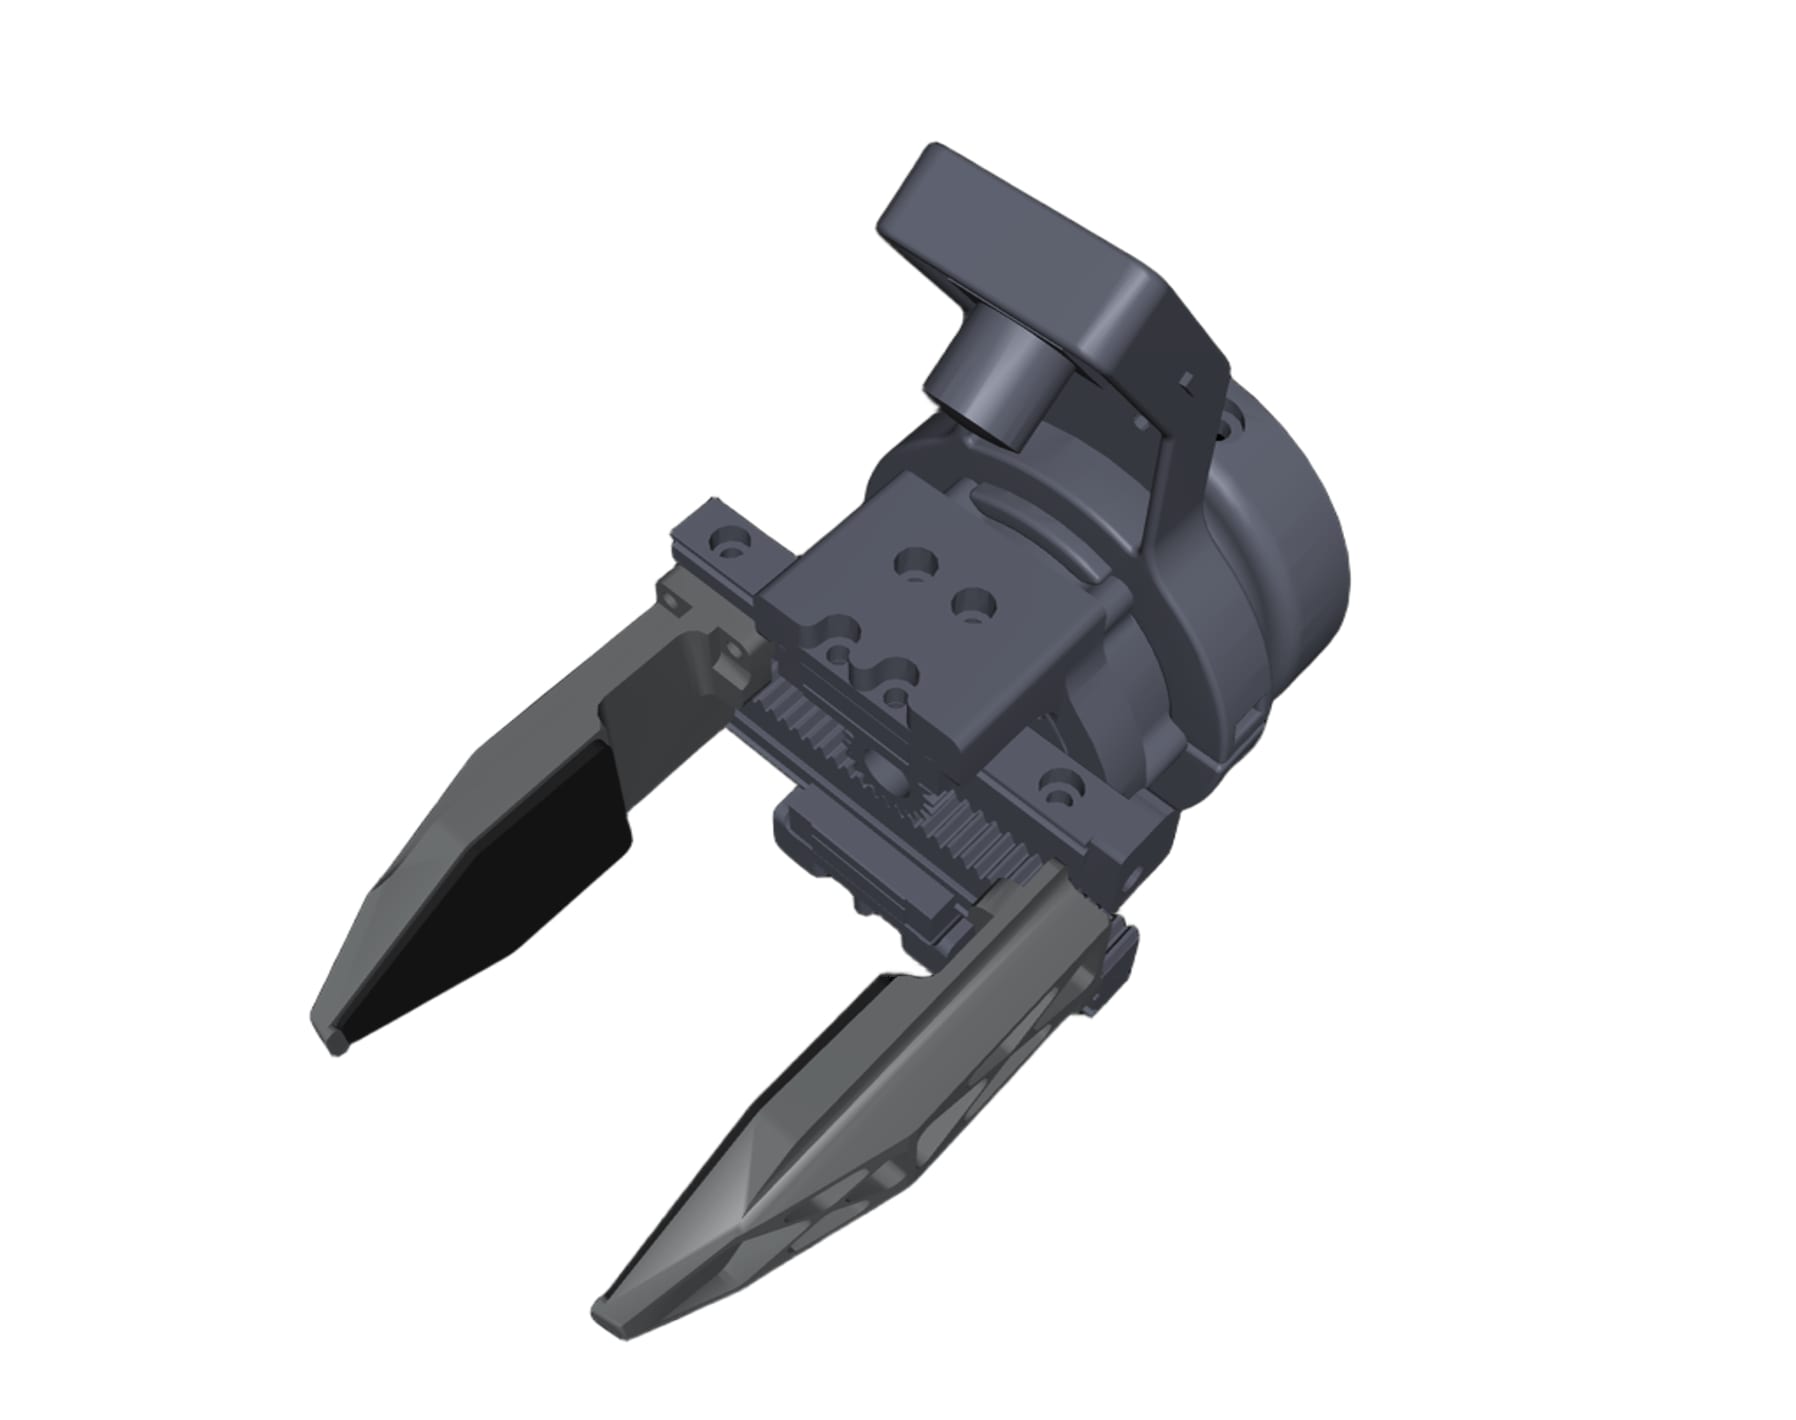
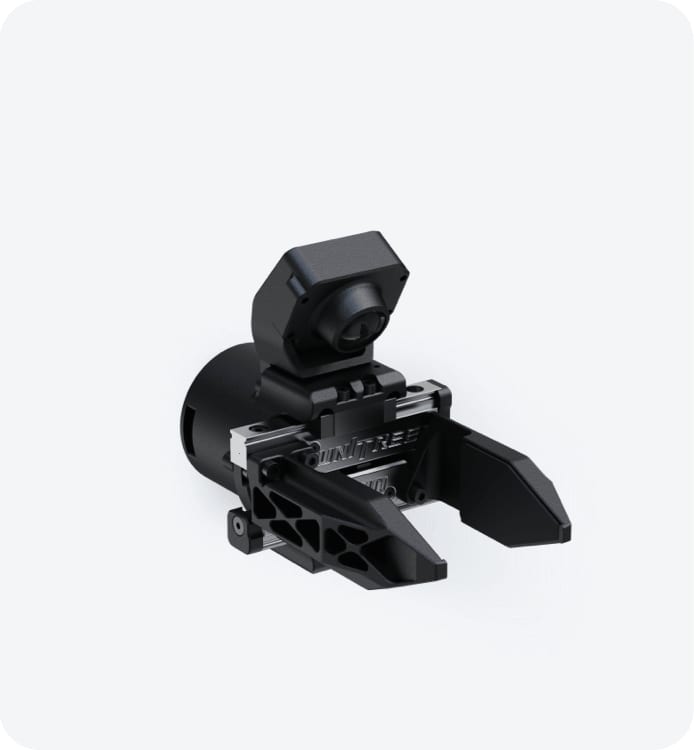
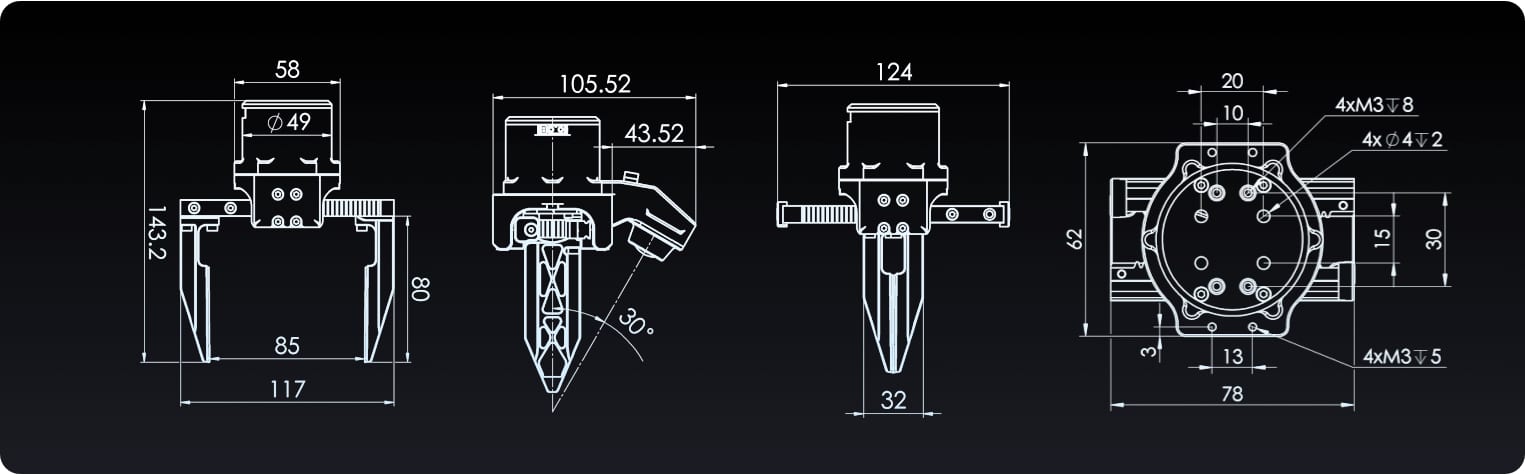
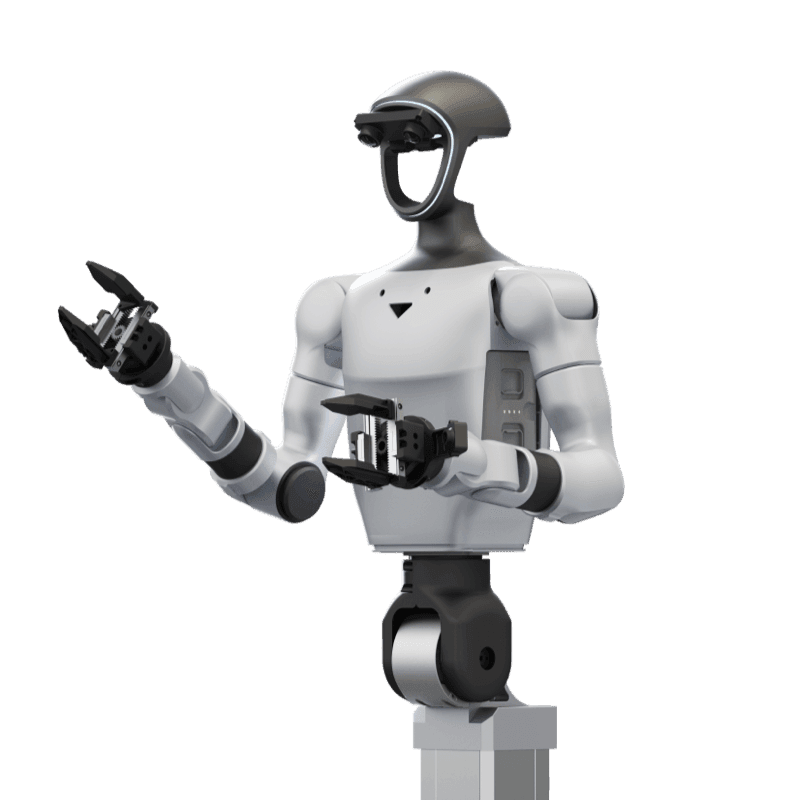
The Dex1-1 is a two-jaw parallel gripper: two jaws close together on a single axis, and there are no fingers or finger joints.
- (1) This design does one thing a dexterous hand does not: it runs repeated pick-and-place work with simple control and a high, adjustable grip force.
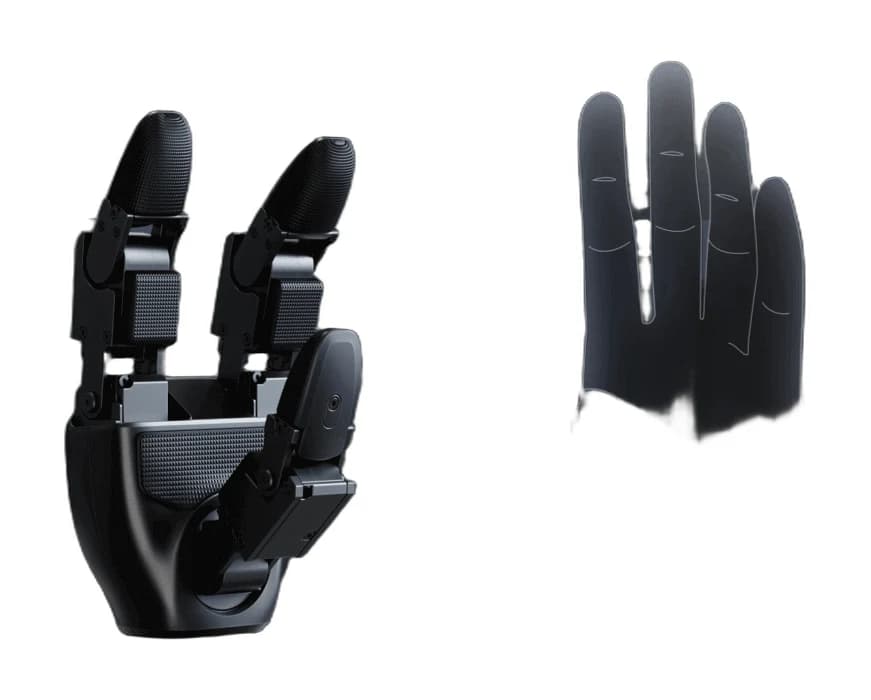
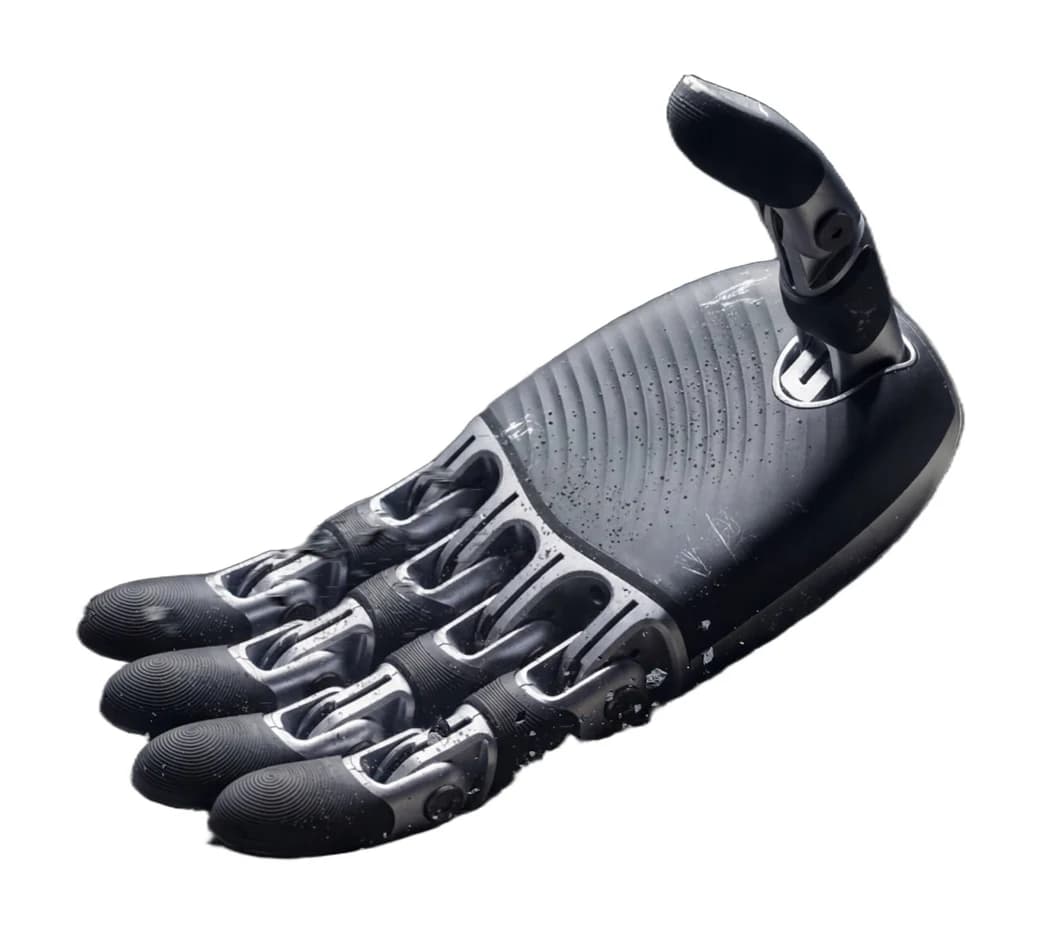
- (2) For tasks that need in-hand reorientation or tool use, five-finger hands are assessed.