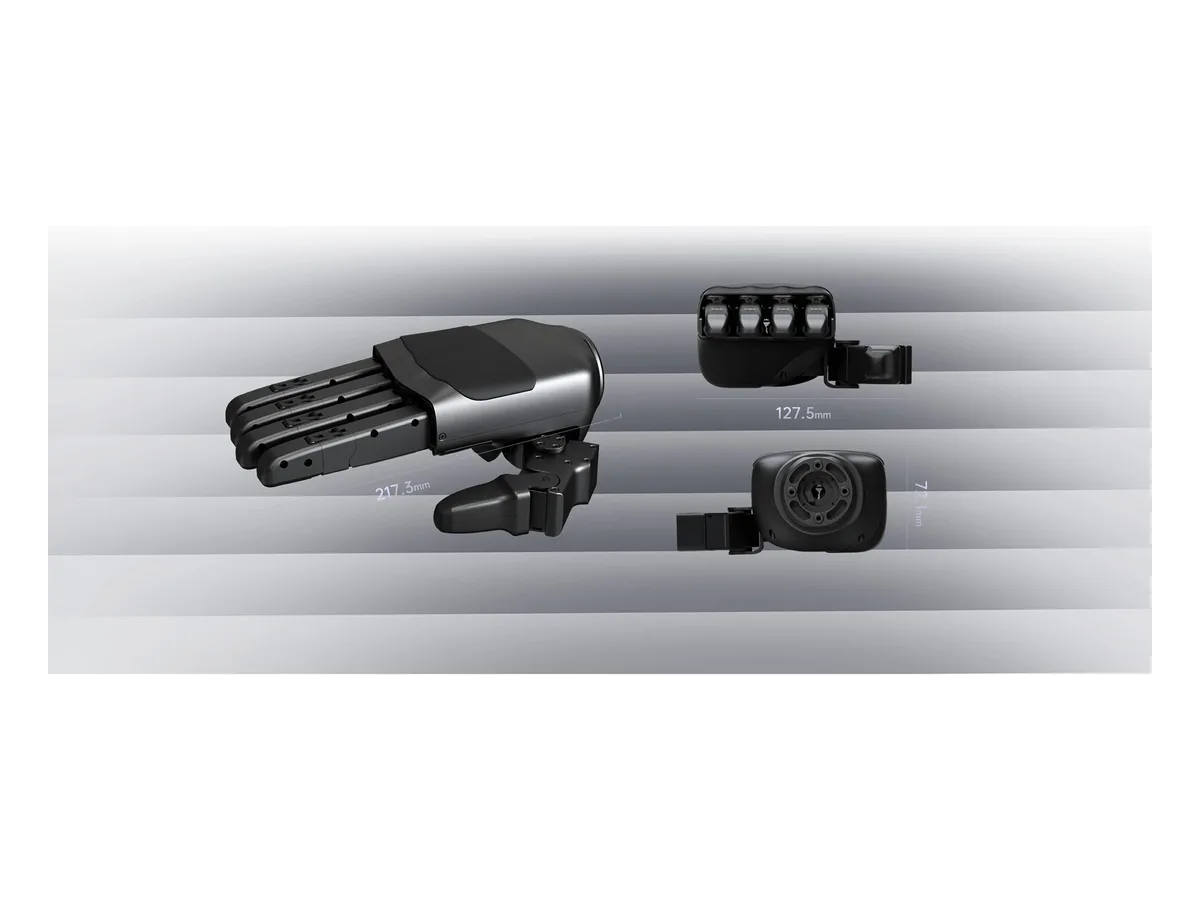
Skip to content
Robotlar

Unitree Dex3-1

Three-Finger Force-Controlled Robot Hand

Degrees of Freedom
7
Thumb 3, index 2, middle 2
Weight
710 g
175 x 88 x 77 mm flat
Tactile Sensors
33
Optional, 9 arrays
Repeatability
±2 mm
Fingertip

The Unitree Dex3-1 is a force-controlled robot hand with 7 degrees of freedom across three fingers (thumb 3, index 2, middle 2). Its 6 direct-drive and 1 geared micro brushless joints run with hybrid force and position control.

Read more

It offers a weight of 710 g, ±2 mm fingertip repeatability, a 500 g load and 1000 Hz communication over USB 2.0. It is used with the Unitree G1; the optional tactile array carries 33 sensors.

Unitree Turkey Distributor · on-site commissioning and support protocol (SLA)

Overview

The Unitree Dex3-1 is a three-finger, force-controlled robot hand used with the Unitree G1 humanoid. It carries 7 degrees of freedom: 3 joints in the thumb and 2 each in the index and middle fingers; its 6 direct-drive and 1 geared micro brushless joints run with hybrid force and position control. It weighs 710 g, has ±2 mm fingertip repeatability and a 500 g load.

The optional tactile array carries 33 sensors per hand. The Dex3-1 is the hand with the widest support in Unitree's software repositories: a unitree_sdk2 example, xr_teleoperate teleoperation, Isaac Lab tasks, a LeRobot configuration and a URDF model are published. As the official distributor of Unitree Robotics in Turkey, Robotlar.org handles Dex3-1 supply, with a G1 or on its own, through a corporate quotation.

Which Dex3-1 fits your needs?

The manufacturer's official variant matrix; the values are documented data.

FeatureDex3-1Dex3-1 Dokunsal
Degrees of freedom77
Weight710 g710 g
Tactile sensorsNone33 sensors, 9 arrays
Pressure range-10 g to 2,500 g
InterfaceUSB 2.0, 1000 HzUSB 2.0, 1000 Hz
QuoteGet a Quote for This ModelDex3-1Get a Quote for This ModelDex3-1 Dokunsal

Values from Unitree's Dex3-1 and G1 pages, 13 November 2026. The tactile array appears as an option on the G1 page and as a separate choice on the G1-D page. Left or right hand is set in the quotation.

Key Advantages

Three Fingers, Seven Joints

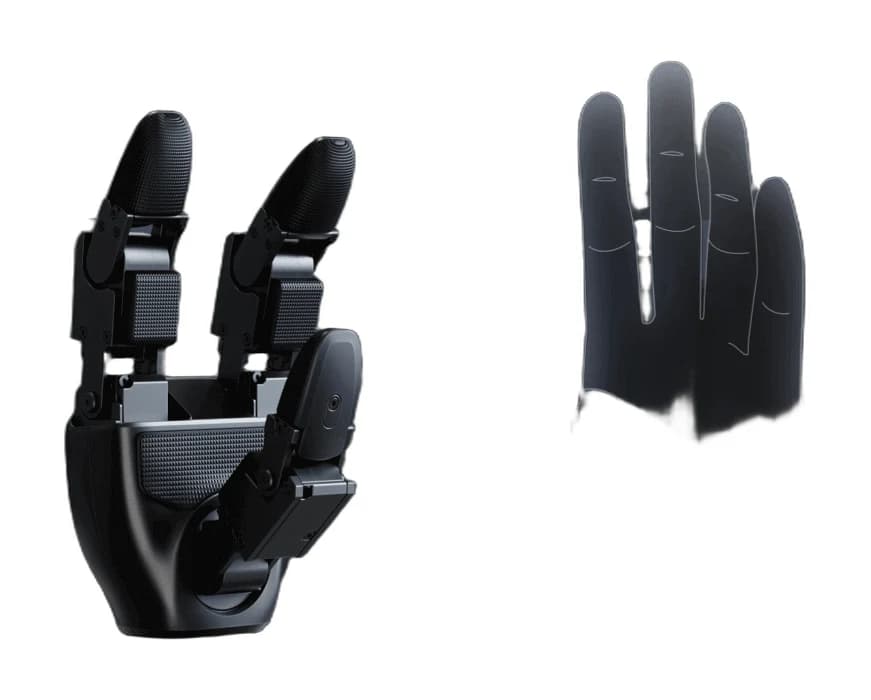
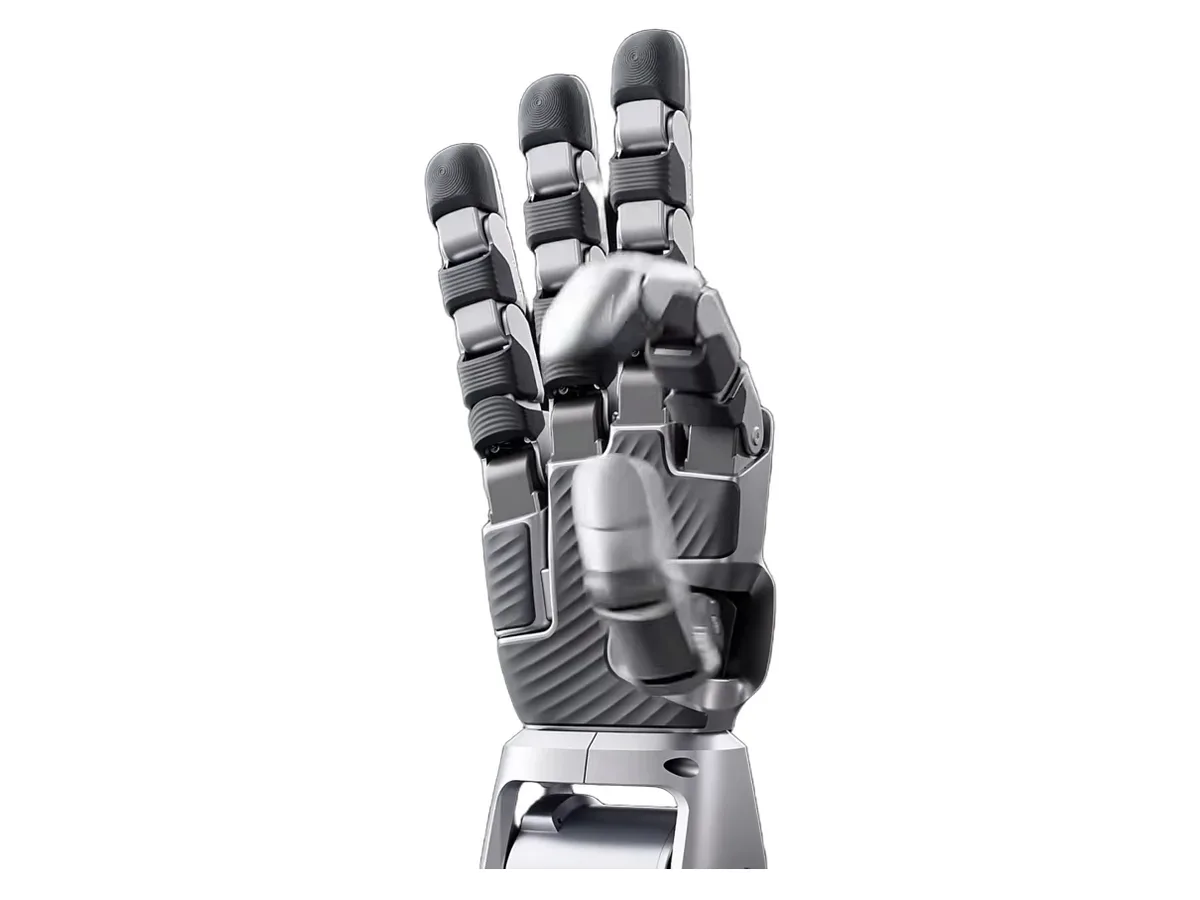
The Dex3-1 carries 7 degrees of freedom: 3 in the thumb and 2 each in the index and middle fingers.

  • (1) The thumb joints rotate from -60° to 60°, -35° to 60° and 0° to 100°.
  • (2) The index and middle finger joints range from 0° to 90° and 0° to 100°.
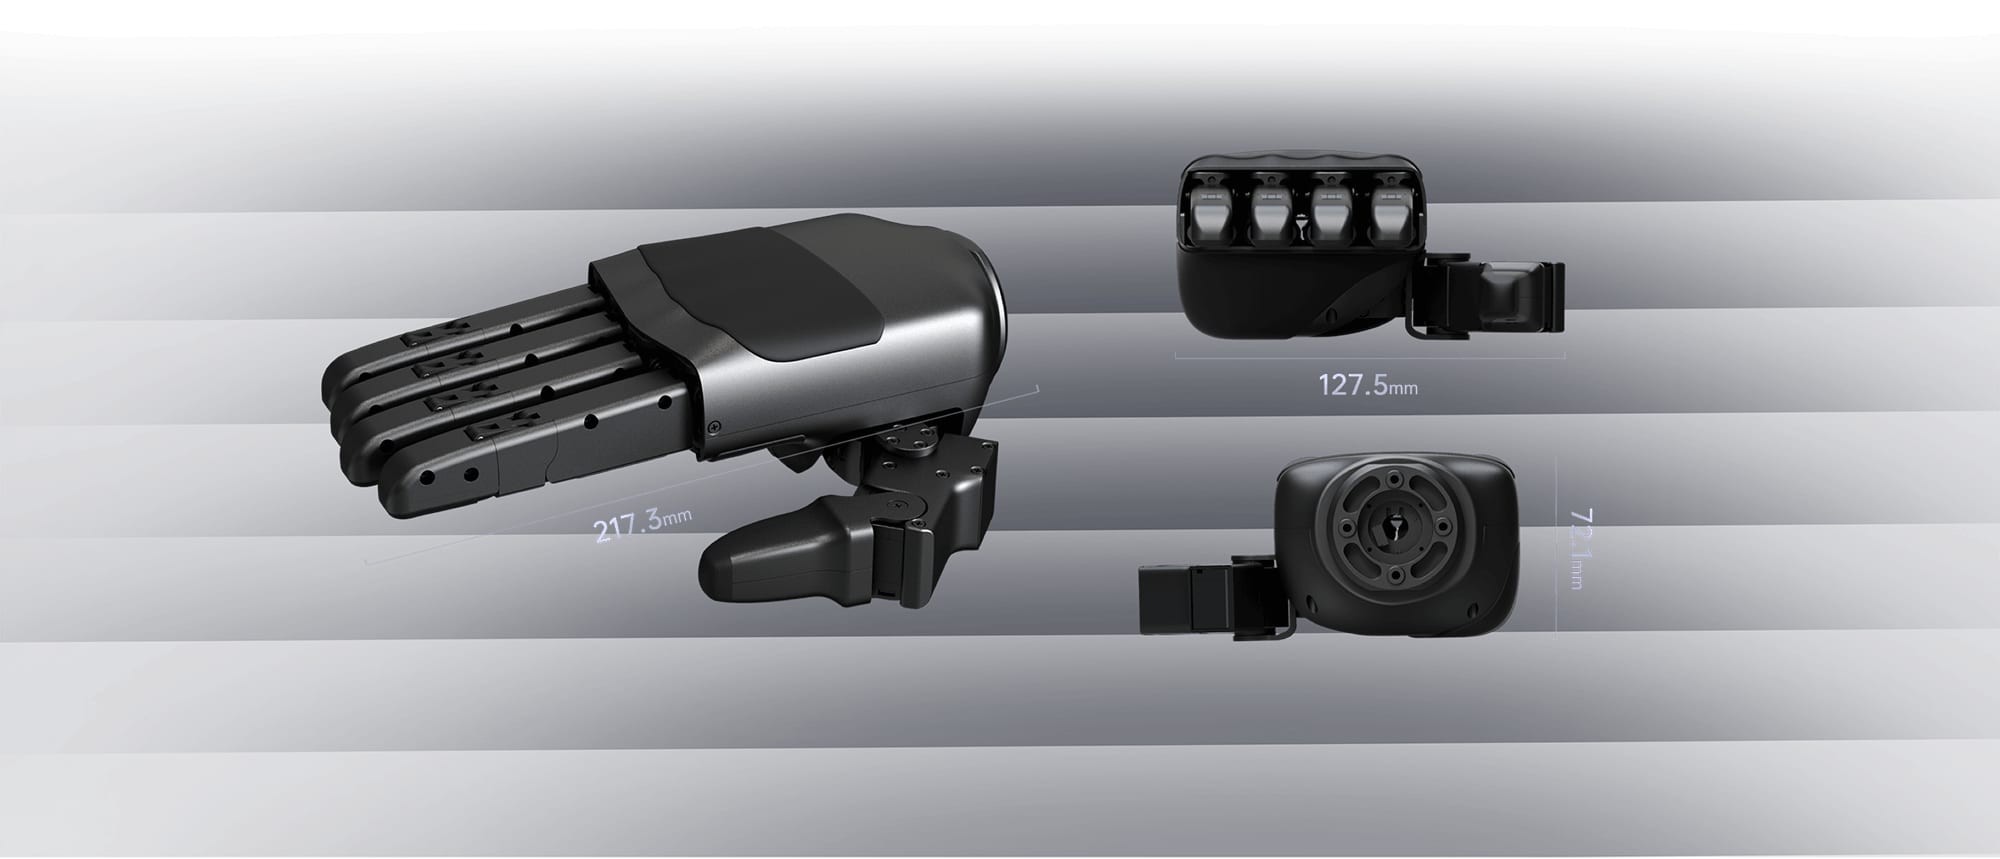
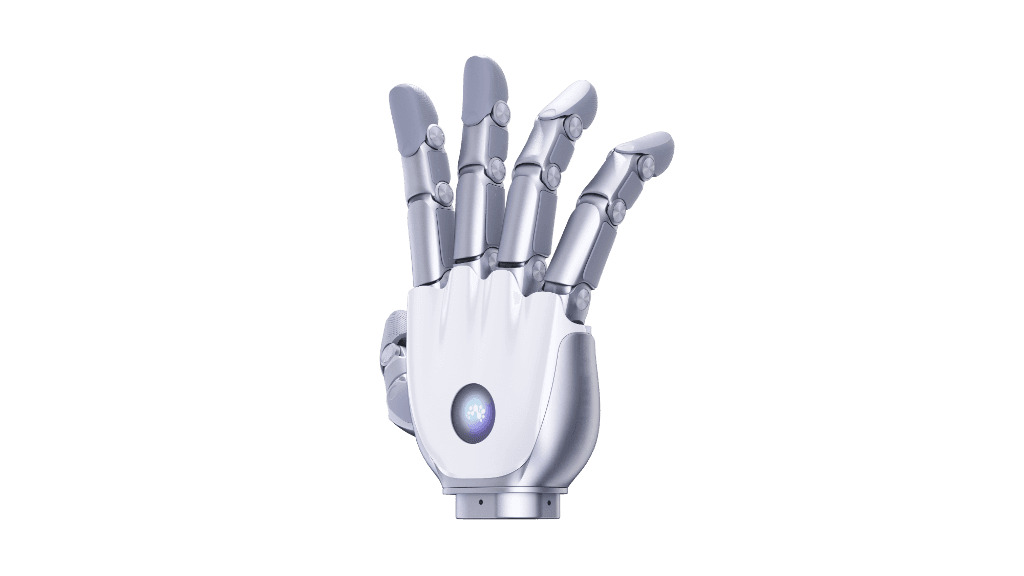
  • (3) In the flat position the hand measures 175 x 88 x 77 mm and weighs 710 g. The dimensions in the image come from the manufacturer's product page.
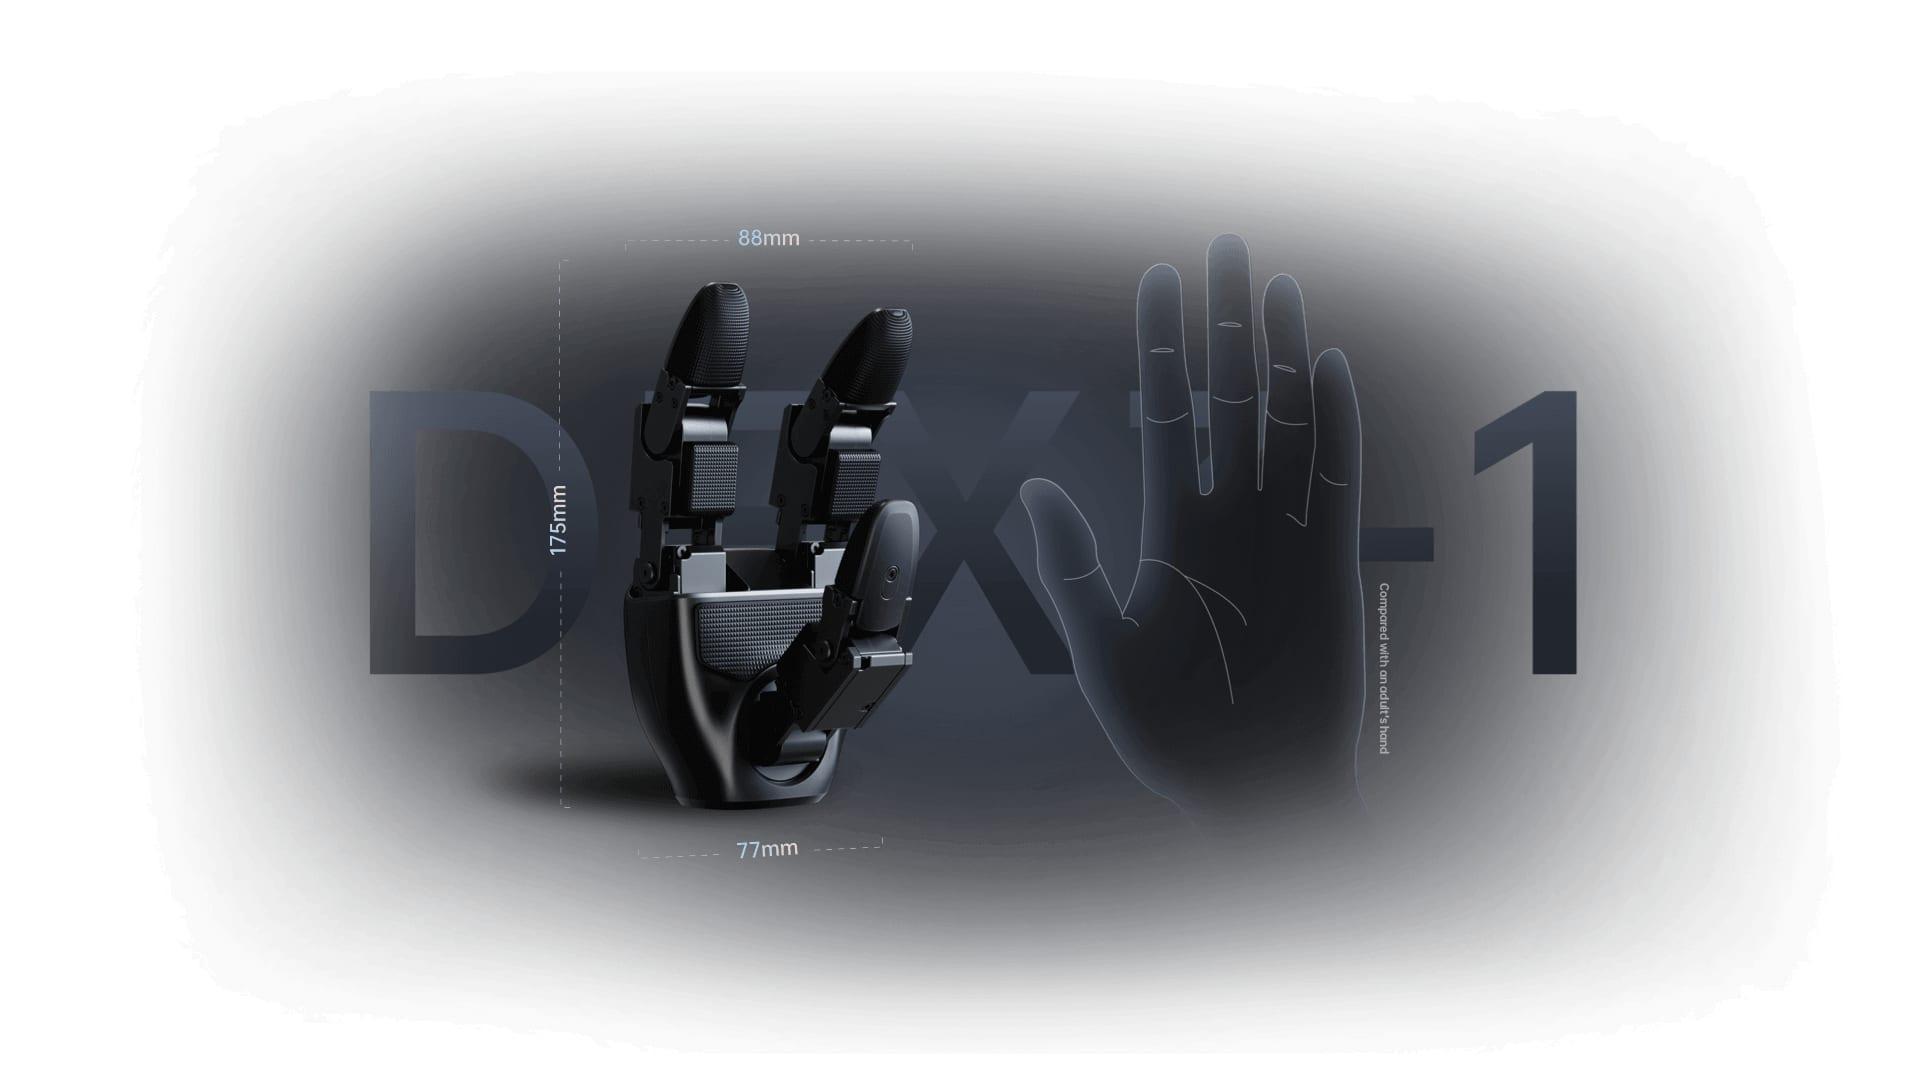
Unitree Dex3-1, Three Fingers, Seven Joints

Hybrid Force and Position Control

The hand has 6 direct-drive and 1 geared micro brushless joint, all force-controlled.

  • (1) With hybrid force and position control the hand tracks position in free motion and force in contact.
  • (2) The manufacturer publishes ±2 mm fingertip position repeatability.
  • (3) The load is 500 g (palm down and up); peak power is 400 W for 3 seconds.

Joint Motors: The F-1515 Series

The manufacturer publishes two micro joint motors: the F-1515-108 (0.76 N·m ideal, 23 rad/s, 45 g) and the F-1515-214 (1.498 N·m ideal, 11 rad/s).

  • Both measure 34.8 x 23.1 x 23.3 mm, run 1000 Hz control, have absolute encoders and take a 12 to 24 V supply.

Optional Tactile Array: 33 Sensors

The G1 page states that a tactile sensor array can optionally be installed on the Dex3-1.

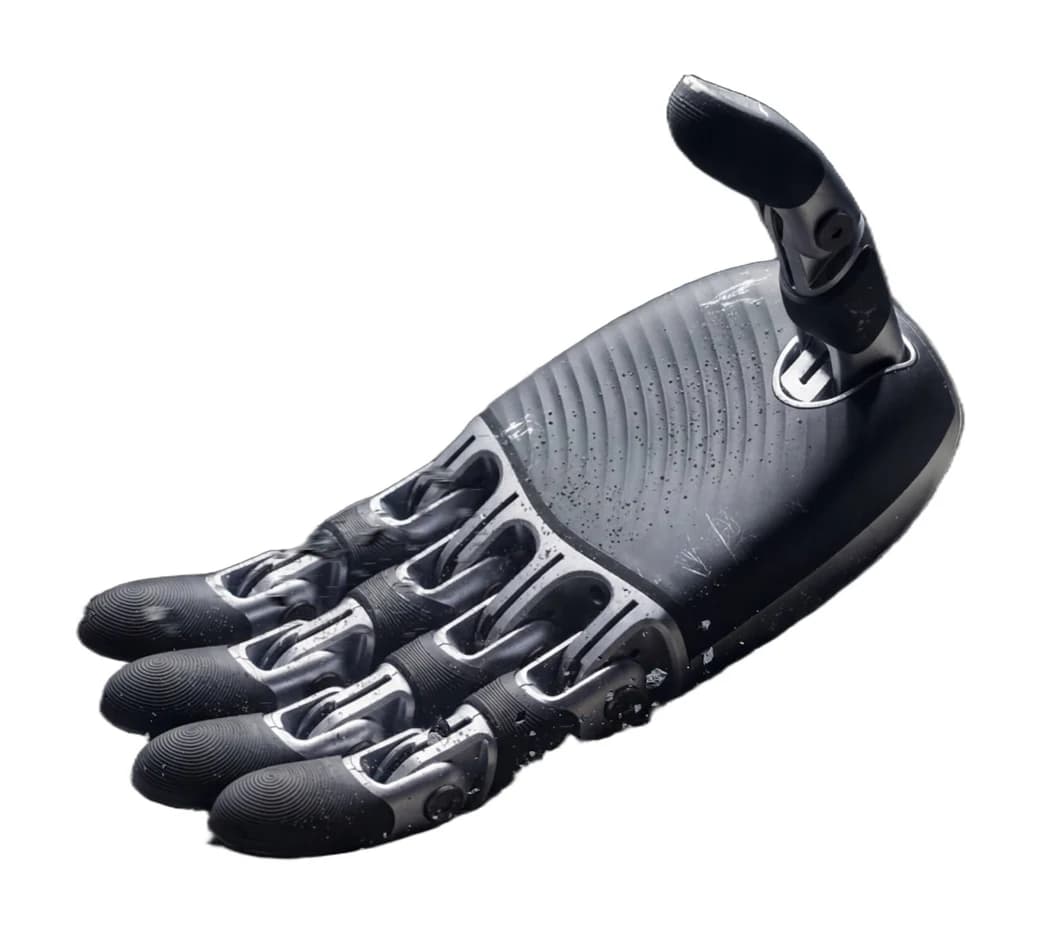
  • (1) There are 33 sensors in total in 9 arrays per hand: three 2x2 arrays in the palm, three 2x2 on the pads and three 3x1 at the fingertips.
  • (2) The range is 10 g to 2,500 g and the damage threshold 20 kg.
  • (3) The G1-D page lists the hand as two options, without and with tactile sensing.

A Ready Software Path on the G1

The Dex3-1 is the hand module with the widest support in Unitree's software repositories.

  • (1) unitree_sdk2 contains a G1 Dex3 example and the hand messages (HandCmd_, HandState_).
  • (2) The xr_teleoperate tool runs XR teleoperation with the --ee dex3 option.
  • (3) unitree_sim_isaaclab contains Dex3 tasks and unitree_lerobot a Dex3 configuration; the unitree_ros repository has the URDF model.

Which Robots Use It?

Unitree states that the Dex3-1 can be used with the G1 and publishes an official removal and installation guide for the G1 Flagship A and B versions.

  • The G1-D page lists the 3-finger hand with no-tactile and tactile options.
  • The H2 and R1 robot pages also list a 3-finger hand option; the Dex3-1 product page does not name these two robots itself.

Unitree Dex3-1: What It Carries, and Where

7 degrees of freedom

Thumb 3, index 2, middle finger 2 joints.

Force and position

Hybrid control; force in contact, position in free motion.

Unitree Dex3-1 technical hardware diagram

6 + 1 joint motors

6 direct-drive and 1 geared micro brushless joint.

Optional tactile array

33 sensors in 9 arrays; 10 g to 2,500 g.

Which robot for which job?

The Unitree Dex3-1 is a candidate for all of these jobs; in each scenario our catalogue also holds other bodies that can do the same work. The right robot follows from the job itself and the delivery timeline.

Manipulation and teleoperation with the G1

The lab runs XR teleoperation on the G1 with the Dex3-1, records demonstration data with the unitree_lerobot configuration and trains the policy with Isaac Lab tasks. Because this path is ready in Unitree's repositories, setup time shortens.

Technical Specifications

20 values in 7 categories; data published by the manufacturer.

General structure
Degrees of freedom
7 (thumb 3, index 2, middle 2)
End effector
Three-finger hand; left and right versions
Joint motor
F-1515-108 and F-1515-214; both 34.8 x 23.1 x 23.3 mm
Manufacturer note
Whether the tactile array is a separate product or an option is not clear on the manufacturer's page; the G1 page says it "can optionally be installed". Fingertip force and speed are not published.
Body dimensions
175 x 88 x 77 mm (flat position)
Integration
Unitree G1 (official: "can be used with G1"); official removal and installation guide for the G1 Flagship A and B versions; the G1-D page lists a "3-finger dexterous hand (no tactile / with tactile)"; the H2 and R1 pages list a 3-finger hand option
Size and weight
Weight
0.71 kg (710 g)
Motion and performance
Payload
0.5 kg (500 g, palm down and up)
Repeatability
±2 mm (fingertip)
Joint range of motion
Thumb: -60° to 60°, -35° to 60°, 0° to 100°. Index and middle: 0° to 90° and 0° to 100°
Power and runtime
Operating power
Peak 400 W (3 s)
Operating voltage
12 to 58 V; static 0.2 A (58 V), maximum 10 A
Sensors and connectivity
Sensors
Joint position and force feedback; optional 33-sensor tactile array
Interfaces
unitree_sdk2 (G1 Dex3 example, HandCmd_ and HandState_), xr_teleoperate (--ee dex3), unitree_sim_isaaclab and unitree_lerobot Dex3 configurations
Connectivity
USB 2.0; 1000 Hz communication
Tactile sensing
Optional tactile array: 33 sensors in total in 9 arrays per hand (palm 3 x 2x2, pad 3 x 2x2, fingertip 3 x 3x1); range 10 g to 2,500 g, damage threshold 20 kg
Joint encoder
Absolute encoder (in the joint motors)
Software and development
Operating system
Dex3-1 URDF model in the unitree_ros repository; Isaac Lab tasks (G1 29 DoF)
Software features
Hybrid force and position control; joint motors at 1000 Hz with absolute encoders, 12 to 24 V
Environmental resilience
Operating temperature
-20 to 60 °C

An itemised quote for the Unitree Dex3-1 is prepared by configuration, quantity and delivery scope.

Purchasing support

Get a quote for the Dex3-1

Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.

  • Supply and delivery scheduling backed directly by the manufacturer
  • Site- and mission-focused technical feasibility and simulation
  • Turnkey hardware, software and mission integration
  • Advisory on corporate tenders, specifications and administrative processes

Direct contact and advisory line: 0850 532 6 777

Add project details (optional)

Product of interest: Unitree Dex3-1

Dex3-1: Frequently Asked Questions

The most common questions about the Unitree Dex3-1.

What is the Unitree Dex3-1?

The Unitree Dex3-1 is a force-controlled robot hand with 7 degrees of freedom across three fingers: thumb 3, index 2, middle finger 2 joints. It runs hybrid force and position control with 6 direct-drive and 1 geared micro brushless joints.

Which robots is the Dex3-1 compatible with?

Unitree states that the Dex3-1 can be used with the G1, and there is an official removal and installation guide for the G1 Flagship A and B. The G1-D page lists the 3-finger hand with no-tactile and tactile options; the H2 and R1 pages also list a 3-finger hand option.

Does the Dex3-1 have tactile sensing?

Optionally, yes. The tactile array carries 33 sensors in total in 9 arrays per hand (palm, pads and fingertips); the range is 10 g to 2,500 g. The G1 page describes the array as optional.

How much does the Dex3-1 weigh and how much load can it carry?

It weighs 710 g (0.71 kg) and measures 175 x 88 x 77 mm in the flat position. The load is 500 g (palm down and up); peak power is 400 W for 3 seconds.

Which interface does it use?

USB 2.0 with 1000 Hz communication. Supply is 12 to 58 V; at 58 V the static current is 0.2 A, and the maximum current is 10 A.

Is there teleoperation and simulation support?

Yes. Unitree's xr_teleoperate tool supports the Dex3-1 with the --ee dex3 option; unitree_sdk2 has a G1 Dex3 example, unitree_sim_isaaclab has Dex3 tasks, unitree_lerobot has a Dex3 configuration and unitree_ros has the URDF model.

How do you choose between the Dex3-1 and the Dex5-1?

The Dex3-1 has three fingers, 7 DoF and weighs 710 g; the software path for the G1 is ready. The Dex5-1 has five fingers, 20 DoF (16 active) and weighs 1,100 g; its fingertip force is 10 N and its load reaches 4.5 kg. If the full range of human objects has to be grasped with five fingers, the Dex5-1 stands out; if a quick start on the G1 is needed, the Dex3-1 does.

How is the Unitree Dex3-1 sourced in Turkey and what does it cost?

Robotlar.org is the official distributor of Unitree Robotics in Turkey. List prices are not published for Unitree products; the price is set in a corporate quotation by left or right hand, the tactile array, quantity and whether it is bought together with a G1.

Official Guarantee

Official Distributor of Unitree Robotics in Turkey

Robotlar.org is the official distributor of Unitree Robotics in Turkey, the Turkey Distributor for Pudu Robotics, and authorized systems integrator (Service Hub), providing sales, on-site engineering across Turkey, spare parts, and SDK/API integration support.

Request Corporate QuoteUnitree Competence Center
Free Pre-Sales Engineering Consultation
Unitree Turkey Distributor

Hand comparison and SDK guide for the Dex3-1