Skip to content
Robotlar

BrainCo Revo 2

Lightweight Five-Finger Robot Hand (6 Active, 11 DoF)

Weight
383 g
Without wrist
Active Joints
6
11 DoF in total
Grip
≥ 50 N
Five fingers; pinch ≥ 15 N
Whole-Hand Load
≥ 20 kg
Manufacturer documentation
Repeatability
0.1°
At joint level
Flexion Time
≤ 0.65 s
Flexion and extension

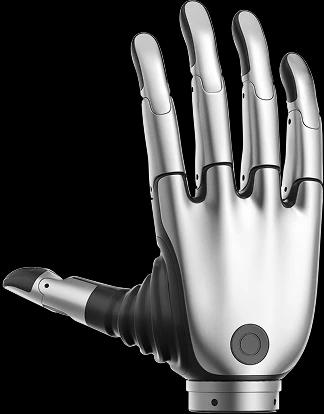
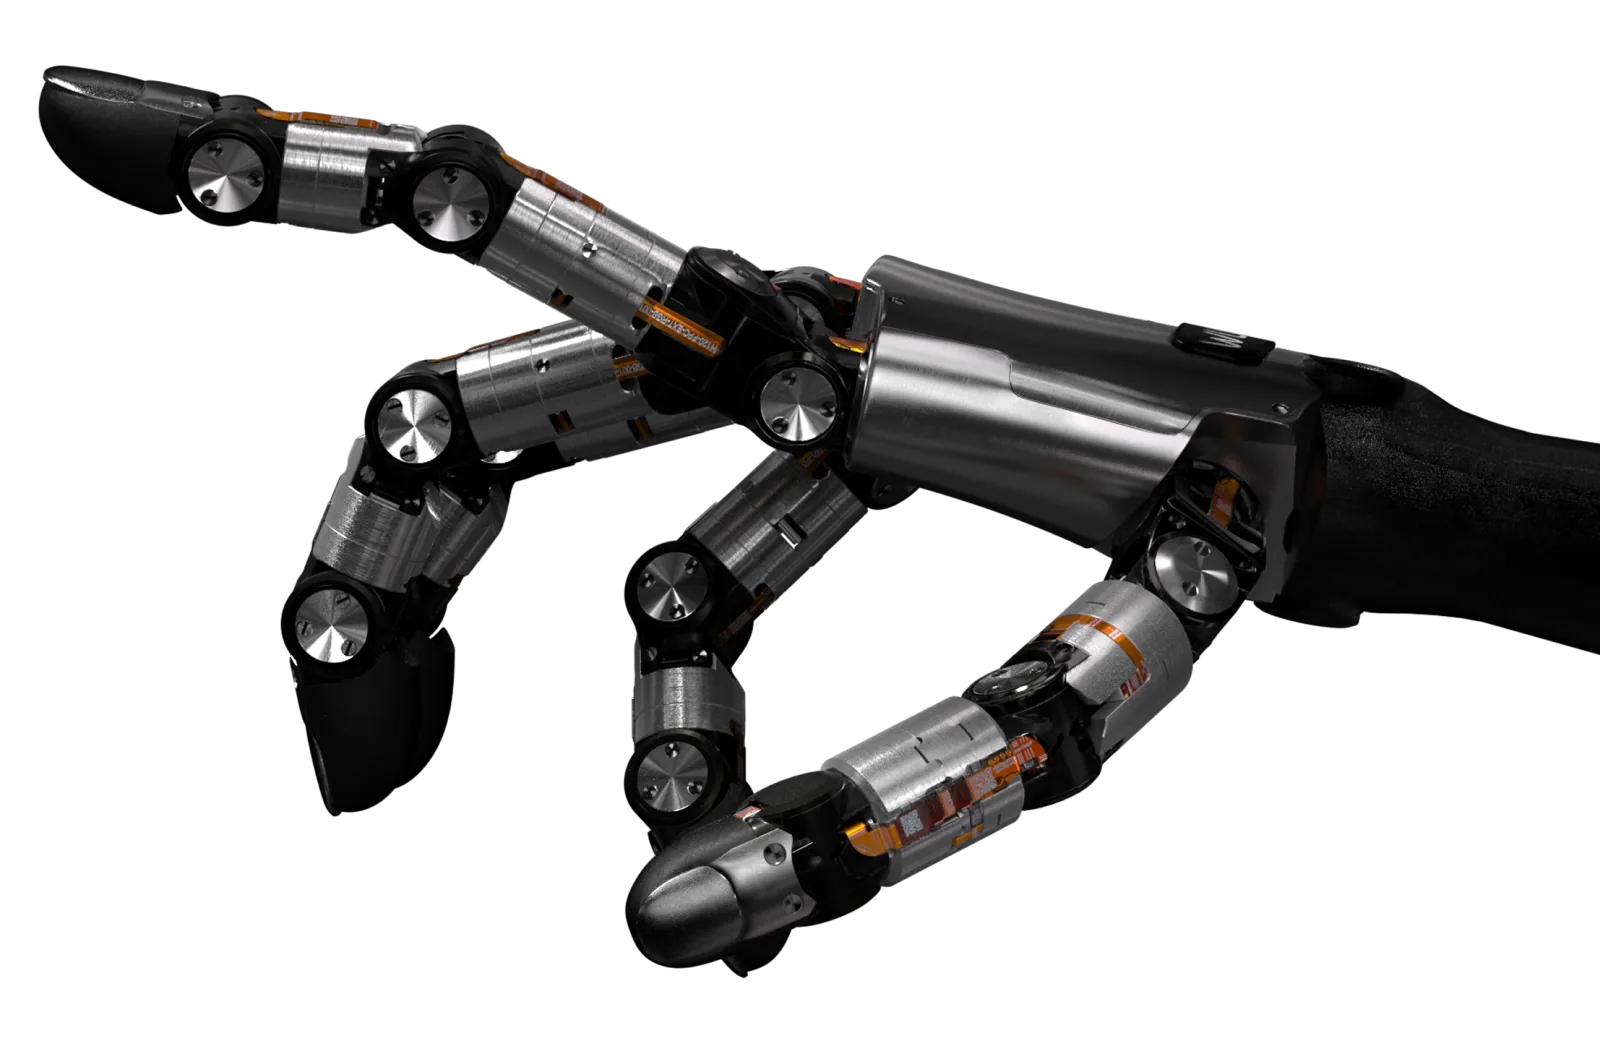
The BrainCo Revo 2 is a lightweight five-finger robot hand from BrainCo (Chinese 强脑科技). 6 of its 11 degrees of freedom are active: 2 active and 1 passive joint in the thumb, 1 active and 1 passive in each other finger.

Read more

It offers a weight of 383 g without the wrist, a five-finger grip of 50 N or more, a whole-hand load of 20 kg or more and 0.1° repeatability. It comes in Basic, Pro and Touch versions; official integration paths are published for the Unitree G1 and the Booster T2.

Enterprise supply · specification support · integration engineering

Overview

The BrainCo Revo 2 is the lightweight five-finger robot hand in the RevoLimb family from BrainCo (Chinese 强脑科技). 6 of its 11 degrees of freedom are active; the thumb has 2 active and 1 passive joint, and each other finger 1 active and 1 passive. Weighing 383 g without the wrist, it offers a five-finger grip of 50 N or more, a whole-hand load of 20 kg or more and 0.1° repeatability.

The Basic version uses RS485 or CAN FD, while the Pro and Touch versions add EtherCAT; Touch adds 3D force and proximity sensing per finger. Unitree G1 integration for the Revo 2 is published in both BrainCo and Unitree repositories, and the hand is among the Booster T2's factory end effector options. BrainCo sells the hand on request only. Robotlar.org offers the Revo 2 to research labs and humanoid or robot arm integrators in Turkey through enterprise sourcing, technical specification support and integration engineering.

2 use cases

Which Revo 2 fits your needs?

The manufacturer's official variant matrix; the values are documented data.

FeatureRevo 2 BasicRevo 2 ProRevo 2 Touch
Part code (left / right)XRL / XRRXEL / XERXTL / XTR
CommunicationRS485 or CAN FD (DIP)RS485, CAN FD, EtherCATRS485, CAN FD, EtherCAT
Supply (documentation)12 to 28 V12 to 64 V12 to 64 V
Tactile sensingNoneNone3D force and proximity per finger
Weight and DoF383 g, 11 (6 active)383 g, 11 (6 active)383 g, 11 (6 active)
QuoteGet a Quote for This ModelRevo 2 BasicGet a Quote for This ModelRevo 2 ProGet a Quote for This ModelRevo 2 Touch

Values from the BrainCo RevoLimb documentation, 13 November 2026. The website gives the voltage as 9 to 28 V and 9 to 64 V; some pages call the Pro version Advanced. Version, hand side and quantity are set in the quotation.

Revo 2 Basic

Grasping and teleoperation projects on RS485 or CAN FD that do not need tactile data.

Revo 2 Pro

Robot arms with an EtherCAT line and platforms that need the wider voltage range.

Revo 2 Touch

Work that needs a tactile compliant grasp with contact force and proximity data.

Use Cases

The use cases the manufacturer defines for the BrainCo Revo 2.

  1. Education and research
  2. Factory and production

Key Advantages

Five Fingers on Six Motors

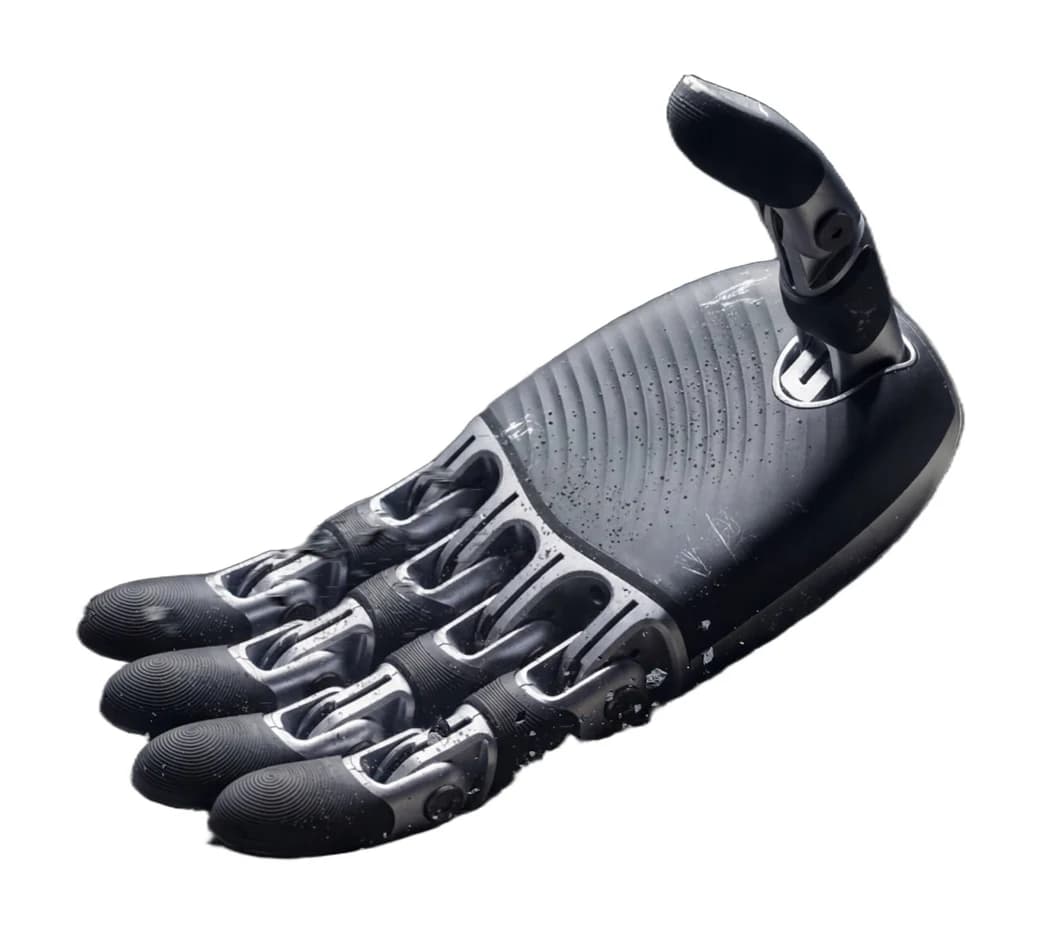
6 of the Revo 2's 11 degrees of freedom are active.

  • (1) The thumb has 2 active and 1 passive joint; it both flexes and opposes.
  • (2) Each of the other four fingers has 1 active and 1 passive joint; the passive joint follows the active one.
  • (3) The manufacturer describes the design as bionic and does not publish linkage or tendon details.
BrainCo Revo 2, Five Fingers on Six Motors

383 g, Close to a Human Hand

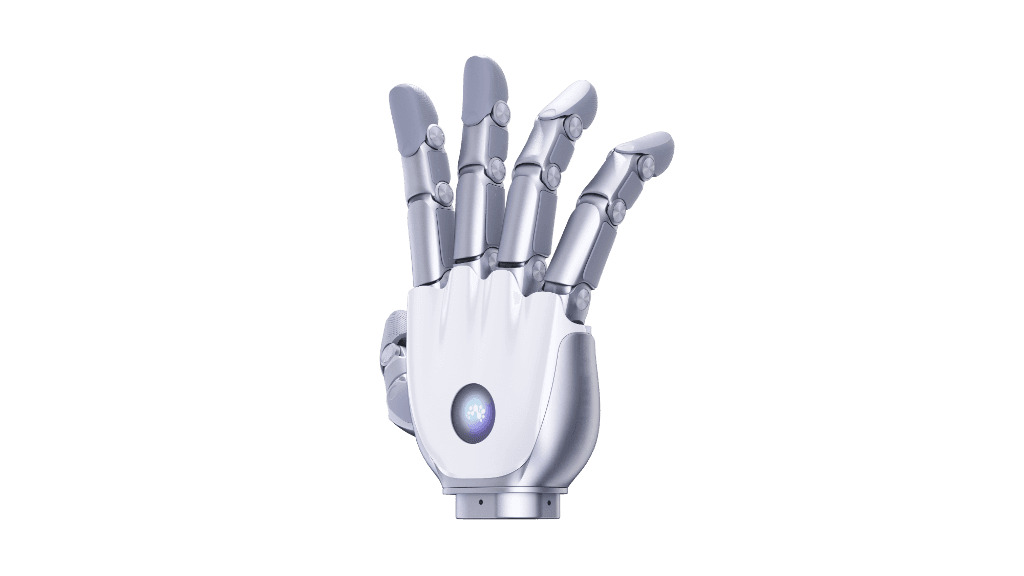
The weight without the wrist is 383 g, and the height from palm base to middle fingertip is 160 mm.

  • (1) The opening between thumb and index finger is 100 mm.
  • (2) The light body leaves margin within the payload limit of humanoid wrists and small robot arms.
  • The image comes from the manufacturer's website.
BrainCo Revo 2, 383 g, Close to a Human Hand

Grip and Speed

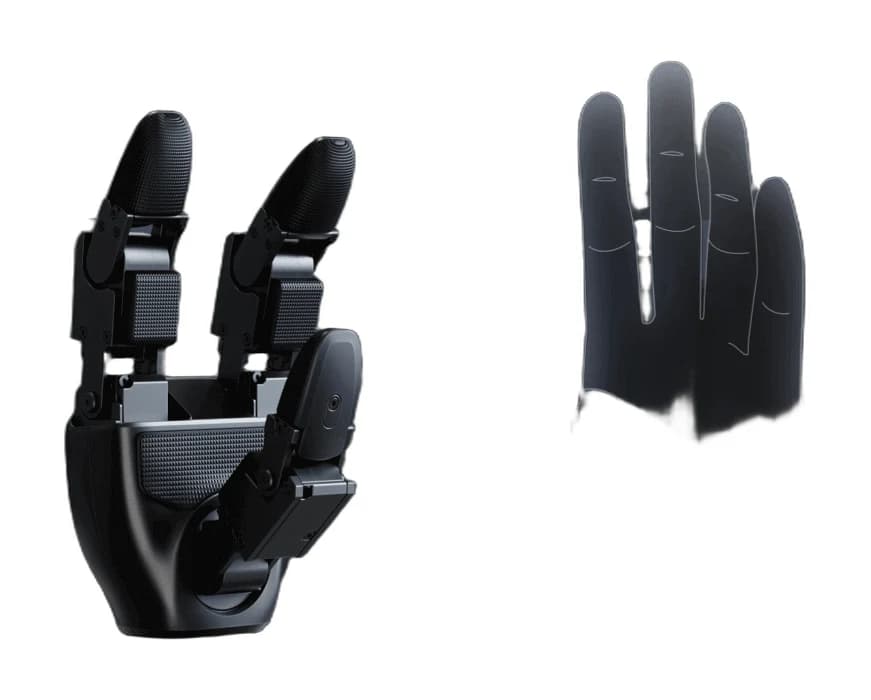
The manufacturer's documentation gives a five-finger grip of 50 N or more, a pinch force of 15 N or more and a whole-hand load of 20 kg or more.

  • (1) Finger flexion and extension take 0.65 seconds or less.
  • (2) Joint repeatability is 0.1°, and noise at 50 cm is 50 dB or less.
  • In the image two Revo 2 hands hold a thin pen (manufacturer image).
BrainCo Revo 2, Grip and Speed

Basic, Pro and Touch

The Revo 2 comes in three versions, as left and right hands.

  • (1) Basic: RS485 or CAN FD (selected by DIP switch), 12 to 28 V.
  • (2) Pro: RS485, CAN FD and EtherCAT, 12 to 64 V.
  • (3) Touch: the Pro interfaces plus 3D force and proximity sensing per finger, with a tactile compliant grasp mode. The tactile point count of the Touch version is not published.

Control Modes and Protections

The hand supports position, speed, current, graded and compliant control modes.

  • (1) It has current, stall, over-temperature and collision protection.
  • (2) Firmware is updated over the air.
  • (3) The operating environment is -10 to 40 °C and 90% relative humidity; colour options are Space Gray, Silver and Dawn Gold.

Revo 2 on the Unitree G1

The Revo 2 is supported for the Unitree G1 from both sides.

  • (1) BrainCo's unitree-g1-brainco-hand repository (v2.0.0) describes integration on the G1's 23 and 29-DoF versions with dual RS-485 and ROS 2.
  • (2) Unitree's own brainco_hand_service repository says "the G1 can be equipped with BrainCoTech's Revo2 Dexterous Hand" and converts serial communication to DDS.
  • (3) Unitree's xr_teleoperate tool uses the hand in teleoperation with the --ee brainco option. Whether the hand is sold pre-integrated with the G1 is not stated.

A Booster T2 Factory Option

Booster's T2 documentation lists the Revo 2 among the T2's end effector options; optional end effectors are installed, wired, configured and tested at the factory.

  • Booster's booster_assets repository includes the T2_31dof_Revo2Hand model (11 moving joints per hand).

SDK, ROS 2 and Simulation

BrainCo publishes its software in the BrainCoTech organisation on GitHub.

  • (1) brainco-hand-sdk: C and Python under MIT, with tactile grasp, EtherCAT and DFU examples.
  • (2) brainco_hand_ros2: ROS 2 Humble, ros2_control, Gazebo and MoveIt; Modbus, CAN FD and EtherCAT; an RM65 arm example.
  • (3) revo2_description and brainco-description: URDF plus MJCF and USD generation.

BrainCo Revo 2: What It Carries, and Where

6 active joints

2 active and 1 passive in the thumb, 1 active and 1 passive in each other finger.

383 g

Weight without wrist; height 160 mm.

100 mm opening

Between thumb and index finger.

BrainCo Revo 2 technical hardware diagram

≥ 50 N grip

With five fingers; pinch 15 N or more, whole-hand load 20 kg or more.

Three communication lines

RS485, CAN FD; EtherCAT on Pro and Touch.

Touch version

3D force and proximity sensing per finger.

The BrainCo Revo 2 up close

3 images; tap to enlarge.

Five Fingers on Six Motors
Grip and Speed
383 g, Close to a Human Hand

Which robot for which job?

The BrainCo Revo 2 is a candidate for all of these jobs; in each scenario our catalogue also holds other bodies that can do the same work. The right robot follows from the job itself and the delivery timeline.

BrainCo Revo 2 use case: A five-finger hand for the Unitree G1

A five-finger hand for the Unitree G1

A lab running a G1 wants a five-finger hand instead of a three-finger one. For the Revo 2 both BrainCo's G1 integration repository and Unitree's brainco_hand_service repository are published; teleoperation runs through Unitree's xr_teleoperate tool. Mechanical mounting and wiring are verified within the project.

A dexterous hand with the Booster T2

An organisation buying a T2 wants the end effector installed and tested at the factory. Booster's documentation lists the Revo 2 among the T2 options, and the T2_31dof_Revo2Hand model is ready for simulation. The hand choice is written into the T2 quotation's configuration.

Technical Specifications

20 values in 7 categories; data published by the manufacturer.

General structure
Degrees of freedom
11 (6 active): thumb 2 active and 1 passive, the other four fingers 1 active and 1 passive
End effector
Five-finger hand; 100 mm opening between thumb and index finger
Joint motor
6 motors; bionic design (linkage or tendon details not published)
Manufacturer note
The voltage range differs between sources: the documentation gives Basic 12 to 28 V and Pro and Touch 12 to 64 V, while the website gives 9 to 28 V and 9 to 64 V. Version names also vary (basic, advanced and tactile in the Chinese documentation; Basic, Pro and Touch in English; Advanced on some pages). The release date is not published.
Body dimensions
Height 160 mm (palm base to middle fingertip)
Precision
0.1° repeatability; noise 50 dB or less at 50 cm; flexion and extension in 0.65 s or less
Colourways
Space Gray, Silver, Dawn Gold
Integration
Unitree G1 (BrainCo documentation and unitree-g1-brainco-hand v2.0.0: G1 23 and 29 DoF, dual RS-485, ROS 2; Unitree's brainco_hand_service repository and xr_teleoperate --ee brainco). Booster T2: a factory-installed end effector option; T2_31dof_Revo2Hand model in the booster_assets repository
Availability
BrainCo sells the Revo 2 on request only; there is no official store or price list
Size and weight
Weight
0.383 kg (383 g, without wrist)
Motion and performance
Payload
Whole-hand load 20 kg or more
Repeatability
0.1°
Power and runtime
Operating voltage
Basic 12 to 28 V; Pro and Touch 12 to 64 V (documentation). Maximum current at 24 V 4.6 A (Basic), 4.65 A
Sensors and connectivity
Sensors
Current, stall, over-temperature and collision protection; 3D force and proximity per finger on the Touch version
Interfaces
brainco-hand-sdk (C and Python, MIT; EtherCAT and DFU examples), brainco_hand_ros2 (ROS 2 Humble, Apache-2.0)
Connectivity
Basic: RS485 or CAN FD (by DIP switch). Pro and Touch: RS485, CAN FD, EtherCAT. Website: communication up to 1 kHz
Tactile sensing
Touch version only: 3D force, proximity and state logging per finger; point count not published
Software and development
Operating system
URDF, MJCF and USD models in the revo2_description and brainco-description repositories; Gazebo and MoveIt
Software features
Control modes: position, speed, current, graded and compliant control; tactile compliant grasp on the Touch version; OTA firmware updates
Environmental resilience
Operating temperature
-10 to 40 °C, 90% relative humidity

An itemised quote for the BrainCo Revo 2 is prepared by configuration, quantity and delivery scope.

Purchasing support

Get a quote for the Revo 2

Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.

  • Supply and delivery scheduling backed directly by the manufacturer
  • Site- and mission-focused technical feasibility and simulation
  • Turnkey hardware, software and mission integration
  • Advisory on corporate tenders, specifications and administrative processes

Direct contact and advisory line: 0850 532 6 777

Add project details (optional)

Product of interest: BrainCo Revo 2

Revo 2: Frequently Asked Questions

The most common questions about the BrainCo Revo 2.

What is the BrainCo Revo 2?

The BrainCo Revo 2 is a lightweight five-finger robot hand from BrainCo (Chinese 强脑科技). 6 of its 11 degrees of freedom are active, and it weighs 383 g without the wrist. It comes in Basic, Pro and Touch versions.

Can the Revo 2 be mounted on a Unitree G1?

Yes, there are two official sources. BrainCo's unitree-g1-brainco-hand repository describes integration on the G1's 23 and 29-DoF versions with dual RS-485 and ROS 2, and Unitree's brainco_hand_service repository states that the G1 can be equipped with the Revo 2. Whether the hand is sold pre-integrated with the G1 is not stated; mounting and wiring are verified within the project.

What is the difference between Basic, Pro and Touch?

Basic uses RS485 or CAN FD (by DIP switch) and runs on 12 to 28 V. Pro offers RS485, CAN FD and EtherCAT and runs on 12 to 64 V. Touch adds 3D force and proximity sensing per finger to the Pro.

How much force does the Revo 2 apply and how much load can it carry?

The manufacturer's documentation gives a five-finger grip of 50 N or more, a pinch force of 15 N or more and a whole-hand load of 20 kg or more. Finger flexion and extension take 0.65 seconds or less.

Is the Revo 2 used with the Booster T2?

Yes. Booster's T2 documentation lists the Revo 2 among the factory-installed end effector options, and the booster_assets repository includes the T2_31dof_Revo2Hand model.

Which SDK and ROS 2 packages are available?

brainco-hand-sdk is in C and Python under MIT; brainco_hand_ros2 offers ROS 2 Humble, ros2_control, Gazebo and MoveIt support (Apache-2.0). The revo2_description and brainco-description repositories contain URDF, MJCF and USD models.

How many tactile points does the Touch version have?

Not published. The manufacturer states that the Touch version has 3D force, proximity and state logging per finger; the point count and measuring range are requested from the manufacturer in writing at the quotation stage.

How does Robotlar.org source the Revo 2?

For BrainCo products Robotlar.org provides enterprise sourcing, technical specification support and integration engineering. Supply into Turkey is planned per project; the scope of import, delivery and commissioning is itemised in the quotation. BrainCo sells the hand on request only; prices are not published and are requested through the quote form.

How are lead time and warranty set?

Lead time is stated in the quotation after confirmation from the manufacturer, based on quantity, version, hand side and import terms. Warranty scope and duration are stated in writing in the quotation according to the sourcing channel.

Similar robots from the same brand