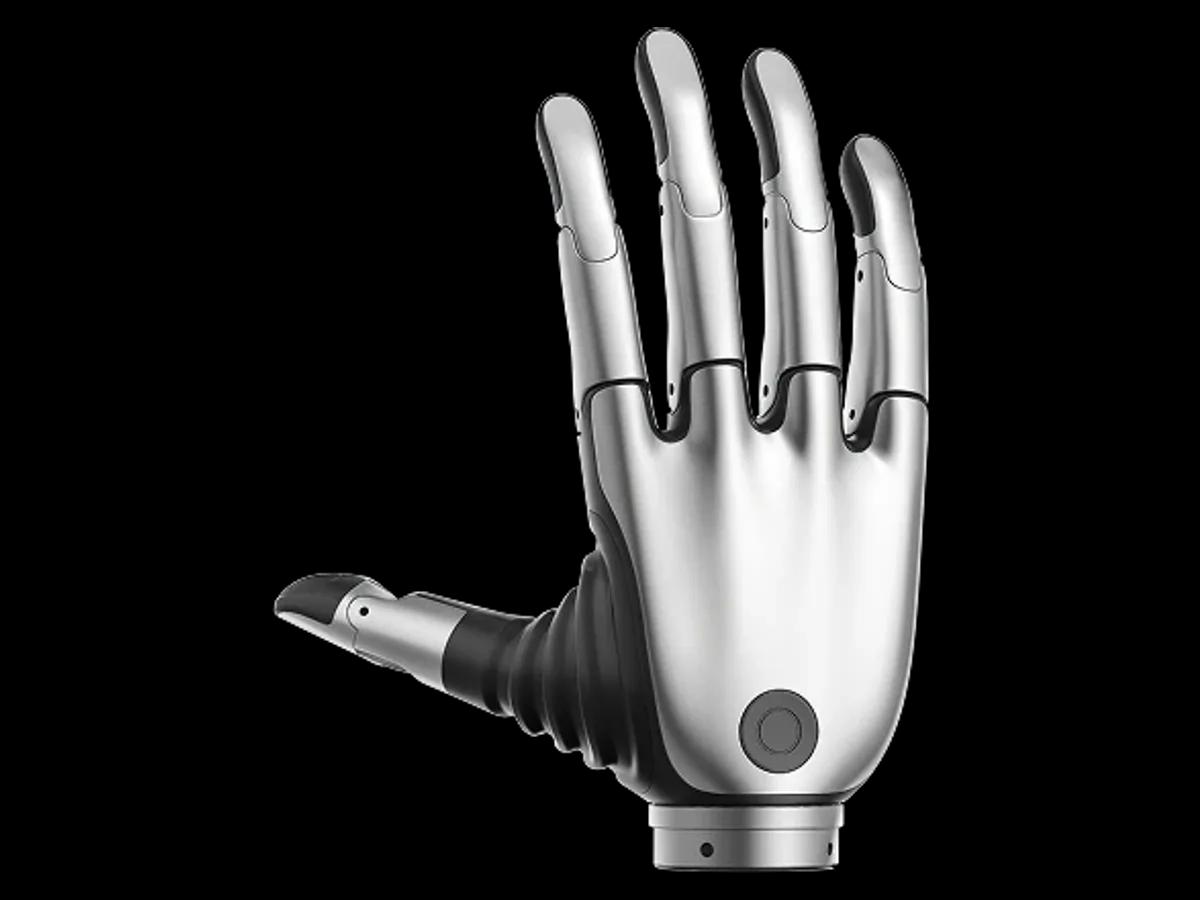
The BrainCo Revo 3 is BrainCo's five-finger dexterous hand with 21 active degrees of freedom, direct drive and back-drivable joints: 5 joints in the thumb and 4 in each of the four fingers.
Read moreShow less
It offers a grip of 100 N or more, a fingertip pinch of 25 N or more, a 20 kg whole-hand load, 0.33 s joint open and close and a 1,000,000-cycle core joint life. Its four versions range from non-tactile to visuo-tactile. The weight is not published by the manufacturer.
Enterprise supply · specification support · integration engineering
1/4
Overview
The BrainCo Revo 3 is the high-end dexterous hand in the RevoLimb family from BrainCo (Chinese 强脑科技). All 21 degrees of freedom are active (thumb 5, four fingers 4 each), and the joints are direct drive and back-drivable. The manufacturer publishes a grip of 100 N or more, a fingertip pinch of 25 N or more, a 20 kg whole-hand load, 0.33 s joint open and close and a 1,000,000-cycle core joint life.
The weight is not published.
Four versions add tactile sensing step by step: the U21 without tactile sensing, the U21F with fingertip force, the U21T with 451 piezoresistive points and the U21VT with a visuo-tactile palm. The hand is controlled at 500 Hz over EtherCAT, CAN FD and RS-485; the SDK, ROS 2 driver and Isaac Sim, Isaac Lab and MuJoCo repositories are published openly. It is among the Booster T2's factory end effector options. BrainCo sells the hand on request only. Robotlar.org offers the Revo 3 to research labs and humanoid integrators in Turkey through enterprise sourcing, technical specification support and integration engineering.
Values from the BrainCo RevoLimb documentation, 13 November 2026. The tactile range row is given in the documentation without a per-version split. The weight is not published. Version, hand side and quantity are set in the quotation.
Revo 3 U21
Grasping, teleoperation and reinforcement learning that run on joint and camera data.
Revo 3 U21F
Work that needs pinch, slip and push-direction tracking through fingertip force.
Revo 3 U21T
Grasping and object recognition research that needs a contact map across the hand.
Revo 3 U21VT
Projects that want high-resolution visuo-tactile contact data in the palm.
Use Cases
The use cases the manufacturer defines for the BrainCo Revo 3.
01Education and research
02Factory and production
Key Advantages
21 Active Joints, Direct Drive
All 21 degrees of freedom of the Revo 3 are active: 5 joints in the thumb and 4 in each of the four fingers.
(1) The joints are direct drive and back-drivable; an external force can turn them.
(2) Control modes are position, MIT force-position, current, admittance and impedance.
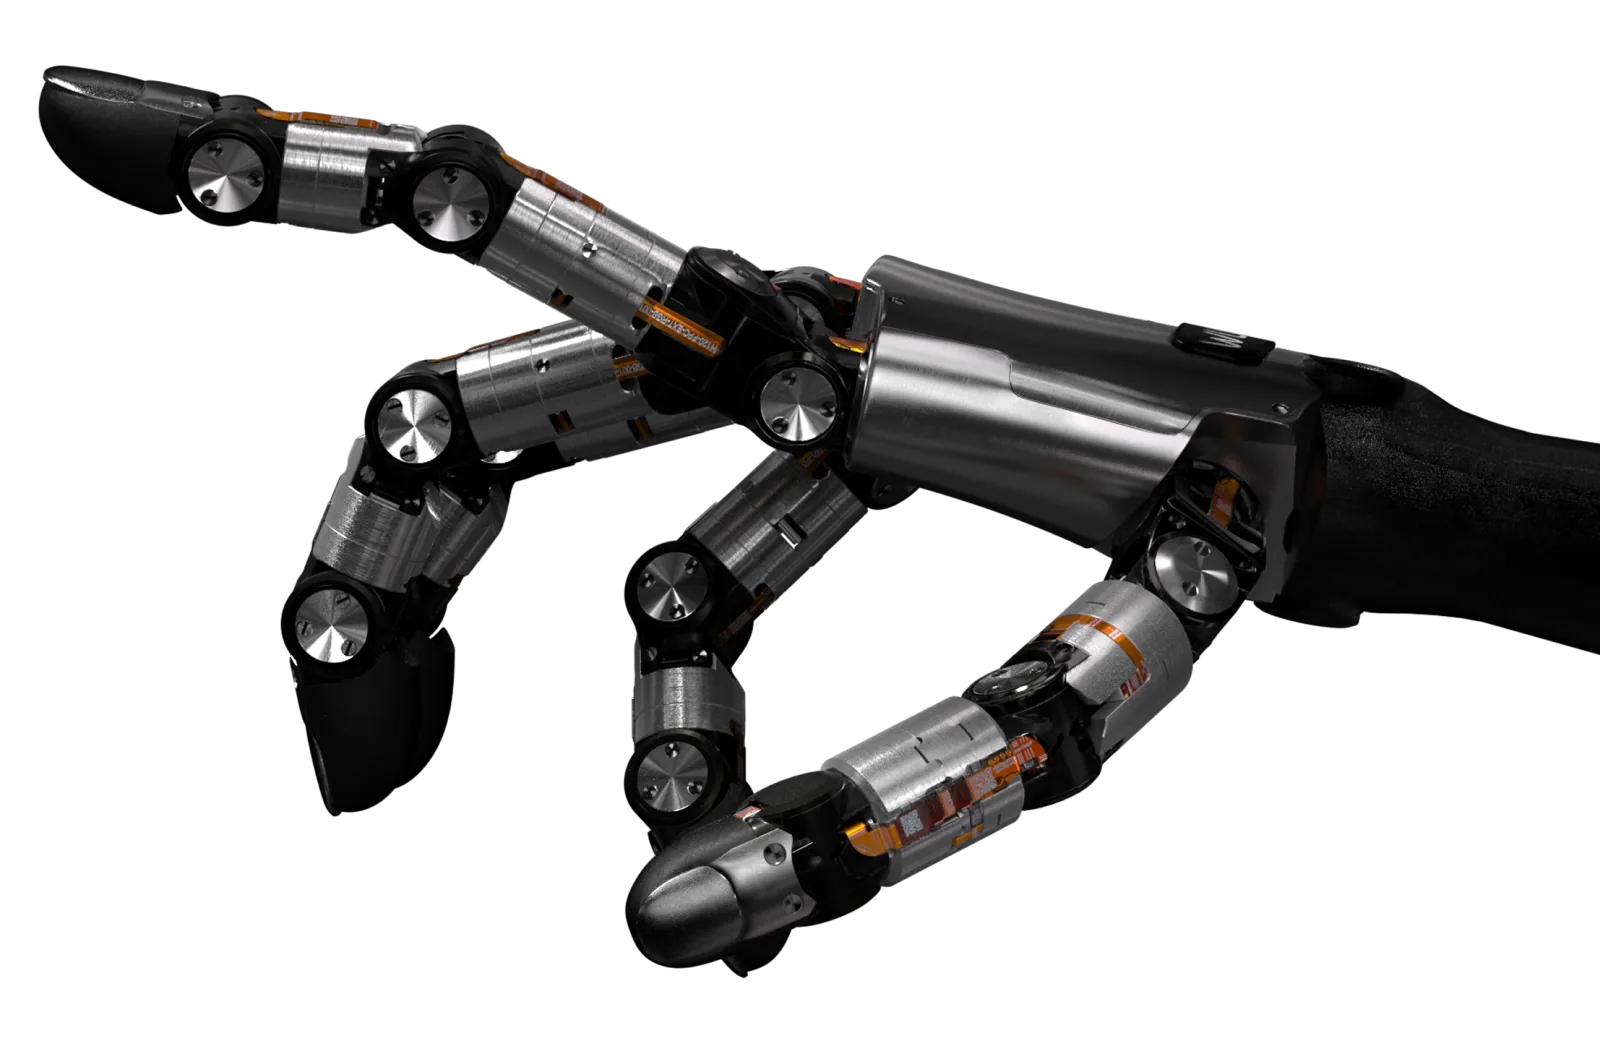
(3) The image comes from the manufacturer's website: the hand shows finger motions on a stand.
100 N Grip, 20 kg Load
The manufacturer gives a maximum active grip of 100 N or more and a fingertip pinch force of 25 N or more.
(1) The whole-hand load is 20 kg and the four-finger load 5 kg.
(2) Joint open and close takes 0.33 seconds; the grasp diameter is 10 to 150 mm.
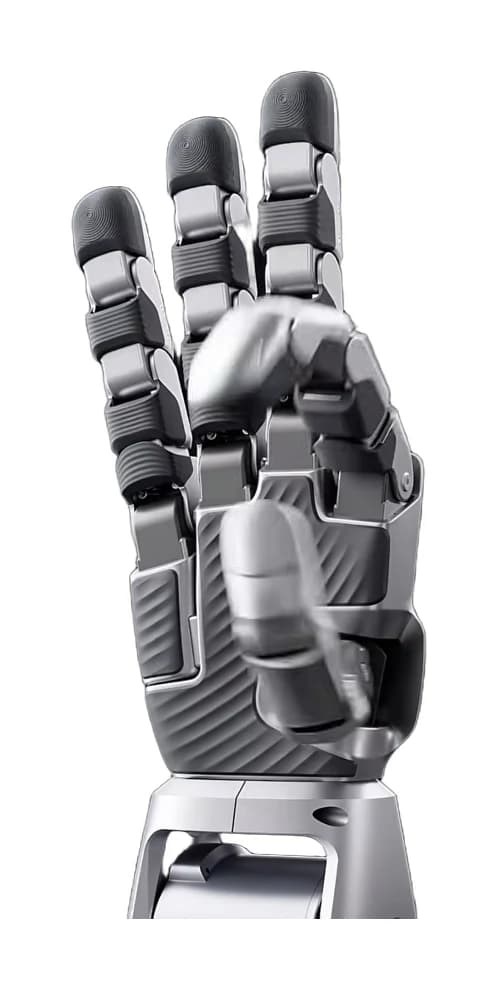
(3) In the image the hand shows different grasps for a cylinder, a ball, a small sphere and a thin rod (manufacturer image).
U21T: 451 Tactile Points Across the Hand
The U21T version carries 451 piezoresistive sensing points spread across the whole hand.
(1) The tactile range is 0 to 20 N, the resolution 0.01 N and the sampling rate 100 Hz.
(2) In the image the area touched on the hand appears as a coloured pressure map in the software (manufacturer image).
U21F: 3-Axis Force at the Fingertips
On the U21F version each of the five fingertips carries a 3-axis force module.
Because normal and tangential force at the fingertip are measured separately, slip tendency and push direction can be tracked.
The image comes from the manufacturer's website: an exploded view of the fingertip modules.
U21VT: A Visuo-Tactile Palm
The U21VT version combines 336 tactile points and 2,000 visuo-tactile markers in the palm.
This version targets research projects that want to see the shape and distribution of contact at high resolution.
Its mapping to the model files is not documented; confirmation is requested from the manufacturer at the quotation stage.
1,000,000-Cycle Joint Life
The manufacturer gives a core joint life of 1,000,000 cycles; joint repeatability is 0.1°.
In long data collection and reinforcement learning runs this is the key input to the maintenance plan.
EtherCAT, CAN FD, RS-485 and 500 Hz
The Revo 3 communicates over EtherCAT, CAN FD and RS-485 (Modbus RTU); the default RS-485 rate is 5 Mbps and the control rate 500 Hz.
(1) Supply is 16 to 85 V; the maximum current at 24 V is 10 A, and a supply of 24 V and over 100 W is recommended.
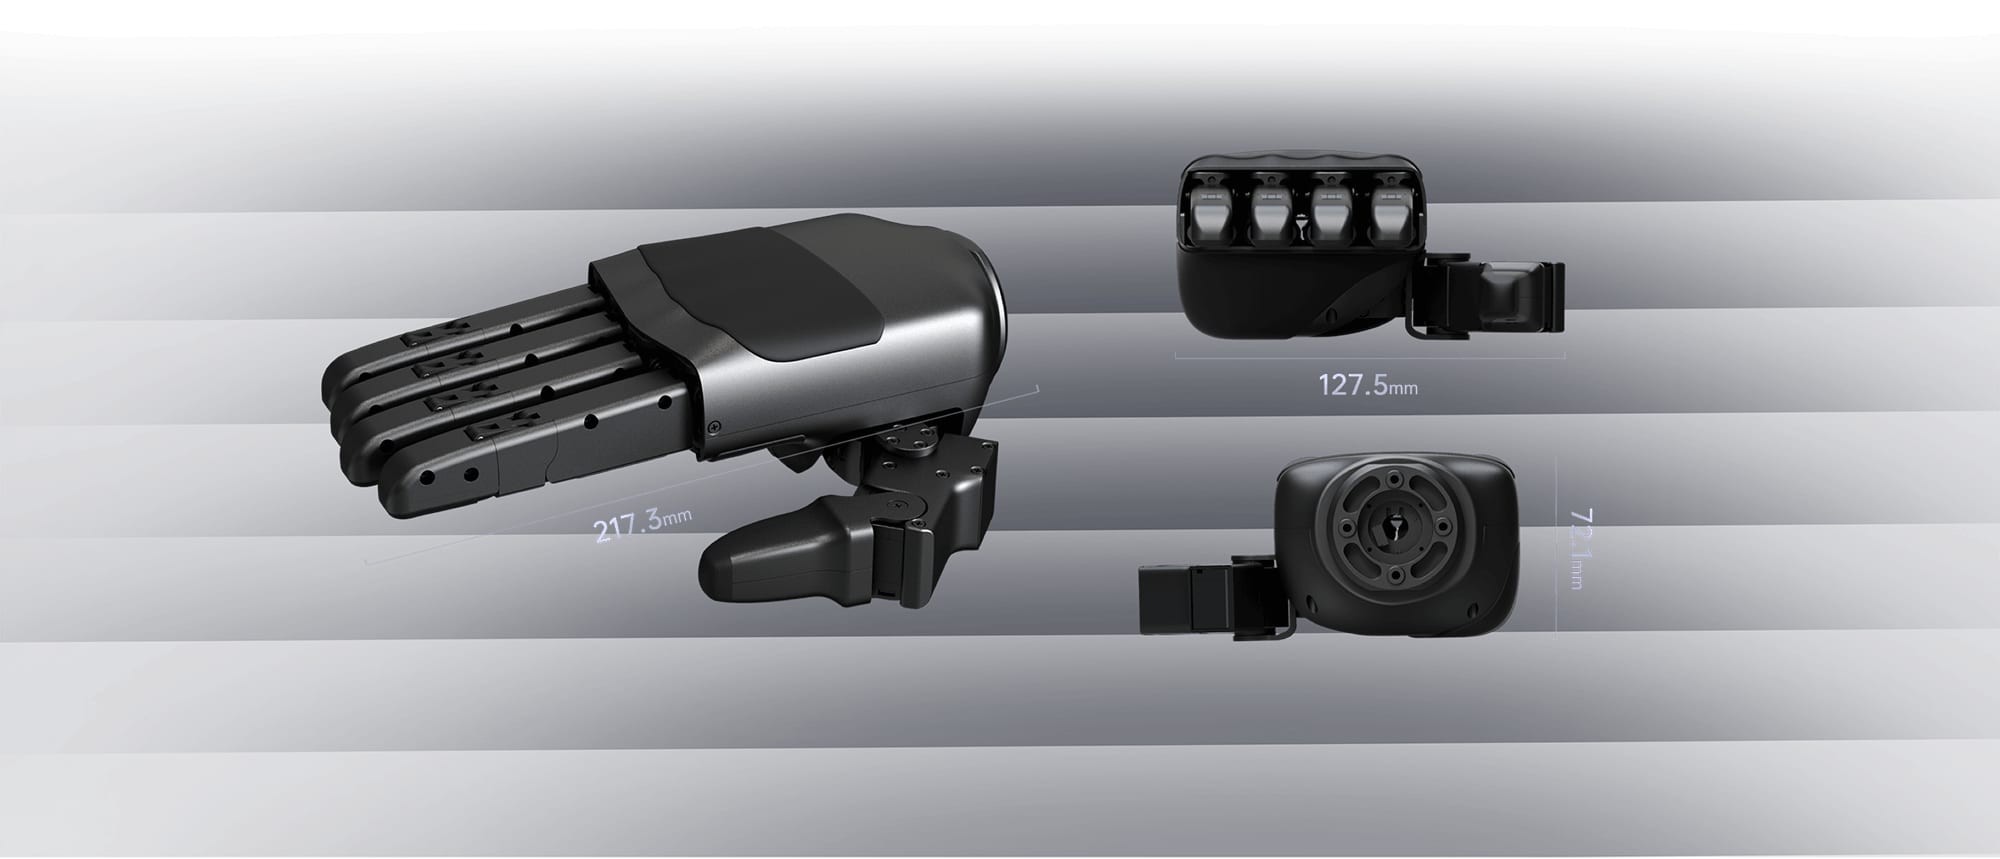
(2) The outer size is 216 x 108 x 50 mm.
The dimension drawing in the image comes from the manufacturer's documentation (labels in Chinese).
SDK, ROS 2 and Simulation
BrainCo publishes a broad open software set for the Revo 3.
(1) brainco-revo3-sdk v2.1.0: Python and C/C++ (September 2026).
(2) brainco_revo3_ros2: a ROS 2 driver that depends on SDK 1.0.4.
(3) RevoSim (Isaac Sim, MIT), RevoLab (Isaac Lab reinforcement learning), Revo-MjLab (MuJoCo), Revo-Retargeting and Revo3-Demos. The website also mentions ManiSkill, Genesis and Omniverse support; the verified repositories cover Isaac and MuJoCo.
BrainCo Revo 3: What It Carries, and Where
21 active joints
5 joints in the thumb, 4 in every finger; each with its own motor.
Direct drive
Back-drivable joints; force-position and impedance control.
216 x 108 x 50 mm
Grasp diameter 10 to 150 mm.
≥ 100 N grip
Fingertip pinch 25 N or more; whole-hand load 20 kg.
Three communication lines
EtherCAT, CAN FD, RS-485; 500 Hz control.
Four tactile options
U21, U21F, U21T and U21VT.
The BrainCo Revo 3 up close
3 images; tap to enlarge.
21 Active Joints, Direct Drive100 N Grip, 20 kg LoadU21T: 451 Tactile Points Across the Hand
Which robot for which job?
The BrainCo Revo 3 is a candidate for all of these jobs; in each scenario our catalogue also holds other bodies that can do the same work. The right robot follows from the job itself and the delivery timeline.
Tactile reinforcement learning
The team trains an in-hand reorientation policy in Isaac Lab with RevoLab, adds the U21T's 451-point tactile data to the observation and transfers the policy to the real hand with 500 Hz control. A 1,000,000-cycle core joint life eases the maintenance plan over long trial series.
An organisation buying a T2 wants a 21-active-joint hand installed and tested at the factory. Booster's documentation lists the Revo 3 among the T2 options; because there is no Revo 3 model file for the T2 in the booster_assets repository, the simulation setup uses BrainCo's own models.
The pilot tests a dexterous hand's capacity to hold tools and heavy parts with a 100 N grip and a 20 kg whole-hand load. Because the weight is not published, the arm payload calculation is made with a written value from the manufacturer.
18 values in 6 categories; data published by the manufacturer.
Size and weight
Weight
Not published by the manufacturer
Motion and performance
Payload
Whole-hand load 20 kg; four-finger load 5 kg
Repeatability
0.1°
Power and runtime
Operating voltage
16 to 85 V; maximum 10 A (24 V); a supply of 24 V and over 100 W is recommended
General structure
Degrees of freedom
21, all active (thumb 5, four fingers 4 each)
End effector
Five-finger hand; grasp diameter 10 to 150 mm
Joint motor
Direct-drive, back-drivable joints
Manufacturer note
The weight is not published in the manufacturer's documentation. Operating temperature and release date are not published. The ROS 2 driver depends on SDK 1.0.4 while the current SDK is 2.x; EtherCAT integration is done separately. How the U21F, U21T and U21VT versions map to the model files is not documented.
Body dimensions
216 x 108 x 50 mm
Lifecycle and testing
Core joint life 1,000,000 cycles
Integration
Booster T2: a factory-installed end effector option (Booster documentation). BrainCo also mentions use with its RevoArm and RevoTron arm and platform
Availability
BrainCo sells the Revo 3 on request only; there is no official store or price list
Size and weight
Weight
Not published by the manufacturer
Motion and performance
Payload
Whole-hand load 20 kg; four-finger load 5 kg
Repeatability
0.1°
Power and runtime
Operating voltage
16 to 85 V; maximum 10 A (24 V); a supply of 24 V and over 100 W is recommended
Sensors and connectivity
Sensors
By version: 3-axis fingertip force (U21F), 451-point piezoresistive skin (U21T), visuo-tactile palm (U21VT)
Interfaces
brainco-revo3-sdk v2.1.0 (Python and C/C++), brainco_revo3_ros2, Revo-Retargeting, Revo3-Demos
Connectivity
EtherCAT, CAN FD, RS-485 (Modbus RTU); RS-485 default 5 Mbps
Tactile sensing
U21: none. U21F: 3-axis force modules at 5 fingertips. U21T: 451 piezoresistive points across the hand. U21VT: 336 points plus 2,000 visuo-tactile markers in the palm. Range 0 to 20 N, resolution 0.01 N, 100 Hz
Lead time is stated in the quotation after confirmation from the manufacturer, based on quantity, version, hand side and import terms. Warranty scope and duration are stated in writing in the quotation according to the sourcing channel.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
Supply and delivery scheduling backed directly by the manufacturer
Site- and mission-focused technical feasibility and simulation
Turnkey hardware, software and mission integration
Advisory on corporate tenders, specifications and administrative processes
The most common questions about the BrainCo Revo 3.
What is the BrainCo Revo 3?
The BrainCo Revo 3 is a five-finger dexterous hand with 21 active degrees of freedom from BrainCo (Chinese 强脑科技). Its joints are direct drive and back-drivable; there are 5 joints in the thumb and 4 in each of the four fingers.
How much does the Revo 3 weigh?
BrainCo does not publish the Revo 3's weight in its documentation. A value found in a third-party source is not verified, so it is not on this page. Projects that need an arm payload calculation request the weight from the manufacturer in writing.
What is the difference between the U21, U21F, U21T and U21VT?
The U21 is the non-tactile version. The U21F carries 3-axis force modules at the five fingertips. The U21T carries 451 piezoresistive points across the hand. The U21VT combines 336 points and 2,000 visuo-tactile markers in the palm. The tactile range is 0 to 20 N, the resolution 0.01 N and the sampling rate 100 Hz.
How much force does the Revo 3 apply and how much load can it carry?
The maximum active grip is 100 N or more, and the fingertip pinch force 25 N or more. The whole-hand load is 20 kg and the four-finger load 5 kg. The grasp diameter is 10 to 150 mm.
Which interface does it use?
EtherCAT, CAN FD and RS-485 (Modbus RTU); RS-485 defaults to 5 Mbps. The control rate is 500 Hz. Supply is 16 to 85 V; the maximum current at 24 V is 10 A.
Which robots is the Revo 3 used with?
Booster's T2 documentation lists the Revo 3 among the factory-installed end effector options. BrainCo also mentions its own RevoArm and RevoTron arm and platform. No BrainCo source was found for the Unitree H1 or H2; on other platforms fit is verified through engineering within the project.
Which SDK and simulation tools are available?
brainco-revo3-sdk v2.1.0 offers Python and C/C++; brainco_revo3_ros2 is the ROS 2 driver (depending on SDK 1.0.4). RevoSim is for Isaac Sim, RevoLab for Isaac Lab reinforcement learning and Revo-MjLab for MuJoCo; Revo-Retargeting and Revo3-Demos are published as well.
What is the difference between the Revo 3 and the Revo 2?
On the Revo 3 all 21 joints are active and direct drive; the grip is 100 N or more, control runs at 500 Hz and there are four tactile versions. On the Revo 2, 6 of 11 DoF are active, it weighs 383 g and grips with 50 N or more; tactile sensing is on the Touch version only.
How does Robotlar.org source the Revo 3?
For BrainCo products Robotlar.org provides enterprise sourcing, technical specification support and integration engineering. Supply into Turkey is planned per project; the scope of import, delivery and commissioning is itemised in the quotation. BrainCo sells the hand on request only; prices are not published and are requested through the quote form.
How are lead time and warranty set?
Lead time is stated in the quotation after confirmation from the manufacturer, based on quantity, version, hand side and import terms. Warranty scope and duration are stated in writing in the quotation according to the sourcing channel.