Concept scenario
Autonomous Oil Leak and Thermal Anomaly Detection in High Voltage Transformers
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Outdoor field
- Operating mode
- Supervised autonomy
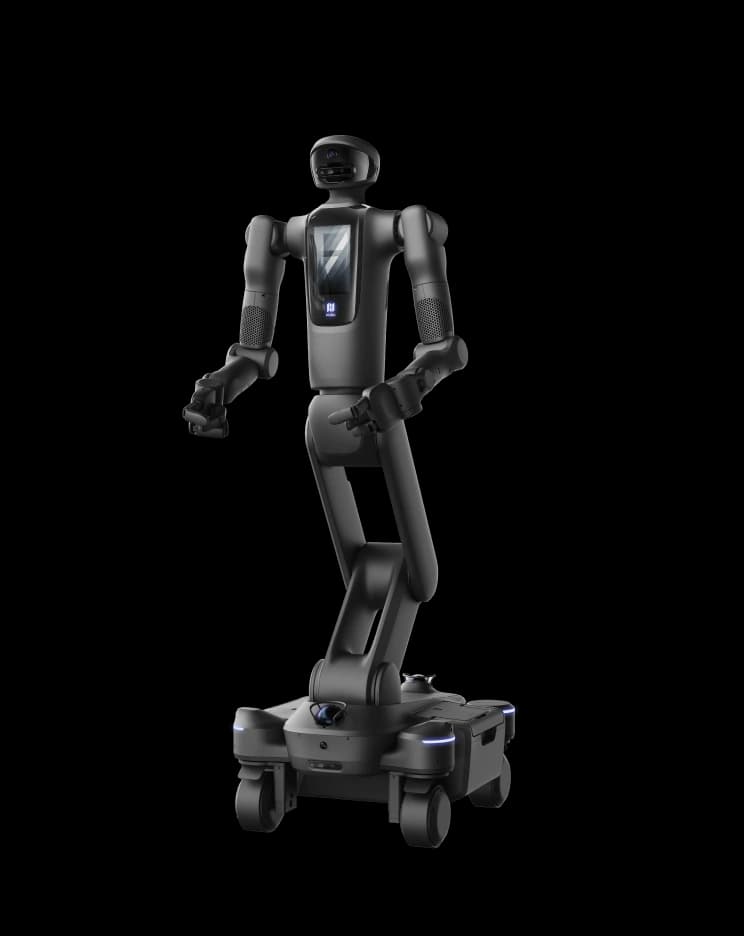
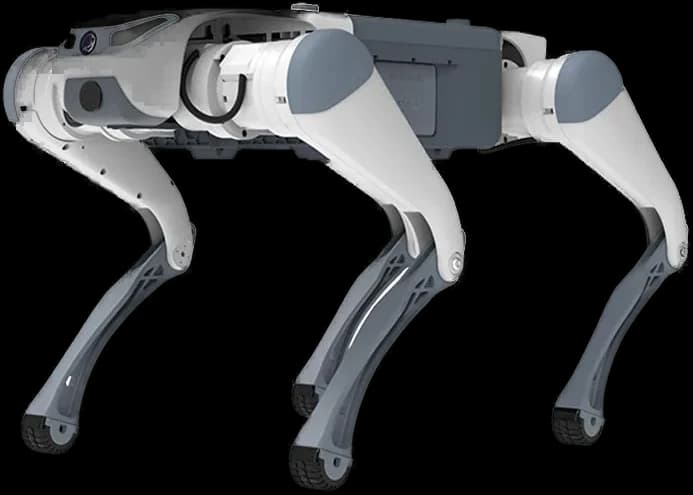
- Proposed robot
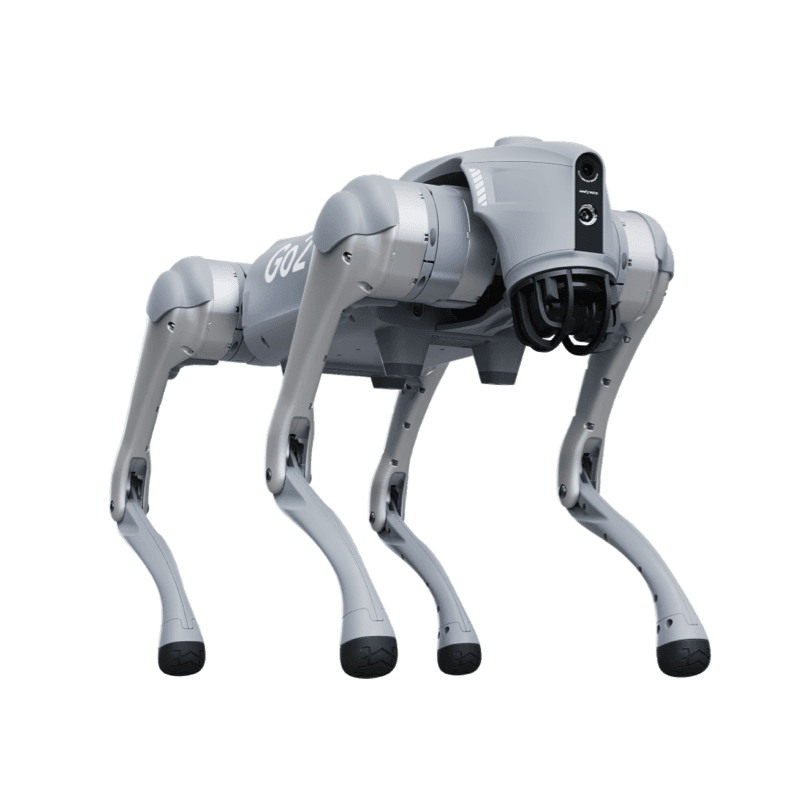
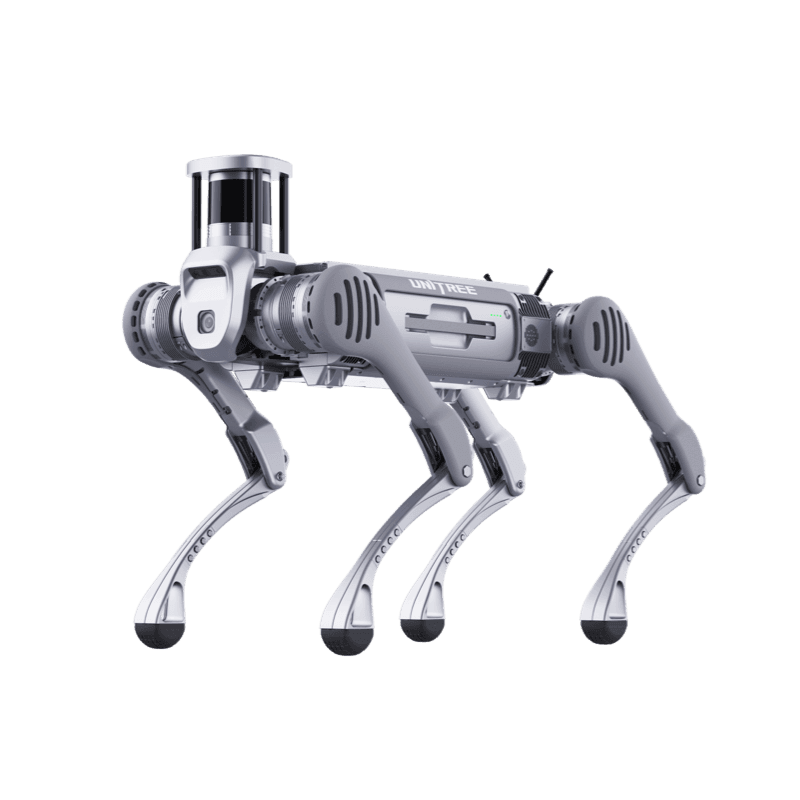
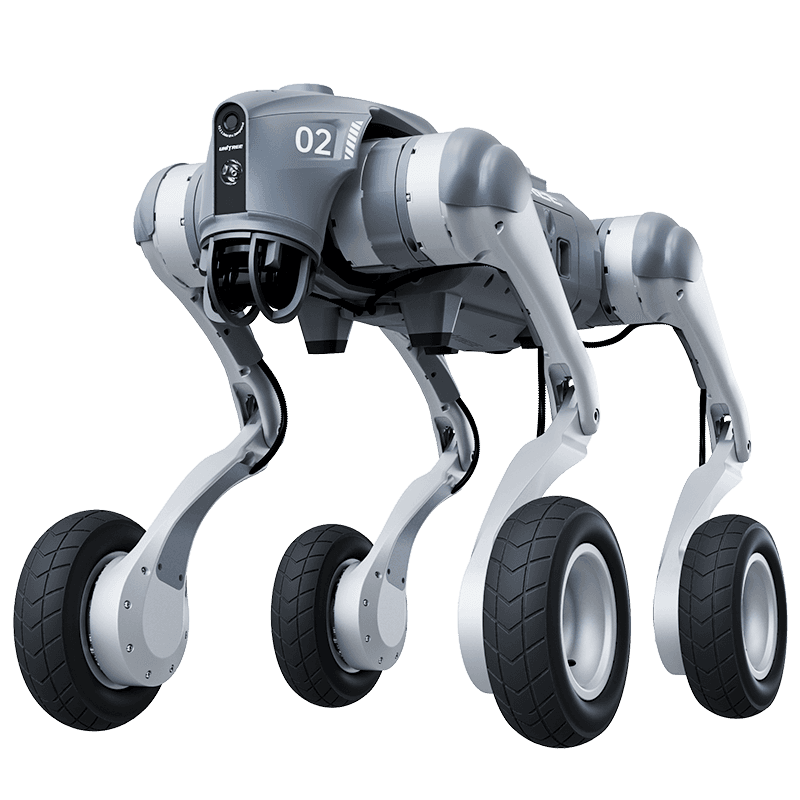
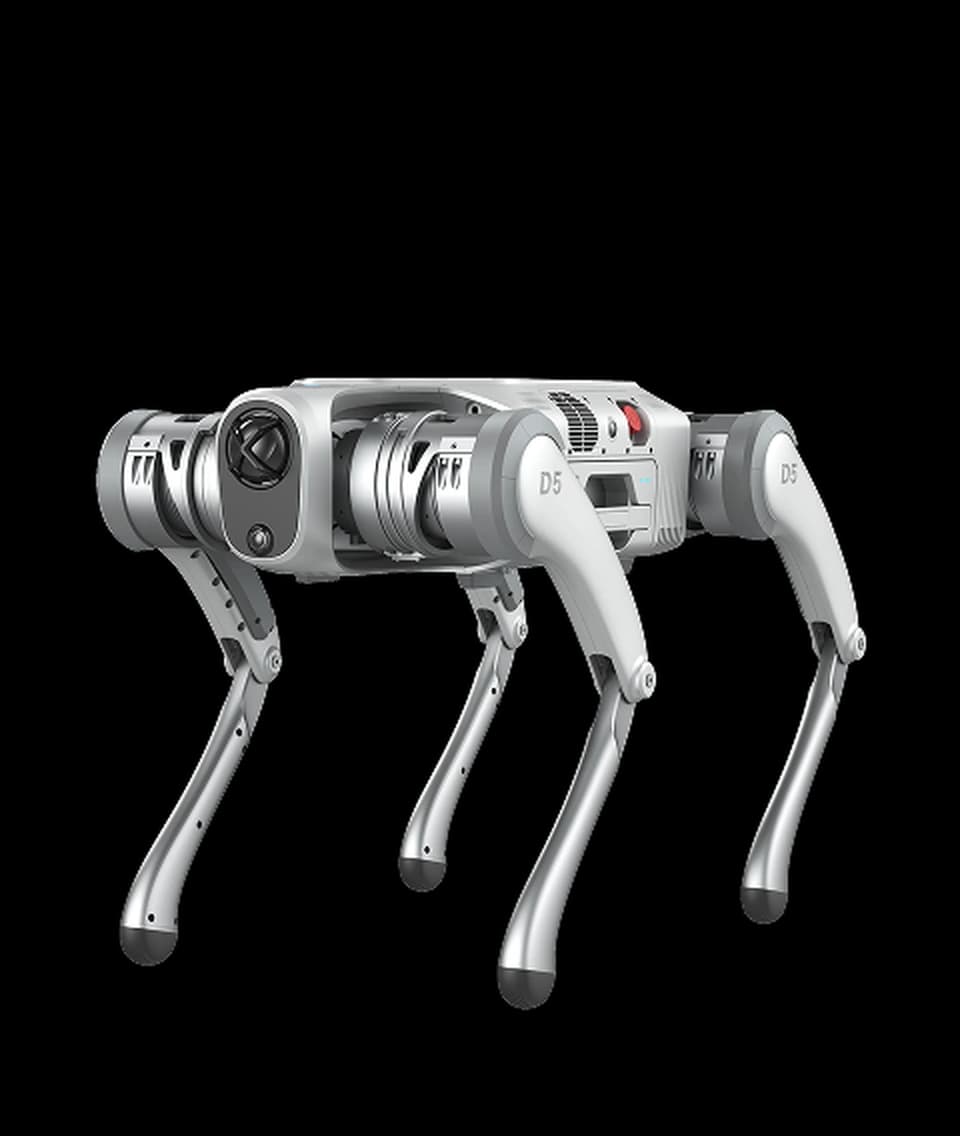
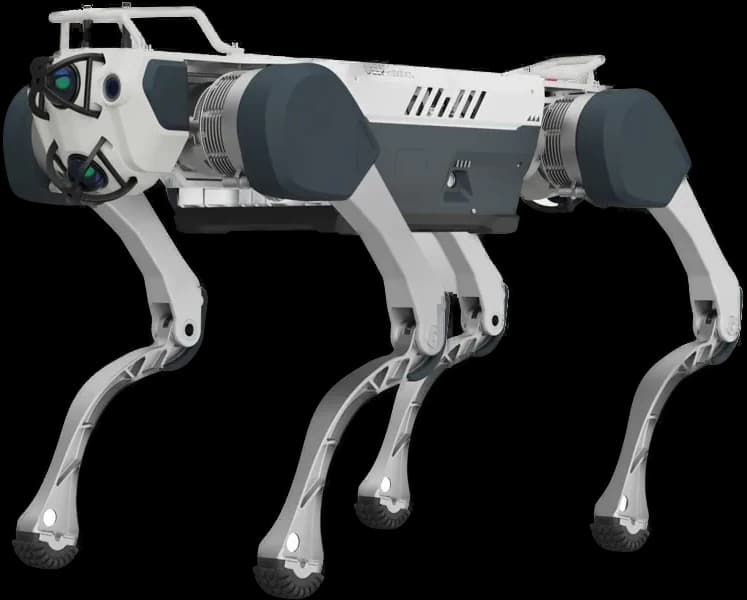
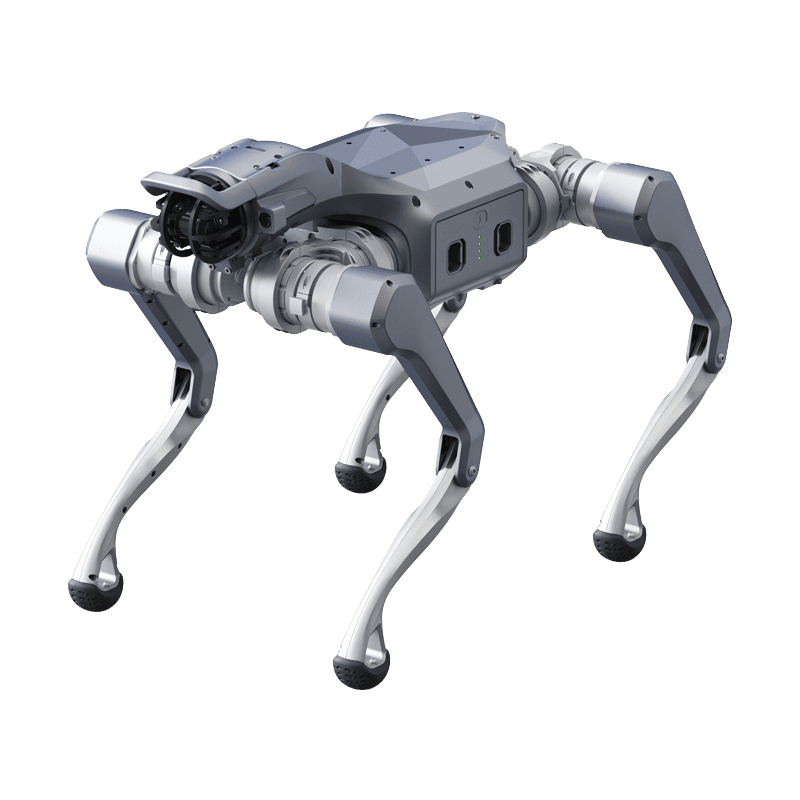
- Unitree A2
The problem addressed
Early detection of micro oil leaks and dangerous thermal expansions before human patrol.
Draft mission flow
- 1The robot starts autonomous patrol on the transformer route determined over the digital twin.
- 2Edge AI simultaneously processes thermal and optical data to detect micro oil leaks.
- 3In anomaly detection, instant image, risk score, and coordinates are transmitted to the command center via API.
Proposed hardware
- High Resolution Optical Camera
- Radiometric Thermal Camera
- NVIDIA Jetson Orin Edge AI
Proposed software
- Navigation
- 3D LiDAR based RTK-GPS Supported SLAM
- Model
- Computer Vision (YOLOv8 Custom Anomalies)
- Integration
- SCADA and CMMS API Integration
The robot's real operating limits
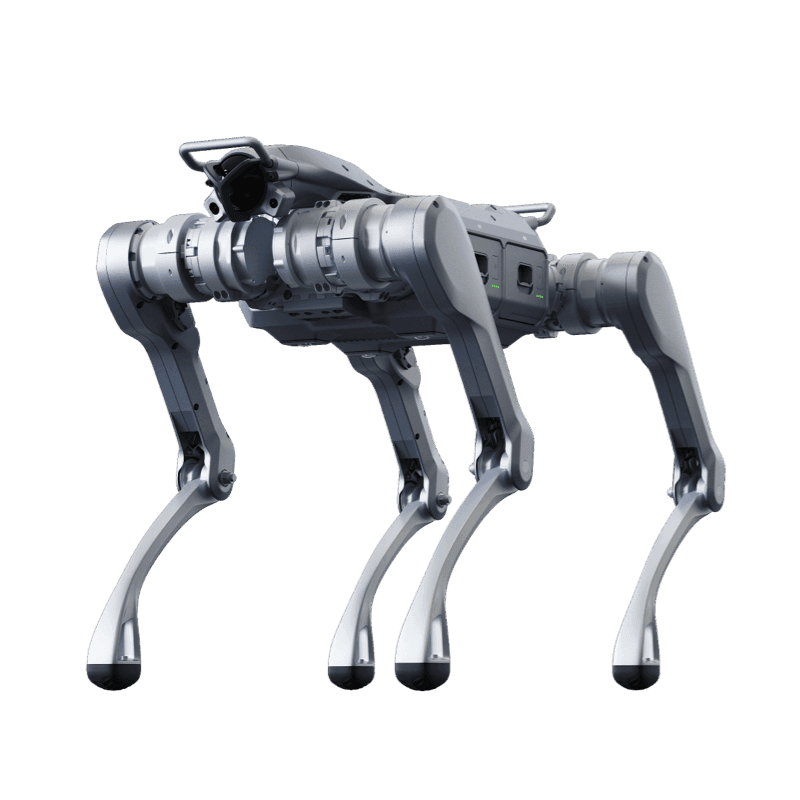
Unitree A2
Industrial Class Legged Robot
Product page- Ingress rating
- IP56-IP67
- Runtime
- >5 hours (No load) / >3 hours (25kg Load)
- Operating temperature
- -20°C to 55°C
- Payload
- 100 kg
- Max speed
- 5 m/s
- Climb
- 45°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.