Concept scenario
Ultrasonic Air Leak Detection
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Indoor, facility
- Operating mode
- Supervised autonomy
- Proposed robot
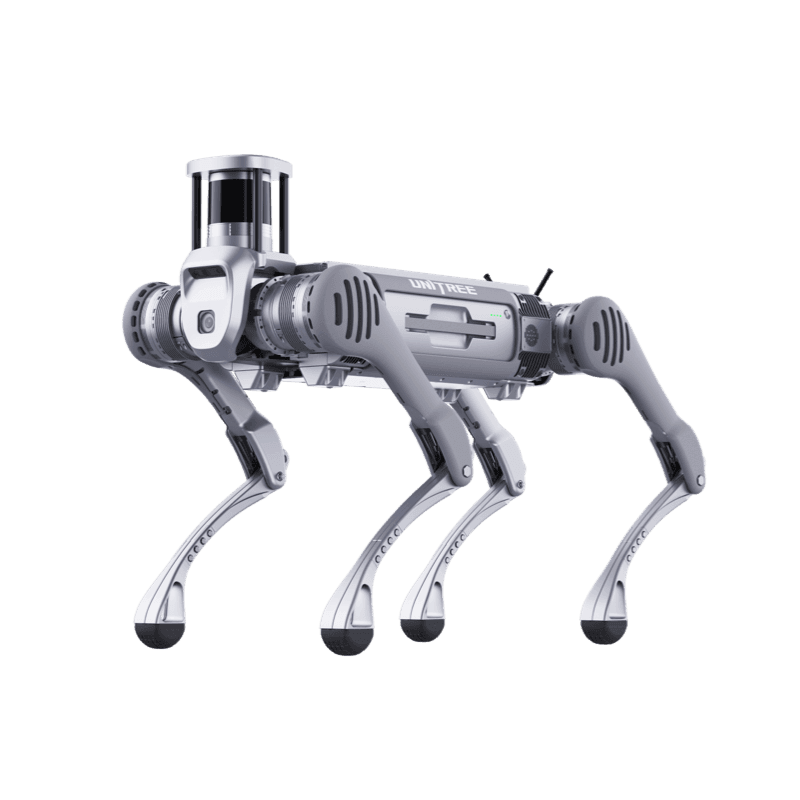
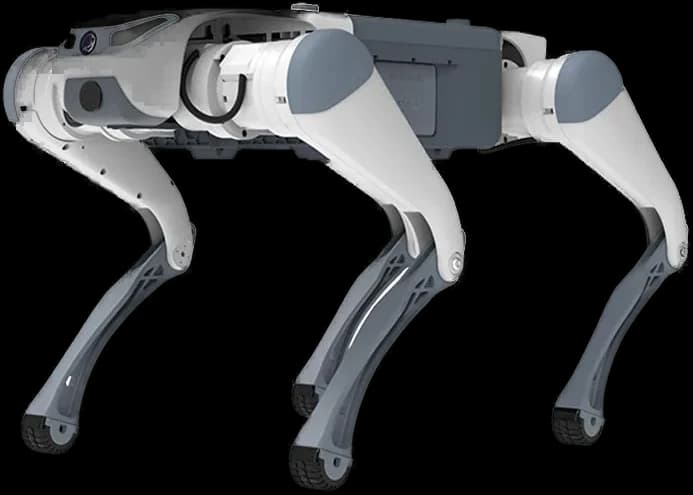
- Unitree AS2
The problem addressed
Invisible pressurized air leaks that cause compressors to run unnecessarily.
Draft mission flow
- 1Performs silent patrols on the factory floor during off-duty hours.
- 2Detects air leak frequencies above 40kHz that the human ear cannot hear with an ultrasonic sensor.
- 3Maps leak points according to decibel levels and creates an energy loss report.
Proposed hardware
- High Frequency Ultrasonic Sensor
- Precision Positioning Lidar
- Battery Management Module
Proposed software
- Navigation
- Autonomous navigation in narrow factory corridors
- Model
- Ultrasonic Wave Processing and Frequency Matching
- Integration
- Factory Energy Management System (EMS)
The robot's real operating limits
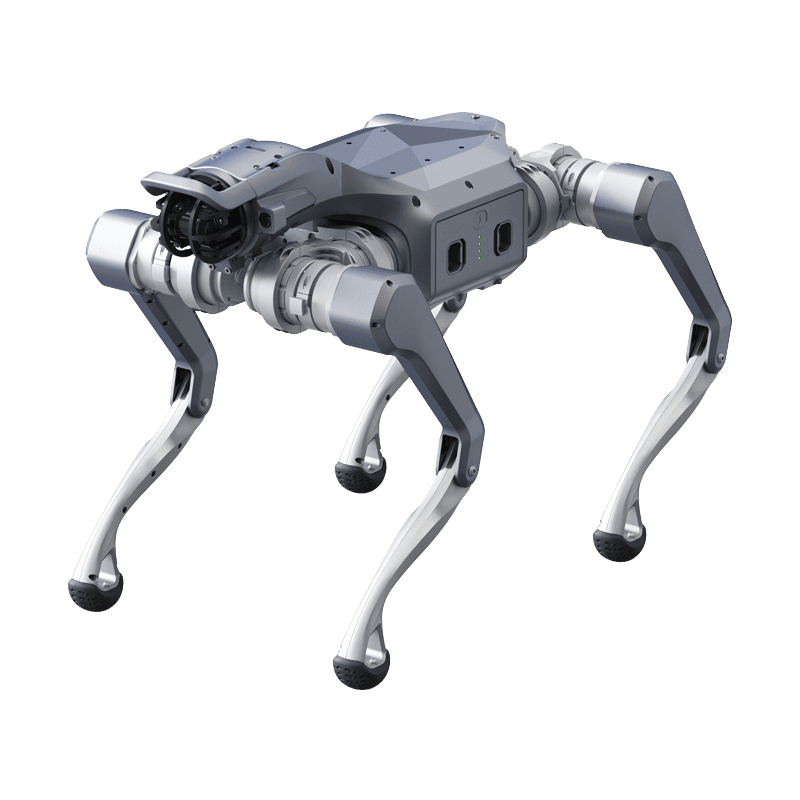
Unitree AS2
Industrial Capacity in a Compact Chassis
Product page- Ingress rating
- IP54
- Runtime
- >4 hours (No load)
- Operating temperature
- -20°C to 50°C
- Payload
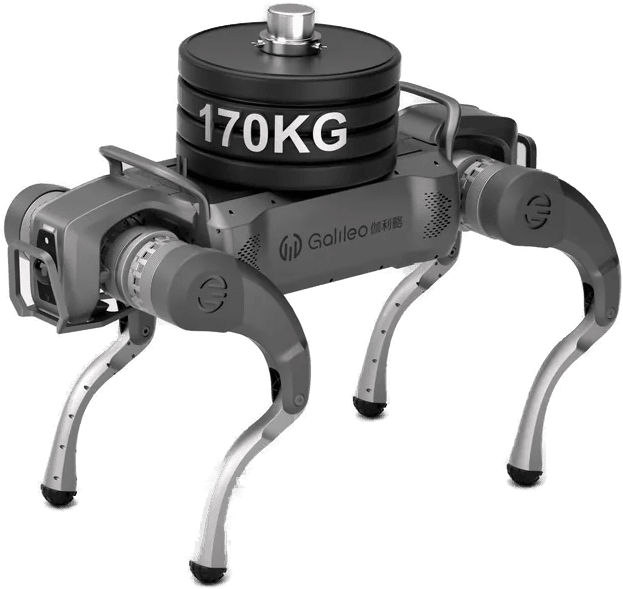
- Up to 65 kg
- Max speed
- >5 m/s
- Climb
- 40°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.