Industrial Facility Face Recognition and Intrusion Verification
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Indoor, facility
- Operating mode
- Supervised autonomy
- Proposed robot
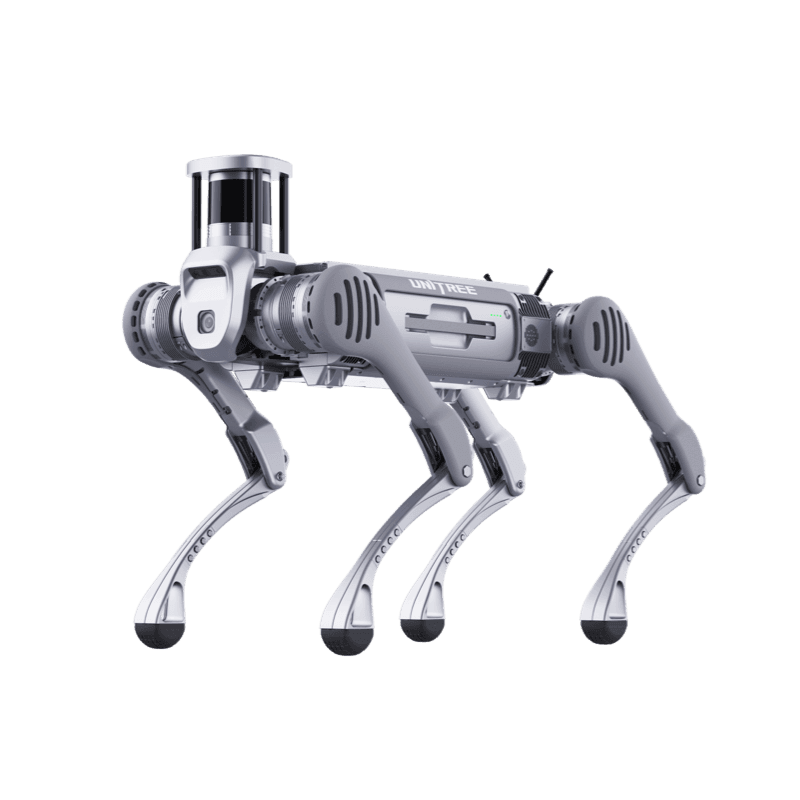
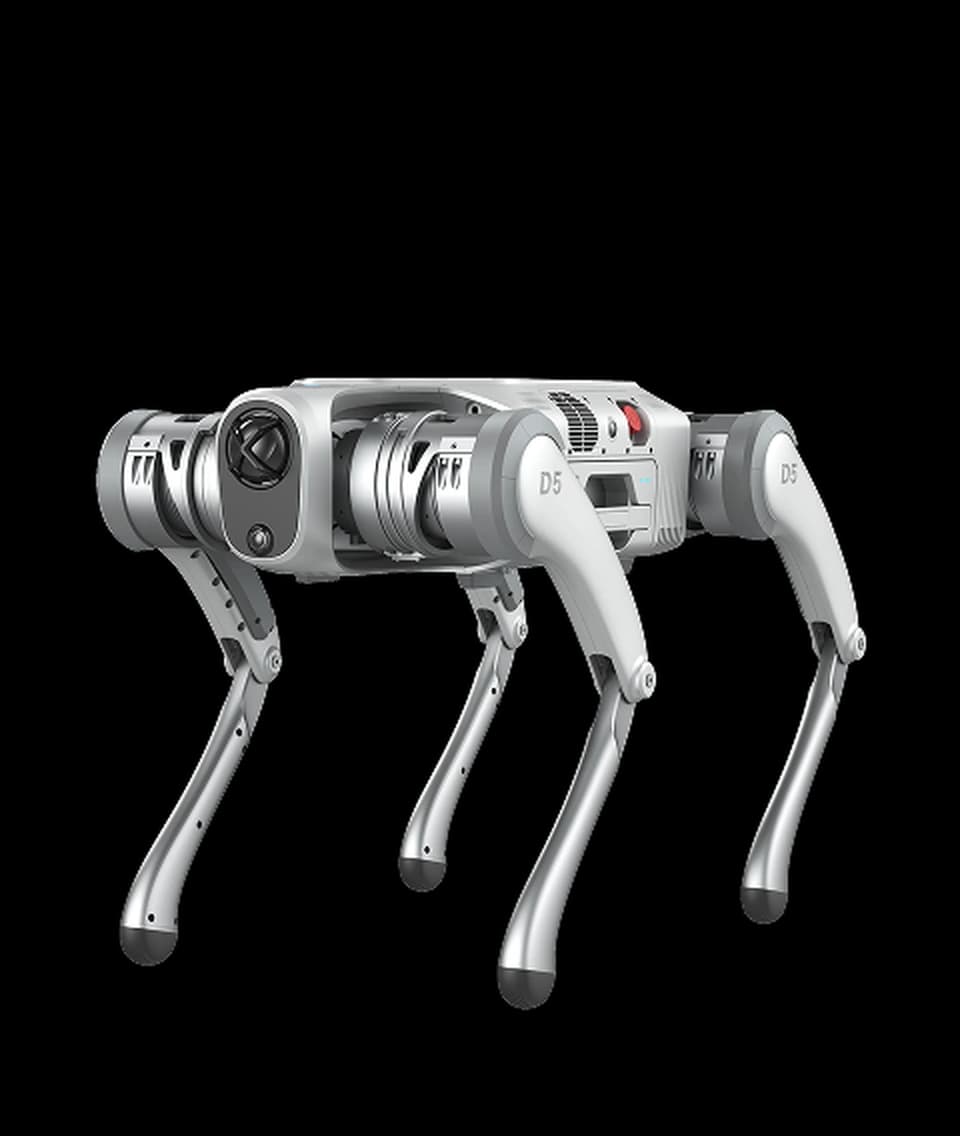
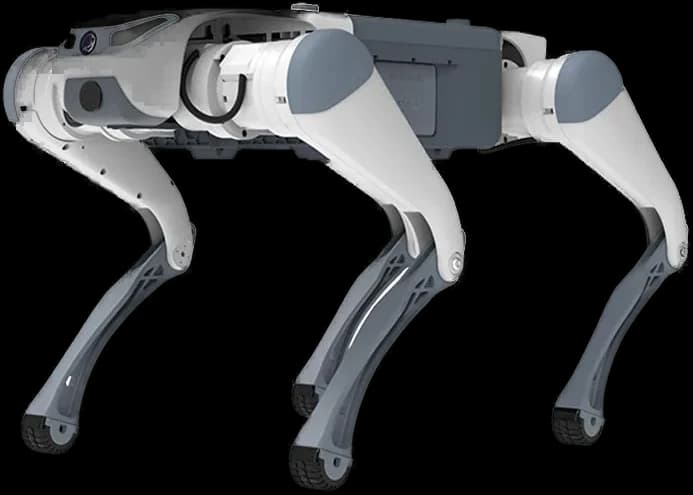
- Unitree AS2
The problem addressed
Theft cases or unauthorized persons leaking into dangerous areas in large facilities.
Draft mission flow
- 1Wanders in the factory/construction site area on random or planned routes.
- 2Instantly matches the face of personnel entering the field of view with the PDKS database.
- 3Sends an instant alarm to the security room when a person who is unauthorized or not on the sub-contractor list is detected.
Proposed hardware
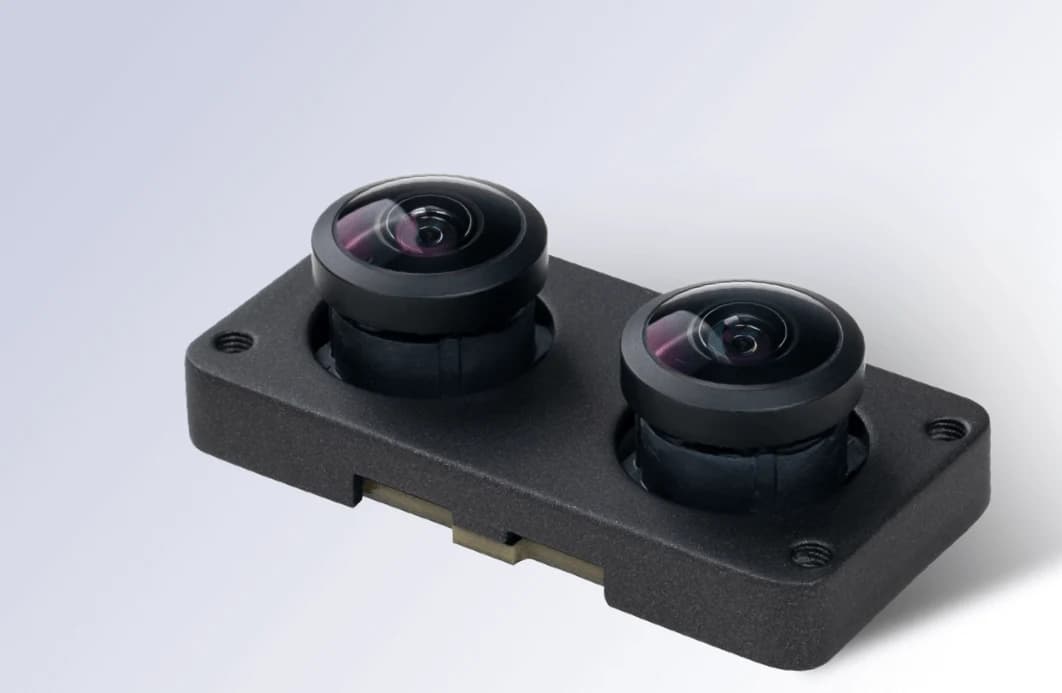
- RGB Depth Camera
- Night Vision Lenses
- NVIDIA Jetson Orin Edge AI
Proposed software
- Navigation
- Autonomous patrol and obstacle avoidance in dynamic personnel traffic
- Model
- Real-Time Face Recognition and Biometric ID Verification
- Integration
- Facility HR Access Control (PDKS) Systems
The robot's real operating limits
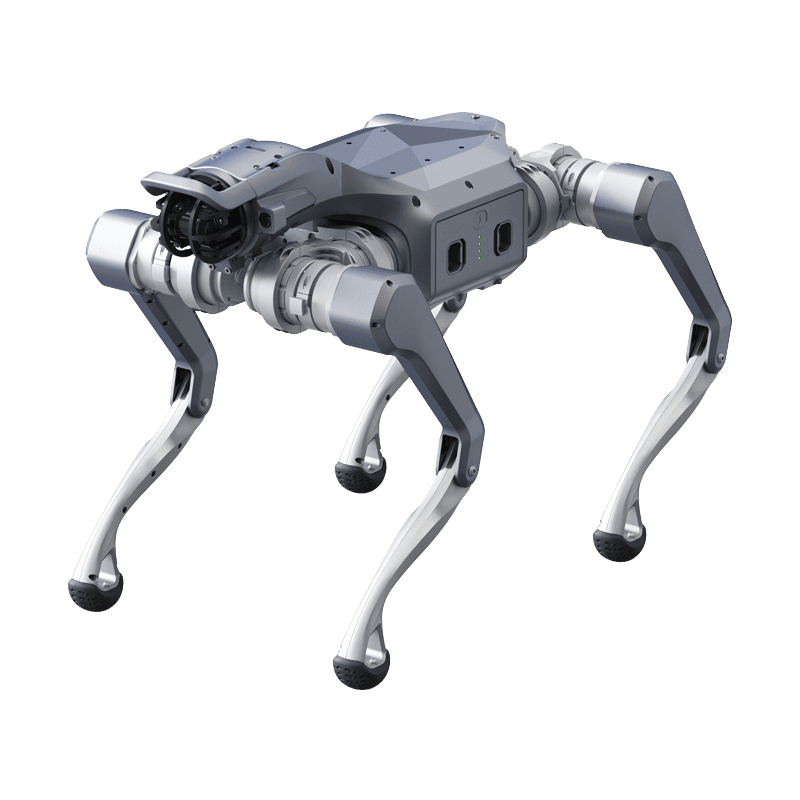
Unitree AS2
Industrial Capacity in a Compact Chassis
Product page- Ingress rating
- IP54
- Runtime
- >4 hours (No load)
- Operating temperature
- -20°C to 50°C
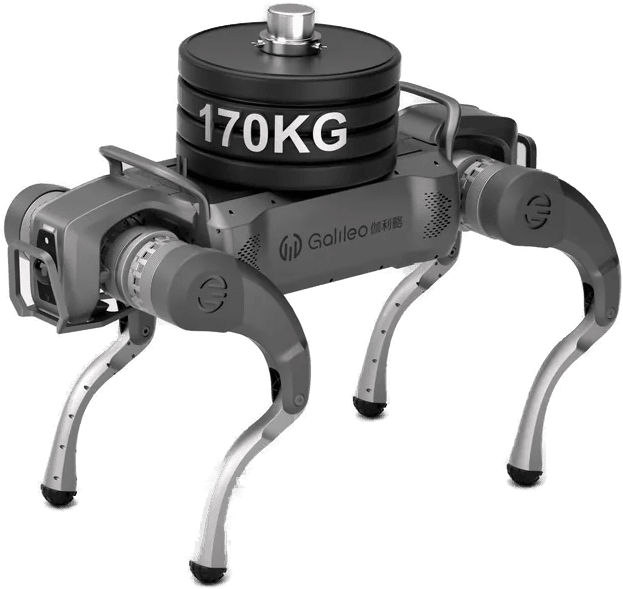
- Payload
- Up to 65 kg
- Max speed
- >5 m/s
- Climb
- 40°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.