






























































Railway Track Gap and Switch Measurement
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Outdoor field
- Operating mode
- Teleoperation
- Proposed robot
- Unitree B2-W
The problem addressed
Slowness of traditional pedestrian railway inspection and human measurement errors.
Draft mission flow
- 1Travels for kilometers on/near rails in wheeled mode.
- 2Measures expansion gaps at rail joints and mechanical wear at switches millimetrically with LiDAR.
- 3Sends points exceeding critical tolerance to the maintenance department with geographic tags.
Proposed hardware
- Millimetric Profile LiDAR
- Dual Optical Camera
- RTK GPS
Proposed software
- Navigation
- High-speed wheeled autonomous travel on the rail line
- Model
- Rail Expansion and Structural Wear Analysis Algorithm
- Integration
- Railway Signaling and Maintenance Network
The robot's real operating limits
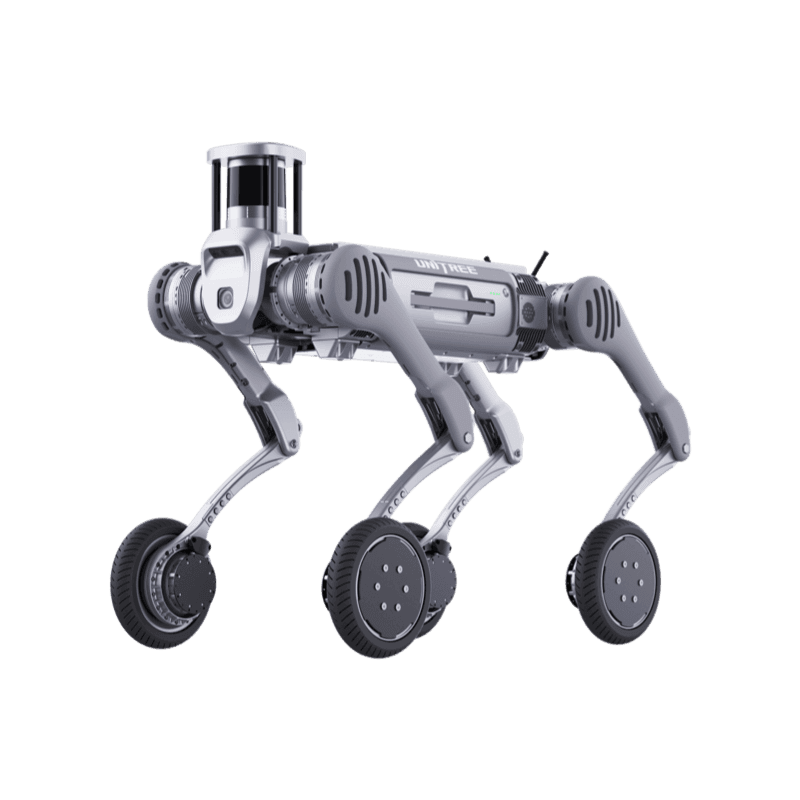
Unitree B2-W
Superior Endurance, High Logistics Efficiency
Product page- Ingress rating
- IP67
- Operating temperature
- -20°C to 55°C
- Payload
- 120 kg
- Max speed
- 15
- Climb
- 45°
- Weight
- 85 kg
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.