






























































Concept scenario
Critical Infrastructure (Plant/Pipe) Peripheral Fence Sabotage Analysis
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Outdoor field
- Operating mode
- Supervised autonomy
- Proposed robot
- Unitree B2-W
The problem addressed
Use of static camera blind spots by saboteurs.
Draft mission flow
- 1The robot goes on mission parallel to the boundary fences during the night shift.
- 2Scans for cuts in the wires with the camera, listens to abnormal sounds from the environment (wire cutters, footsteps) with acoustic sensors.
- 3Transmits 4K live broadcast to the center in silent mode when sabotage or infiltration is detected.
Proposed hardware
- Thermal Sensor
- Optical Camera
- Laser Guided Acoustic Listening
- Edge AI
Proposed software
- Navigation
- Continuous closed-loop patrol along rough terrain and fence boundaries
- Model
- Physical Damage (Wire Cutting, Climbing) and Gunshot Detection
- Integration
- Security Command & Control Center
The robot's real operating limits
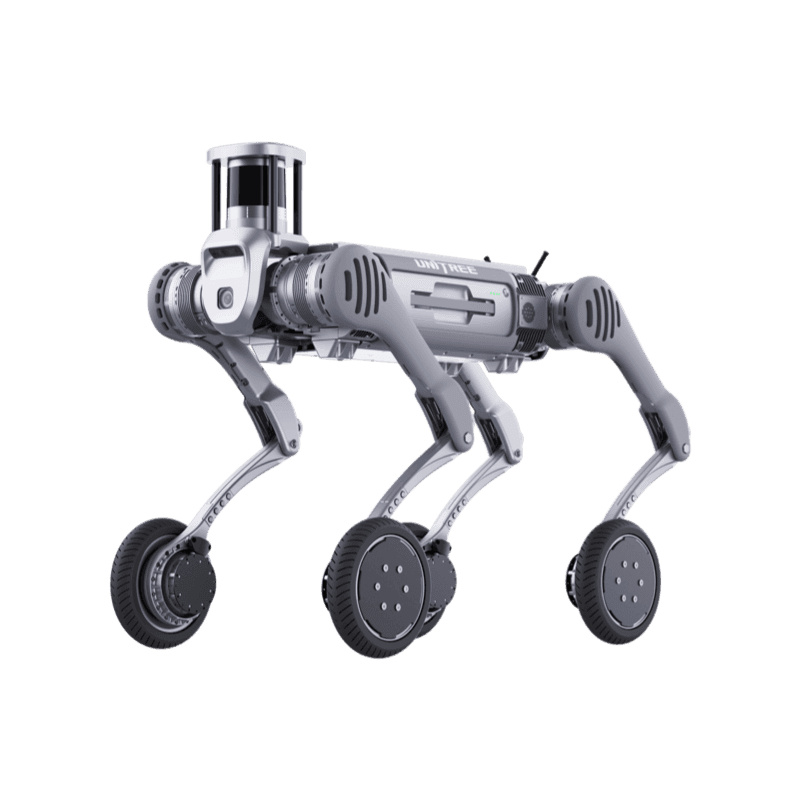
Unitree B2-W
Superior Endurance, High Logistics Efficiency
Product page- Ingress rating
- IP67
- Operating temperature
- -20°C to 55°C
- Payload
- 120 kg
- Max speed
- 15
- Climb
- 45°
- Weight
- 85 kg
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.