Takes the cage and pallet work to where it is
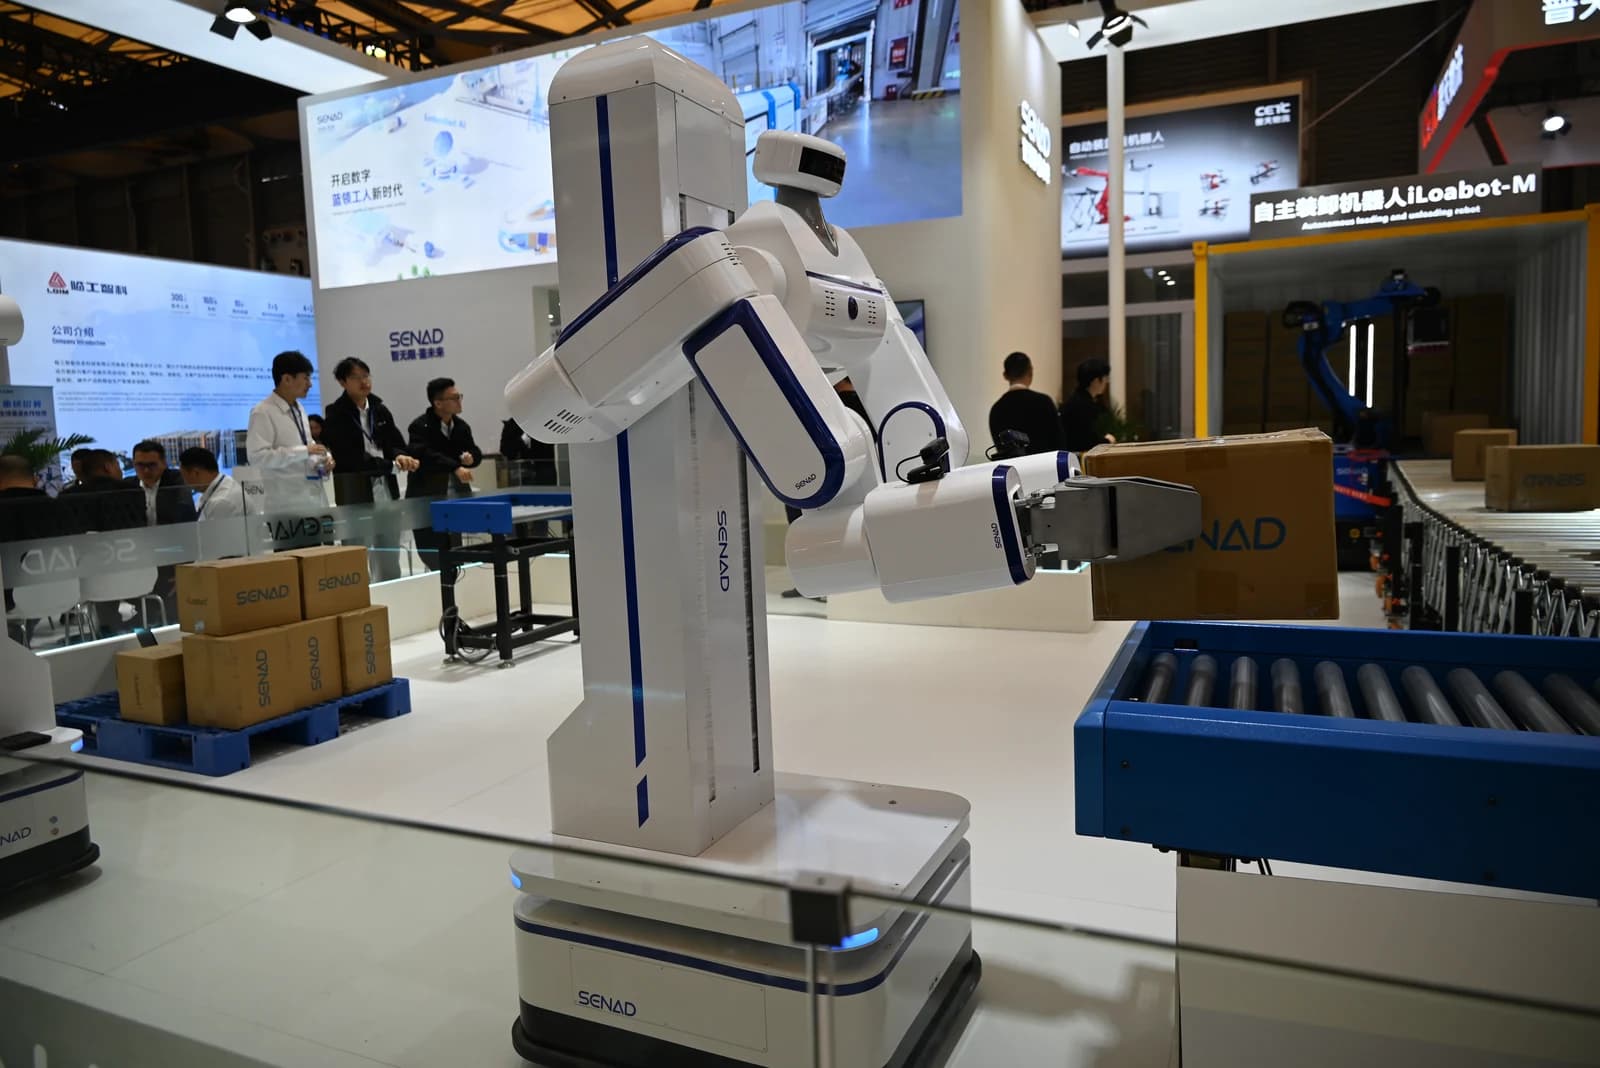
Depalletizing and cage filling have been automated in fixed cells; the work has to be carried to the cell. The iLoabot-P reverses this: the large-payload collaborative arm on an autonomously navigating tracked chassis goes to where the load is. It finds the position of the cage cart by itself, opens the cage and places the product on a conveyor or at a designated point; it breaks down the pallet and, if required, rebuilds the same product. The 1227 × 832 × 1900 mm, 250 kg body moves through the warehouse aisle and processes cartons of up to 25 kg and between 150 mm and 400 mm at 8-13 cycles per minute.
Mixed stacks and SLAM
The built-in intelligent mixed-stack algorithm resolves multi-product stacks in online (order not known in advance) and offline (planned) mode; sorting is done while depalletizing, and the picked product is stacked directly into a cage or onto a pallet. Intelligent SLAM navigation leaves localisation, mapping and route planning to the robot; in follow mode the robot follows the operator, and the collaborative arm works in the same space as people. The in-house delivery platform configures the tasks to the site flow.
Tracked chassis and energy
The distributed-load tracked chassis moves through demanding conditions without damaging the floor; with the climbing and obstacle crossing shown at CIIF 2025 it drives straight into vehicle bodies with tail doors and clears the sills where wheeled platforms catch and slip. The lithium-ion battery charges wirelessly; the trip to the charging point is part of the robot's task plan. The operating temperature is -20 to 60 °C.
A shared flow with the iLoabot-M
The iLoabot-P joined the iLoabot family in 2024 and is positioned as the complement of the unloading robots: the iLoabot-M lowers the carton from the container onto the conveyor, the iLoabot-P takes it from the conveyor and builds it into a cage or onto a pallet; in the opposite direction it opens the cage and prepares for loading. In 2025 the robot was exhibited with the other family members at CIIF and CeMAT ASIA in Shanghai.
Applications
- Cage-cart flow: autonomous location and opening of the cage and drop-off of the product onto a conveyor or a designated point; filling of empty cages.
- Depalletizing and palletizing: multi-SKU online and offline mixed stacks; sorting while breaking down.
- Sorting and picking: product sorting on complex sites, picked product stacked directly into a cage or onto a pallet.
- Machine tending: heavy-load handling, feeding product to the line and taking it off.
- Unloading-line complement: the palletizing and caging step in a shared flow with the iLoabot-M and iLoabot-Pro.
- Vehicle bodies: entry into trucks with tail doors on the tracked chassis, cage and pallet work inside the body.
Price and sourcing
The iLoabot-P is sourced for Turkey on a project basis: cage and pallet types, carton sizes and weights, SKU variety, aisle widths and charging layout are worked out at the survey. Investment is set by corporate quotation against configuration, end-effector choice, shared installation with the iLoabot unloading robots, commissioning scope and quantity; import, customs clearance, commissioning, operator training and after-sales support are part of delivery.
Summary
The iLoabot-P takes depalletizing and cage work out of the fixed cell and carries it to where the load is: the 250 kg tracked body moves with SLAM, the collaborative arm picks cartons of up to 25 kg at 8-13 cycles per minute, and the mixed-stack algorithm sorts multi-SKU pallets while breaking them down. Wireless charging and climbing into tail-door bodies free the robot between warehouse and vehicle; the shared flow set up with the iLoabot-M is in continuous use. For warehouses with heavy cage-cart and pallet traffic and operators completing the unloading line with palletizing, request a quotation with the carton and SKU profile.