Skip to content
Robotlar

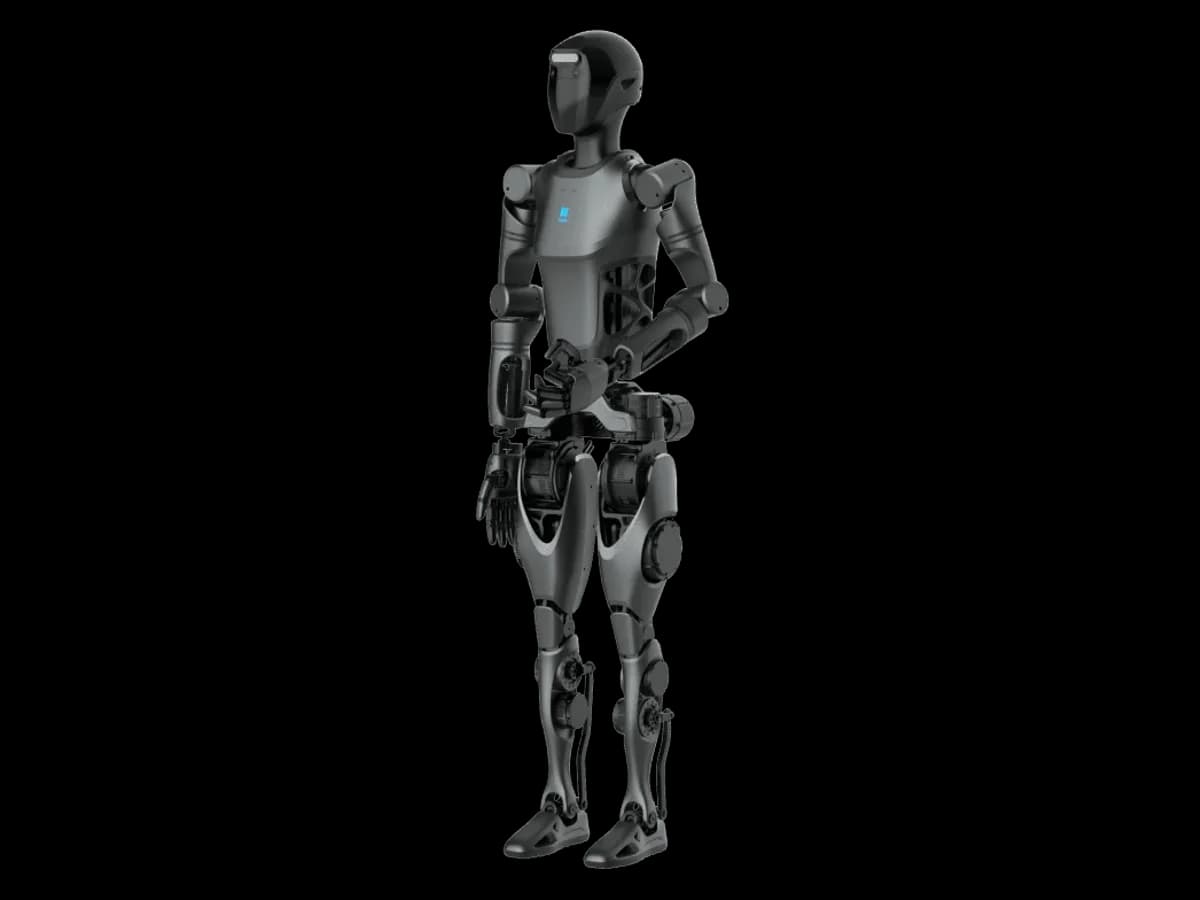
Fourier GR-1

First-Generation Research Humanoid Robot

Height
165 cm
Approximately 55 kg
DOF
32
44 actuators with dexterous hands
Joint Torque
230 N·m
FSA actuator
Walking Speed
5 km/s
3 kg single hand
Battery
460 Wh
Charging 46 V / 2 A
Processor
i7-13700H
20 threads

The Fourier GR-1 is the first humanoid robot Fourier developed. It stands 165 cm and weighs approximately 55 kg; the body carries 32 degrees of freedom (legs 6+6, waist 3, head 3, arms 7+7), and in the dexterous-hand configuration the total actuator count reaches 44.

Read more

Walking speed is 5 km/h, single-hand payload 3 kg and peak joint torque 230 N·m. The drive is based on the Fourier Smart Actuator family, which combines motor, driver, reducer and encoder into a single module. It carries a 460 Wh battery and a 20-thread Intel i7-13700H processor. Perception includes a RealSense depth camera; the pure-vision solution uses six RGB cameras with a bird's-eye-view, Transformer and occupancy network approach. Because Fourier has shifted product focus to the GR-3 and GRW, the GR-1 product page has been removed from the manufacturer's site.

Enterprise supply · specification support · integration engineering

Overview

The Fourier GR-1 is the first humanoid robot Fourier developed and the starting point of the GRx series. Equipped with FSA actuators, the body reproduces a near-human distribution of degrees of freedom with a versatile structure and advanced motion control.

Mechanically: dimensions of 1650 × 515 × 320 mm, a weight of approximately 55 kg and a 1680 mm arm span. The body carries 32 degrees of freedom: legs 6+6, waist 3, head 3, arms 7+7. In the dexterous-hand configuration the total actuator count reaches 44, staying at 34 on the gripper-equipped GR-1L. Walking speed is 5 km/h, single-hand payload 3 kg and peak joint torque 230 N·m.

The drive is based on the Fourier Smart Actuator family, combining motor, driver, reducer and encoder into a single module. Supply is 46.2 V with a maximum power of approximately 550 W. The battery holds 460 Wh and charges at 46 V / 2 A.

Compute runs on an Intel i7-13700H: six performance and eight efficiency cores, 20 threads and frequencies from 1.6 to 5.0 GHz. Perception includes a RealSense depth camera and a ring-shaped microphone array; the pure-vision solution uses six RGB cameras with a bird's-eye-view, Transformer and occupancy network approach. The frame is aluminium alloy and engineering plastic.

Fourier has shifted product focus to the GR-3 and the wheeled GRW; the GR-1 product page has been removed from the manufacturer's site and its brochure is no longer listed in the download centre.

If you are planning a new project we can assess Fourier's current models together with the Unitree G1 and H2 options deliverable in Turkey today.


The Fourier GR-1 in motion

Tap the cover to play; sound and loading start only on click.

Fourier GR-1 product video

Which GR-1 fits your needs?

The manufacturer's official variant matrix; the values are documented data.

FeatureGR-1GR-1LGR-1 ProGR-1L Pro
End-effectorBecerikli elTutucuBecerikli elTutucu
BodyGR1T1GR1T1GR1T2GR1T2
WeightYaklaşık 55 kgYaklaşık 55 kgYaklaşık 60 kgYaklaşık 60 kg
Arm span1680 mm1665 mm1680 mm1665 mm
Total actuators44344434
Body degrees of freedom32323232
QuoteGet a Quote for This ModelGR-1Get a Quote for This ModelGR-1LGet a Quote for This ModelGR-1 ProGet a Quote for This ModelGR-1L Pro

All four editions share a 165 cm height and 32 body degrees of freedom (legs 6+6, waist 3, head 3, arms 7+7). The difference is the end-effector and the body revision: dexterous-hand editions reach 44 total actuators while the gripper-equipped L editions stay at 34. The Pro editions use the GR1T2 body.

GR-1

The base edition with dexterous hands; open to grasping trials with 44 actuators.

GR-1L

The simplified edition with grippers; focused on locomotion research with 34 actuators.

GR-1 Pro

Dexterous hands on the GR1T2 body revision.

GR-1L Pro

Grippers on the GR1T2 body revision.

Key Advantages

The Start of the GRx Series

The GR-1 is the first humanoid robot Fourier developed.

  • Equipped with FSA actuators, the body reproduces a near-human distribution of degrees of freedom with a versatile structure and advanced motion control.
  • Starting from this body, the series evolved through three generations: the GR-1, GR-2 and GR-3.
Fourier GR-1, The Start of the GRx Series

Made for AI: Six Core Values

The GRx series was designed under the "Made for AI" principle and built around six core values: locomotion, cognition, bionic design, commercial viability, user experience and manipulation.

  • That framework is preserved in every generation of the series starting with the GR-1.
Fourier GR-1, Made for AI: Six Core Values

The Fourier GR-1 up close

2 images; tap to enlarge.

Technical Specifications

31 values in 7 categories; data published by the manufacturer.

General structure
Mobility form
Bipedal full-size humanoid; advanced motion control with a near-human degree-of-freedom distribution
Degrees of freedom
32 in the body; 44 total actuators in the dexterous-hand edition and 34 with grippers
Neck DoF
3 DoF
Torque density
Peak joint torque 230 N·m; the Fourier Smart Actuator (FSA) family combines motor, driver, reducer and encoder into a single module; 46.2 V supply with a maximum power of approximately 550 W
Materials
Aluminium alloy and engineering plastic
DoF layout
32 degrees of freedom in the body: legs 6+6, waist 3, head 3, arms 7+7. Dexterous hands add 6+6; total actuators reach 44 with dexterous hands and 34 with grippers
Payload
3 kg single-hand payload
Joint module
Fourier Smart Actuator (FSA): motor, driver, reducer and encoder in one module; peak joint torque 230 N·m
Battery system
A 460 Wh battery charging at 46 V / 2 A.
Structure and materials
Aluminium alloy and engineering plastic
Size and weight
Dimensions (standing)
1650 × 515 × 320 mm; arm span 1680 mm (GR-1), 1665 mm (GR-1L)
Weight
55 kg
Arm reach
1764 mm arm span
Motion and performance
Arm payload
3
Maximum speed
5
Joint torque
230 N·m (maximum joint torque)
Power and runtime
Battery
460 Wh; charging at 46 V / 2 A.
Runtime
Approximately 60 minutes; approximately 45 minutes while walking; charging time 315 minutes
Charging time
315 min
Charger
Adapter input 100-240V 50/60Hz; adapter output 46V 2A MAX
Operating power
Maximum operating power approximately 550 W
Operating voltage
46.2 V power supply voltage; actuator working voltage 12-60 V with 46 V rated and 40 A maximum current; adapter input 100-240 V 50/60 Hz, adapter output 46 V 2 A max
Sensors and connectivity
Sensors
RealSense depth camera; the pure-vision solution uses six RGB cameras with a bird's-eye-view, Transformer and occupancy network approach; IMU
Connectivity
1 x HDMI and 3 x Type-C (fast charge, download, peripheral expansion); components are interconnected over an Ethernet bus and powered from a unified 46 V supply
Wireless
Wi-Fi IEEE 802.11a/b/g/n/ac; Bluetooth 4.2
Interaction
Ring-shaped microphone array
Joint encoder
Each active joint of the leg is equipped with an absolute encoder for position detection
Software and development
Processor
Intel i7-13700H; 6 performance and 8 efficiency cores, 20 threads, 1.6 to 5.0 GHz
Operating system
Ubuntu 20.04 with ROS 2
Software features
Six degrees of freedom per dexterous hand; the motion control stack and simulation models are published in Fourier's open repositories
Environmental resilience
Certifications
GB 17625.1-2012, GB 4943.1-2011, GB/T 9254-2008 (manufacturer statement)

An itemised quote for the Fourier GR-1 is prepared by configuration, quantity and delivery scope.

Technical Analysis of a First-Generation HumanoidDesign decisions, comparison table and evaluation

32 Degrees of Freedom and a Three-Axis Waist

The GR-1's breakdown is: legs 6+6, waist 3, head 3, arms 7+7. A three-axis waist and three-axis head reflect a first-generation choice to imitate the human torso as closely as possible. In the second-generation GR-2 the waist drops to one axis and the head to two, bringing the body total down to 29. The series therefore moved away from copying human anatomy toward prioritising controllability and the manipulation budget.

FSA: An Actuator in a Single Module

The Fourier Smart Actuator combines motor, driver, reducer and encoder into a single housing. The practical result is fewer cables and less assembly time: each joint runs off a single bus connection. Peak torque is 230 N·m. For comparison the second-generation FSA 2.0 produces 436 N·m on the same measure and adds a second encoder; in the first generation's single-encoder arrangement, backlash after the reducer stays invisible to the control loop.

Comparison of the GRx Generations

FeatureFourier GR-1Fourier GR-2Fourier GR-3
Height165 cm175 cm165 cm
WeightApproximately 55 kgApproximately 63 kg71 kg
Body degrees of freedom322955 (including hands)
Waist axes313
Peak joint torque230 N·m436 N·m-
ActuatorFSAFSA 2.0, dual encoder-
Manufacturer pageRemovedRemoved, brochure remainsLive

Engineering Assessment

The GR-1 is not a product to buy today but a reference showing where the GRx series began. What stands out technically is the three-axis waist and three-axis head: at 32, its body total is the highest in the series and offers the distribution closest to human anatomy. Consolidating the FSA actuator into a single module became an architectural choice preserved in later generations. The limits are what you would expect of a first generation: peak torque of 230 N·m is about half the second generation's, the single encoder leaves post-reducer error invisible and runtime was never published. Fourier has shifted focus to the GR-3 and GRW; for a new project those two models, or the Unitree G1 and H2 deliverable today, should be evaluated.

Purchasing support

Get a quote for the GR-1

Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.

  • Supply and delivery scheduling backed directly by the manufacturer
  • Site- and mission-focused technical feasibility and simulation
  • Turnkey hardware, software and mission integration
  • Advisory on corporate tenders, specifications and administrative processes

Direct contact and advisory line: 0850 532 6 777

Add project details (optional)

Product of interest: GR-1

GR-1: Frequently Asked Questions

The most common questions about the Fourier GR-1.

Can the Fourier GR-1 still be bought?

The GR-1 product page has been removed from Fourier's site and the brochure is no longer listed in the download centre; the model is at the end of its life cycle. Fourier's current humanoid focus is the GR-3 and the wheeled GRW. If you have a specific GR-1 requirement you can talk to Robotlar.org, but for a new project we suggest evaluating the current models or the alternatives deliverable today.

What are the Fourier GR-1's specifications?

Dimensions 1650 × 515 × 320 mm, weight approximately 55 kg, arm span 1680 mm. Thirty-two degrees of freedom in the body: legs 6+6, waist 3, head 3, arms 7+7; 44 total actuators with dexterous hands and 34 on the gripper-equipped GR-1L. Walking speed 5 km/h, single-hand payload 3 kg, peak joint torque 230 N·m. The battery is 460 Wh charging at 46 V / 2 A. The processor is an Intel i7-13700H with 20 threads. Perception includes a RealSense depth camera and a ring microphone; the pure-vision solution uses six RGB cameras.

What is the difference between the GR-1 editions?

All four editions share a 165 cm height and 32 body degrees of freedom. The GR-1 carries dexterous hands and reaches 44 total actuators; the GR-1L carries grippers, stays at 34 and has a 1665 mm arm span. The Pro editions use the GR1T2 body revision and weigh approximately 60 kg. The choice depends on whether the work requires fine grasping.

Is there a humanoid alternative deliverable today?

Yes. The Unitree G1 (132 cm, 35 kg, Jetson Orin) and the full-size Unitree H2 (182 cm, 70 kg, 31 degrees of freedom) can be ordered now, with 4-6 week delivery, a 1-year official warranty, on-site commissioning and engineering support across Turkey. Pricing is set by quote per configuration.


Other robots in this category