






























































Modular system design
The wheeled base and the upper body of head, arms and torso separate.
- The system is used as a complete robot, or the upper body is mounted on other chassis models and RealMan dual-arm platforms.
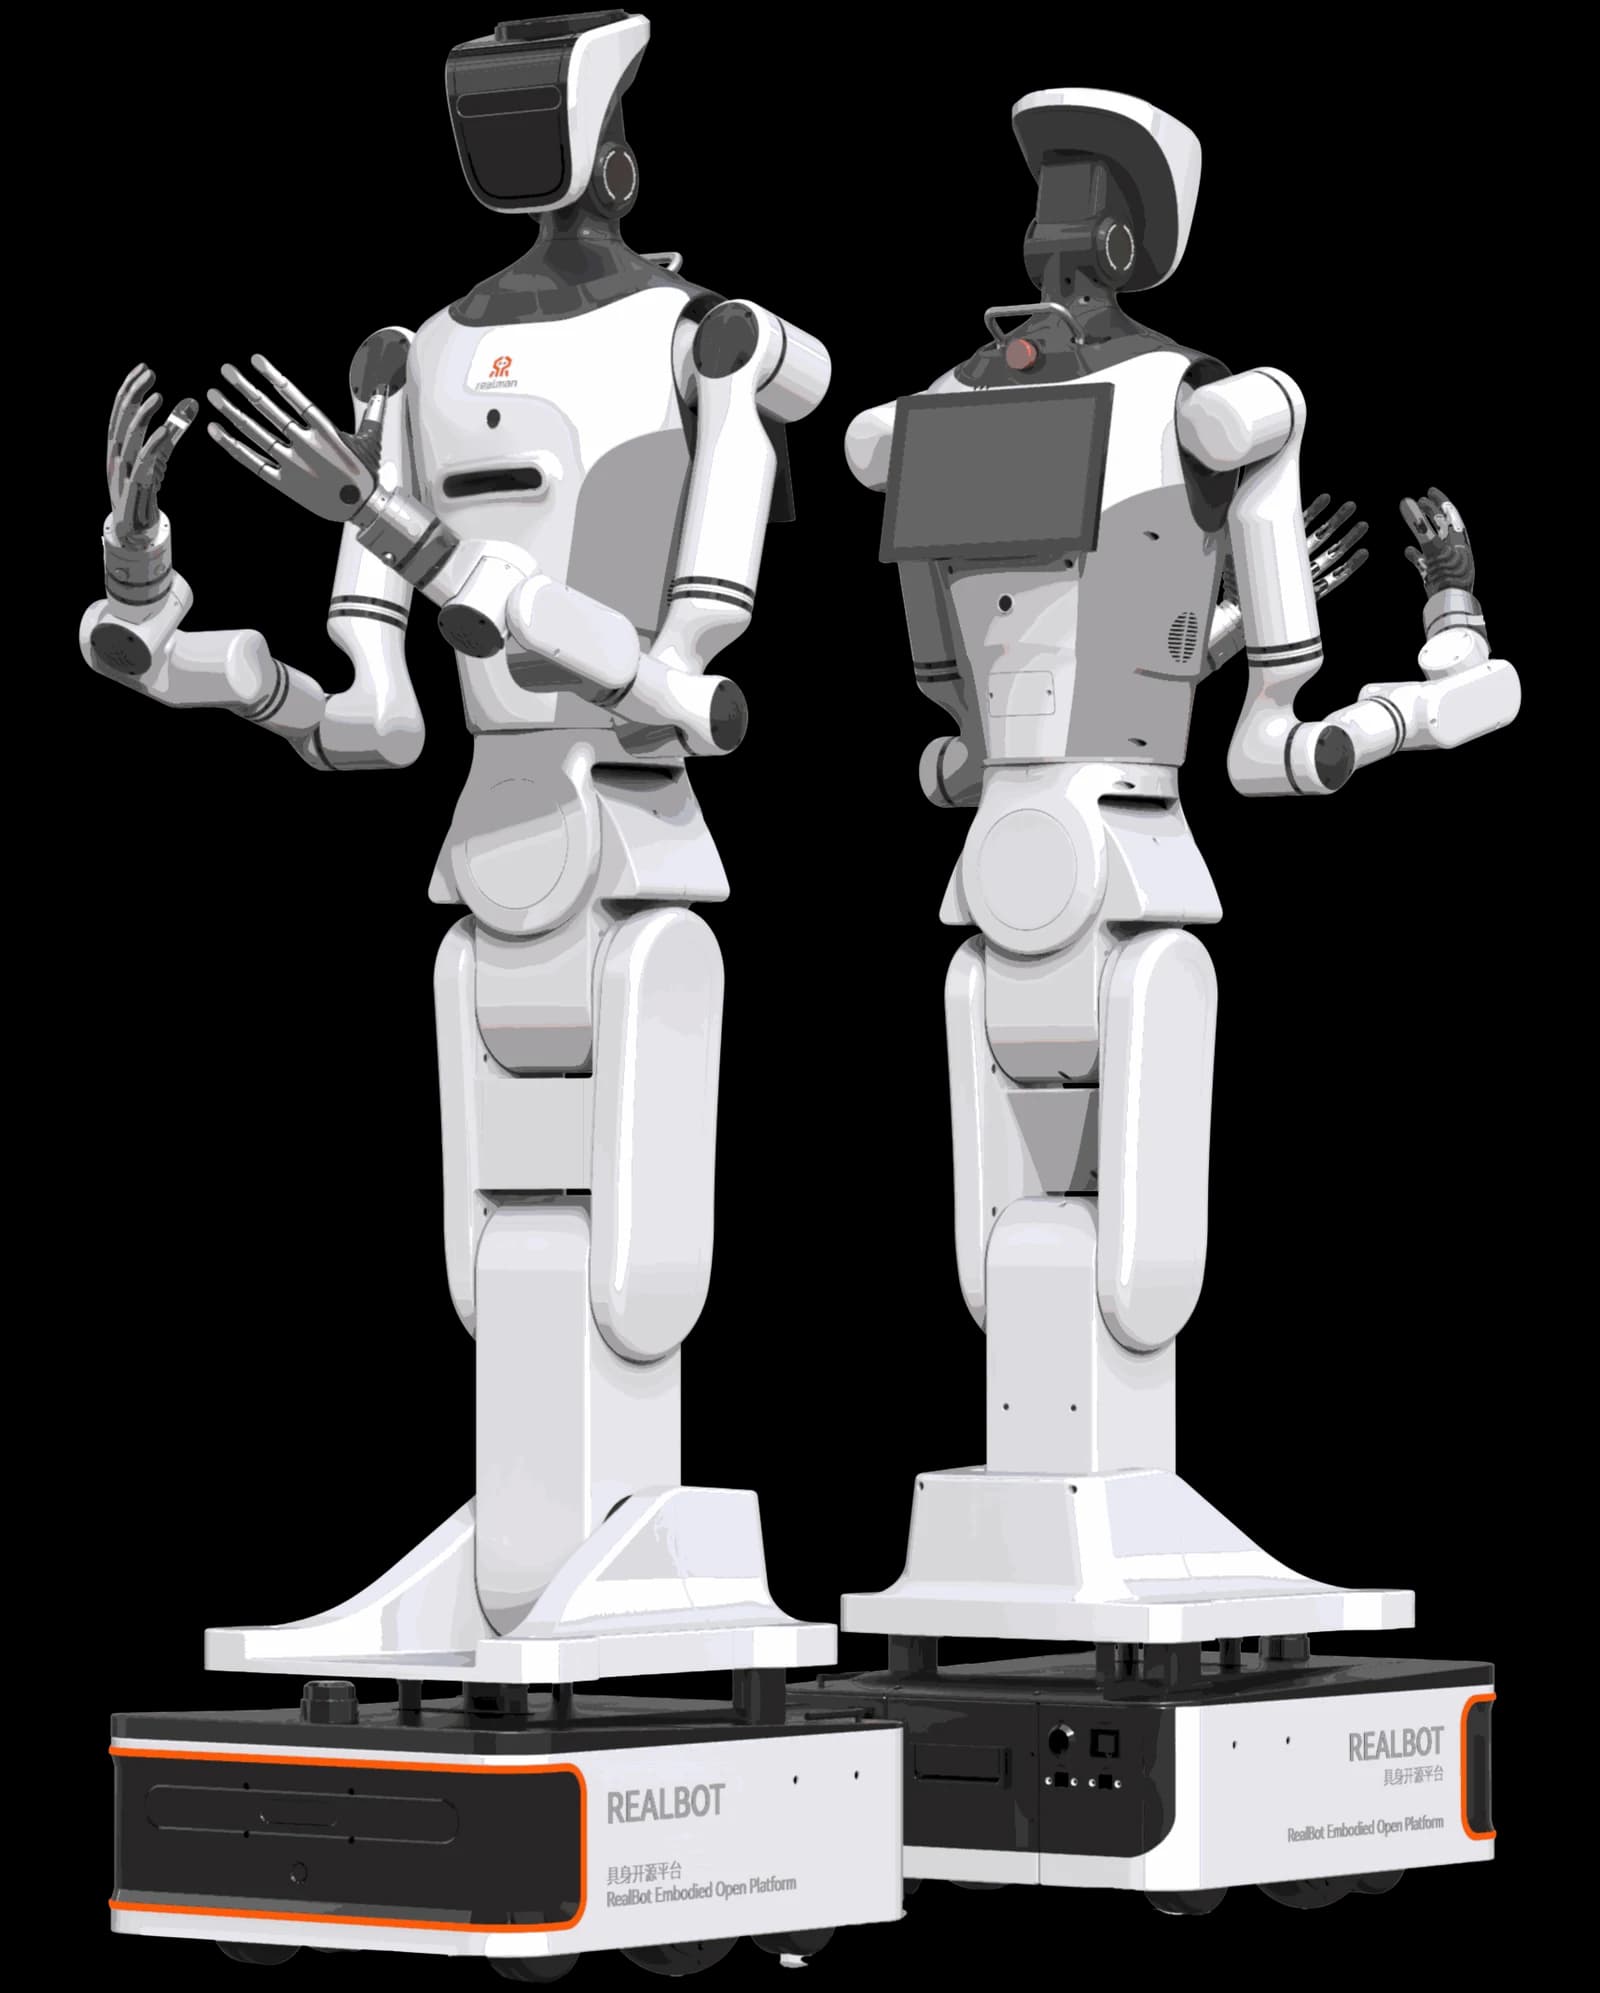
Wheeled Humanoid Robot (Separable Base, Dual-Arm)
The RealMan RealBot-01 is a wheeled humanoid robot with 21 active degrees of freedom that combines a separable wheeled base with a humanoid upper body in one system.
The 570 × 465 × 1680 mm body weighs approximately 125 kg; each of the two RX75 arms carries 5 kg, vertical reach is 2100 mm and horizontal reach 1818 mm without end-effector. Five depth cameras, three fisheye cameras, a LiDAR, two IMUs and a microphone array give it 3D reconstruction, obstacle detection, object and gesture recognition, autonomous navigation and sound source localization; it is designed for AI training and data collection, retail, education and industrial production lines.
Enterprise supply · specification support · integration engineering
The RealBot-01 is the wheeled humanoid robot of Beijing-based RealMan Robotics and carries the company's own joint modules and RX75 arms onto a humanoid body. The architecture has two parts: a wheeled mobility base and an upper body of head, arms and torso. Together they work as a complete robot; the upper body can be detached from the base and mounted on other chassis models or combined with RealMan's dual-arm platforms.
The body measures 570 × 465 × 1680 mm and weighs approximately 125 kg. Of the 21 active degrees of freedom, 14 sit in the two arms; the waist carries 3 axes, the legs 2 and the neck 2. Each 7-axis RX75 arm carries 5 kg and houses a six-axis force-torque sensor with a 200 N / 7 N·m range; vertical reach is 2100 mm and horizontal reach 1818 mm without end-effector. A multi-DoF dexterous hand or gripper is added to task requirements, with compatibility ready for OYMotion, BrainCo and Zhixing products. The perception package consists of five depth cameras, three 130-degree fisheye cameras on the chest, rear and base, a single-line LiDAR with a range above 40 metres at 90% reflectivity, two IMUs and a head-mounted microphone array; tactile sensors are optional. The system performs 3D reconstruction, obstacle detection, object and gesture recognition, autonomous navigation and sound source localization. Chassis and shoulder width are under 465 mm and the in-place turning radius is 690 mm; travel speed is set between 0.1 and 1.5 m/s and the 40 Ah BMS-supported battery charges in approximately 2 hours. The data collection version ships with the Orbbec 335LG and the standard version with the Intel RealSense D405 camera; the RealSense D435 is optional. RealMan was founded in 2018; with offices in Beijing, Changzhou, Shenzhen, Tokyo and San Francisco it has served more than 8,000 enterprise customers, and its robotic arms run at an MTBF of 50,000 hours. The RealBot-01 is designed for AI training and data collection, retail, education and production lines; it is supplied to Turkey with enterprise supply, commissioning and engineering support.
3 use casesTap the cover to play; sound and loading start only on click.
The manufacturer's official variant matrix; the values are documented data.
| Feature | RealBot-01 Standart | RealBot-01 Veri Toplama |
|---|---|---|
| Version camera | Intel RealSense D405 (D435 opsiyonel) | Orbbec 335LG |
| Body, arms, LiDAR, battery | Aynı | Aynı |
| Quote | Get a Quote for This ModelRealBot-01 Standart | Get a Quote for This ModelRealBot-01 Veri Toplama |
The two versions differ only in camera hardware; the 21-axis body, RX75 arms, LiDAR and 40 Ah battery are shared.
RealBot-01 Standart
Task execution in retail, education and production lines; close-range depth with the RealSense D405.
RealBot-01 Veri Toplama
Real-robot data collection for embodied-AI model training; Orbbec 335LG as standard.
The use cases the manufacturer defines for the RealMan RealBot-01.
The wheeled base and the upper body of head, arms and torso separate.
14 axes in the two arms, 3 in the waist, 2 in the legs and 2 in the neck.
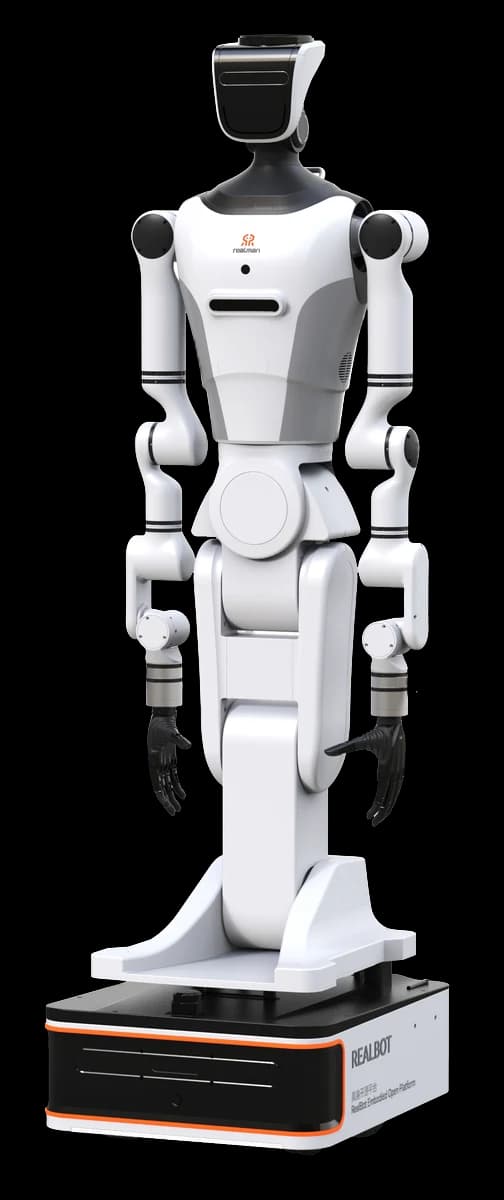
5 depth cameras, 3 fisheye cameras, LiDAR, 2 IMUs, a head-mounted microphone array and optional tactile sensors; 3D reconstruction, object and gesture recognition, autonomous navigation and sound source localization.
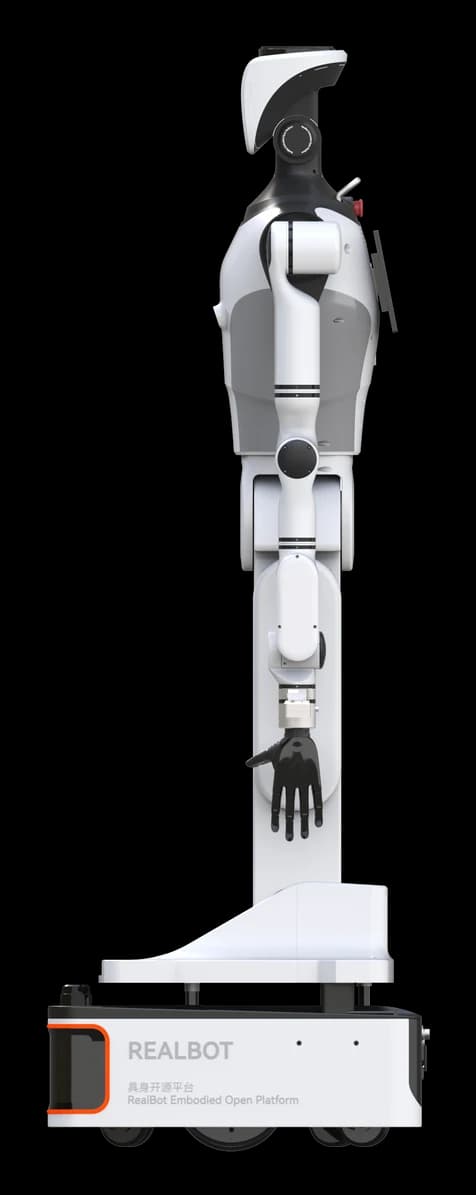
Chassis and shoulder width under 465 mm, in-place turning radius 690 mm.
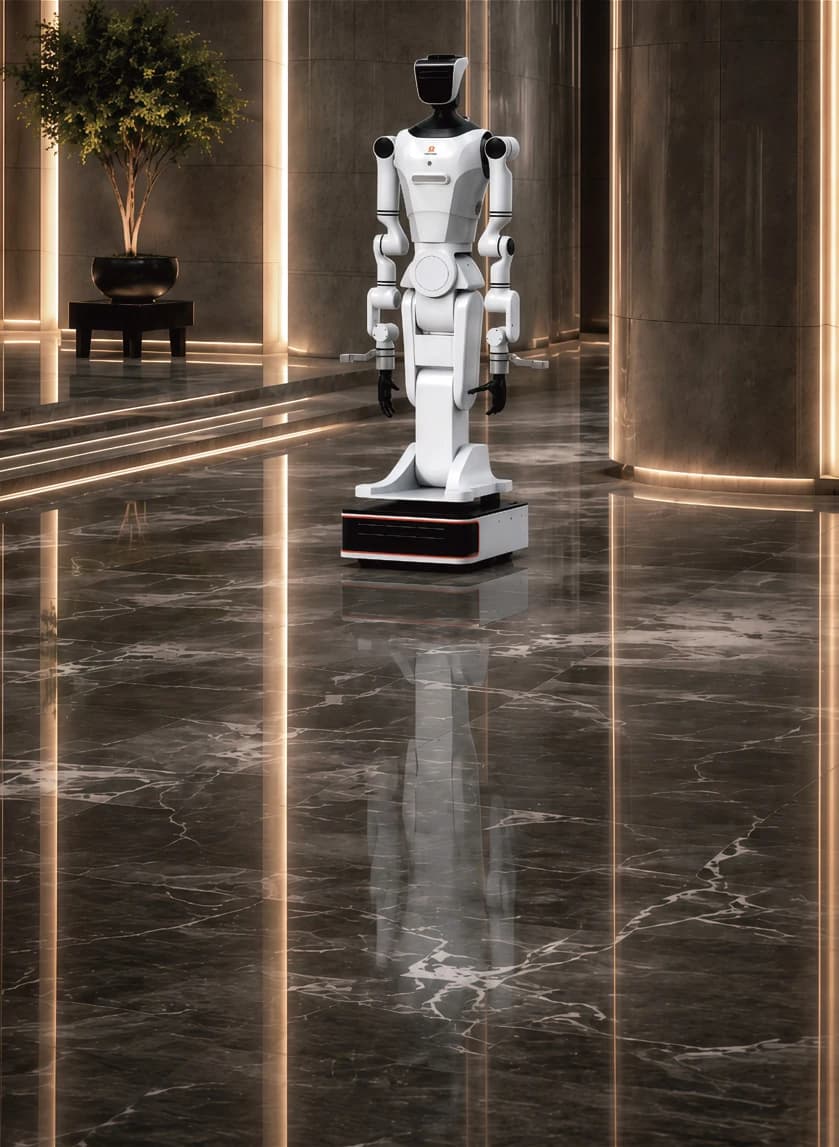
5 images; tap to enlarge.
21 values in 6 categories; data published by the manufacturer.
Verified on the manufacturer page on 18 September 2026.
An itemised quote for the RealMan RealBot-01 is prepared by configuration, quantity and delivery scope.
The RealBot-01 architecture is built from two parts: a wheeled mobility base and a humanoid upper body of head, arms and torso. Together they work as a complete robot; the upper body can be detached from the base and mounted on other chassis models or combined with RealMan's dual-arm platforms. This separation lets the same manipulation hardware be reused across floor and task profiles: on the wheeled base in a store with narrow aisles, bench-mounted at a fixed station. On the production side RealMan draws that flexibility from its own joint-module and arm manufacturing; the RX75, RM75 and RM65 arms fit the RealBot body directly.
There are 21 active axes across the body: 14 in the two arms, 3 in the waist, 2 in the legs and 2 in the neck. The arms are RealMan's 7-axis RX75 series; each carries 5 kg and houses a six-axis force-torque sensor with a 200 N / 7 N·m range and 0.5% full-scale accuracy. That sensor lets contact tasks, such as seating parts, opening doors or grasping soft objects, run under force control rather than position control. Vertical reach is 2100 mm and horizontal reach 1818 mm without end-effector; a multi-DoF dexterous hand or gripper is chosen for the hand, with compatibility ready for OYMotion, BrainCo and Zhixing products.
Five depth cameras, three 130-degree fisheye cameras on the chest, rear and base, a single-line LiDAR with a range above 40 metres at 90% reflectivity, two IMUs and a head-mounted microphone array combine into one perception system; tactile sensors are optional. The package delivers 3D reconstruction, obstacle detection, object and gesture recognition, autonomous navigation and sound source localization. Camera hardware depends on the version: the data collection version ships with the Orbbec 335LG as standard, the standard version uses the Intel RealSense D405, and the RealSense D435 is offered as an option.
Chassis and shoulder width are held under 465 mm and the in-place turning radius is 690 mm. Those dimensions let the robot move through human-scale spaces such as shelf aisles, corridors and the side of a production line without layout changes. Travel speed is set between 0.1 and 1.5 m/s; the 40 Ah BMS-supported battery charges in approximately 2 hours. At 1680 mm tall, shelf-top and bench height are covered by the same body.
The RealBot-01 is sourced for Turkey on a project basis; version choice, hand or gripper configuration, compute and software package, quantity and delivery terms set the corporate quotation. Import, customs clearance, commissioning and engineering support are part of delivery. Request a quotation with your application scenario and target tasks.
| Parameter | Value |
|---|---|
| Robot type | Wheeled humanoid robot; separable base and upper body |
| Overall dimensions | 570 × 465 × 1680 mm |
| Weight | Approx. 125 kg |
| Total active DoF | 21 (arms 14, waist 3, legs 2, neck 2) |
| Arms | 2 × RX75, 7 axes per arm |
| Single arm payload | 5 kg |
| Vertical reach | 2100 mm |
| Horizontal reach | 1818 mm (without end-effector) |
| Turning radius | 690 mm (in-place) |
| Movement speed | 0.1-1.5 m/s |
| Vision system | Stereo depth / RGB; 5 depth cameras, 3 fisheye cameras |
| Wide-angle cameras | 130° FOV × 3 (chest, rear, base) |
| LiDAR | Single-line; detection range over 40 m at 90% reflectivity |
| Voice module | Circular 6-mic smart speaker (optional) |
| Battery | 40 Ah (BMS) |
| Charging time | Approx. 2 hours |
| Version camera | Data collection: Orbbec 335LG; standard: Intel RealSense D405; D435 optional |
| End-effector compatibility | OYMotion, BrainCo and Zhixing grippers and dexterous hands |
The RealBot-01 is the manipulation hardware that arm and joint maker RealMan carries onto a humanoid body: two 7-axis force-sensing RX75 arms, a 21-axis body, a perception package of five depth and three fisheye cameras and narrow-corridor mobility at under 465 mm width. Because the upper body separates from the base, the same investment can serve several chassis and stations. Organisations evaluating it for embodied-AI data collection, production line and retail tasks should state target tasks and version preference in the quotation request.
Supply model
Supply to Turkey is planned per project; import, delivery and commissioning scope are itemised in the quote.
Pre-sales assessment
Site and mission focused technical feasibility; specification and administrative process support.
Demo and site visit request
Send a demo request; availability and scope are settled in the call.
Source documents
Technical values come from the manufacturer's documents; verified on 18 September 2026. 1 documents at the bottom of the page.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
Direct contact and advisory line: 0850 532 6 777
The most common questions about the RealMan RealBot-01.
RealMan Robotics' wheeled humanoid robot with 21 active degrees of freedom: a separable wheeled base, two 7-axis RX75 arms (5 kg per arm), a perception package of five depth and three fisheye cameras, LiDAR and a 40 Ah battery. It is designed for AI training and data collection, retail, education and production lines.
Yes. The upper body of head, arms and torso can be removed from the wheeled base and mounted on other chassis models or combined with RealMan's dual-arm platforms. The same manipulation hardware can alternate between mobile and fixed stations.
Only the camera hardware: the data collection version ships with the Orbbec 335LG and the standard version with the Intel RealSense D405; the RealSense D435 is optional. Body, arms, LiDAR and battery are the same in both versions.
A multi-DoF dexterous hand or gripper is added to task requirements. The robot is compatible with grippers and dexterous hands from OYMotion, BrainCo and Zhixing and with RealMan's RX75, RM75 and RM65 arms.
Chassis and shoulder width are under 465 mm and the in-place turning radius is 690 mm. Designed for shelf aisles, corridors and line-side passages, those dimensions allow installation without changing the store or workshop layout.
It is sourced on a project basis; import, customs clearance, commissioning and engineering support are part of delivery. Investment is set by corporate quotation against version, hand or gripper configuration, quantity and delivery terms. Send your application scenario and target tasks; the quotation follows.


