






























































Wheeled and foldable
Folding legs with ankle and knee axes, 0.3 m lift travel and a four-steer four-drive chassis; 0-2.1 m vertical working range, 1.5 m/s speed, 8-degree climb.
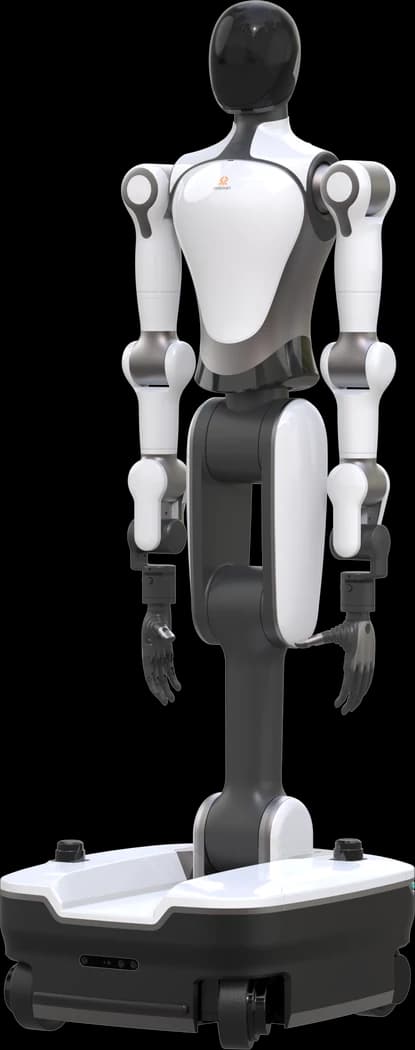
Wheeled Dual-Arm Foldable Humanoid Robot
The RealMan RealBot-S2 is a full-size wheeled humanoid robot with 20 active degrees of freedom whose folding-leg body on a four-steer four-drive chassis covers a 0-2.1 m vertical working range.
The 614 × 552 × 1700 mm body weighs approximately 125 kg; two 7-axis humanoid arms carry 5 kg each, head and waist have two axes apiece, and the legs fold at ankle and knee axes. With 360-degree head vision from a stereo RGB and two fisheye cameras, dual-LiDAR navigation and NVIDIA Jetson AGX Orin 64 GB compute it is built for data collection and training, home service, retail and industrial manufacturing; the 48 V 20 Ah battery gives around 6 hours of operation.
Enterprise supply · specification support · integration engineering
The RealBot-S2 is the full-size wheeled humanoid robot with folding legs in RealMan Robotics' RealBot family. The lower body consists of folding legs with ankle and knee axes and a four-steer four-drive chassis; when the legs fold the arms drop to floor level, when they extend they reach 2.1 m, and a 0.3 m lift travel completes that range. The body measures 614 × 552 × 1700 mm and weighs approximately 125 kg.
Excluding the base and end-effector there are 20 active axes: 7 per arm, pitch and yaw in the head, pitch and yaw in the waist, ankle and knee in the legs. The humanoid-configuration arms carry 5 kg and reach is 0.69 m; each arm houses a six-axis force-torque sensor with a 200 N / 7 N·m range and 0.5% full-scale accuracy, and at the end-effector a two-finger parallel gripper and a five-finger dexterous hand swap quickly. The stereo RGB camera and two fisheye cameras in the head give 360-degree surround vision and an RGB-D camera is standard in the hands; compute runs on an NVIDIA Jetson AGX Orin 64 GB. The chassis moves at 0.1-1.5 m/s, climbs 8 degrees, crosses 20 mm obstacles and runs SLAM navigation and localization with dynamic obstacle avoidance on dual LiDAR. Modules release quickly, and OTA remote operation and maintenance deliver updates without a site visit. The 48 V 20 Ah battery runs around 6 hours in typical use; manual charging, battery swapping and automatic dock charging are supported. Connectivity is wired, Wi-Fi and optional 5G; a built-in microphone array and speaker serve voice interaction, and an optional tablet takes the place of a display. RealMan was founded in Beijing in 2018 and builds its robotic arms on its own joint modules; in 2025 it established Beijing's first humanoid robot data training center. The RealBot-S2 is built for data collection and training, home service, retail and industrial manufacturing; it is supplied to Turkey with enterprise supply, commissioning and engineering support.
4 use casesThe use cases the manufacturer defines for the RealMan RealBot-S2.
Folding legs with ankle and knee axes, 0.3 m lift travel and a four-steer four-drive chassis; 0-2.1 m vertical working range, 1.5 m/s speed, 8-degree climb.
The stereo RGB camera and two fisheye cameras in the head give 360-degree surround vision; dual LiDAR feeds SLAM navigation and dynamic obstacle avoidance, and an RGB-D camera is standard in the hands.
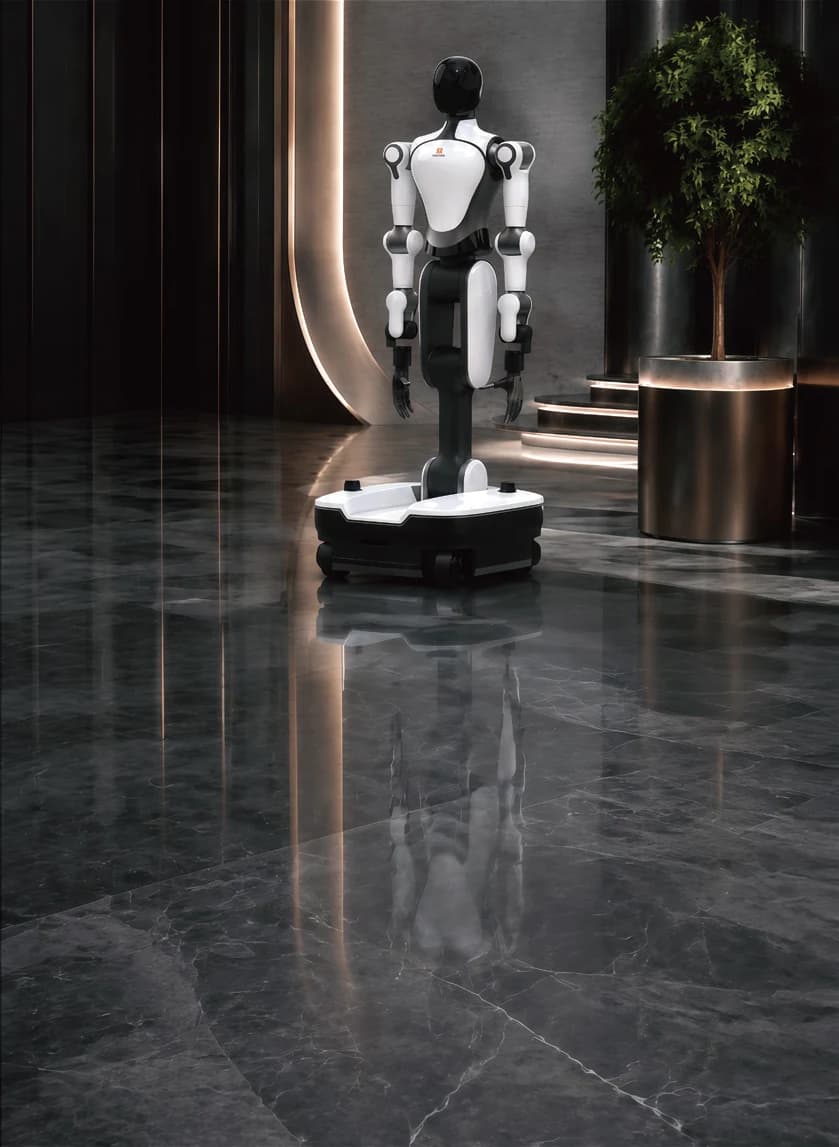
Maintenance and upgrades are done by swapping modules; OTA remote operation and maintenance provide updates and diagnostics without a site visit.
The 48 V 20 Ah battery runs around 6 hours; manual charging, battery swapping or automatic dock charging is chosen.
2 images; tap to enlarge.
26 values in 6 categories; data published by the manufacturer.
Verified on the manufacturer page on 18 September 2026.
An itemised quote for the RealMan RealBot-S2 is prepared by configuration, quantity and delivery scope.
The lower body of the RealBot-S2 consists of folding legs with ankle and knee axes and a four-steer four-drive chassis. When the legs fold the arms drop to floor level and when they extend they reach 2.1 m; a 0.3 m lift travel completes that range. Each of the four wheels both steers and drives, so the robot turns in place and moves sideways; speed is 0.1 to 1.5 m/s, climb capability 8 degrees and obstacle crossing 20 mm. The body measures 614 × 552 × 1700 mm and weighs approximately 125 kg; SLAM navigation and localization with dynamic obstacle avoidance run on dual LiDAR.
Excluding the base and end-effector there are 20 active axes: 7 per arm, pitch and yaw in the head, pitch and yaw in the waist, ankle and knee in the legs. The humanoid-configuration arms carry 5 kg and reach is 0.69 m; each arm houses a six-axis force-torque sensor with a 200 N / 7 N·m range and 0.5% full-scale accuracy. The stereo RGB camera and two fisheye cameras in the head give 360-degree surround vision, and the RGB-D cameras in the hands watch the moment of grasp. Compute runs on an NVIDIA Jetson AGX Orin 64 GB; at the end-effector a two-finger parallel gripper and a five-finger dexterous hand swap quickly.
Modules release quickly; maintenance and upgrades are done by swapping parts, and OTA remote operation and maintenance reduce the need for on-site intervention. The 48 V 20 Ah battery gives around 6 hours of typical operation; charging is manual, the battery can be swapped, or the robot recharges itself at an automatic dock. Connectivity is wired, Wi-Fi and optional 5G; a built-in microphone array and speaker serve voice interaction, and an optional tablet takes the place of a display. These traits move the S2 away from single-robot demonstration and towards data collection and manufacturing deployments where several robots are managed remotely on one site.
The RealBot-S2 is sourced for Turkey on a project basis; camera and end-effector configuration, 5G and automatic charging dock options, quantity and delivery terms set the corporate quotation. Import, customs clearance, commissioning and engineering support are part of delivery. Request a quotation with your use scenario.
| Parameter | Value |
|---|---|
| Robot type | Full-size wheeled dual-arm foldable robot |
| Overall dimensions | 614 × 552 × 1700 mm |
| Weight | Approx. 125 kg |
| Vertical working range | 0-2.1 m |
| Lift travel | 0.3 m |
| Total DoF | 20 (excluding base and end-effector) |
| Head / waist / legs | 2 (pitch, yaw) / 2 (pitch, yaw) / 2 (ankle, knee) |
| DoF per arm | 7 |
| Rated payload per arm | 5 kg |
| Reach | 0.69 m (without end-effector) |
| Force-torque sensor | 200 N / 7 N·m; 0.5% FS |
| End-effector | Two-finger parallel gripper / five-finger dexterous hand, quick switching |
| Main processor | NVIDIA Jetson AGX Orin 64 GB |
| Head cameras | 1 stereo RGB + 2 fisheye |
| Hand camera | RGB-D (standard) / monocular RGB (optional) |
| Chassis | Four-wheel steering and drive; 0.1-1.5 m/s; 8° climb; 20 mm obstacle |
| Navigation | SLAM navigation and localization; dynamic obstacle avoidance; dual LiDAR |
| Battery | 48 V 20 Ah |
| Charging method | Manual charging, battery swapping, automatic dock charging |
| Typical runtime | Approx. 6 hours |
| Communication | Wired, Wi-Fi, 5G (optional) |
| Display | None; optional tablet |
The RealBot-S2 is the RealBot family model with a four-steer four-drive chassis and folding legs: with 20 axes it works from floor level up to 2.1 m, reaches 1.5 m/s and navigates on dual LiDAR. Quick-release modules, OTA maintenance, battery swapping and automatic dock charging prepare it for multi-robot data collection and manufacturing deployments. The 5 kg force-torque-sensing arms and gripper-to-dexterous-hand swap also cover retail and household tasks; state charging infrastructure and connectivity preference in the quotation request.
Supply model
Supply to Turkey is planned per project; import, delivery and commissioning scope are itemised in the quote.
Pre-sales assessment
Site and mission focused technical feasibility; specification and administrative process support.
Demo and site visit request
Send a demo request; availability and scope are settled in the call.
Source documents
Technical values come from the manufacturer's documents; verified on 18 September 2026. 1 documents at the bottom of the page.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
Direct contact and advisory line: 0850 532 6 777
The most common questions about the RealMan RealBot-S2.
RealMan Robotics' full-size wheeled humanoid robot with folding legs: 20 active degrees of freedom, two 7-axis arms (5 kg per arm), a 0-2.1 m vertical working range, a four-steer four-drive chassis, an NVIDIA Jetson AGX Orin 64 GB and around 6 hours of runtime. It is built for data collection and training, home service, retail and industrial manufacturing.
When the ankle- and knee-axis legs fold the arms drop to floor level, and when they extend they reach 2.1 m; a 0.3 m lift travel completes the range. One robot can therefore handle a box on the floor and a product on the top shelf in the same task.
There are three paths: manual charging, battery swapping and automatic dock charging. The 48 V 20 Ah battery runs around 6 hours in typical use; on multi-robot sites battery swapping and the automatic dock provide continuous shifts.
Yes. OTA remote operation and maintenance handle software updates and diagnostics without a site visit; connectivity is wired, Wi-Fi and optional 5G. Quick-release modules reduce hardware maintenance to part replacement.
At the end-effector a two-finger parallel gripper and a five-finger dexterous hand swap quickly. Each arm houses a six-axis force-torque sensor with a 200 N / 7 N·m range and 0.5% full-scale accuracy; payload per arm is 5 kg.
It is sourced on a project basis; import, customs clearance, commissioning and engineering support are part of delivery. Investment is set by corporate quotation against camera and end-effector configuration, 5G and charging dock options, quantity and delivery terms. Send your use scenario; the quotation follows.


