RM65-B-V arm
A 6-axis RM65-B-V arm with 5 kg payload for precise single-arm manipulation; the RM65 series carries ±0.05 mm repeatability and a 7.2 kg net weight.
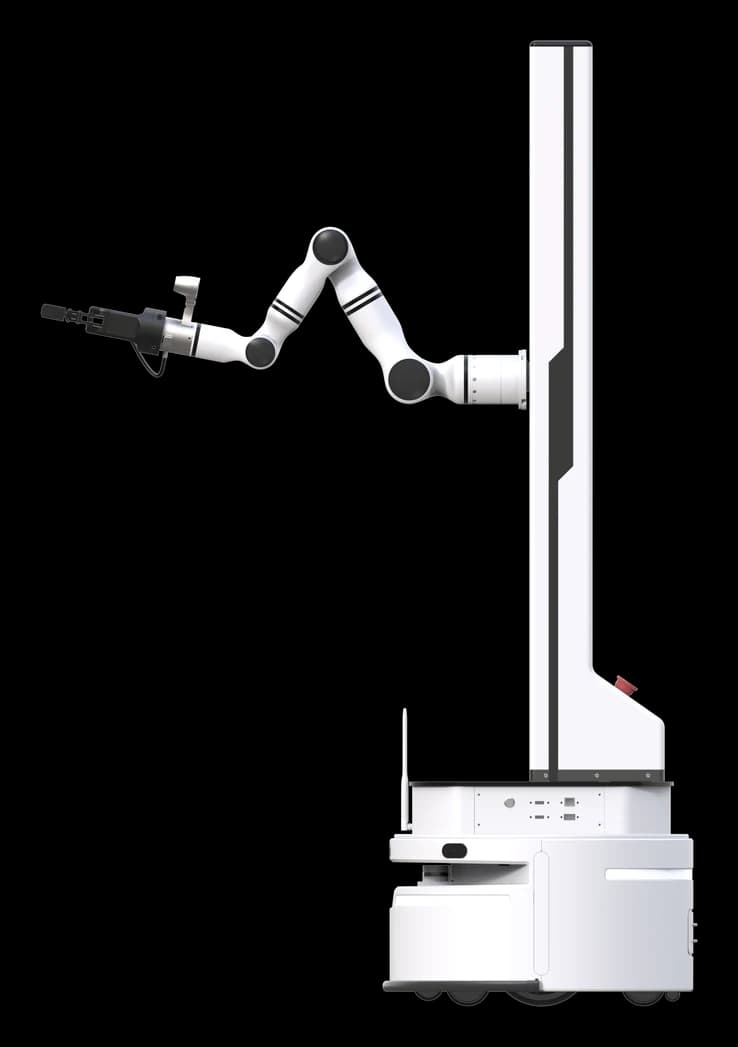
Single-Arm Vertical Lift Mobile Manipulator
The RealMan Single-Arm Lift is a single-arm mobile manipulator that carries a 900 mm lift column and a 6-axis RM65-B-V arm on a 505 mm circular autonomous base.
The arm carries 5 kg; the 1605 mm tall body weighs approximately 100 kg, turns in tight spaces with a 252.5 mm in-place turning radius and travels at 1 m/s. Autonomous SLAM navigation gives positioning accuracy within ±5 cm; with 3 hours of runtime, 100-240 V AC charging and a 5-40 °C operating range it is designed for industrial production, logistics and warehousing, retail, home service, research and education.
Enterprise supply · specification support · integration engineering
The Single-Arm Lift is RealMan Robotics' single-arm vertical lift mobile manipulator and combines the company's RM65 series arm with an autonomous base. Three components come together in one machine: a 505 mm diameter circular base with autonomous navigation, a lift column rising through an effective travel of not less than 900 mm, and a 6-axis RM65-B-V arm on top of the column. Full-body control manages all three in one task plan.
Overall height is 1605 mm and weight approximately 100 kg. The arm carries 5 kg; the RM65 series is built to a 610 mm working radius, 7.2 kg net weight and ±0.05 mm repeatability, and RealMan robotic arms operate at an MTBF of 50,000 hours. The circular base turns in narrow shelf aisles with a 252.5 mm in-place turning radius; travel speed is 1 m/s, autonomous SLAM navigation holds positioning accuracy within ±5 cm and obstacle avoidance relies on LiDAR and vision sensors. Runtime is 3 hours; charging uses a 100-240 V AC 50 Hz supply, the system runs on 24 V DC and the operating temperature range is 5 to 40 °C. On the development side the JSON and Modbus protocols, C, C++, C# and Python SDKs and ROS and ROS 2 packages are used. RealMan is a maker of lightweight robotic arms and joint modules founded in Beijing in 2018; it added lifting robots to its range in 2021 and has served more than 8,000 enterprise customers. The Single-Arm Lift is designed for industrial production, logistics and warehousing, retail, home service, research and education; it is supplied to Turkey with enterprise supply, commissioning and engineering support.
3 use casesThe use cases the manufacturer defines for the RealMan Single-Arm Lift.
A 6-axis RM65-B-V arm with 5 kg payload for precise single-arm manipulation; the RM65 series carries ±0.05 mm repeatability and a 7.2 kg net weight.
An effective lift travel of not less than 900 mm gives flexible height adjustment for multi-level operation; the vertical workspace expands markedly.
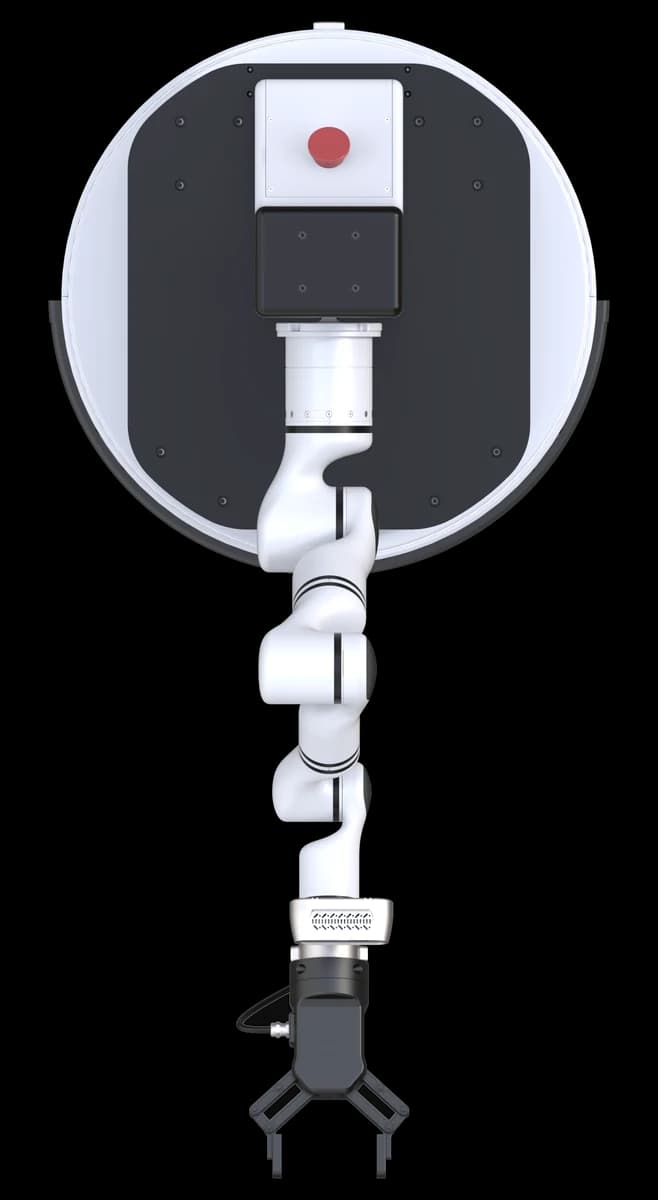
The 505 mm omnidirectional base turns in tight spaces with a 252.5 mm in-place turning radius; 1 m/s speed, 100 kg body.
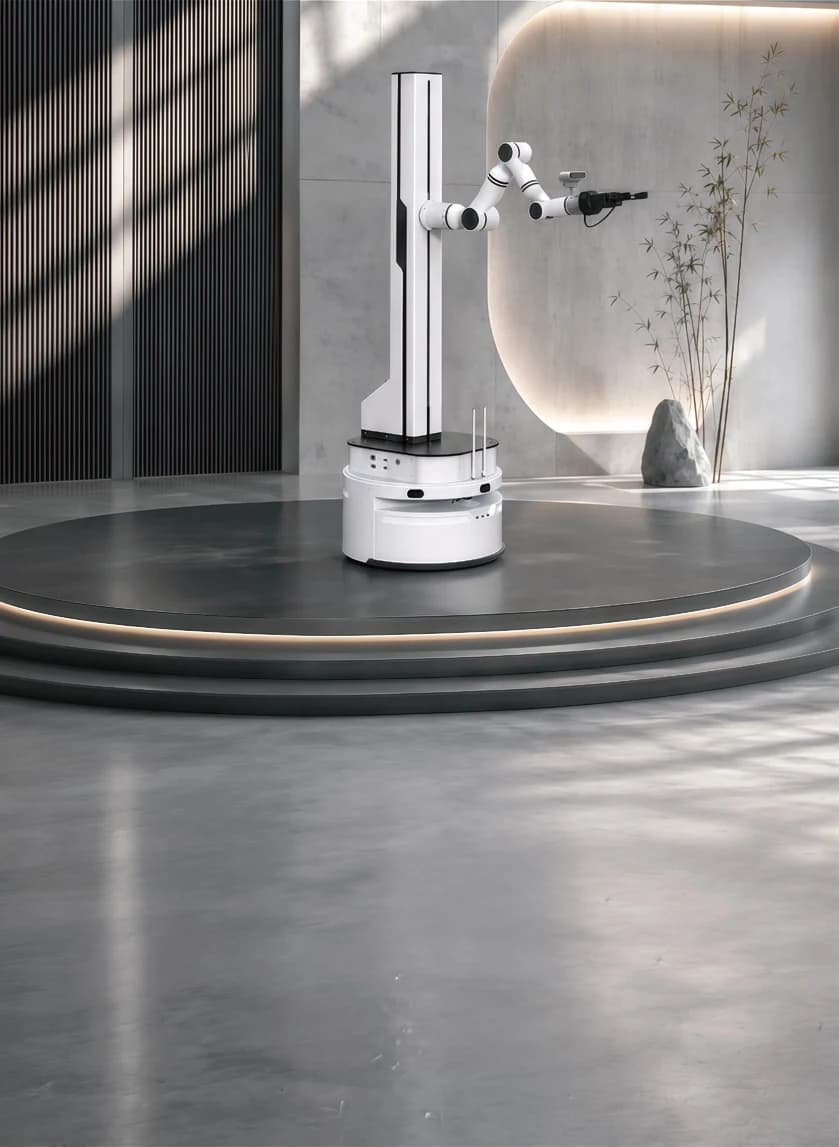
Autonomous SLAM path planning gives positioning accuracy within ±5 cm; 3 hours of runtime.
3 images; tap to enlarge.
25 values in 7 categories; data published by the manufacturer.
Verified on the manufacturer page on 18 September 2026.
An itemised quote for the RealMan Single-Arm Lift is prepared by configuration, quantity and delivery scope.
The Single-Arm Lift brings three components into one machine: a 505 mm diameter circular base with autonomous navigation, a lift column rising through an effective travel of not less than 900 mm, and a 6-axis RM65-B-V arm on top of the column. Full-body control manages all three in one task plan; the robot drives to the shelf, raises the column to the target height and the arm handles the object. Overall height is 1605 mm and weight approximately 100 kg. The circular base and 252.5 mm in-place turning radius allow turns in narrow shelf aisles.
The arm on the platform comes from RealMan's RM65 series: a 6-axis humanoid configuration, 5 kg payload, 610 mm working radius, 7.2 kg net weight and ±0.05 mm repeatability. The arm's 7.2 kg weight keeps the load on the lift column low; the system runs on 24 V DC. RealMan robotic arms operate at an MTBF of 50,000 hours, and the same arm series is used on the company's dual-arm lift platform.
The base maps and plans routes with autonomous SLAM; positioning accuracy is within ±5 cm and travel speed is 1 m/s. Runtime is 3 hours; charging uses a 100-240 V AC 50 Hz supply and the operating temperature range is 5 to 40 °C. Those values place the platform in enclosed, flat-floored spaces such as retail and logistics.
The Single-Arm Lift is sourced for Turkey on a project basis; gripper and sensor configuration, quantity and delivery terms set the corporate quotation. Import, customs clearance, commissioning and engineering support are part of delivery. Request a quotation with your shelf layout and target tasks.
| Parameter | Value |
|---|---|
| Robot type | Vertical lift single-arm mobile robot |
| Overall dimensions | Height 1605 mm; diameter 505 mm |
| Weight | Approx. 100 kg |
| Arm model | RM65-B-V (6 axes) |
| Arm payload | 5 kg |
| Effective lift travel | Not less than 900 mm |
| Travel speed | 1 m/s |
| Turning radius | 252.5 mm (in-place rotation) |
| Positioning accuracy | Within ±5 cm |
| Navigation | Autonomous SLAM |
| Battery runtime | 3 hours |
| Charging supply | 100-240 V AC 50 Hz |
| Working voltage | 24 V DC |
| Operating environment | 5-40 °C |
| Core capability | Full-body control; precise single-arm manipulation |
The Single-Arm Lift is RealMan's simplest mobile manipulator, combining the company's arm and joint manufacturing with an autonomous base: a 6-axis 5 kg RM65-B-V arm, 900 mm lift travel, a 505 mm circular base and SLAM navigation accurate to ±5 cm. It is sized for single-arm pick-and-place in narrow shelf aisles and transfer between stations; its 3-hour runtime is managed by placing a charging window in the shift plan. Organisations evaluating it for retail and logistics tasks that do not need two arms should state shelf heights and object types in the quotation request.
Supply model
Supply to Turkey is planned per project; import, delivery and commissioning scope are itemised in the quote.
Pre-sales assessment
Site and mission focused technical feasibility; specification and administrative process support.
Demo and site visit request
Send a demo request; availability and scope are settled in the call.
Source documents
Technical values come from the manufacturer's documents; verified on 18 September 2026. 1 documents at the bottom of the page.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
Direct contact and advisory line: 0850 532 6 777
The most common questions about the RealMan Single-Arm Lift.
RealMan Robotics' single-arm vertical lift mobile manipulator: a 505 mm autonomous circular base, a 900 mm lift column and a 6-axis RM65-B-V arm carrying 5 kg. Height 1605 mm, weight approximately 100 kg; SLAM navigation gives positioning accuracy within ±5 cm.
The lift column moves through an effective travel of not less than 900 mm; together with that travel the RM65 arm with its 610 mm working radius covers heights from near floor level to the top shelf. Target shelf heights are assessed together with the layout at the quotation stage.
Yes. The 505 mm circular base turns with a 252.5 mm in-place turning radius and changes direction in any aisle wider than the base diameter. Travel speed is 1 m/s.
Runtime is 3 hours; charging uses a 100-240 V AC 50 Hz supply and the system runs on 24 V DC. All-day use is arranged by adding a charging window to the shift plan; the operating temperature range is 5-40 °C.
The Single-Arm Lift is more compact with one RM65-B-V arm, a 505 mm circular base, 1 m/s speed and 3 hours of runtime. The Dual-Arm Lift has two RM65-B-V arms (RM75-B-V optional), a 640 × 450 × 1780 mm body, 0-2400 mm vertical reach, 1.5 m/s speed, 3-4 hours of runtime and wired teleoperation for bimanual tasks and data collection.
It is sourced on a project basis; import, customs clearance, commissioning and engineering support are part of delivery. Investment is set by corporate quotation against gripper and sensor configuration, quantity and delivery terms. Send your shelf layout and target tasks; the quotation follows.