What Is the Booster SDK and Which Robots Does It Support?
The repository is at BoosterRobotics/booster_robotics_sdk. According to the README, the package contains the C++ SDK; the Python SDK is distributed separately as a pip package. The licence is Apache-2.0 and the communication layer is built on fastDDS. The B1 prefix in example file names comes from the SDK's class names (such as B1LocoClient); the same client is used with today's product family.
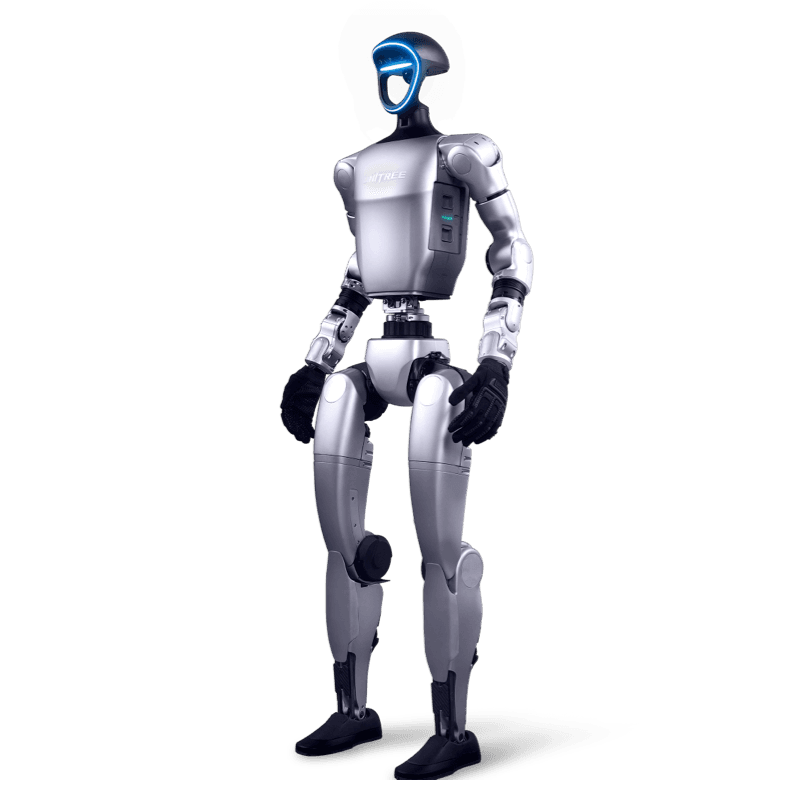
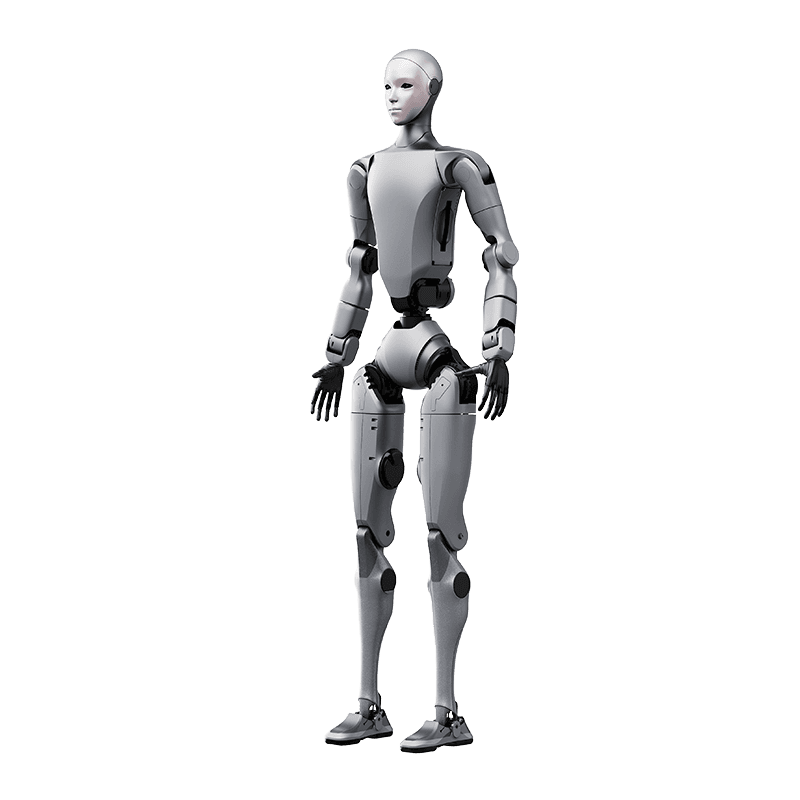
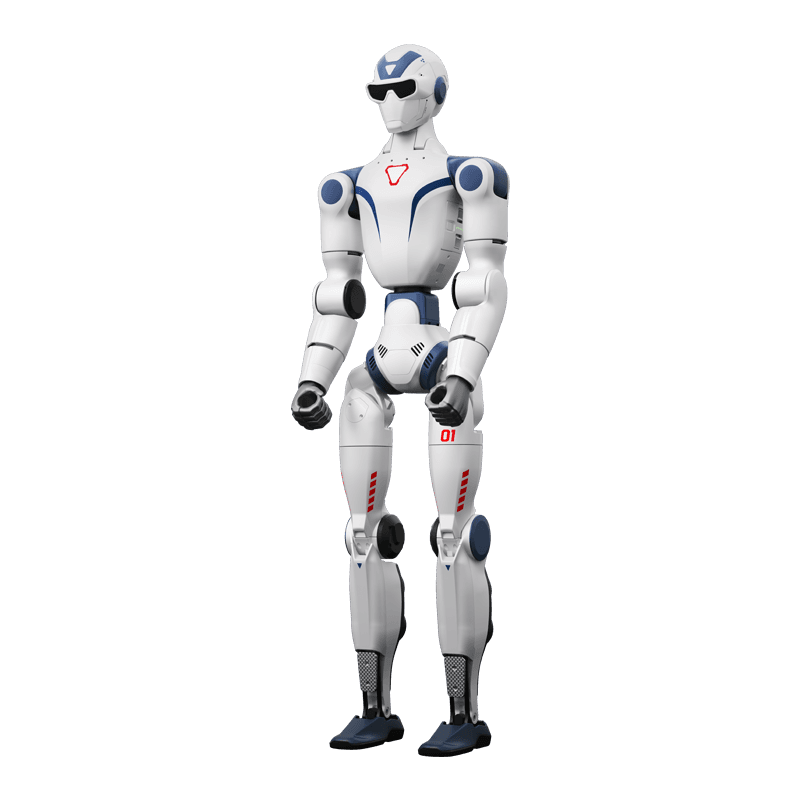
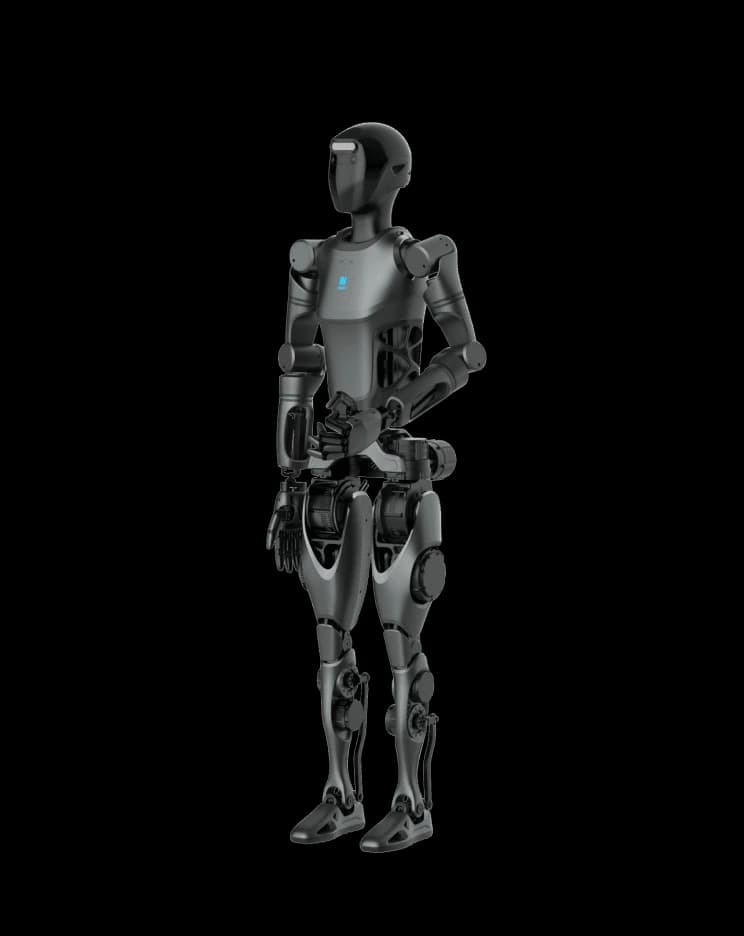
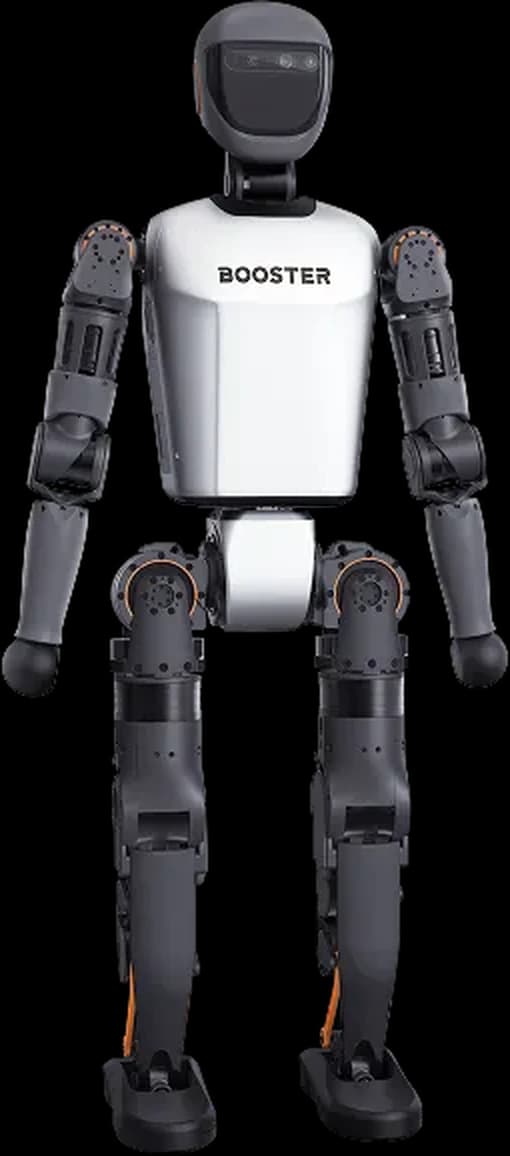
The SDK header defines the robot modes explicitly and lists the K1 and T1 as the supported models for soccer mode (kSoccer). Our product records note that the T1, K1 and T2 share one software stack; for commands specific to the T2's hand and arm capabilities, the documentation shipped with the robot is the reference.
Installation (Ubuntu 22.04, C++ and Python)
Prerequisites from the README: Ubuntu 22.04 LTS, an aarch64 or x86_64 processor, gcc 11.4.0. Dependencies are installed with the script at the repository root, and the examples build with CMake:
sudo ./install.sh
mkdir build
cd build
cmake ..
make
./b1_loco_example_client 127.0.0.1
For Python, the SDK installs with pip:
pip install booster_robotics_sdk_python --userThe example client takes one argument, the network interface; when running on the robot's own computer, use 127.0.0.1. From an external development machine, pass the address of the interface on the robot's network.
First Motion Command: Walking and Arm Control
High-level control goes through the B1LocoClient class. The flow has three steps: start the DDS channel factory, start the client, switch the robot to a suitable mode and send commands. The core of the b1_loco_example_client.cpp example in the repository:
booster::robot::ChannelFactory::Instance()->Init(0, "127.0.0.1");
booster::robot::b1::B1LocoClient client;
client.Init();
client.ChangeMode(booster::robot::RobotMode::kPrepare);  // stand ready on two feet
client.ChangeMode(booster::robot::RobotMode::kWalking);  // walking mode
client.Move(0.2, 0.0, 0.0);                              // vx, vy, vyaw
client.Move(0.0, 0.0, 0.0);                              // stop
Modes in the header: kDamping (all motors in damping mode, the robot may fall), kPrepare (two-foot standing posture before walking), kWalking (locomotion and walking-mode actions), kCustom (body control and custom actions), kSoccer (soccer actions; K1 and T1). The client also offers ready behaviours such as RotateHead, WaveHand, Handshake, LieDown, GetUp, Shoot and Dance; MoveHandEndEffector and MoveDualHandEndEffector for the arms; and ControlGripper and ControlDexterousHand for end effectors. Arm examples are in the repository as b1_arm_sdk_example and, for the 7-axis arm, b1_7dof_arm_sdk_example.
Low-Level Control: DDS Topics
For joint-level work, the SDK offers data channels published over fastDDS. The main topics defined in the headers:
- rt/low_state: joint and IMU state
- rt/joint_ctrl: joint commands
- rt/odometer_state: odometry
- rt/fall_down: fall state
- rt/booster_hand_data: hand data
The low_level_subscriber, low_level_publisher, battery_state_subscriber and odometer_example examples in the repository show how to subscribe to these channels and publish commands. Read the safety section below before sending joint commands.
Using ROS 2
Booster publishes the booster_robotics_sdk_ros2 repository for ROS 2. Its booster_ros2_interface package carries message and service definitions: messages such as LowState and LowCmd, MotorState and MotorCmd, ImuState, Odometer, FallDownState, HandCommand and RemoteControllerState, plus the RpcService and AgentService services. The package is defined with ament_cmake and built with colcon build; the repository also has a booster_ros2_example folder.
According to the booster_deploy README, the interface comes pre-installed on the robot and is loaded with the /opt/booster/BoosterRos2Interface/install/setup.bash script. The robocup_demo match software also uses ROS 2 Humble packages.
What Is Booster Studio?
Booster Studio is the integrated development environment Booster Robotics introduced in June 2026. By the maker's description it brings agent development, Vibe Coding, simulation and debugging, and deployment to a physical robot into one environment; the T2's product record also lists integrated development through Booster Studio. The robocup_demo README notes that a ready layout file can be imported into Booster Studio to inspect the match software's logs, and that the software can be run in the Booster Studio simulator. For a detailed feature list and release notes, the documentation shipped with the robot is the reference.
Safety: Mode Changes and Joint Control
- Damping mode drops the robot: The header states plainly that the robot may fall in kDamping. Put the robot on a gantry or support before switching to it.
- Start and finish in the ready posture: The booster_gym deployment document asks you to put the robot in ready (PREP) mode and stand it stably on the ground before running a policy, and to switch back to PREP before closing the program, so control is released safely.
- Do not copy gains from simulation: The booster_deploy README notes that on parallel-actuated joints the damping (Kd) value goes straight to the motor, so the training-simulator value must be recalculated.
- Software version: Features such as deployment and vision-based kicking require a minimum robot software version; check the version requirement in the READMEs before installing.
- Area and personal safety: Run first trials in an empty, flat, marked area with the emergency stop within reach.
SDK Training and Integration Support in Turkey
Robotlar.org is an authorized distributor of Booster Robotics products in Turkey. With T1, K1 and T2 deliveries, SDK and ROS 2 setup, first-motion and low-level control training, policy transfer with Booster Gym and robocup_demo setup for RoboCup teams are delivered on site in Turkey; a 1-year warranty and authorized service are included. For the ordering steps see the Booster buying guide, for reinforcement learning the Booster Gym guide, and for model choice the Booster Robotics authorized distributor in Turkey page.