What Is Booster Gym?
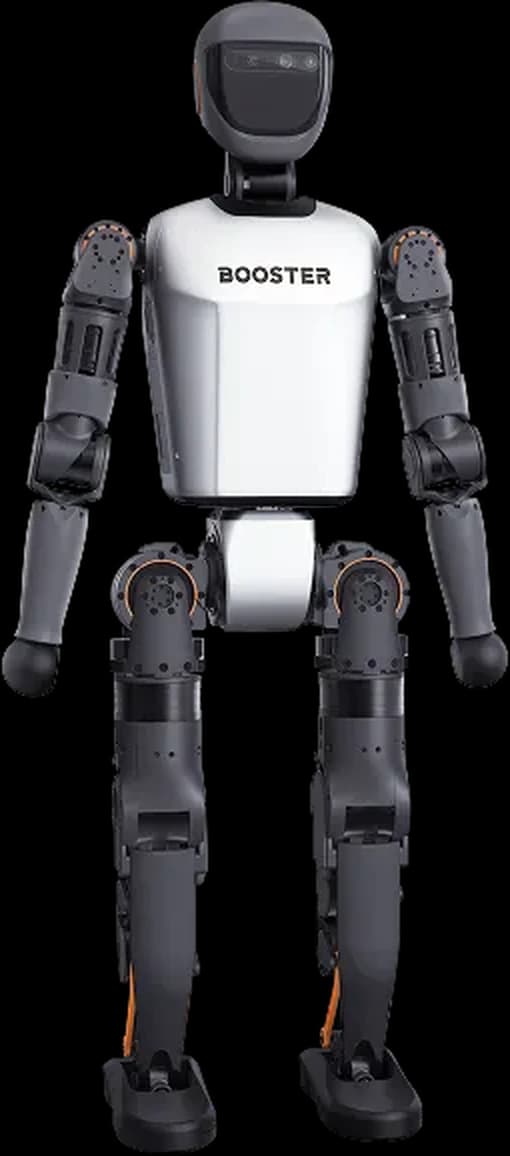
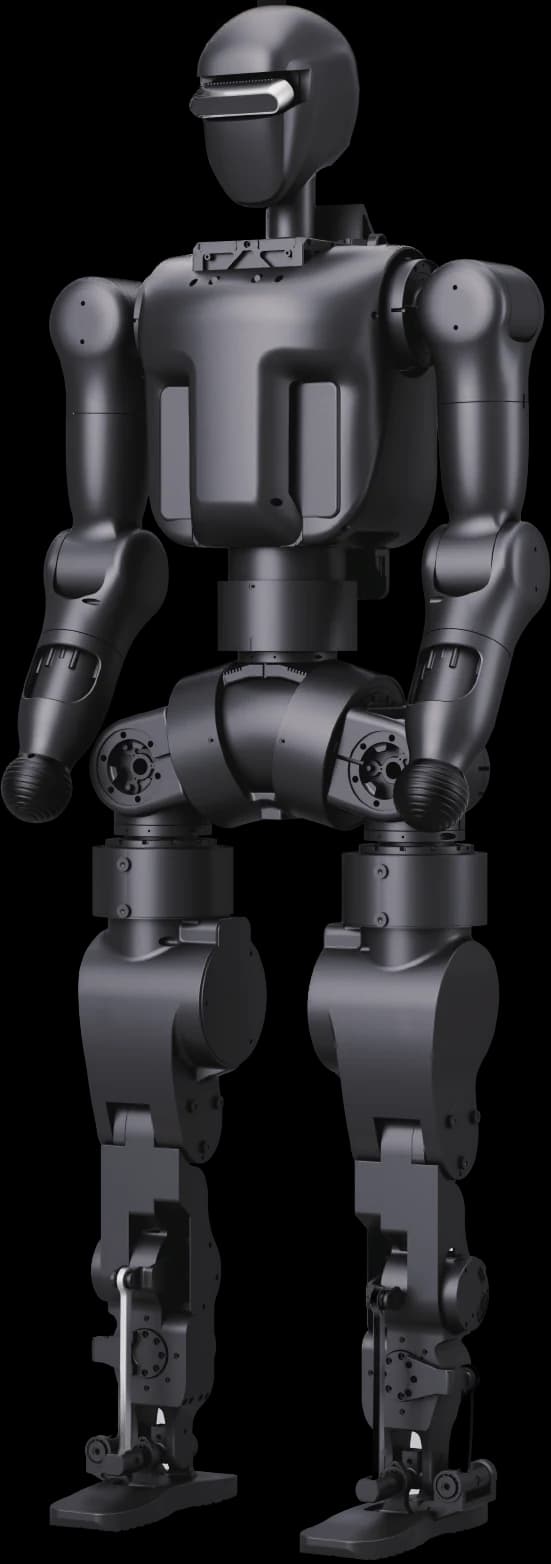
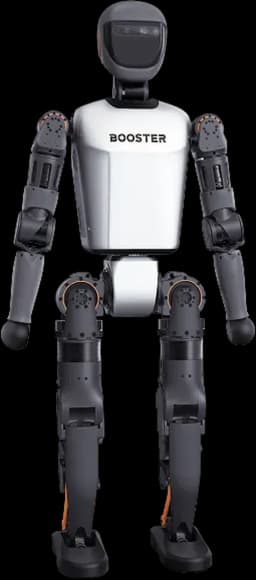
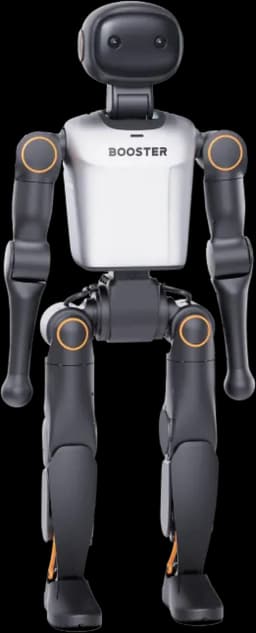
booster_gym brings a full pipeline from training to deployment into one repository. The four features its README highlights: an end-to-end flow covering training, evaluation and deployment; settings and techniques that narrow the gap between simulation and reality; customisable environments and algorithms; and a ready configuration for the Booster T1. The paper describing the framework is published on arXiv as 2506.15132. As of October 2026 the repository has about 305 stars on GitHub.
Installation and Requirements
The installation steps in the README:
- Create a conda environment with Python 3.8.
- Install PyTorch with CUDA support (README: numpy 1.21.6, pytorch 2.0, pytorch-cuda 11.8).
- Download Isaac Gym Preview 4 from NVIDIA's site and install it with
pip install -e .in the isaacgym/python folder; if libpython3.8 cannot be found, add the LD_LIBRARY_PATH setting to the conda environment's activation script. - Install the remaining dependencies with
pip install -r requirements.txt.
Isaac Gym needs a CUDA-capable NVIDIA GPU. Plan the training computer separately from the robot: the robot's on-board compute is for running the policy, while training with thousands of parallel environments needs a desktop or server GPU.
The Training Loop: Train, Play, Sim2Sim, Sim2Real
1. Training. Settings are read from envs/<task>.yaml; logs and models are written under logs/<date-time>/.
python train.py --task=T1The main settings you can override from the command line: --num_envs (number of environments), --headless (no viewer window), --checkpoint (-1 for the latest model), --sim_device and --rl_device (e.g. cuda:0), --seed and --max_iterations. Progress is tracked with TensorBoard; Weights & Biases is also supported and can be turned off in the config.
2. In-simulation testing. The policy runs in the training environment and a video is saved to the videos/ folder:
python play.py --task=T1 --checkpoint=-13. Cross-simulation (sim2sim). The policy is tested in MuJoCo to check that it also works in another physics engine:
python play_mujoco.py --task=T1 --checkpoint=-14. Export and deployment (sim2real). The model is exported from .pth to a JIT-optimised .pt; it then runs with the script in the deploy folder, first in Webots and then on the real robot with the same script:
python export_model.py --task=T1 --checkpoint=-1
python deploy.py --config=T1.yaml
deploy.py's --net argument sets the network interface for SDK communication (default 127.0.0.1). Before running on the real robot, put it in PREP mode and stand it stably on the ground; switch back to PREP before closing the program.
Isaac Lab with booster_train
The newer pipeline lives in the booster_train repository. According to its README it follows the standard Isaac Lab project structure, is tested with IsaacLab 2.3.2 and Isaac Sim 5.1.0, and includes the BeyondMimic motion tracking framework adapted for Booster robots; the supported platforms are the T2, T1 and K1. Motion data comes from the booster_assets repository and is converted from CSV to NPZ with a conversion script.
python scripts/list_envs.py
python scripts/rsl_rl/train.py --task=<TASK> --headless --device cuda:0
python scripts/rsl_rl/play.py --task=<TASK> --checkpoint=<PATH>
play.py exports the trained policy in TorchScript and ONNX formats to an exported folder under logs/rsl_rl/ for deployment on real robots. Booster Gym comes ready for T1 locomotion, while booster_train is the better starting point for teams that want motion tracking tasks on all three bodies, the K1 included.
Deploying to the Real Robot (booster_deploy)
booster_deploy is a lightweight deployment framework that runs the same policy code in MuJoCo (sim2sim) and on a real Booster robot (sim2real); it borrows many of its designs from Isaac Lab. Prerequisites in the README: current robot software for real deployments (the minimum version is in the README), Python 3.10+ and ROS 2 with booster_interface pre-installed on the robot, and optional MuJoCo for local simulation.
python scripts/deploy.py --list
python scripts/deploy.py --task <TASK> --mujoco
# on the robot, over SSH:
source /opt/booster/BoosterRos2Interface/install/setup.bash
python scripts/deploy.py --task <TASK>
The checkpoint file extension selects the inference backend: TorchScript for .pt, .jit and .torchscript, ONNX Runtime for .onnx. An important note in the README: on parallel-actuated joints the damping (Kd) value is sent straight to the motors, so the training-simulator value must not be reused and has to be recalculated for the motor side.
How Does It Differ from Unitree RL Gym?
They are different repositories from different makers, and policies do not transfer directly between their robots. Booster Gym ships ready for the Booster T1 (and booster_train for the T2, T1 and K1); it follows a flow of training in Isaac Gym, sim2sim in MuJoCo and pre-deployment checks in Webots. The Unitree reinforcement learning workflow is written for Unitree robots; we cover it on our RL Gym page and in the Go2 reinforcement learning guide. The concepts (parallel environments, domain randomisation, sim2sim, sim2real) are shared; a method learned in one lab works in the other.
Which Projects Have Run on Booster Bodies?
Customer cases run on the T1 include UC Berkeley's FastTD3 reinforcement learning algorithm, Carnegie Mellon's FALCON framework and Purdue University's table tennis work (Booster's customer case list). Teams using the T1 and K1 at RoboCup also develop their kicking and walking policies with these tools; details are in our humanoid football robot guide.
RL Training and Lab Setup in Turkey
Robotlar.org is an authorized distributor of Booster Robotics products in Turkey. With T1 and K1 deliveries, Booster Gym and booster_train setup, training-computer configuration and sim2sim and sim2real transfer training are delivered on site in Turkey; a 1-year warranty and authorized service are included. For GPU workstation, safety gantry and test area planning see the robotics education lab setup guide, for the SDK side the Booster SDK guide, and for the ordering steps the Booster buying guide.