Industrial Zone Post-Chemical Accident Area Safety Reconnaissance
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Indoor, public area
- Operating mode
- Teleoperation
- Proposed robot
- Unitree AS2
The problem addressed
Fire/AFAD personnel forced to enter toxic zone after chemical accident and loss of life risk.
Draft mission flow
- 1After chemical spill/explosion, robot begins reconnaissance with safe approach from upwind direction to the zone.
- 2Multi gas detector identifies chemical type and concentration; creates spread area map with wind data.
- 3Thermal camera locates trapped personnel in the zone; safe corridor information transmitted to rescue team.
- 4All gas measurement and imagery data transmitted to AFAD and fire department CBRN unit; evacuation boundaries drawn.
Proposed hardware
- Multi Gas Detector (VOC/H2S/NH3/Cl2)
- Thermal Camera
- HD Camera
- IP68 Chemical Resistant Body
- 5G Communication
Proposed software
- Navigation
- Safe reconnaissance navigation considering wind direction in industrial area after chemical accident
- Model
- Chemical Gas Type and Concentration Detection, Wind-Based Spread Area Prediction, and Safe Corridor Calculation
- Integration
- OIZ AFAD Coordination Center and Fire Department CBRN Unit
The robot's real operating limits
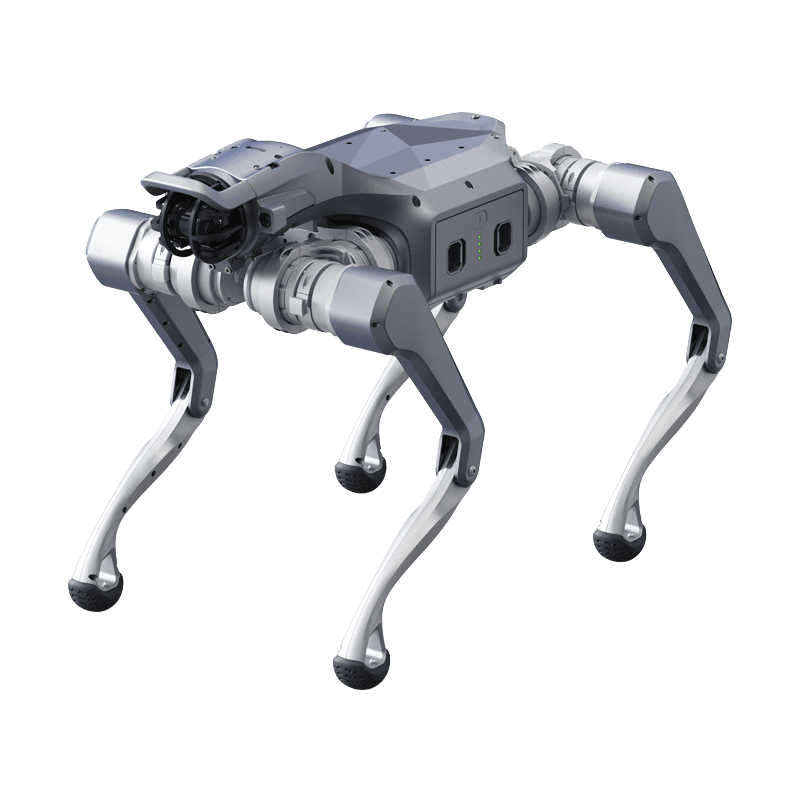
Unitree AS2
Compact industrial robot dog
Product page- Ingress rating
- IP54
- Runtime
- >4 hours (No load)
- Operating temperature
- -20°C to 50°C
- Payload
- Up to 65 kg
- Max speed
- >5 m/s
- Climb
- 40°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.