High-Temperature Press Roll Alignment Control in Paper Mills
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Outdoor field
- Operating mode
- Supervised autonomy
- Proposed robot
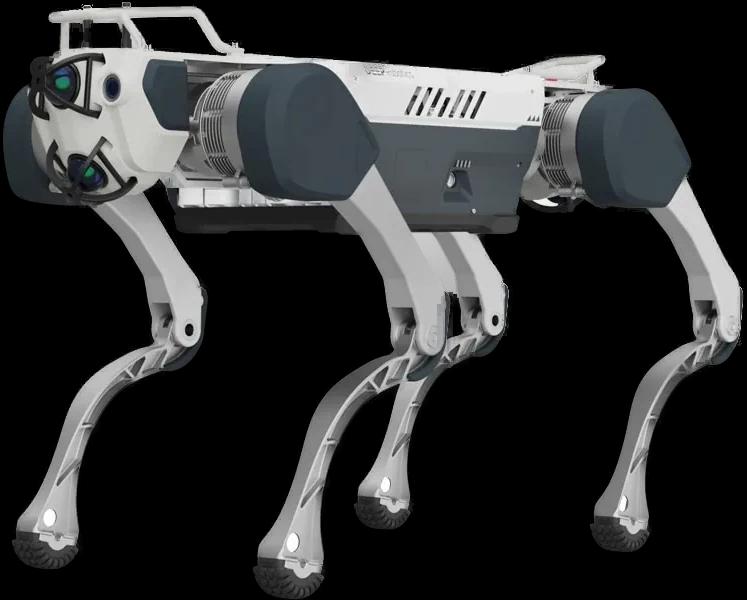
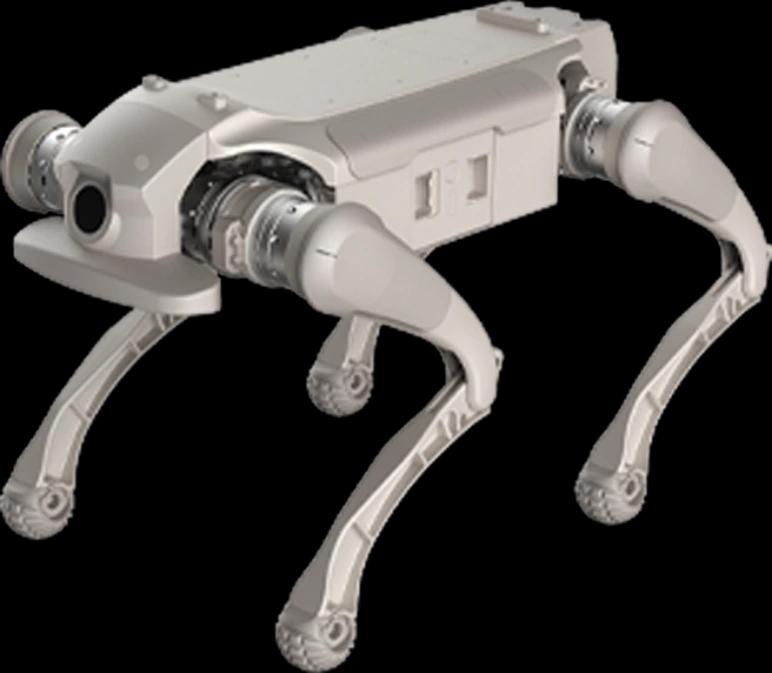
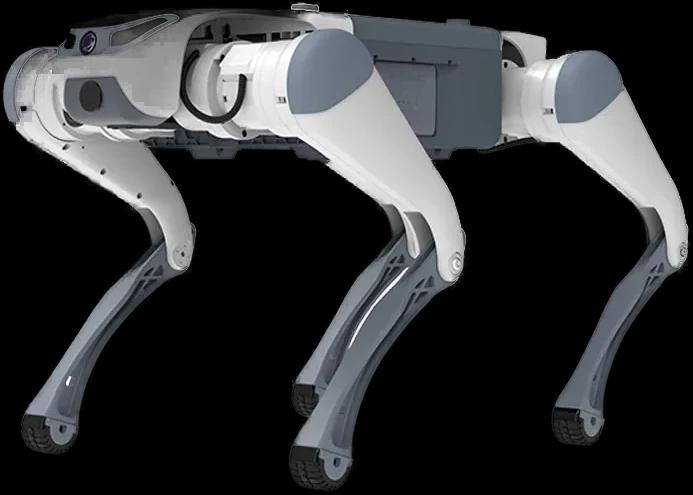
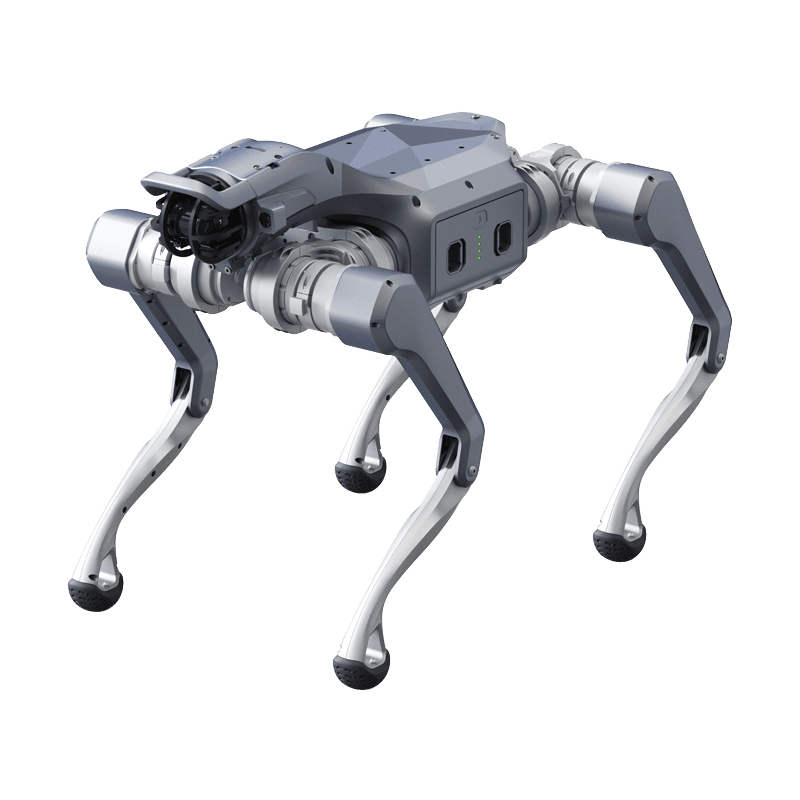
- Unitree A2
The problem addressed
A web break on giant paper reels instantly halts production and forces a full machine cleanout before the line can restart.
Draft mission flow
- 1Fabrikada buharla kuruyan dev kağıt bobin preslerinin arasında titizlik içinde gezer.
- 2Kağıdı ezen sıcak silindirlerin milimetrik hizasındaki (alignment) deviasyonları (kaymayı) lazerle tarar.
- 3Hizası bozulan merdanenin kağıtları yırtıp fabrikayı durdurmasına dakikalar kala merdaneye hidrolik ayar istetir.
Proposed hardware
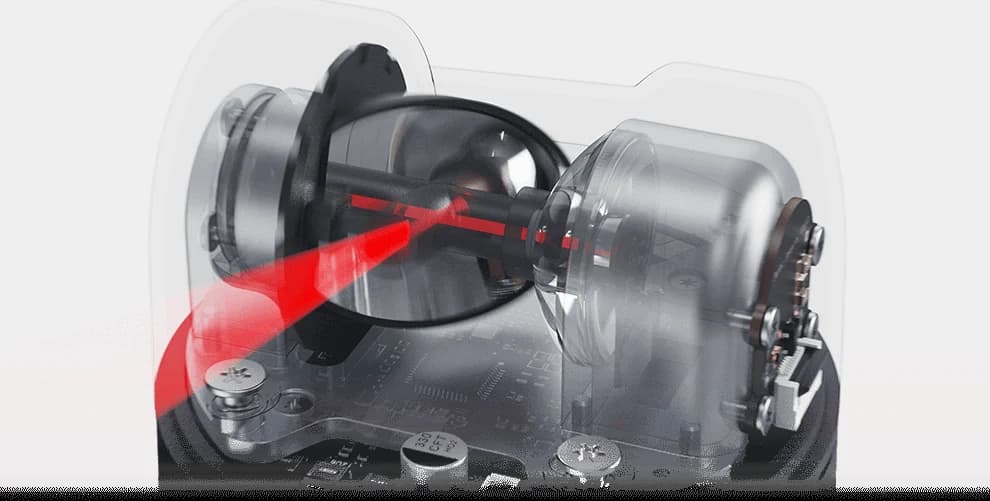
- Çift Eksensel (Dual-Axis) Lazer Ölçer
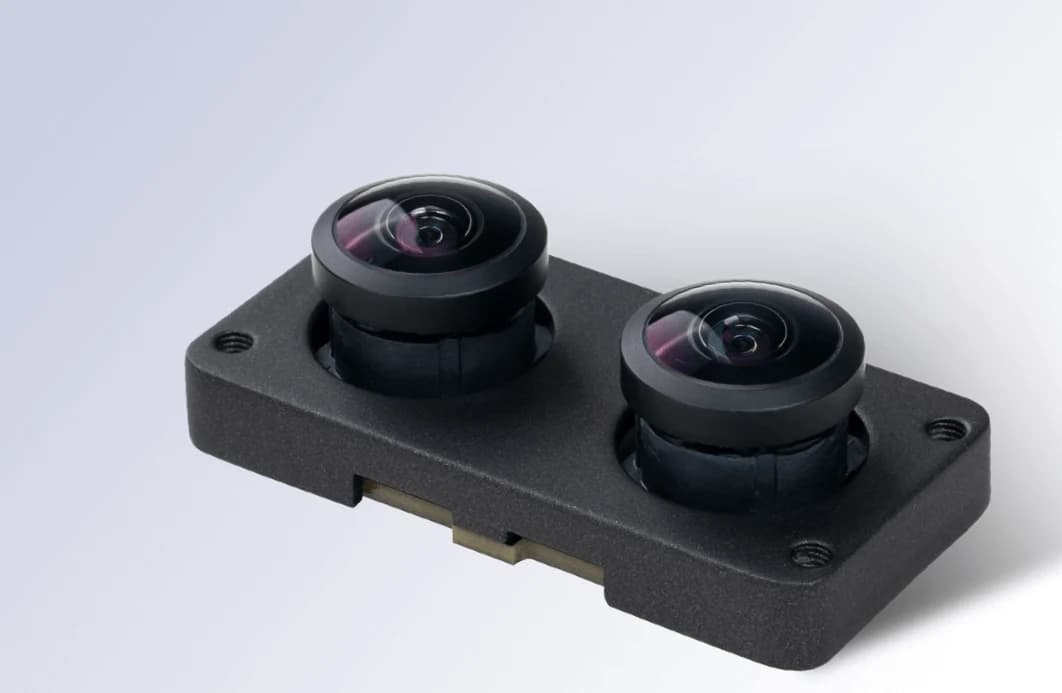
- Yüksek Isı Filtreli Yüzey Tarayıcı Kamerası
- Antistatik Gövde Kaplaması
Proposed software
- Navigation
- Dakikada binlerce metre kağıt saran dev silindirlerin etrafından 3D SLAM kaçınması
- Model
- Silindir Senkronizasyon Kayması ve Kağıt Yırtılma Tespiti
- Integration
- Selüloz Kesim Hattı PLC / SCADA OME Ağı
The robot's real operating limits
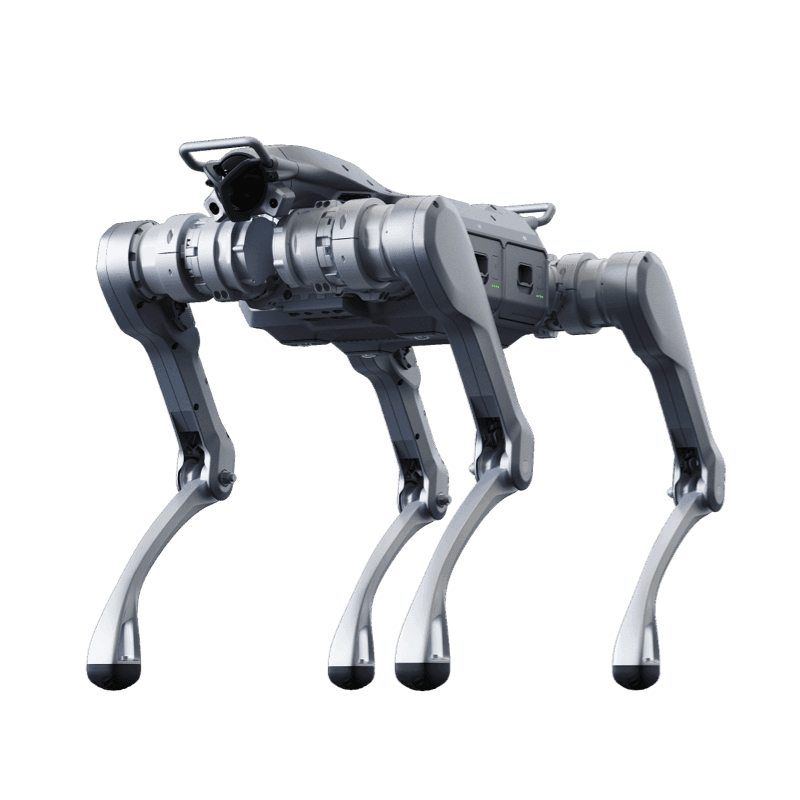
Unitree A2
Industrial Class Legged Robot
Product page- Ingress rating
- IP56-IP67
- Runtime
- >5 hours (No load) / >3 hours (25kg Load)
- Operating temperature
- -20°C to 55°C
- Payload
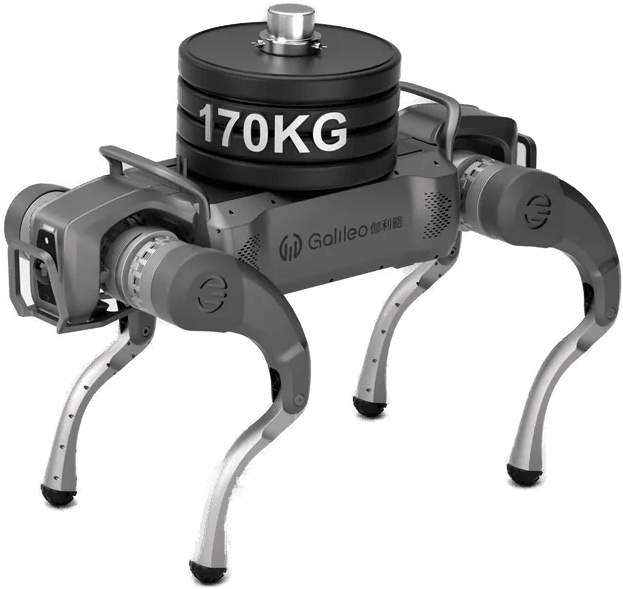
- 100 kg
- Max speed
- 5 m/s
- Climb
- 45°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.