Pharmaceutical Cleanroom Particle and Contamination Mapping
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Outdoor field
- Operating mode
- Teleoperation
- Proposed robot
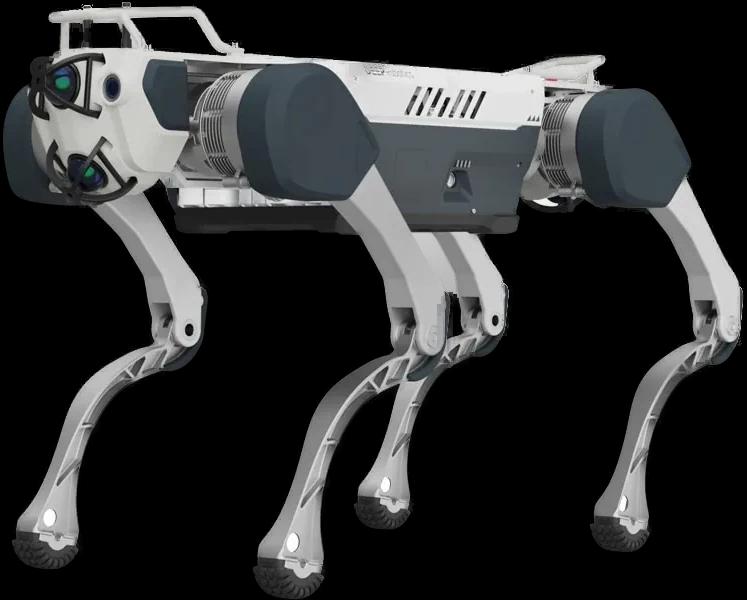
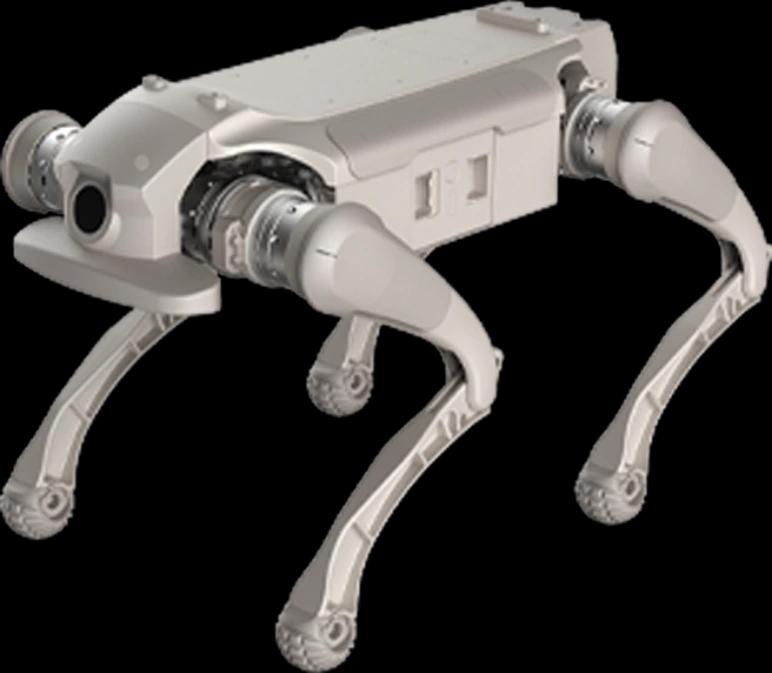
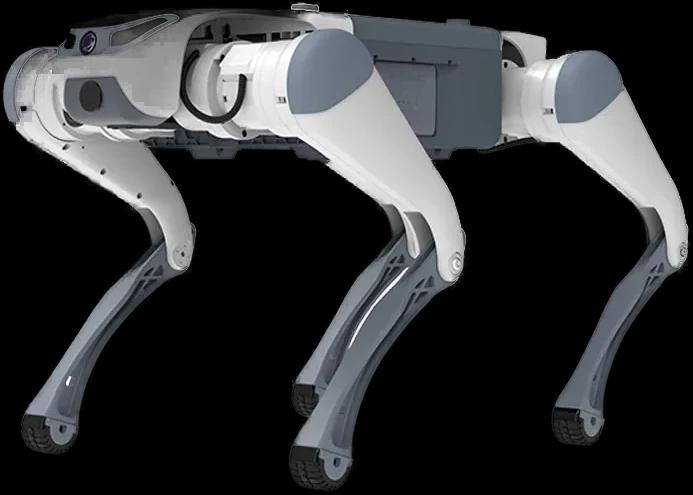
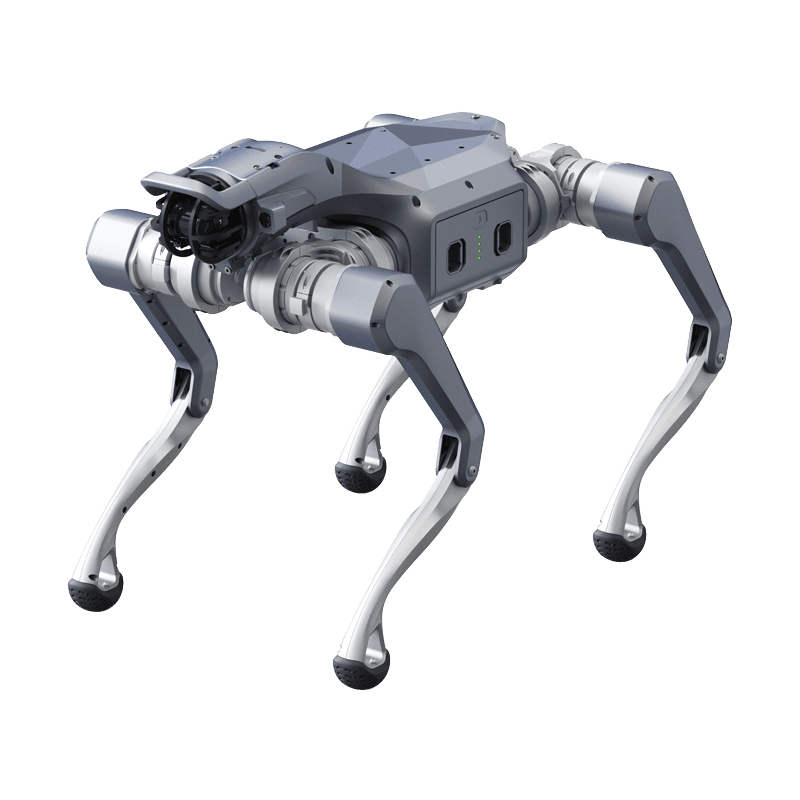
- Unitree A2
The problem addressed
Natural particle contamination from human entry into cleanrooms even in sterile garments, resulting in lost production (batch rejection).
Draft mission flow
- 1Karantina veya aseptik üretim alanlarında insan girmeden (insan derisi dökmeksizin) ortamı tarar.
- 2Havada 1 metreküp içindeki 0.5 ile 5 mikron arası partikülleri sayar.
- 3Odanın hangi noktasında (kapı altı, filtre menfezi) kontaminasyon tavan yaptıysa onu 3 Boyutlu ısı haritasıyla GMP raporuna işler.
Proposed hardware
- Hassas Lazer Partikül Sayacı (0.1 Micron)
- Lidar ile Hava Akımı Modelleme
- HEPA Filtre Uyumlu Tasarım
Proposed software
- Navigation
- Sıfır türbülans yaratacak mikro düzeyde yavaş, sarsıntısız hassas SLAM
- Model
- Havadaki Biyolojik / İnert Parçacık Segmentasyonu
- Integration
- İlaç GMP (İyi Üretim Uygulamaları) Veritabanı
The robot's real operating limits
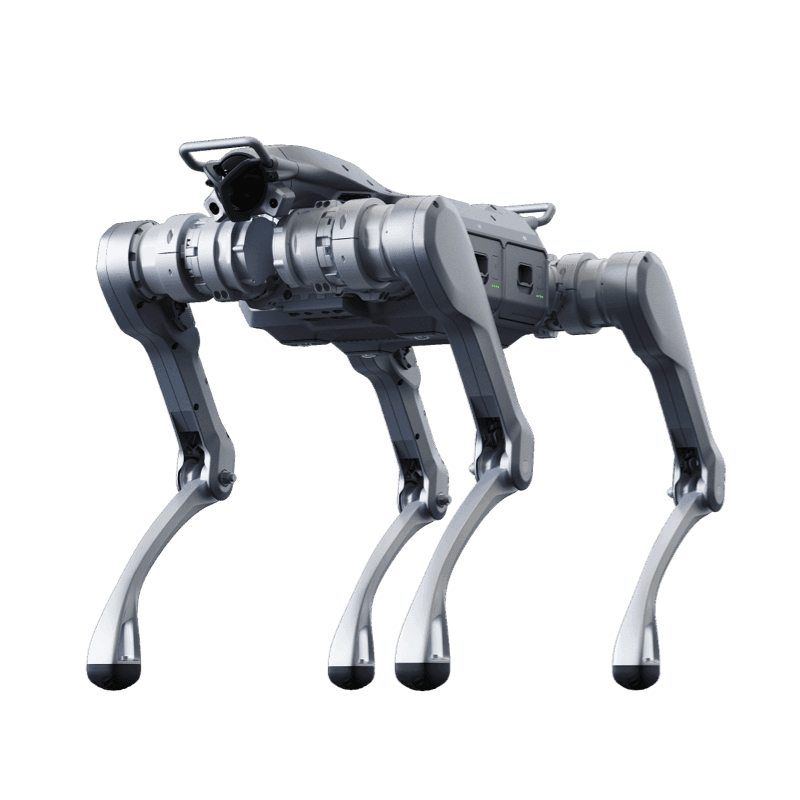
Unitree A2
Industrial Class Legged Robot
Product page- Ingress rating
- IP56-IP67
- Runtime
- >5 hours (No load) / >3 hours (25kg Load)
- Operating temperature
- -20°C to 55°C
- Payload
- 100 kg
- Max speed
- 5 m/s
- Climb
- 45°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.