WiFi Dead Zone Detection & Signal Quality Mapping
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Indoor, public area
- Operating mode
- Supervised autonomy
- Proposed robot
- Unitree AS2
The problem addressed
Constantly dropping WiFi, slow internet, and non-functional mobile app in malls; digital age customer complaint.
Draft mission flow
- 1Robot measures WiFi signal strength, bandwidth, and latency at every point in the mall.
- 2Dead zones (no/weak signal) and high interference areas visualized on 3D heatmap.
- 3Indoor positioning service accuracy tested at each point via Bluetooth beacon receiver.
- 4Access point addition/relocation recommendations automatically reported to IT team; verification tour conducted after fixes.
Proposed hardware
- WiFi 6 Analyzer Module
- Bluetooth Beacon Receiver
- GPS/iBeacon Location Module
- HD Camera
- LED Display
Proposed software
- Navigation
- Grid-based signal measurement route covering all mall areas
- Model
- WiFi Signal Strength Heatmap, Bandwidth Test, and Interference Source Detection
- Integration
- Mall IT Infrastructure Management System and Network Operations Center (NOC)
The robot's real operating limits
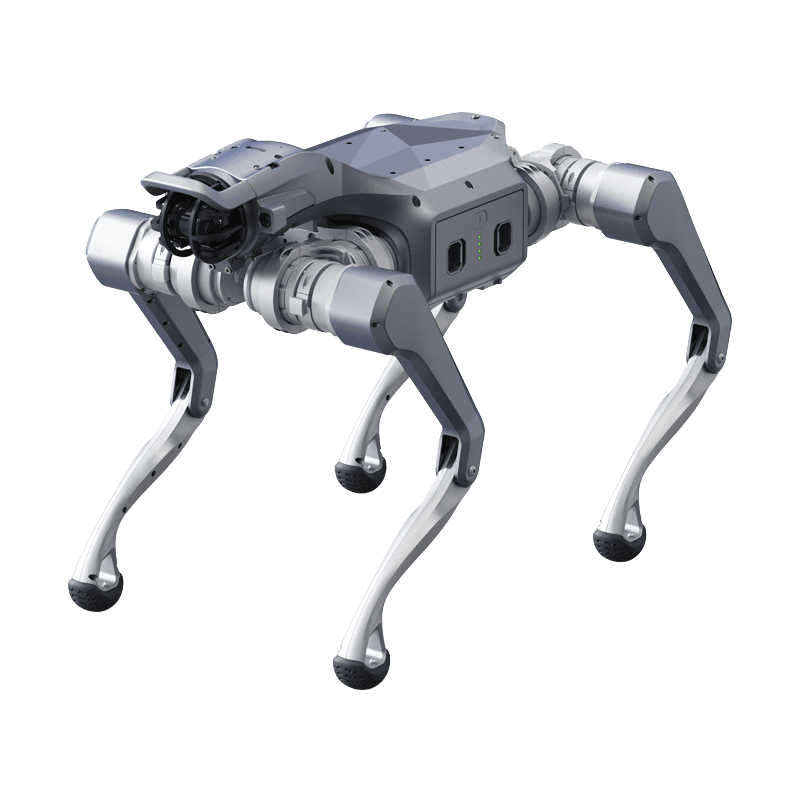
Unitree AS2
Compact industrial robot dog
Product page- Ingress rating
- IP54
- Runtime
- >4 hours (No load)
- Operating temperature
- -20°C to 50°C
- Payload
- Up to 65 kg
- Max speed
- >5 m/s
- Climb
- 40°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.