Industrial Waste Site Environmental Pollution Monitoring Patrol
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Outdoor field
- Operating mode
- Supervised autonomy
- Proposed robot
- Unitree B2
The problem addressed
Late detection of environmental pollution at industrial waste sites and inability to detect illegal dumping.
Draft mission flow
- 1The robot patrols 24/7 around the waste site; gas sensors detect VOC, H2S, and ammonia leaks.
- 2Thermal camera monitors temperature rise (chemical reaction indicator) and overflow risk in waste pools.
- 3When vehicles illegally dumping waste at night detected, license plate and footage reported to Environmental Directorate.
- 4All environmental measurement data transmitted to authorities as daily report; risk prediction made with trend analysis.
Proposed hardware
- Multi Gas Sensor (VOC/H2S/NH3)
- Radiometric Thermal Camera
- HD Camera
- Water Quality Probe Sensor
- 5G Communication
Proposed software
- Navigation
- Autonomous patrol along fence line and basin edge around industrial waste site
- Model
- Gas Leak Point Detection, Liquid Waste Overflow Early Warning, and Illegal Night-Time Dumping Detection
- Integration
- Provincial Directorate of Environment Monitoring System and OIZ Management
The robot's real operating limits
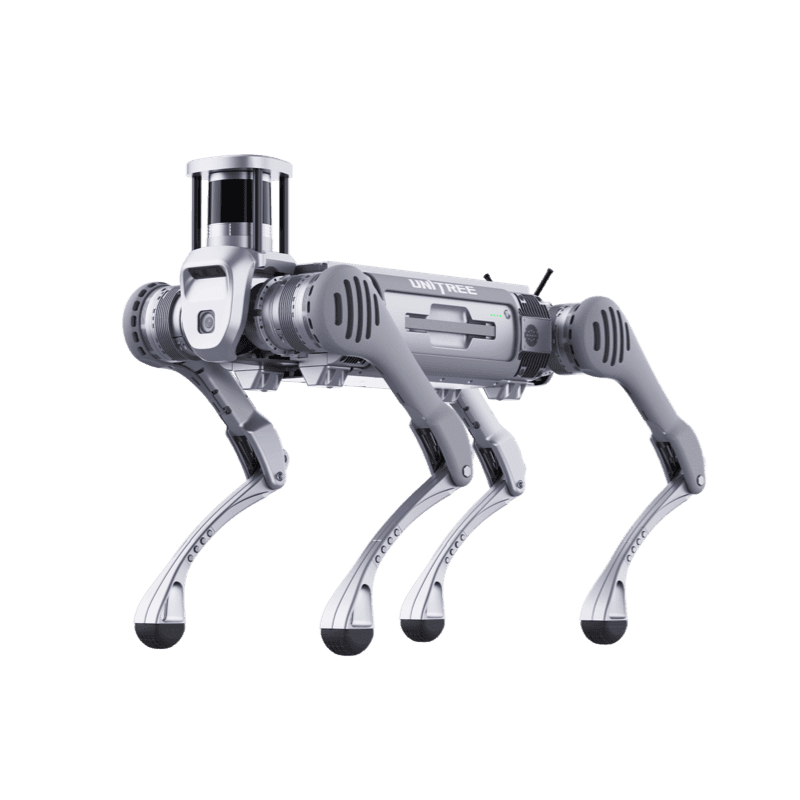
Unitree B2
Industrial robot dog: IP67, 120 kg static payload
Product page- Ingress rating
- IP67
- Runtime
- >5 hours (No load) / >4 hours (20kg Load)
- Operating temperature
- -20°C to 55°C
- Payload
- 120 kg
- Max speed
- >6 m/s
- Climb
- 45°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.