Medical Waste Storage Area Security and Leakage Control
Scenario record: it defines the environment, the mission flow and a proposed hardware and software configuration. The list below is a configuration proposal, not an installation inventory. Field projects lists deployed systems and their measurements.
- Environment
- Outdoor field
- Operating mode
- Supervised autonomy
- Proposed robot
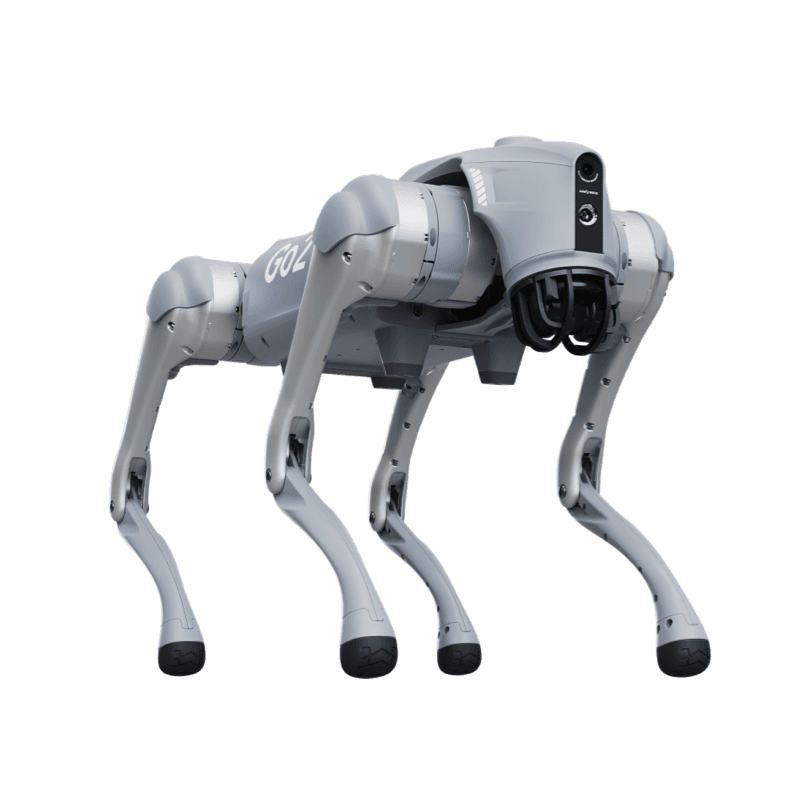
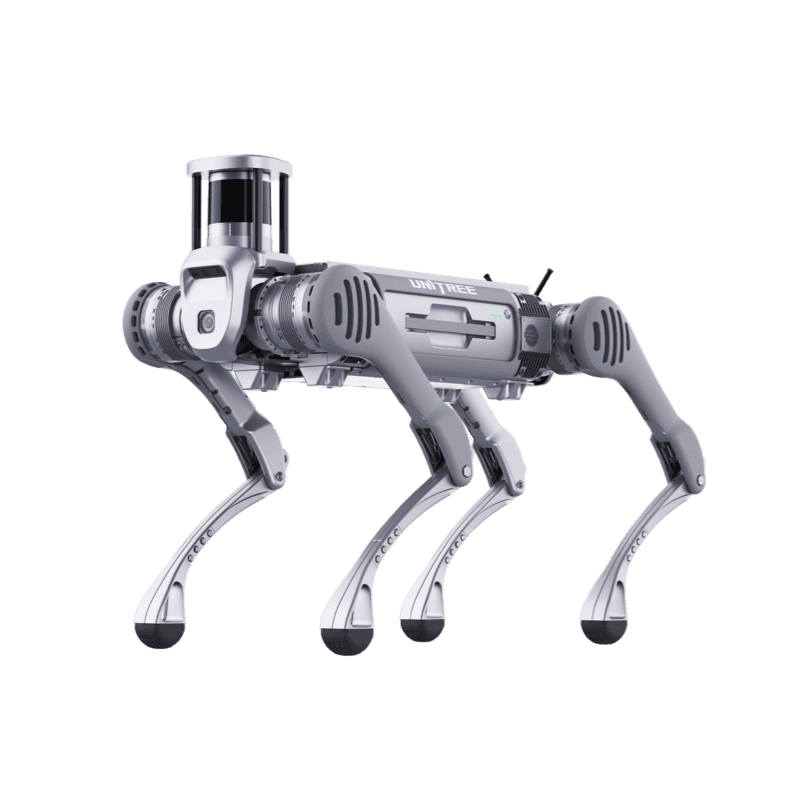
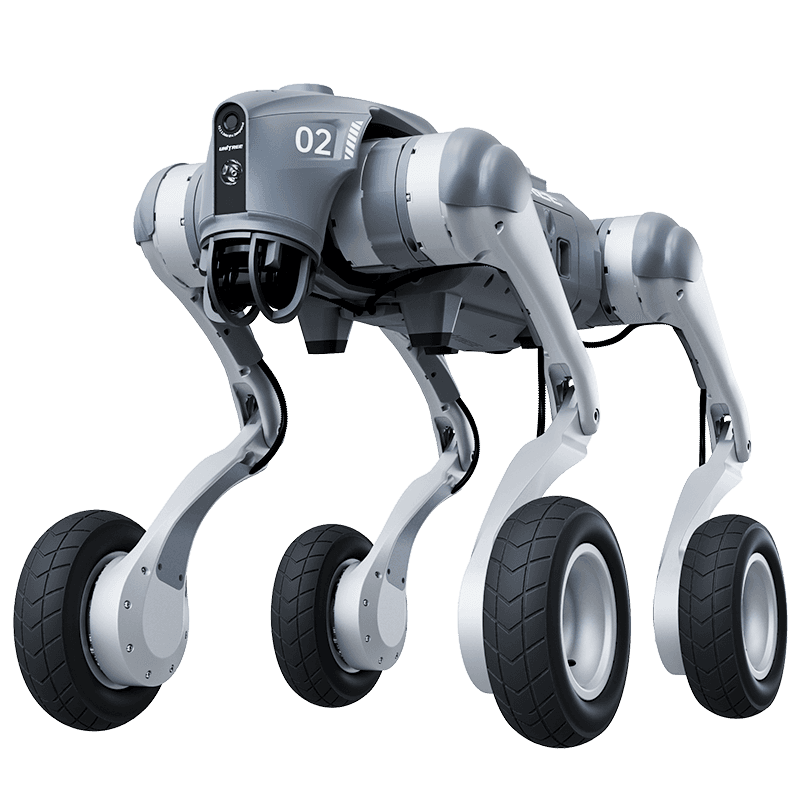
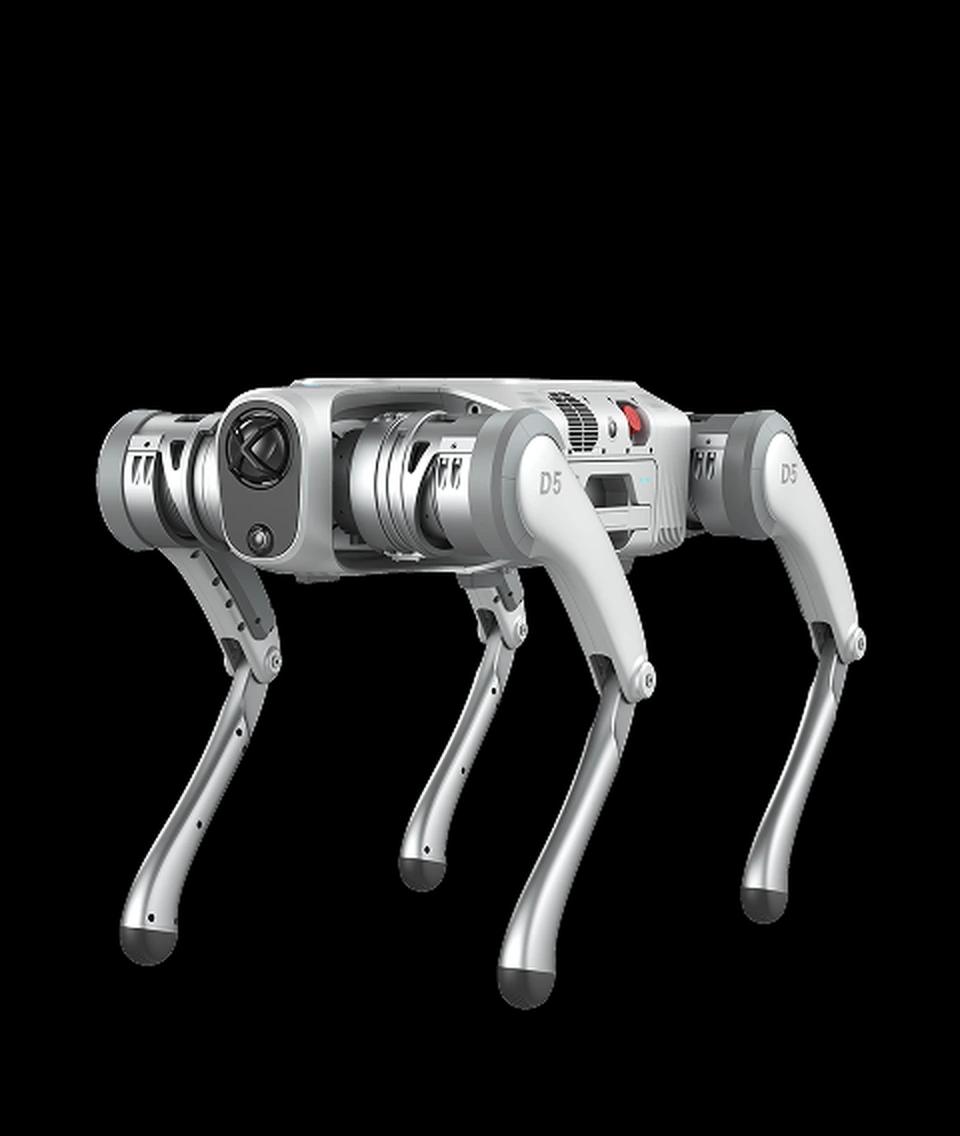
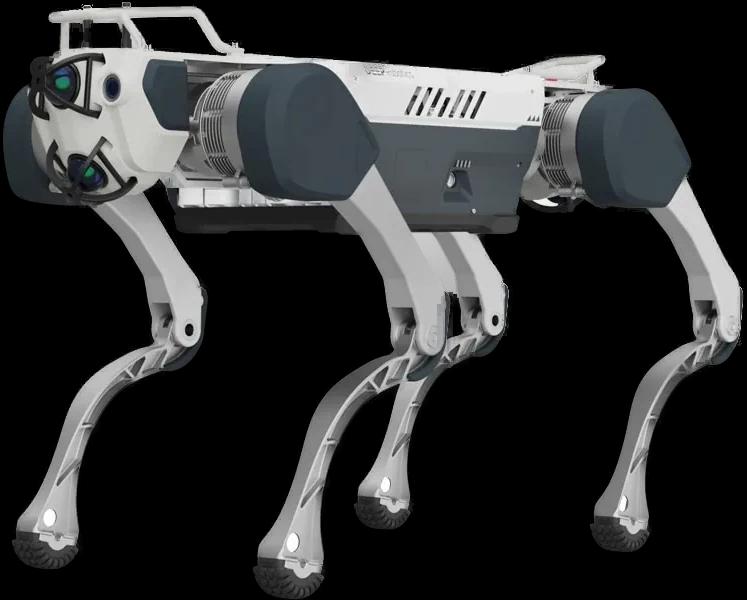
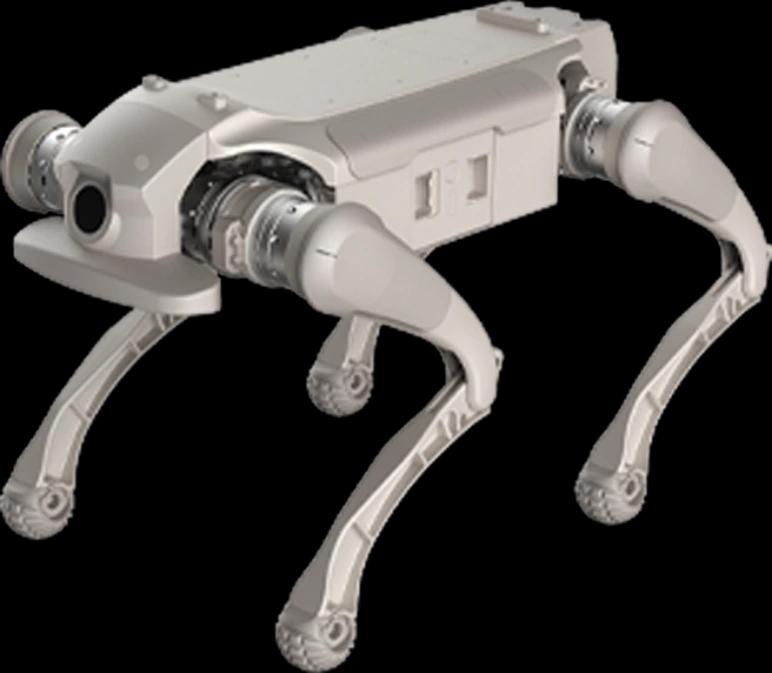
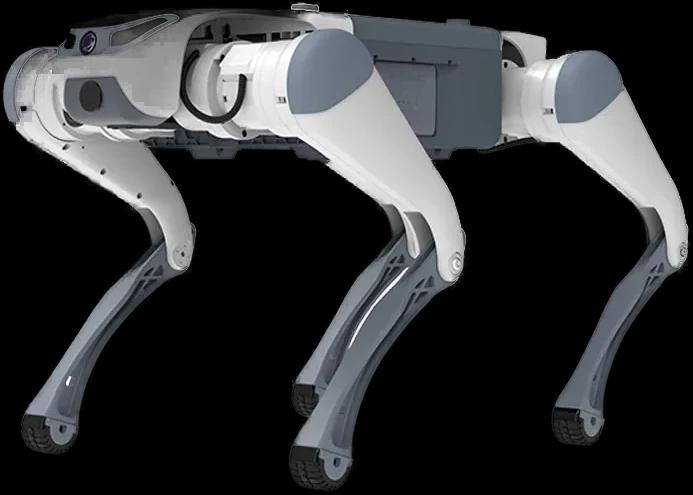
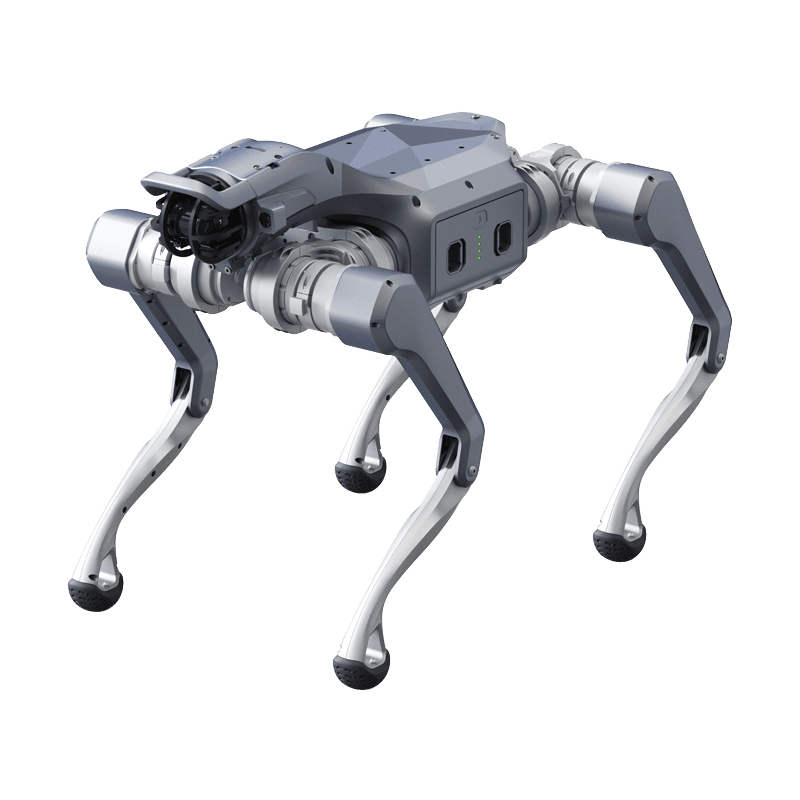
- Unitree A2
The problem addressed
Medical waste leakage creating environmental and health risk; biohazard from unauthorized access.
Draft mission flow
- 1The robot patrols autonomously in the medical waste storage area; checks containers for leaks and damage.
- 2Detects abnormal heating (biological decomposition) with thermal camera and leak color changes with optical camera.
- 3Monitors decomposition gases like H₂S and ammonia with gas detector; evaluates ventilation adequacy.
- 4Detects unauthorized person entry to the area; transmits security and leakage report to waste management system.
Proposed hardware
- Thermal Camera
- HD Optical Camera
- Multi-Gas Detector
- LED Warning Lights
Proposed software
- Navigation
- Safe distance SLAM around and in interior corridors of medical waste storage area
- Model
- Container Leak Detection (Color Change/Moisture Anomaly) and Unauthorized Access Detection
- Integration
- Hospital Waste Management System and Environmental Inspection Portal
The robot's real operating limits
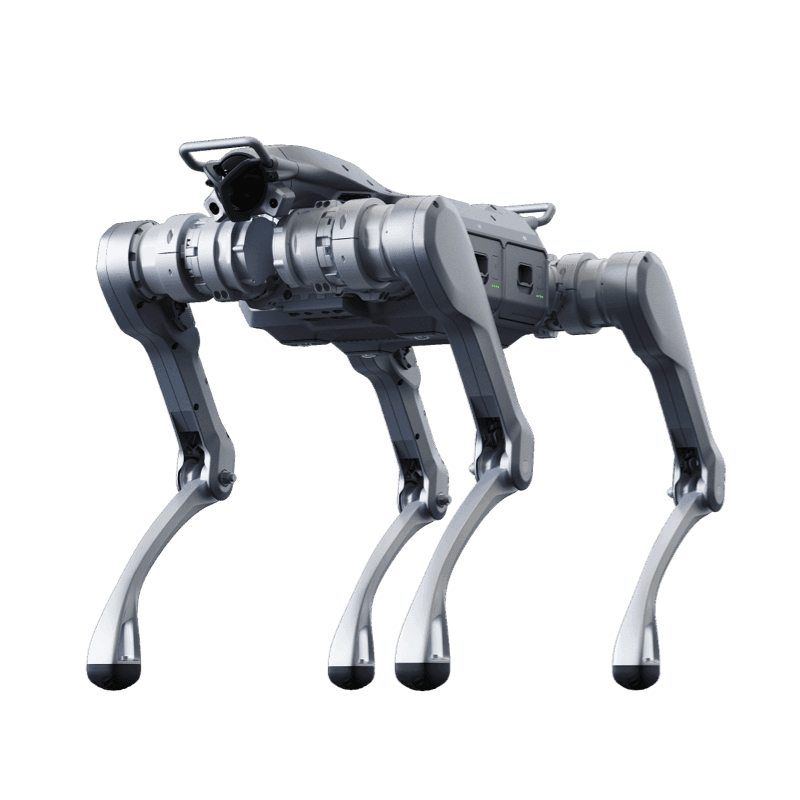
Unitree A2
Industrial Class Legged Robot
Product page- Ingress rating
- IP56-IP67
- Runtime
- >5 hours (No load) / >3 hours (25kg Load)
- Operating temperature
- -20°C to 55°C
- Payload
- 100 kg
- Max speed
- 5 m/s
- Climb
- 45°
Values are manufacturer data. Scenario fit is determined by comparing these limits with site conditions.
From scenario to installation
Feasibility is determined by the site survey: floor and route, network coverage, the charging point, intervention responsibilities and the conditions under which the robot must stop. The survey report defines the scope, the constraints and the commissioning steps.