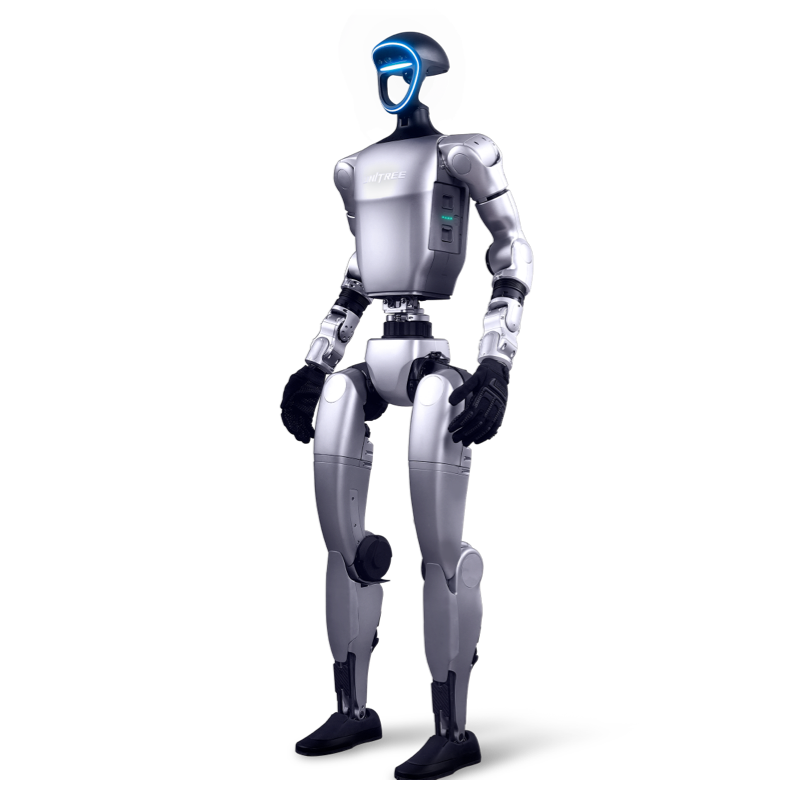
Control and SDK: unitree_sdk2, unitree_sdk2_python
unitree_sdk2 (C++) and unitree_sdk2_python form the G1's core control layer: state reading over CycloneDDS, the high-level locomotion client and low-level joint access. Both repos carry G1-specific example directories (stand-up, walking velocity commands, arm/hand examples). The Python side is for fast prototyping, the C++ side for real-time control loops.
The ROS2 Layer: unitree_ros2
unitree_ros2 bridges DDS messages into the ROS2 Humble world: robot state streams as topics, commands are sent from ROS2 nodes. If you work with Nav2, MoveIt or an existing ROS2 toolchain, this is the entry point. Hands-on setup and examples are in the G1 ROS2 integration guide.
Reinforcement Learning: unitree_rl_gym, unitree_rl_lab, unitree_rl_mjlab
unitree_rl_gym provides official locomotion training examples on Isaac Gym, G1 included; unitree_rl_lab does the same on the current Isaac Lab, and unitree_rl_mjlab on MuJoCo. Environment setup and sim-to-real transfer steps are on the RL Gym page.
Model Files: URDF, MJCF and USD
The g1_description folder under unitree_ros/robots holds the URDF and MJCF body definitions; unitree_model carries the USD counterparts for Isaac Sim. Per-model file names and direct links are listed in the URDF/MJCF/USD table on the open source page.
Teleoperation and Data Collection: xr_teleoperate, unitree_lerobot
xr_teleoperate is the official stack for driving the G1 with Vision Pro, PICO and Quest; demonstration data for imitation learning is collected here. unitree_lerobot converts that data to the LeRobot format and connects it to policy training. The end-to-end flow is in the G1 teleoperation guide.
World Model and VLA: the unifolm Family
unifolm-world-model-action (UnifoLM-WMA-0) opens the multi-embodiment world model and action architecture; unifolm-vla opens the VLA model for humanoid manipulation. This is the watch list for teams running high-level AI on the G1.
Turkish Repositories: the Unitree-Turkiye Organization
The Unitree-Turkiye organization carries the Turkish repos relevant to G1 developers: unitree-g1-isaac-groot-turkce (the GR00T pipeline from data collection to Jetson deployment), unitree-lerobot-turkce (dual-arm data and imitation learning), unitree-hunerli-el-turkce (Dex5-1/Dex3-1 comparison) and the unitree_rl_gym translation.
Which Repo for Which Scenario
First motion command: unitree_sdk2_python | Integration into a ROS2 architecture: unitree_ros2 | Training a walking policy: unitree_rl_gym or unitree_rl_lab | Simulation scene: unitree_ros (URDF/MJCF) + unitree_model (USD) | Collecting demonstrations: xr_teleoperate + unitree_lerobot | Turkish starting point: the Unitree-Turkiye repos. For the hardware side, the G1 product page and the G1 research platform page list the configuration options.