The Official Documentation Center
Unitree's documentation center lives at support.unitree.com: G1 quick start, safety procedures, remote controller and app usage, and in the developer section the SDK services and state machine (FSM) reference. Firmware updates and official app links are also there. It is in English and Chinese.
Hardware Reference Summary
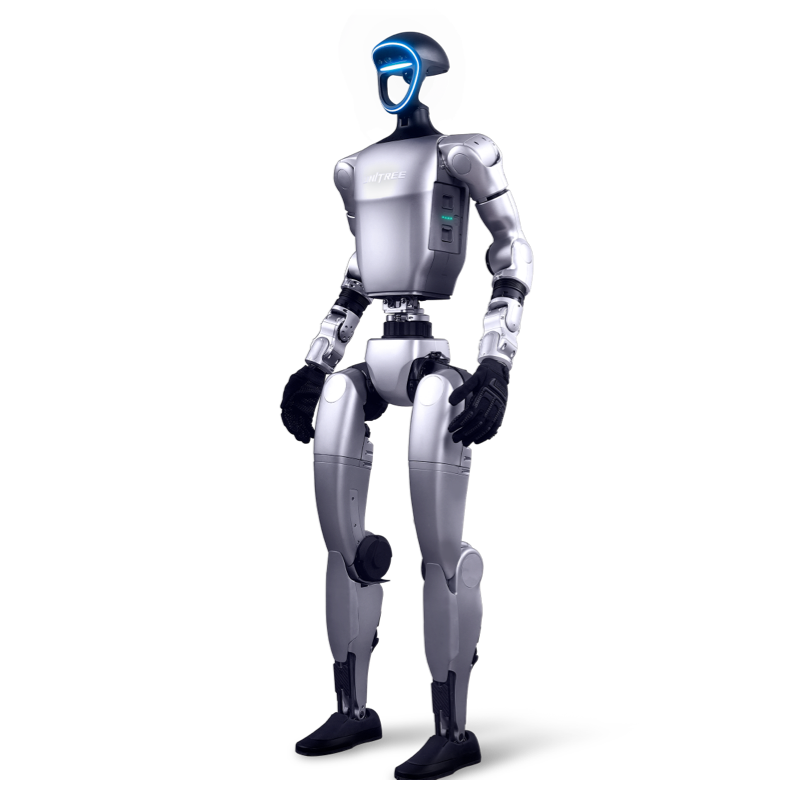
G1: 23 to 43 degrees of freedom (by configuration), NVIDIA Jetson Orin NX (100 TOPS) on the EDU, LIVOX MID360 LiDAR (360° horizontal FOV) and Intel RealSense D435i depth camera, optional Dex3-1 three-fingered hand (7 DoF, Lemo 6-pin interface). The OS side is Ubuntu 22.04 LTS with ROS2 Humble. See the G1 Basic vs EDU comparison for configuration differences and the G1 pricing page for current prices.
Software Stack Map
Control: unitree_sdk2 / unitree_sdk2_python (over CycloneDDS). Integration: unitree_ros2 (ROS2 Humble). Simulation: URDF/MJCF (unitree_ros), USD (unitree_model), Isaac Sim and MuJoCo. Training: unitree_rl_gym / unitree_rl_lab. Teleoperation: xr_teleoperate. The full repo list and scenario mapping is in the G1 GitHub repository map.
Turkish Index: Getting Started and Procurement
G1 product page (specs and configurations) | Basic vs EDU differences | G1 pricing, G1 EDU pricing | G1 research platform (university and corporate research setups).
Turkish Index: Development
SDK development guide (hardware architecture, joint limits, first code) | ROS2 integration examples | G1 SLAM and autonomous navigation | Gait training with RL Gym.
Turkish Index: AI and Data
Isaac GR00T pipeline (from data collection to Jetson deployment) | G1 AI development guide | Teleoperation (Vision Pro, PICO, Quest) | Imitation learning with LeRobot | Dex5-1 dexterous hand.
Which Document for Which Job
Unboxing and first run: official quick start (support.unitree.com) | First Python command: SDK development guide | Connecting to an existing ROS2 system: ROS2 integration examples | Mapping and autonomous walking: G1 SLAM guide | Policy training: RL Gym | Teaching skills from demonstrations: teleoperation + LeRobot | Purchase decision: Basic/EDU comparison + pricing pages.